The five-finger adaptive robotic hand that gives Unitree humanoids and Z1 arms a research-grade manipulator — 15 degrees of freedom, ~1 kg, ±0.2 mm fingertip repeatability, multi-contact tactile fingertips, EtherCAT + TTL control, and a quick-swap wrist adapter. Retrofit your existing G1, H1, H2 or Z1 in under five minutes.
Most robotic hands stop at a claw. The Dex5-1 delivers a full anthropomorphic five-finger design with per-finger tactile feedback, low-latency EtherCAT control and quick retrofit compatibility for the Unitree platforms you already own.
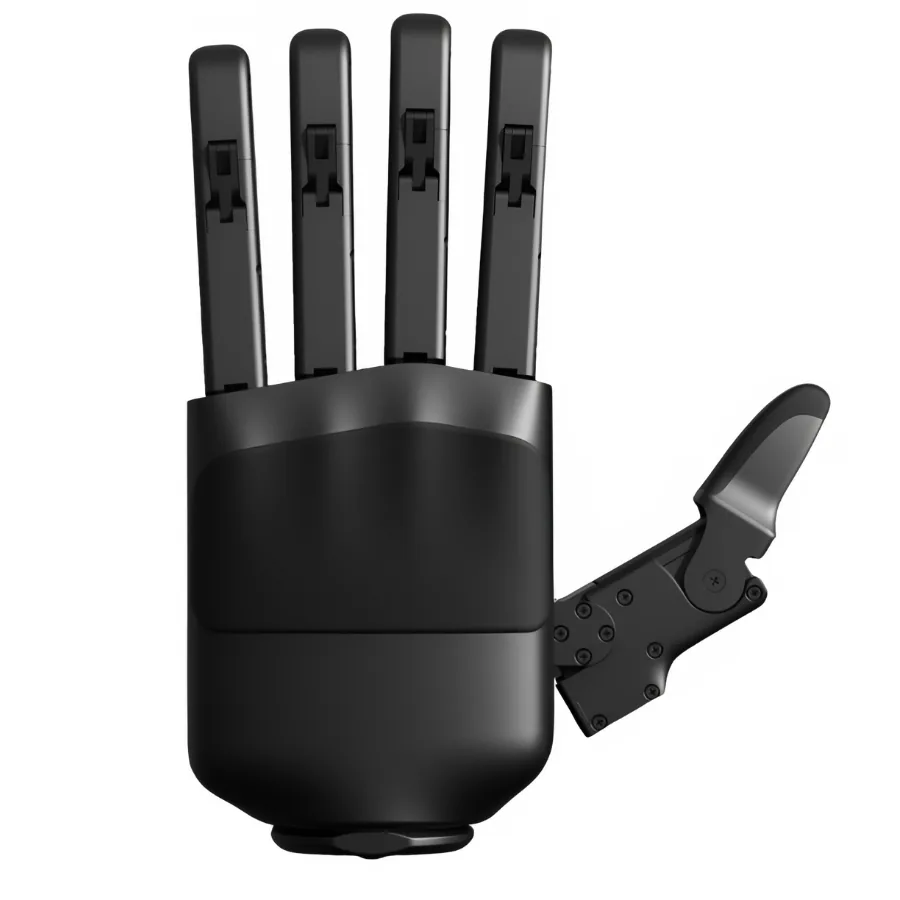
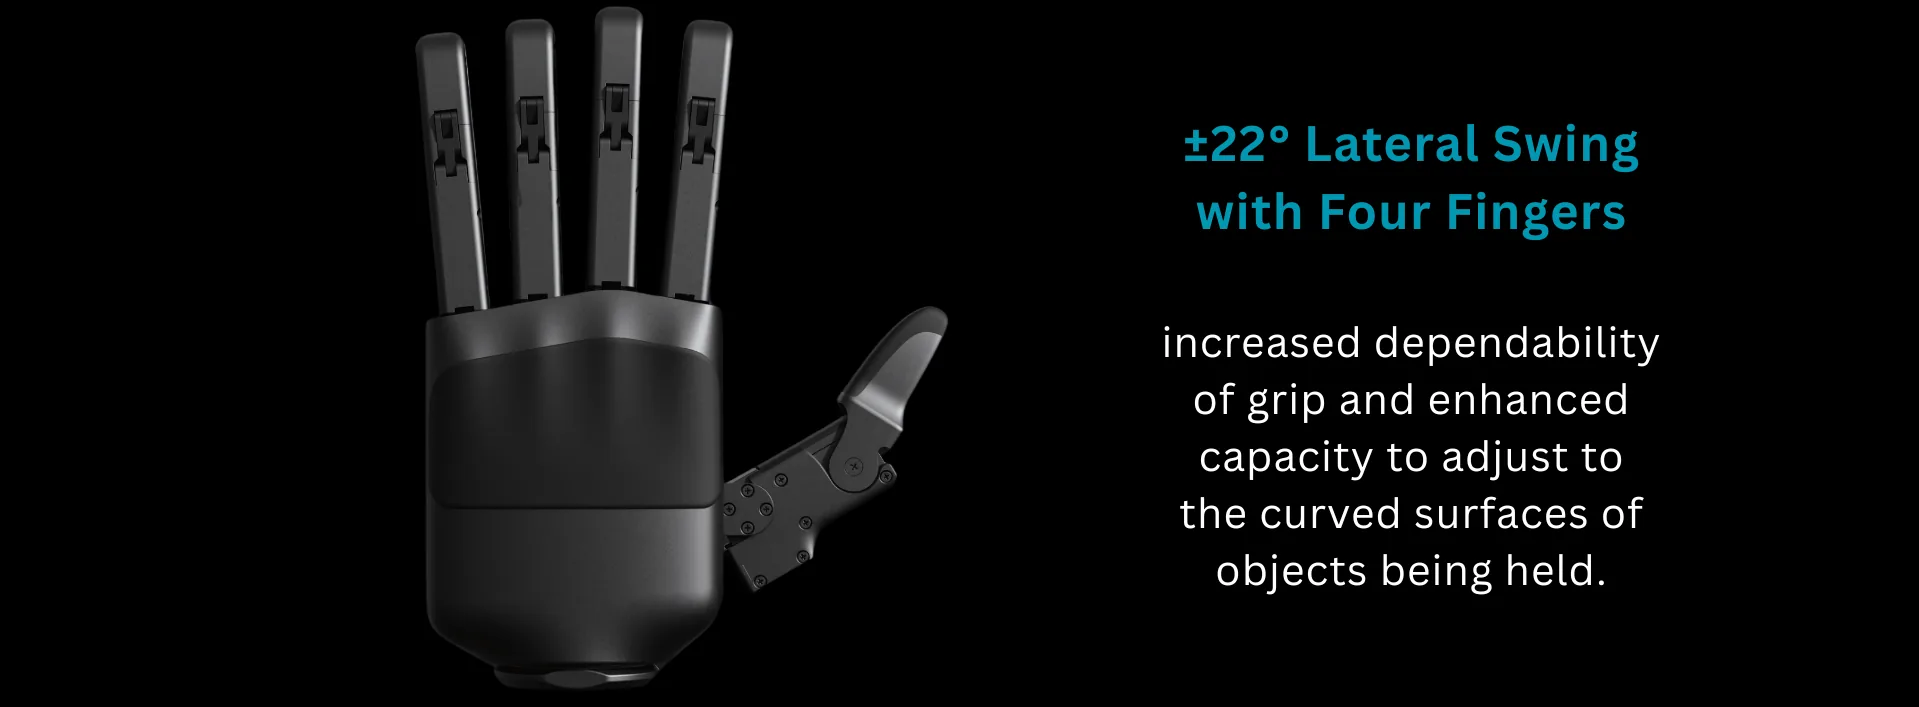
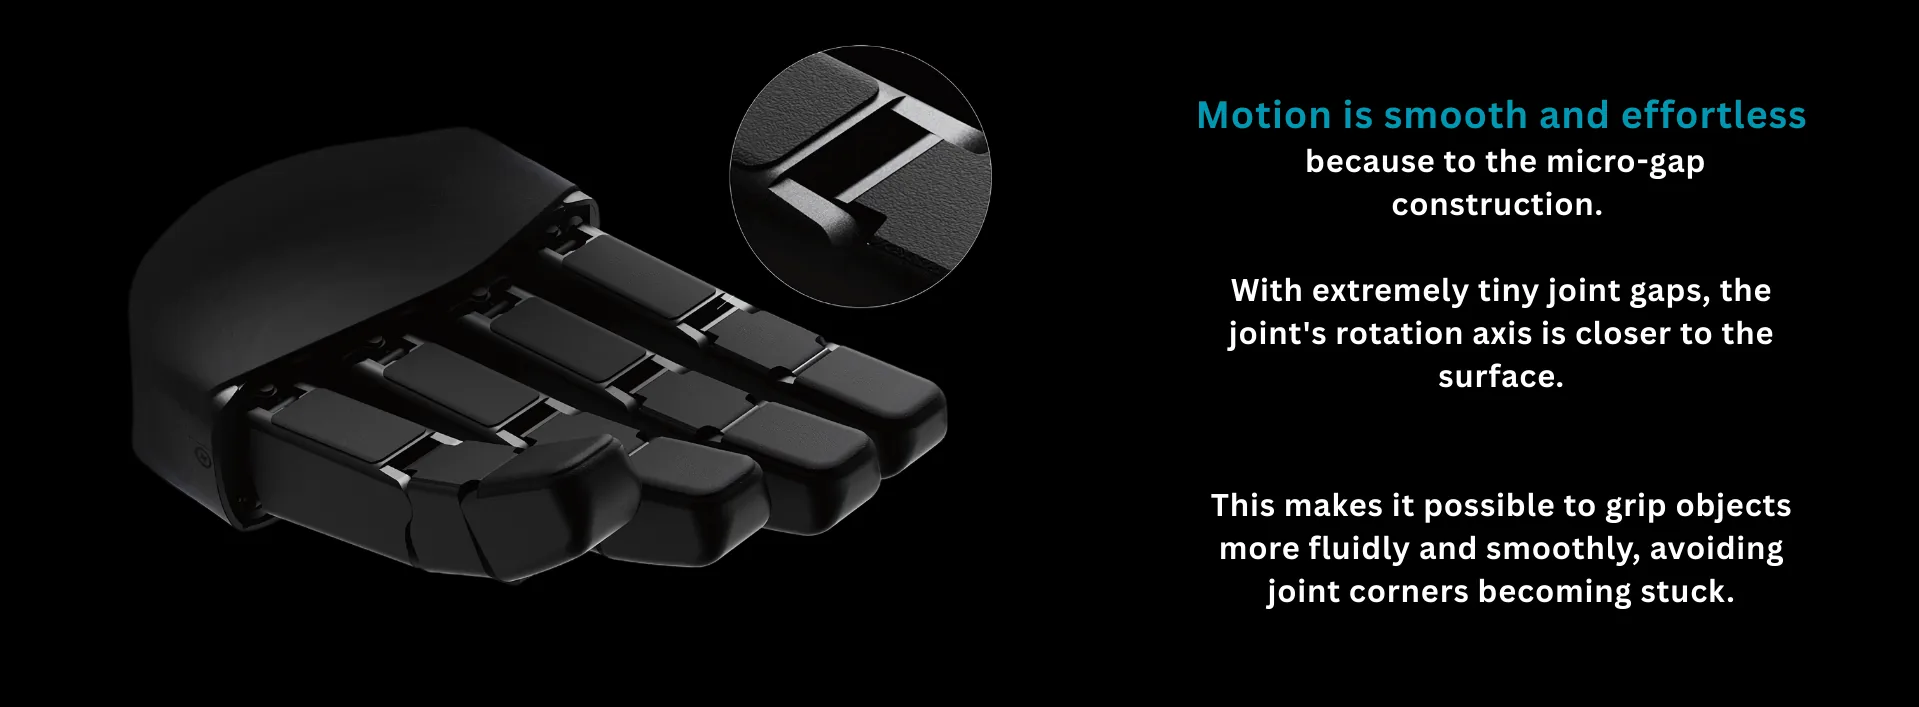
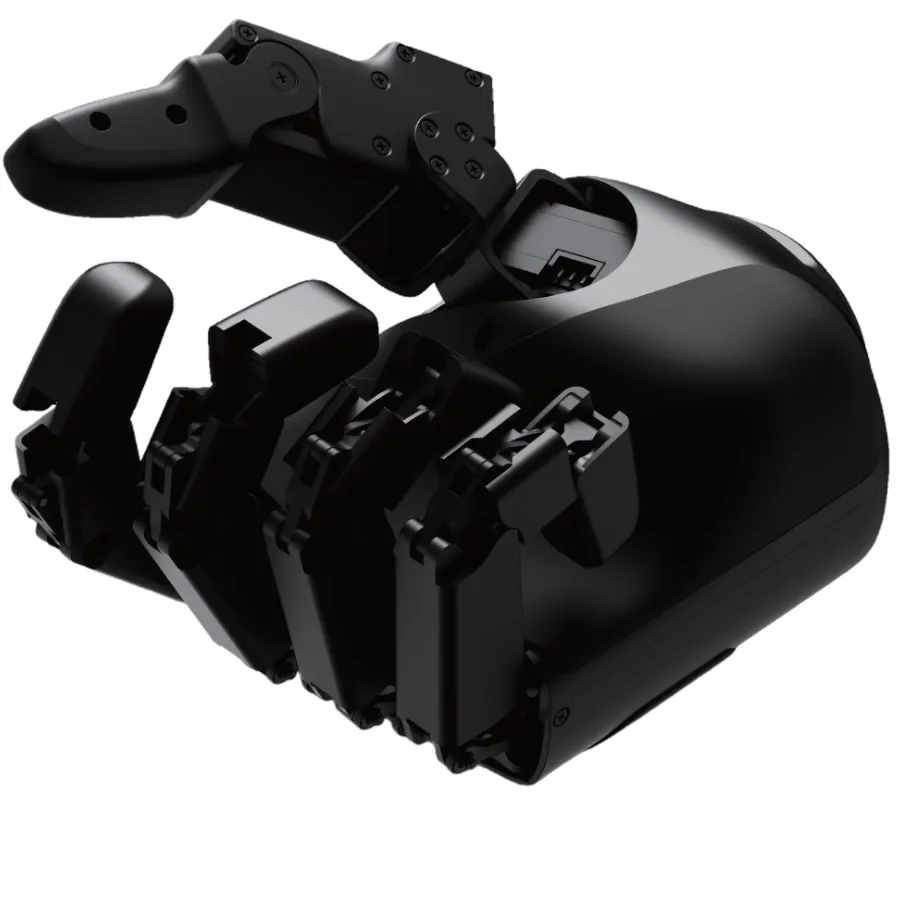
Five modular fingers, three active joints each, with a coupled palm-spread mechanism for enveloping grasps. Magnesium-alloy frame and polymer links keep the hand under 1 kg while delivering 20–30 N of fingertip force. Serviceable digits mean a bent tendon or worn silicone pad is a five-minute repair, not a return-to-manufacturer job.
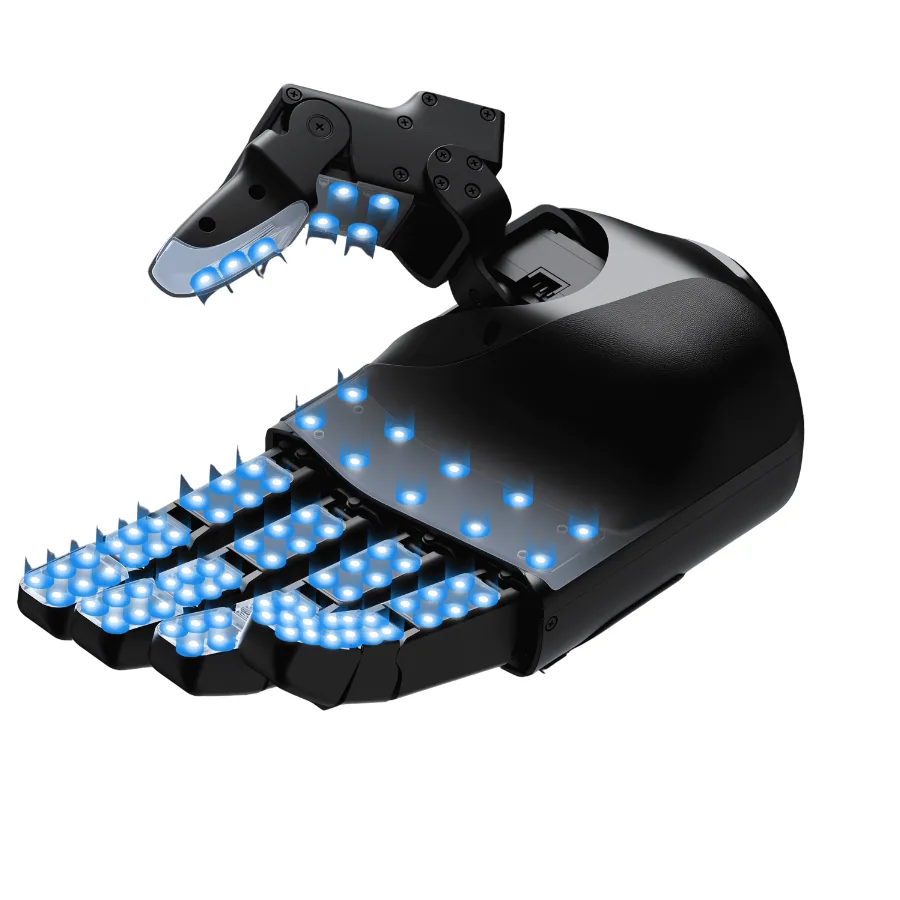
Every fingertip is instrumented with a multi-zone capacitive / pressure tactile array — the sensor input imitation-learning and contact-rich manipulation policies need. Silicone tactile pads give consistent surface friction across a wide range of grasped objects, from a golf ball to a stapler.
Five pre-built grasp primitives ship in the firmware — call them by name from the SDK and the on-board controller runs the coordinated finger trajectories. Or drive individual joints directly via position, velocity, force or impedance modes for research work. Built-in over-current and jam protection keeps servos safe during risky grasps.
A four-bolt M4 quick-swap wrist interface on a 31–34 mm PCD retrofits directly onto Unitree H1, G1, H2 and Z1 arm mounts. Pre-wired 1.5 m harness (custom lengths available). ROS 2 URDF meshes and C++ / Python SDK ship with the box — your existing manipulation stack sees the Dex5-1 as another end-effector, not a new robot.
Full mechanical, electrical, tactile, and integration specifications.
Specs per Unitree Dex5-1 datasheet. Pair configuration available. Sensor coverage (Dex5-1 vs Dex5-1P tactile) ships per order. Compatible with Unitree G1, H1, H2 and Z1 arm; ask for a bracket if you need to retrofit a non-Unitree arm.
Five pre-built motion primitives plus one fully-articulated mode — pick the grasp your task needs, drive it by name.
Thumb + index fingertip · small objects · ~20 N
Wrap-around · cylinders / handles · envelope contact
Thumb + index + middle · stable three-point hold
Thumb + side of index · keys, cards, thin objects
All 5 fingers · balls, apples, curved objects
Per-joint position / velocity / force / impedance
The five-finger hand that Indian research groups and integrators fit to their existing Unitree platforms.
Contact-rich grasping, dexterous manipulation, tool use — tactile fingertips give the sensor resolution real research needs.
Teleoperate + record on H1 / G1 / H2, train VLA and behavioural-cloning policies, deploy back onto the same hand.
Already own a Unitree G1, H1, H2 or Z1? Retrofit the Dex5-1 in under five minutes and unlock five-finger manipulation.
System integrators who need a productionised five-finger end-effector with EtherCAT, ROS 2 drivers and industrial-grade servicing.
The quick-swap wrist adapter is designed for the Unitree H1, G1, H2 humanoid platforms and the Z1 arm (via an adapter plate). Install takes under five minutes with the pre-wired 1.5 m harness. If you need to fit the Dex5-1 to a non-Unitree arm, ask us for a custom bracket — we’ve integrated Dex5-1 with several third-party arm mounts.
The Dex5-1 ships as a single hand in the base kit (hand + wrist adapter + cable set + pad kit + quick-start guide). Pair configuration is available on request — useful if you’re running bilateral manipulation research or upgrading both hands on an H2. Ask for the paired quote on enquiry.
Every fingertip carries a multi-zone capacitive / pressure array — sensors that read contact area, contact force distribution and slip signals in real time. The signals stream over EtherCAT to the host controller with ≤ 5–10 ms latency, making them usable for closed-loop grasp control, tactile-conditioned imitation-learning policies and force-feedback teleoperation.
Position, velocity, grip-force and impedance control — per joint. Plus five pre-built motion primitives (pinch, power grasp, tripod, lateral, spherical) callable by name from the SDK. Built-in over-current, jam detection and auto-home / calibration keep the servos safe during risky grasps.
C++ and Python SDK, plus ROS and ROS 2 drivers with URDF meshes for simulation. EtherCAT (CoE) at ≤ 5–10 ms latency for real-time control loops, TTL for simpler integrations. Compatible with existing Unitree SDK stacks — your G1, H1 or H2 host code sees the Dex5-1 as a swappable end-effector.
Yes. The hand is modular by design — individual finger modules are serviceable, silicone tactile pads swap out with the included pad kit, and cable harnesses are pre-wired for quick replacement. Field-serviceable on-site rather than return-to-factory; xBoom carries spare pads and finger modules for AMC customers.
12-month manufacturer warranty plus the 1-Year xBoom AMC — parts, labour, on-site visits within India, dedicated support engineer. KYC approval is required before dispatch. Pan-India insured shipping from Bengaluru; GCC coverage via our Dubai office.
Tell us the host platform — H1, G1, H2, Z1 arm or a custom mount — and we’ll drop an INR proposal into your inbox with GST invoice, KYC and AMC options.
Drones and related equipment on this website are regulated in India. Before you continue, please note:
Tick the box to enable the button. Shown once every 30 days.