
Unitree R1-A5 Smart B
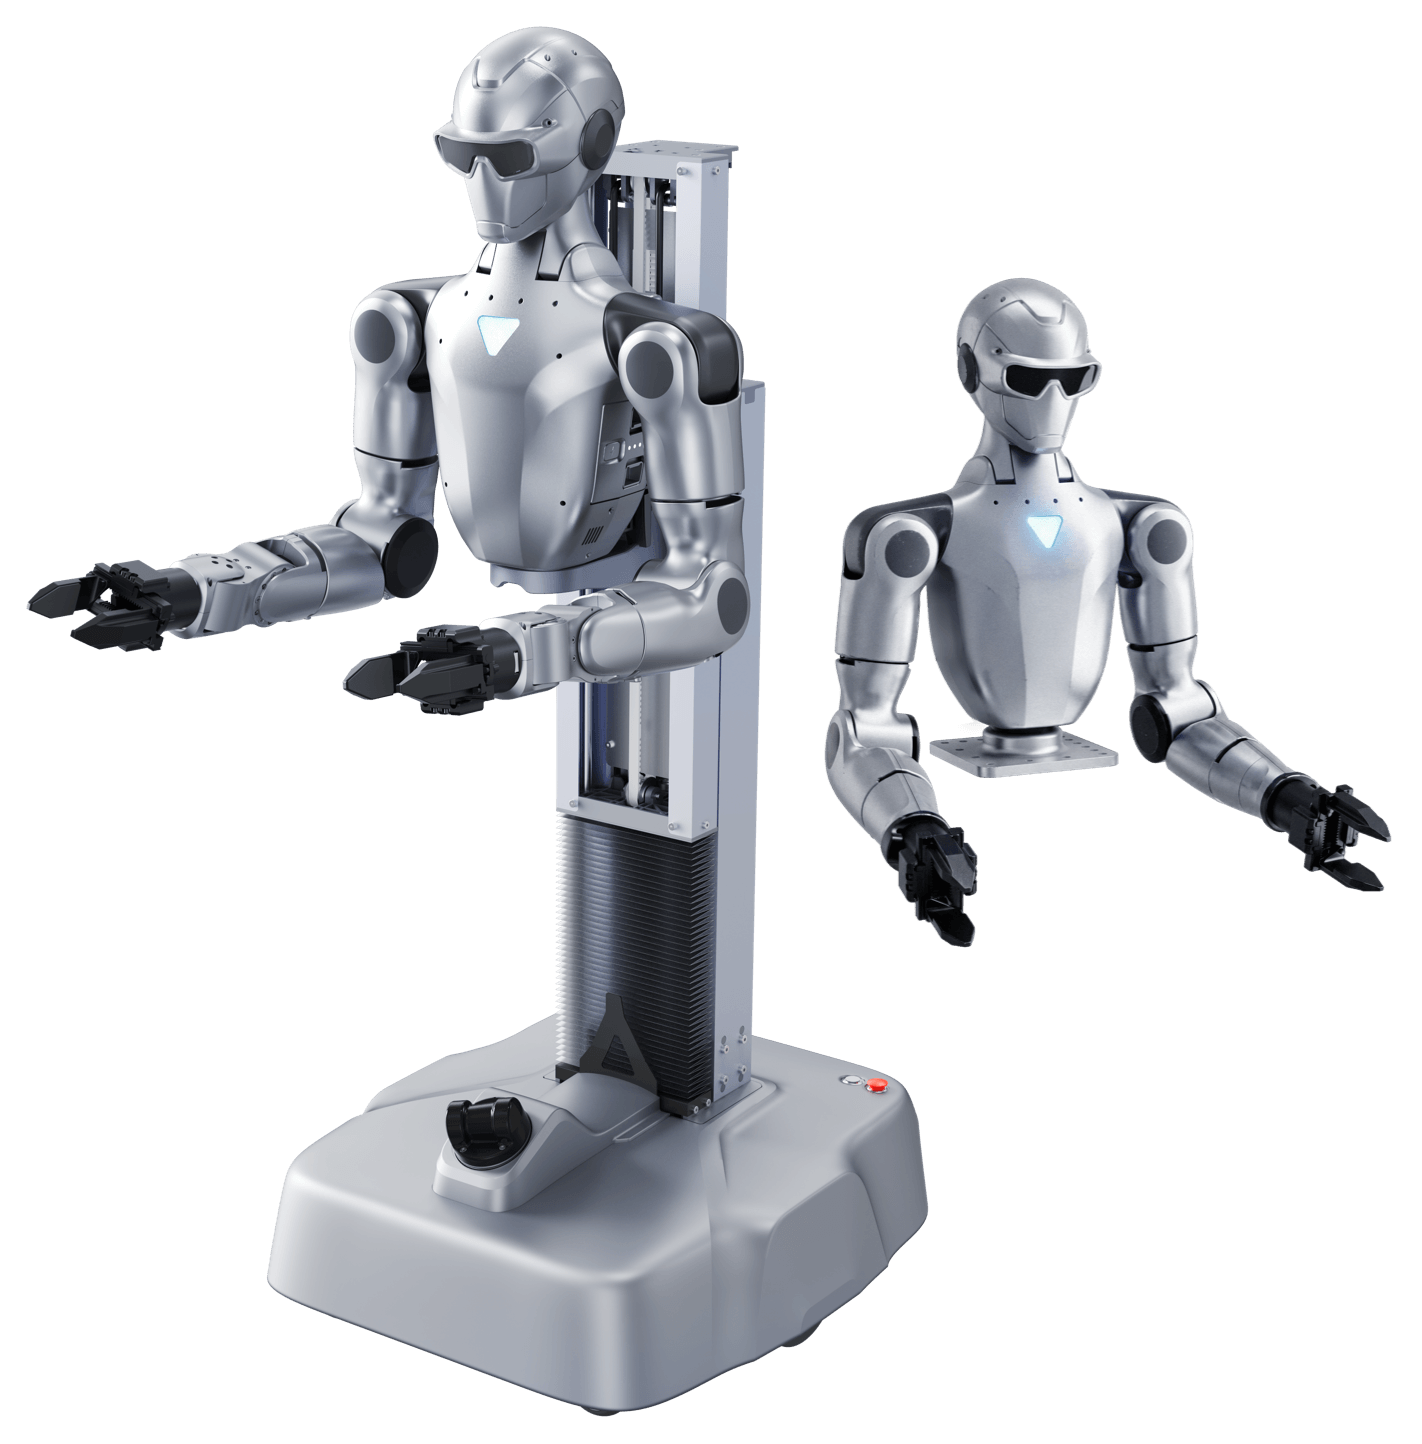
- 27 DOF dual-arm humanoid robot: 5×2 arms + 1 waist + 2 head + 7×2 end effector
- Dimensions: 700×357×190mm
- Arms: 420mm upper arm + forearm, approx. 2kg arm load
- Joint ranges: waist yaw ±150°, head yaw ±115° / pitch ±36°
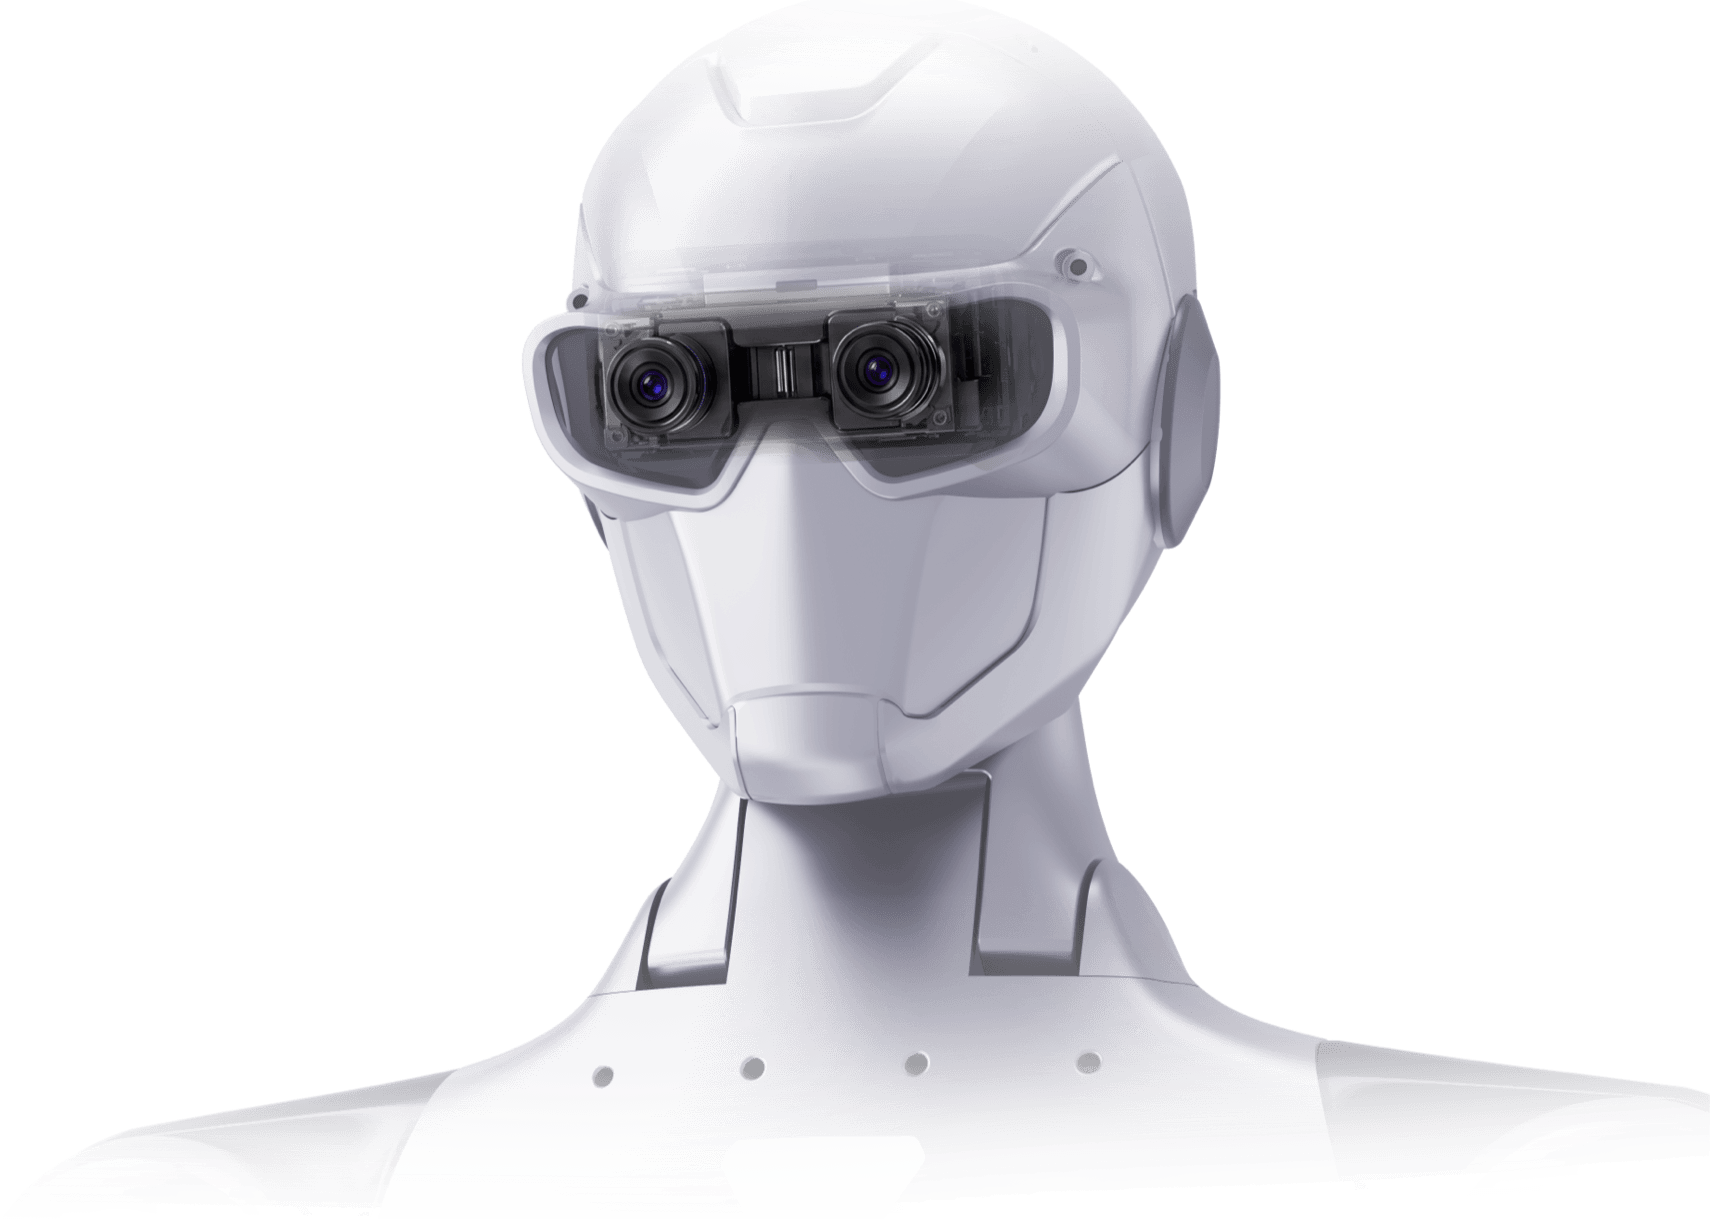
- Perception: binocular camera + wrist cameras; built-in 40tops docking station
- Computing: 8-core body CPU, 8-core head CPU with 10TOPS, 4-microphone array, dual speakers, WiFi 6 / Bluetooth 5.2
- End effector: 2× Dex3-1 dexterous hand (non-tactile)s
- External power or optional R1-A upper body battery (about 1.5h); OTA, secondary development
- Trusted dealerDirect manufacturer partnership
- Pan-India deliveryInsured shipping, all states
- Post-sale supportTraining + service included
What makes it work
R1-A5 Smart B Dual-Arm Humanoid Robot
Ultra-fast deployment, multi-scenario application
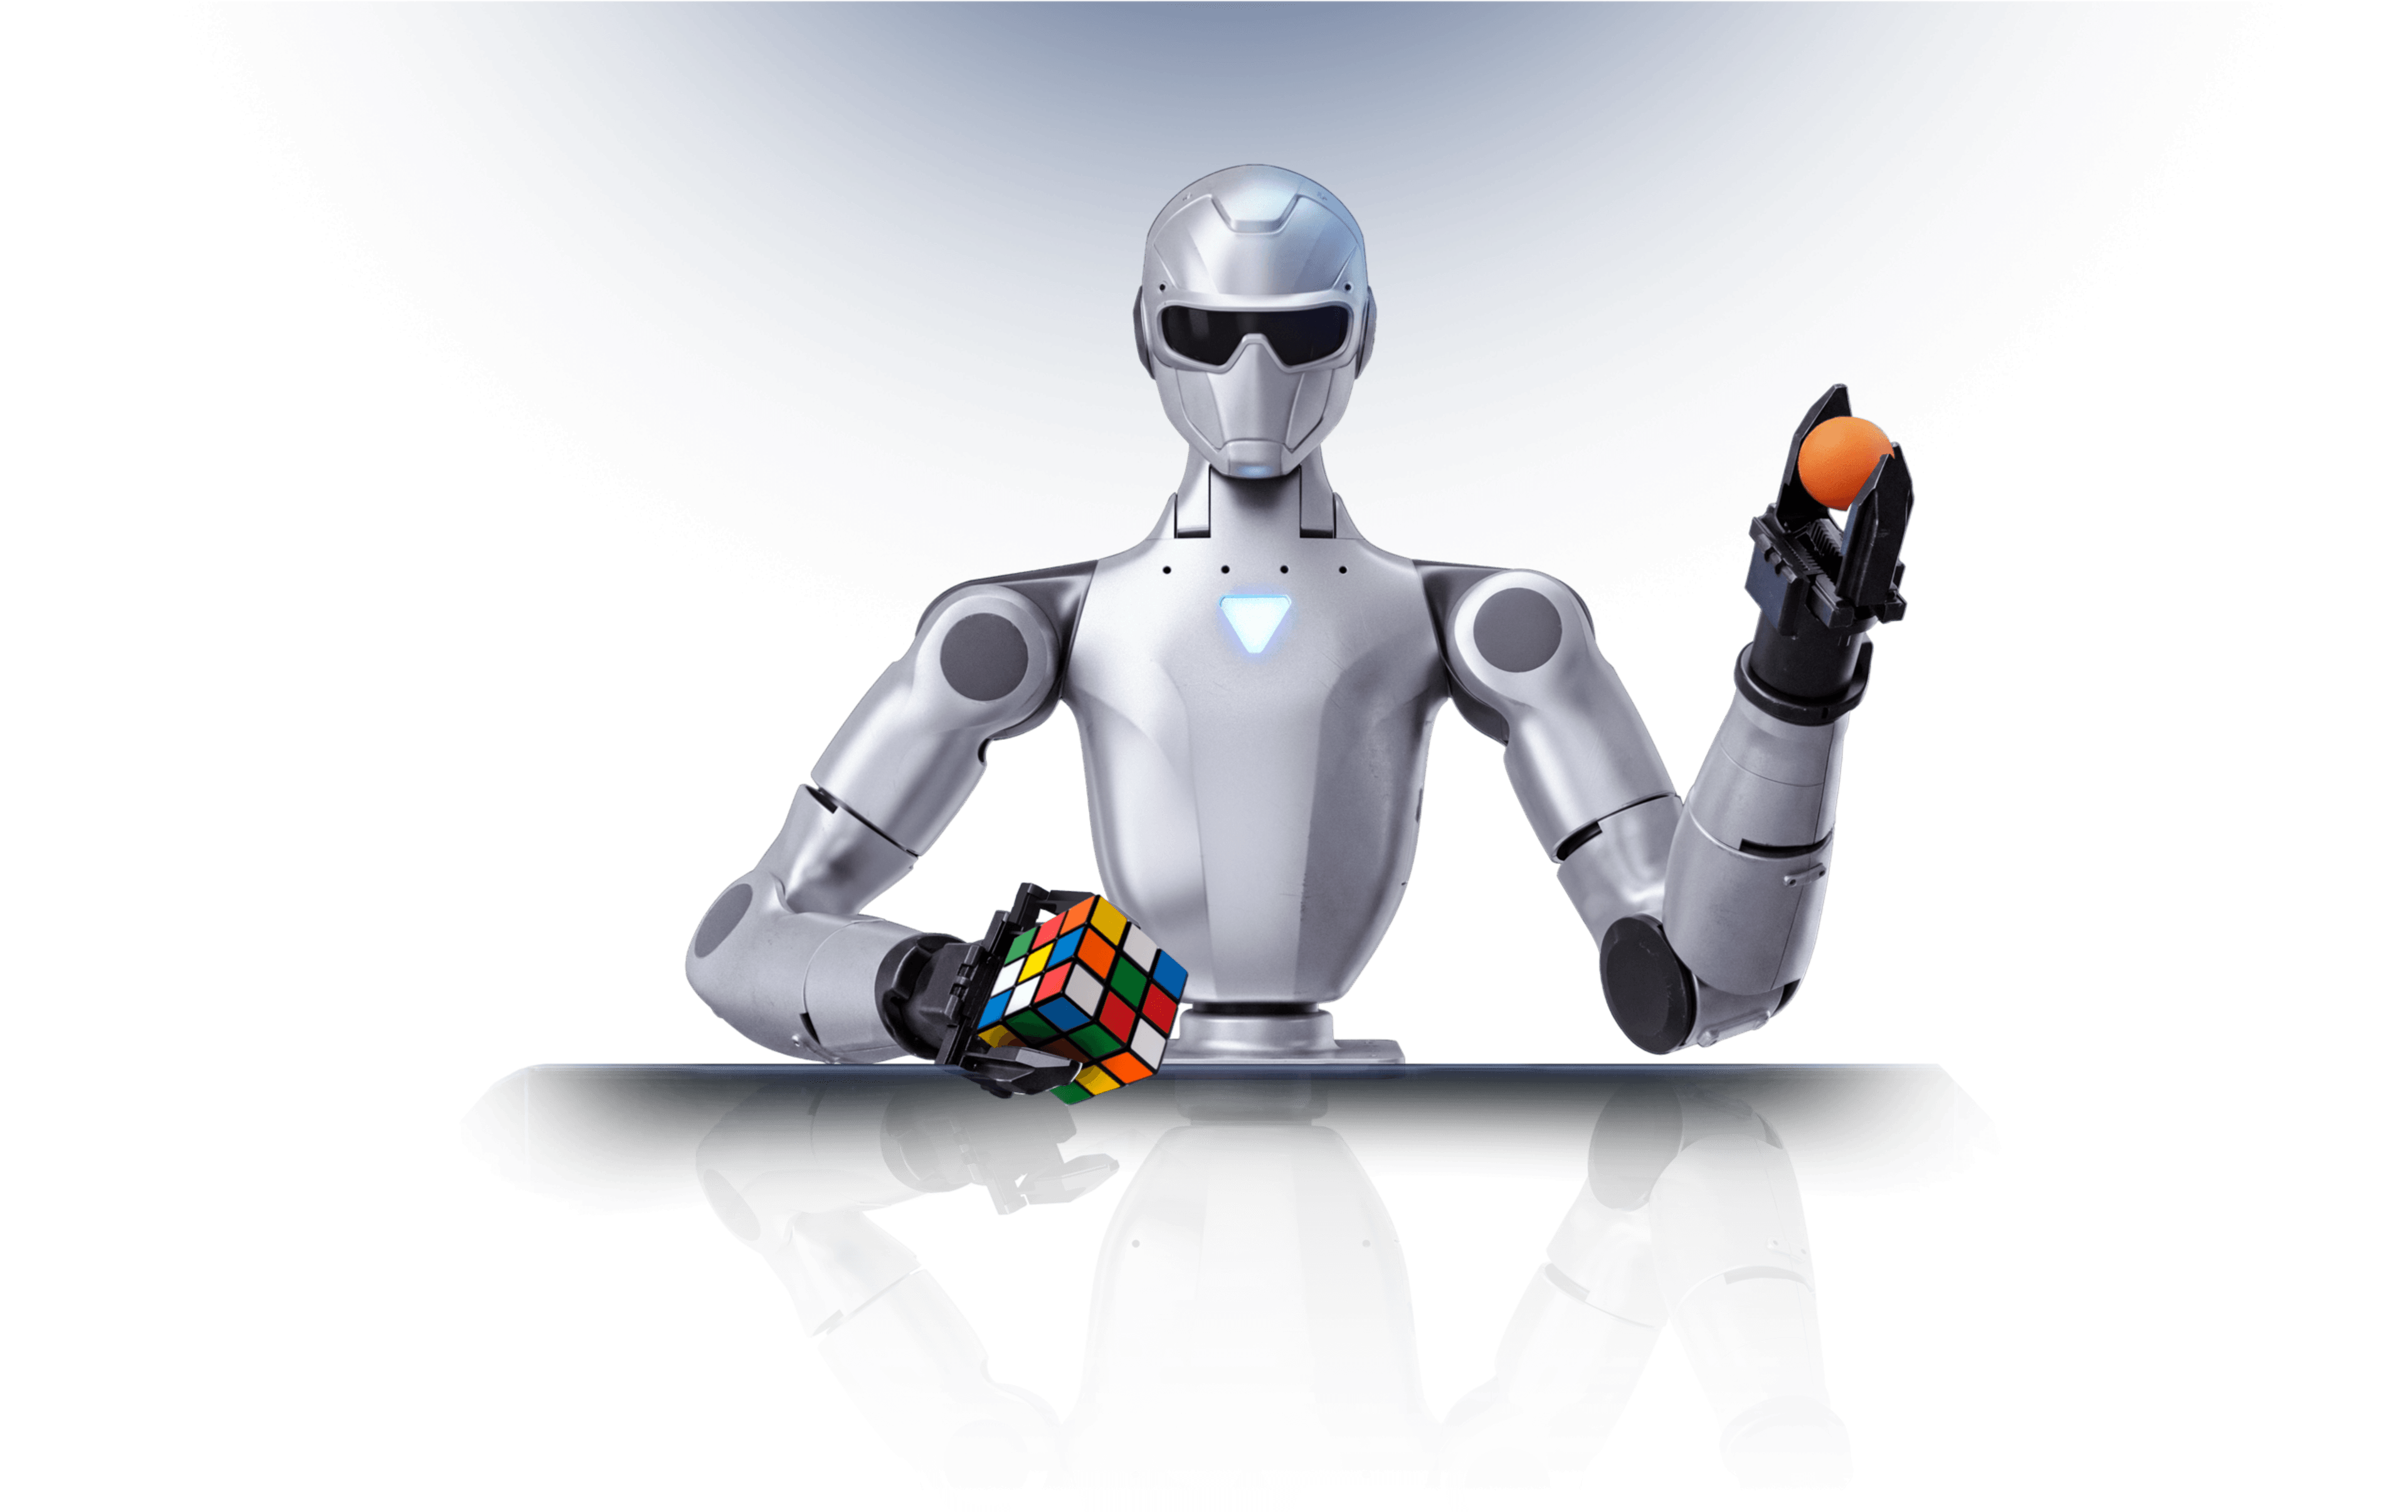
R1-A5 Smart B
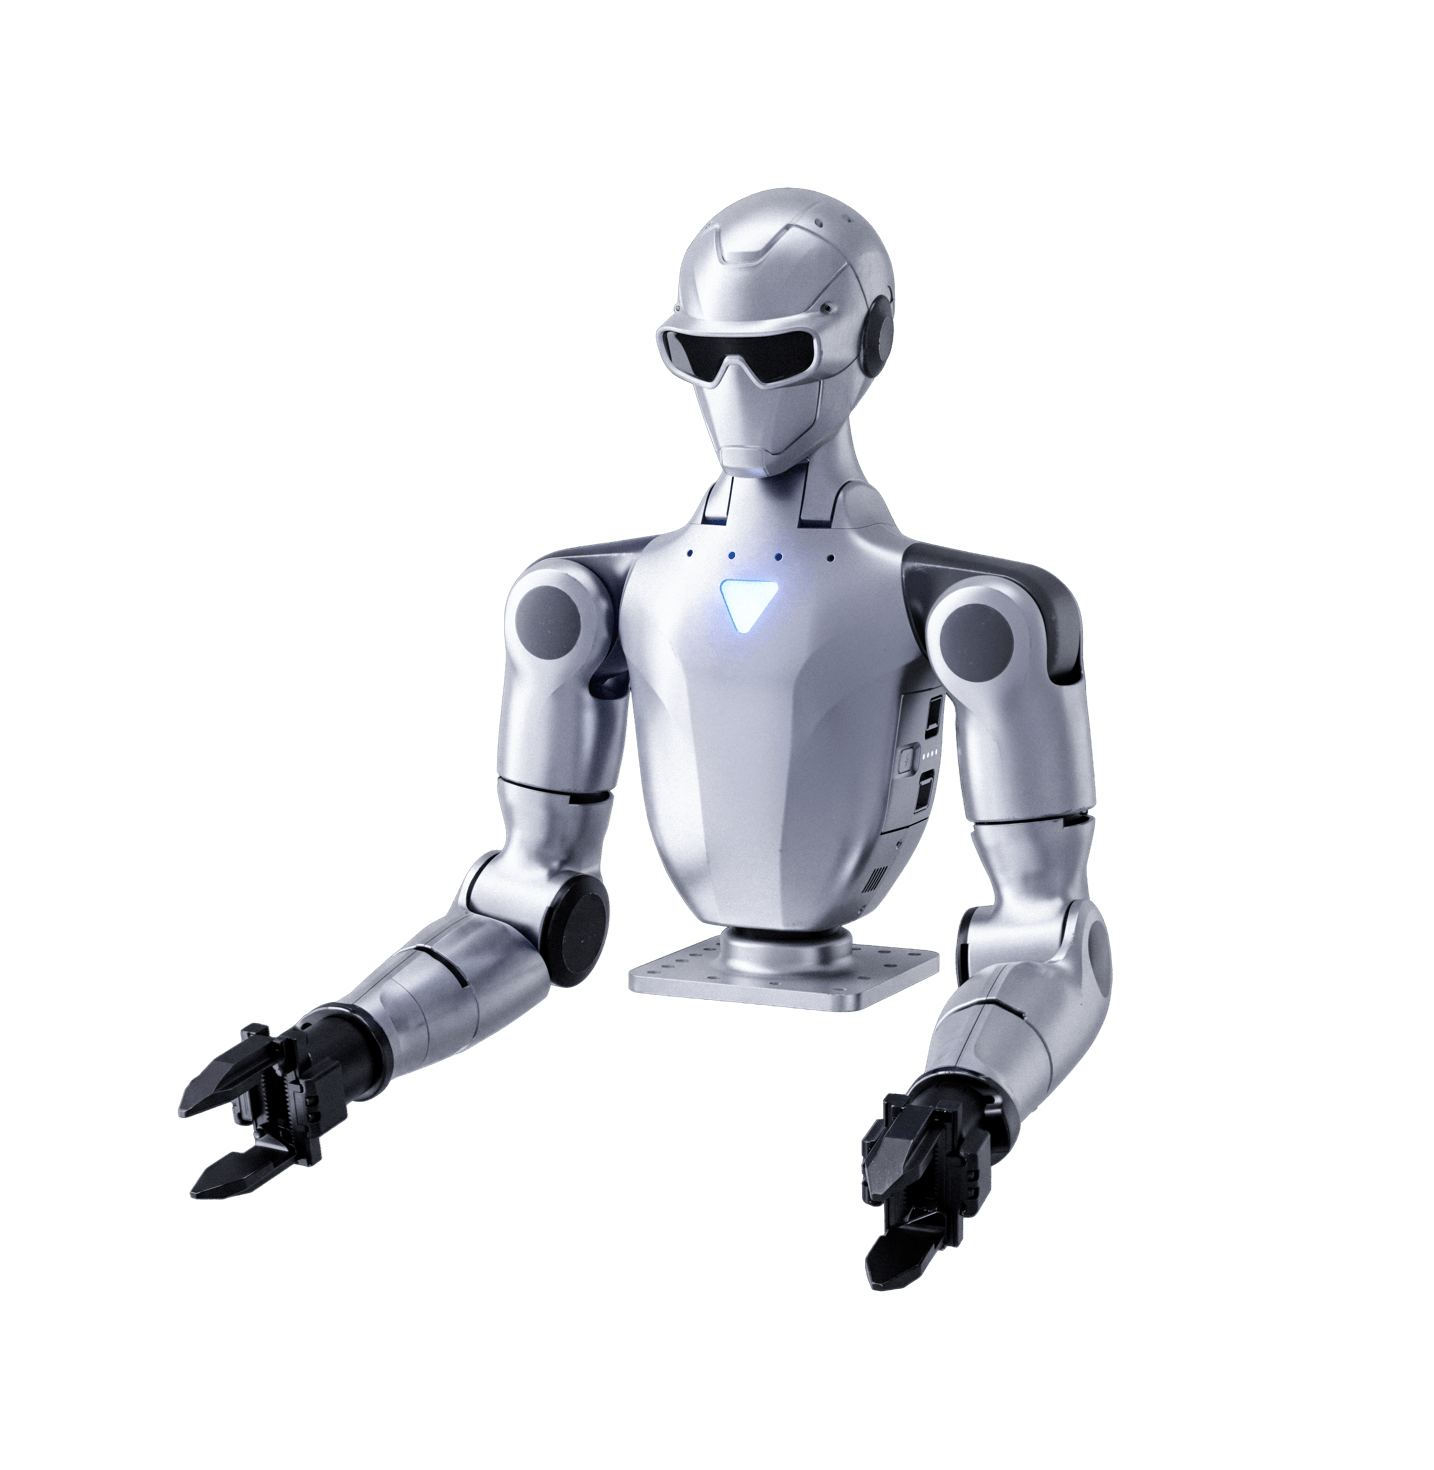
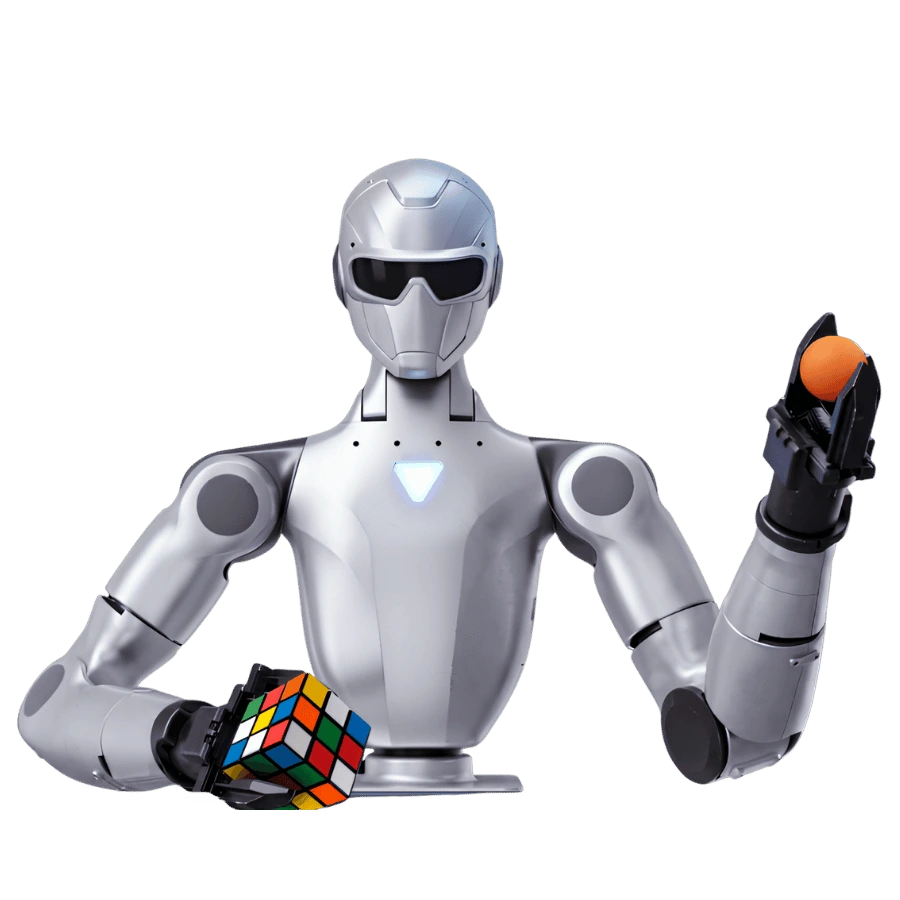
R1-A5 Smart B is a dual-arm humanoid robot with 27 degrees of freedom, equipped with Dex3-1 dexterous hand (non-tactile)s. Perception: binocular camera + wrist cameras.
Key Features
High-performance dual-arm robot
High-performance motors, reducers, encoders and various robot sensors
More diverse interaction methods
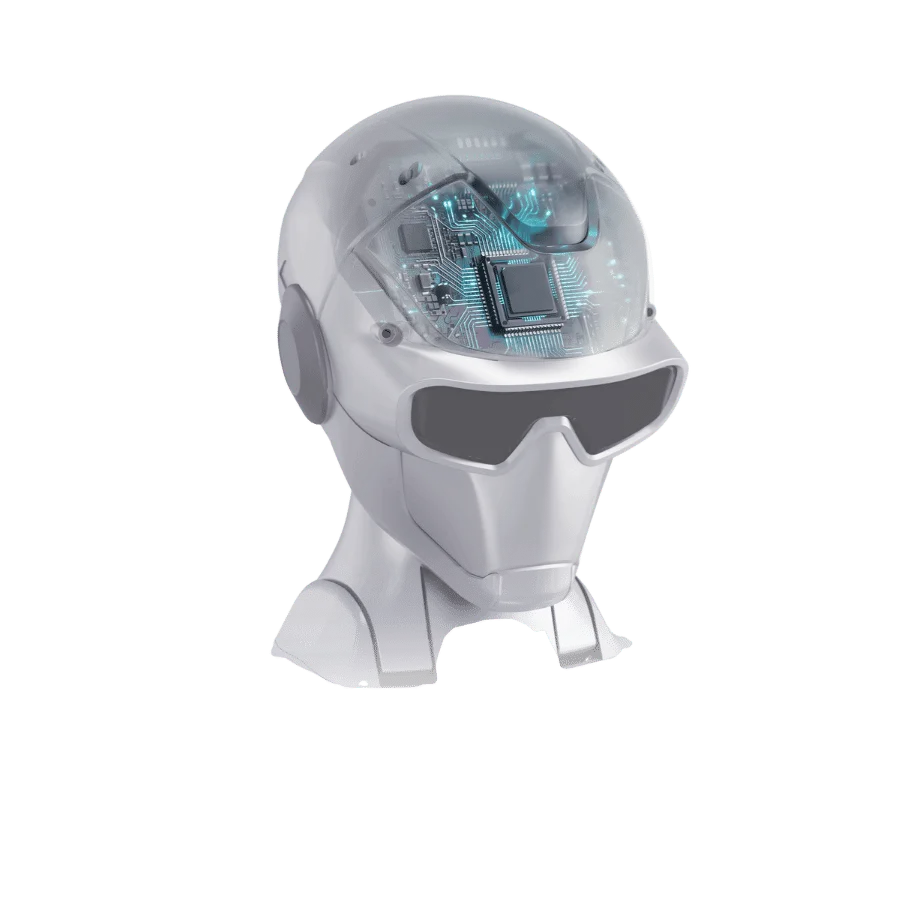
Configure visual dual-camera computing modules and voice interaction system
Full-stack open secondary development
A mature robot development framework that supports full-process secondary development at the underlying level
Higher Degrees of Freedom
High-Performance Computing Module
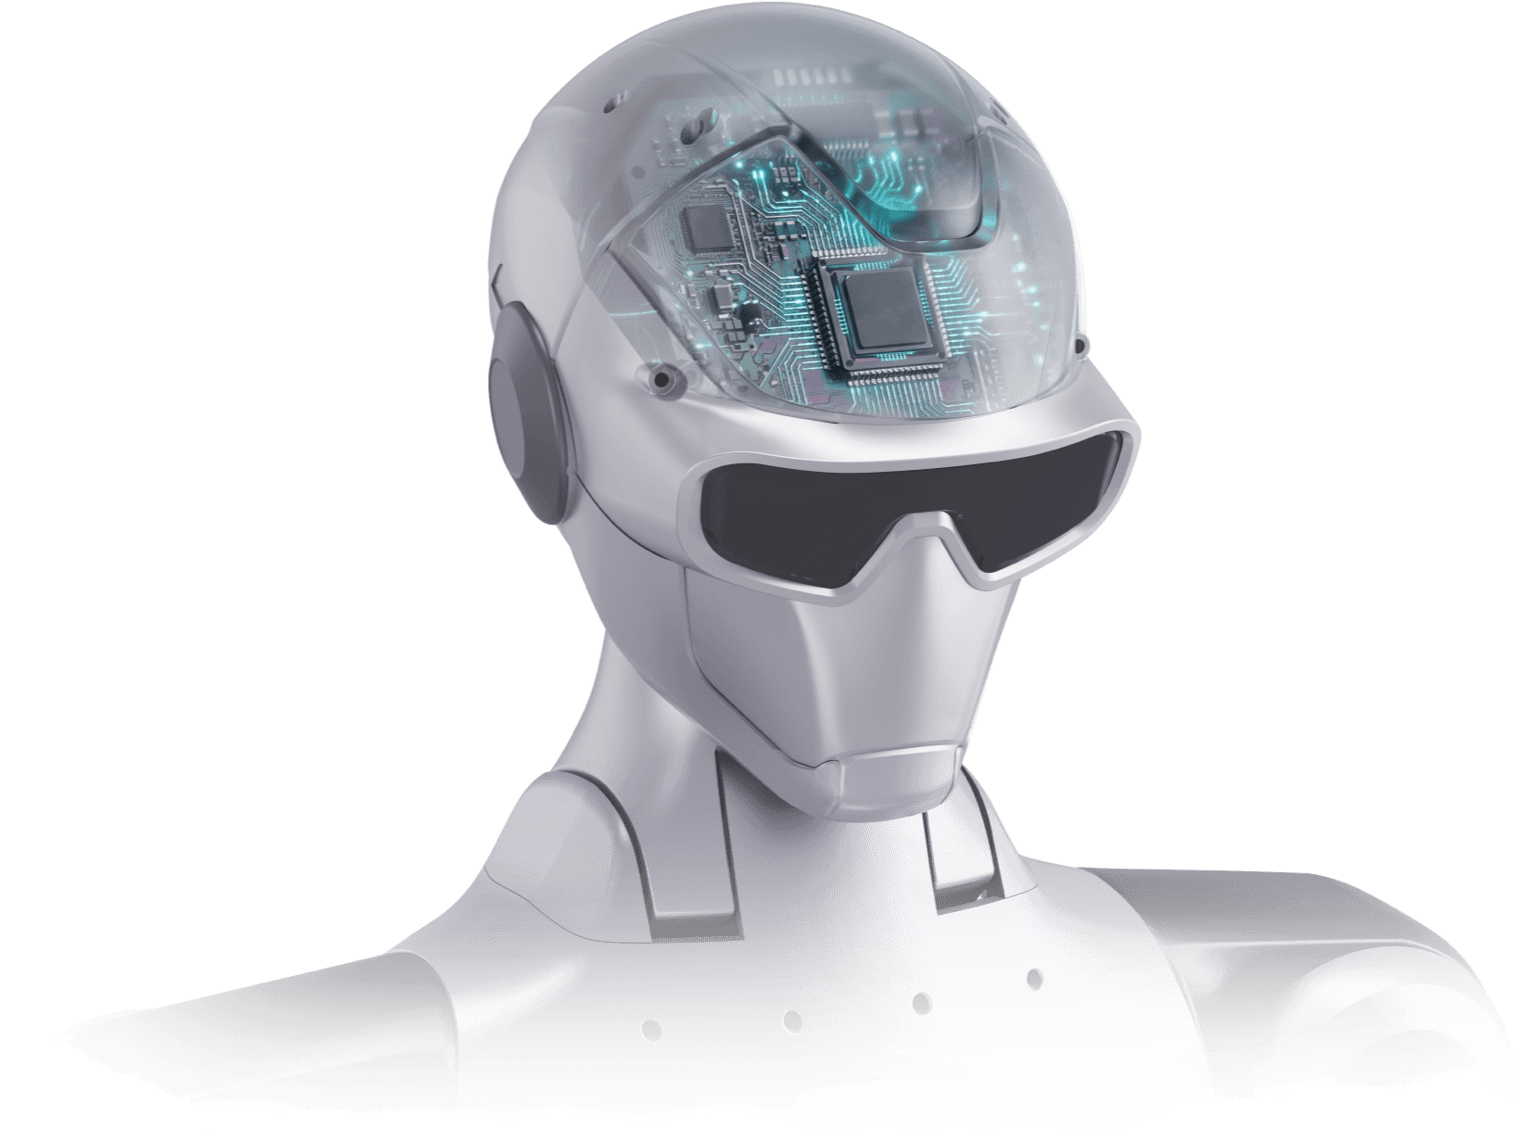
- Head processor: 8-core high-performance CPU, 10TOPS head module computing power
- Body processor: 8-core high-performance CPU
- Binocular module with RGB and depth map interfaces
- Voice collaboration: 4-microphone array + dual speakers
Open Program Interfaces and End Interfaces
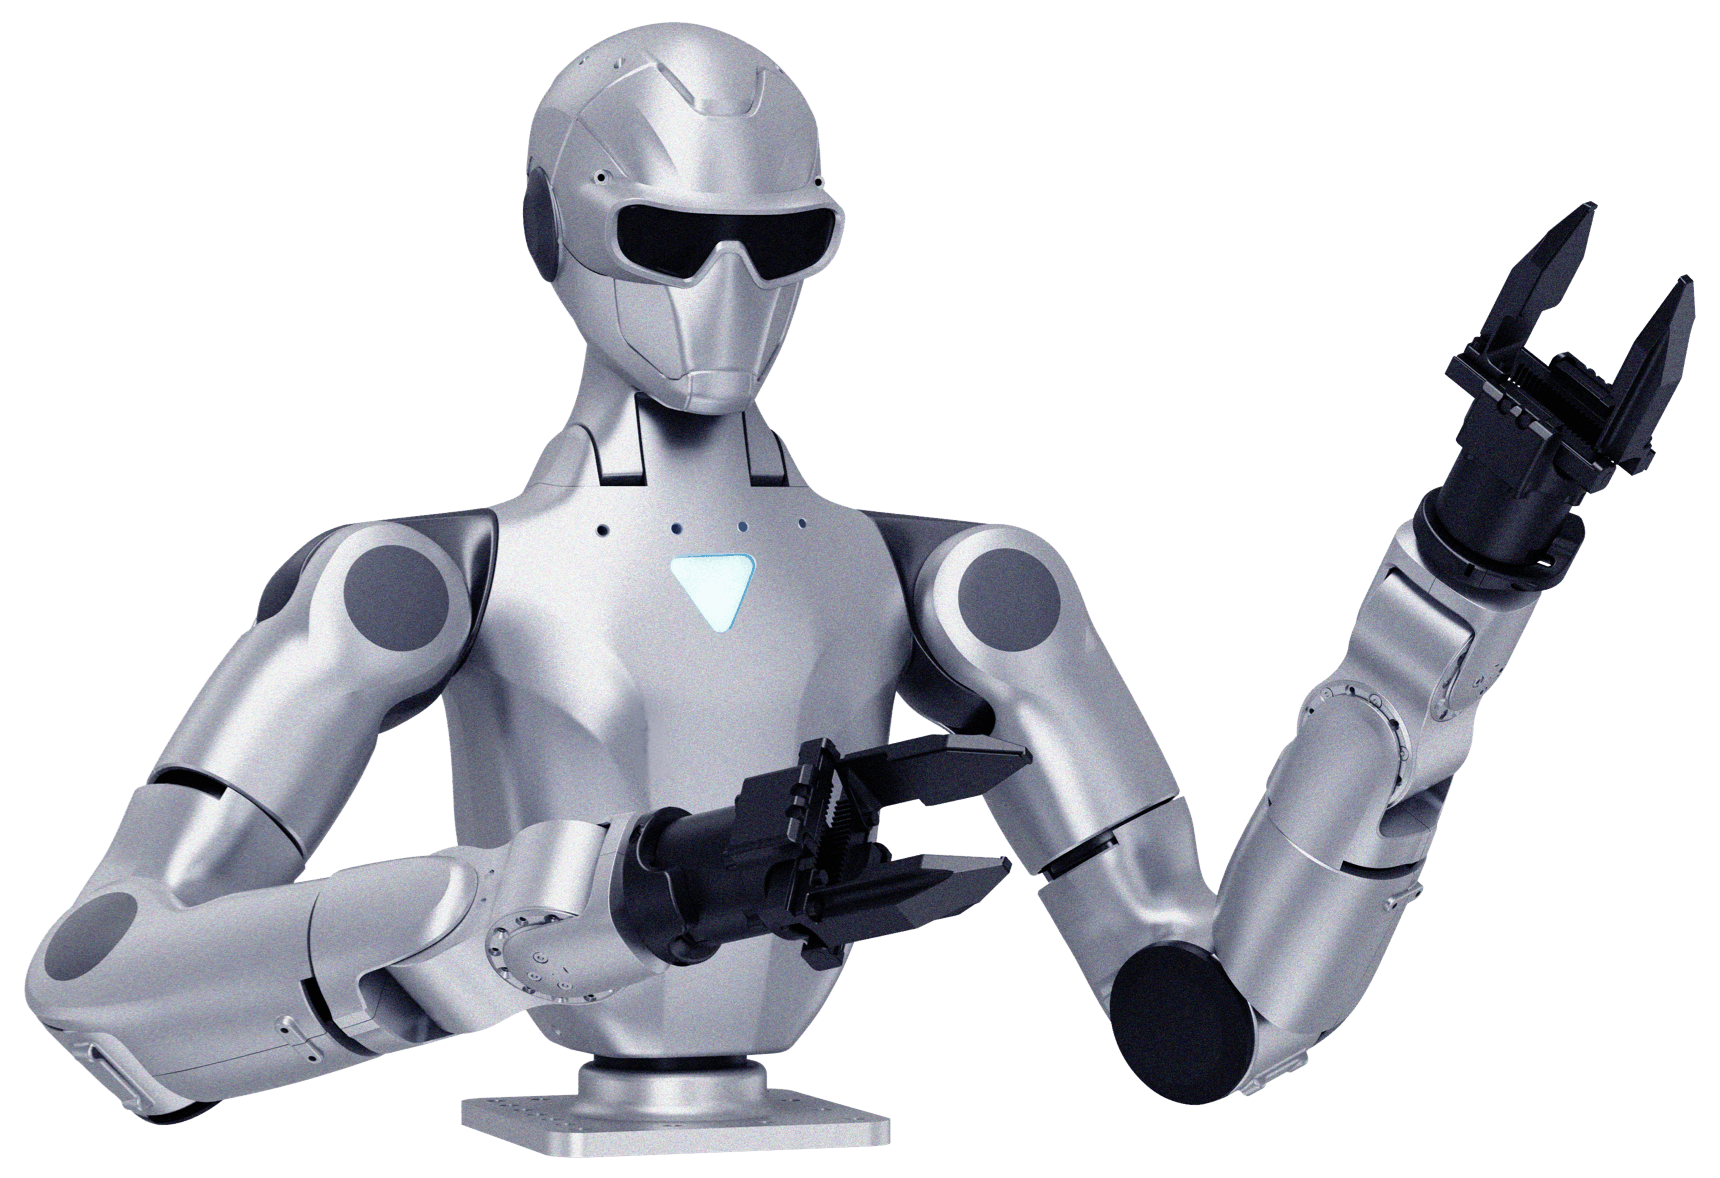
Open interfaces for the underlying system, robotic arm, audio, lighting and visual control; the end can be quickly equipped with different actuators.
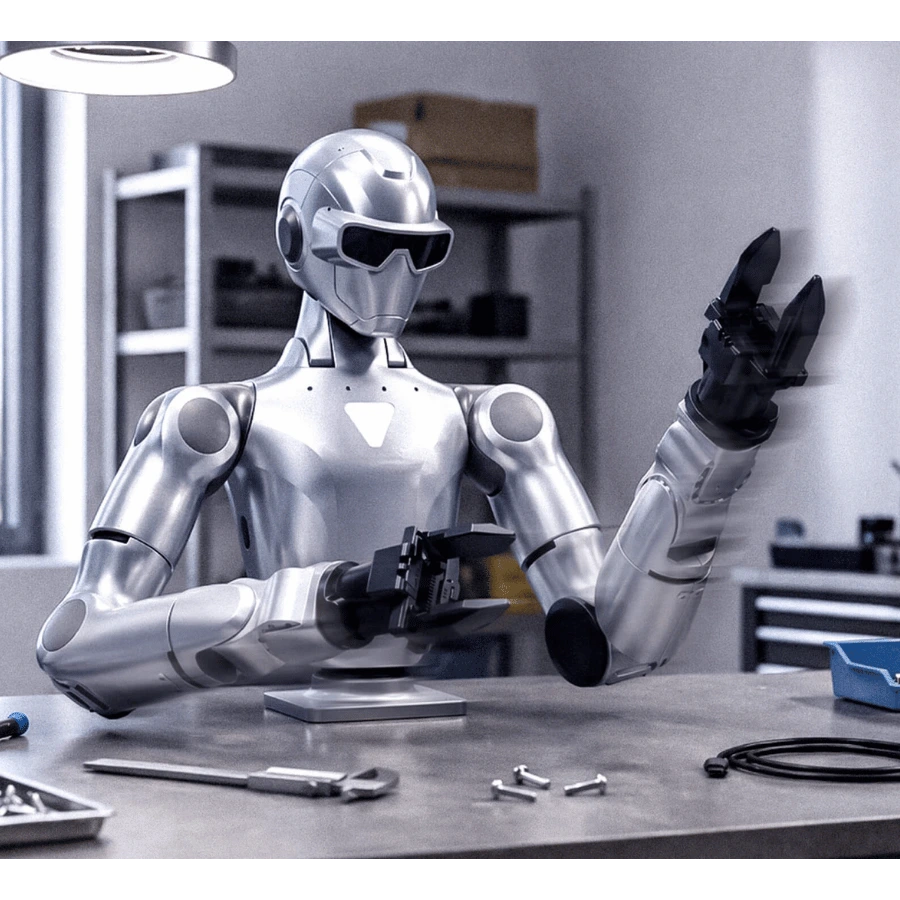
Application Scenarios
End Effector — Dex3-1 dexterous hand (non-tactile)
| End effector | 2× Dex3-1 dexterous hands |
|---|---|
| DOF per hand | 7 |
| Tactile sensing | No |
Technical Specifications — R1-A5 Smart B
| Model | R1-A5 Smart B |
|---|---|
| Dimensions | 700×357×190mm |
| Total DOF | 27 (13 (5×2 arms + 1 waist + 2 head) + 7×2 end effector) |
| Arm length (upper arm + forearm) | 420mm |
| Arm load | Approx. 2kg |
| Waist joint range | Yaw ±150° |
| Head joint range | Yaw ±115° / Pitch ±36° |
| Body processor | 8-core CPU |
|---|---|
| Head processor | 8-core CPU + 10TOPS |
| Microphones | 4-microphone array |
| Speakers | Dual speakers |
| Wireless | WiFi 6 / Bluetooth 5.2 |
| Vision | Binocular camera + wrist cameras |
| Docking station | Built-in 40TOPS docking station |
| Power | External power supply; optional R1-A upper body battery (about 1.5h) |
|---|
| Remote control | Dual-hand remote controller (standard) |
|---|---|
| OTA upgrade | Supported |
| Secondary development | Supported |
| Warranty | 12 months |
Frequently Asked Questions
What is the R1-A5 Smart B?
The R1-A5 Smart B is a dual-arm humanoid robot with Binocular camera + wrist cameras, a built-in 40tops docking station and Dex3-1 dexterous hand (non-tactile)s, for 27 DOF in total.
What are the dimensions of the R1-A5 Smart B?
It measures 700×357×190mm.
How many degrees of freedom does the R1-A5 Smart B have?
27 DOF in total: 13 (5×2 arms + 1 waist + 2 head) plus 7×2 end effector.
How is the R1-A5 Smart B powered?
It runs on an external power supply, or on the optional R1-A upper body battery for about 1.5h.
Is the R1-A5 Smart B open for development?
Yes. It supports secondary development and OTA upgrades, ships with a dual-hand remote controller, and carries a 12-month warranty.
The full sheet
Related products
-
·LND·00
-
·LND·01
-
·LND·02
-
·LND·03
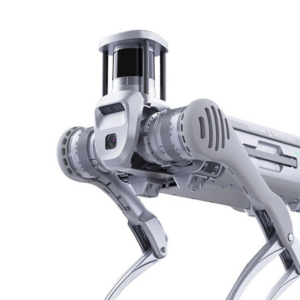
 Unitree B2- Basic Version with 3D LIDAR Robot Dog (Industry grade)₹8,516,949 (Excl. GST)Add to cart

There are no reviews yet.