
JetMax ROS 2 AI Robotic Arm
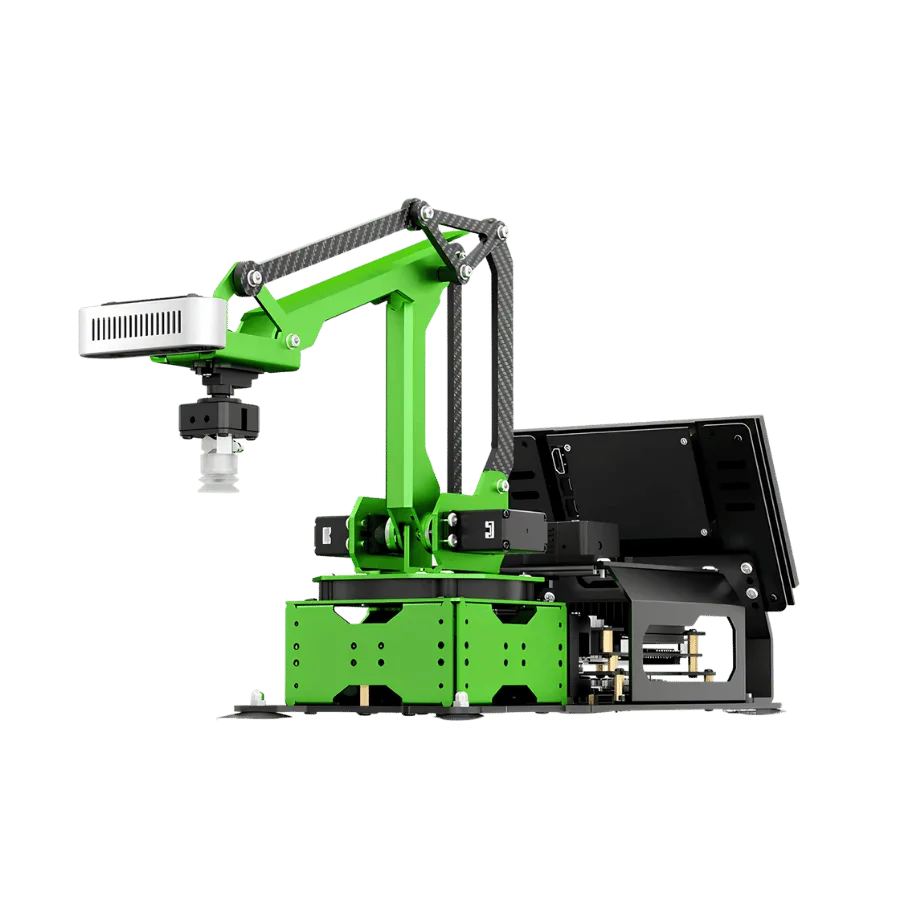
- Desktop AI arm with 4+1 DOF metal and carbon fiber body
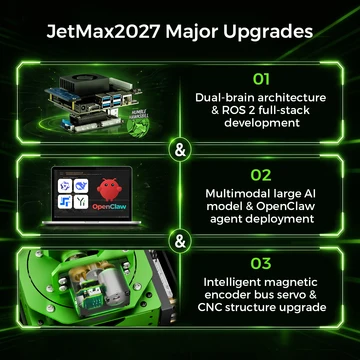
- Dual-controller design: Jetson or Raspberry Pi 5 with an STM32 controller
- 3D depth camera and WonderEcho Pro AI voice box
- Multimodal large AI models and OpenClaw agent, online or offline
- Ubuntu 22.04.5 and ROS 2 Humble, Python, C, C++ and JavaScript
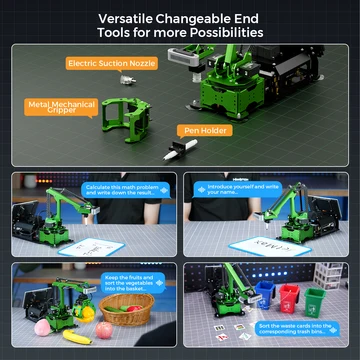
- Modular end effectors: suction nozzle, metal gripper, pen holder
- Controllers: Without Controller, Raspberry Pi 5 (2GB/4GB/8GB), Jetson Nano (4GB), Jetson Orin Nano Super (4GB/8GB), Jetson Orin NX Super (8GB/16GB), with optional Mecanum Wheel Chassis, Tank Chassis, Sliding Rail or Conveyor Belt
- Trusted dealerDirect manufacturer partnership
- Pan-India deliveryInsured shipping, all states
- Post-sale supportTraining + service included
What makes it work
JetMax ROS 2 AI Robotic Arm – LLM & OpenClaw AI Agent, 3D Vision & Voice Control – Starter Kit without controller
JetMax2027 is a desktop AI robotic arm designed for education. This listing is the Starter Kit without controller, with an electric suction nozzle and a monocular camera.
Product Description
JetMax2027 is a desktop AI robotic arm designed for education. Powered by an STM32 multi-function controller and magnetic encoder bus servos, it works with a Jetson or Raspberry Pi 5 host controller (not included in this version). By integrating advanced inverse kinematics and mainstream algorithm frameworks, it enables 3D environmental perception, dynamic target tracking, and intelligent grasping. Deployed with multimodal large AI models and the OpenClaw agent, JetMax bridges multi-dimensional perception with physical execution. Fully supporting Python programming and backed by comprehensive courses, it redefines embodied intelligence development.
Available Options
Model
Controller
Key Features & Applications

ROS2 x OpenClaw
Empowered by high-performance hardware and multi-dimensional sensors combined with multimodal large models, JetMax achieves next-level human-robot collaboration and intelligent task execution.

Deploys Large AI Models
Integrating vision, voice, and text AI models, JetMax intelligently perceives surroundings, plans actions, and executes tasks. This unlocks advanced Embodied AI applications, including emotion perception, scene understanding, target tracking, and AI-driven navigation.

Industrial-Grade Precision Structure Design
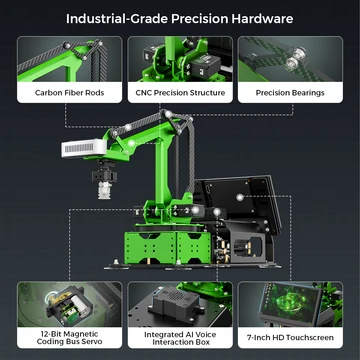
JetMax features an industrial-grade CNC linkage mechanism with carbon fiber rods, drastically reducing structural backlash. Integrated with 24 precision bearings, it eliminates transmission gaps, ensuring high rigidity and repeatability for XYZ 3D spatial movements.
Creative Applications of Multimodal Al Large Models

Object Tracking
Leveraging large visual models for scene analysis, JetMax extracts environmental info, locks target coordinates, and uses the KCF algorithm for dynamic tracking.

Intent Perception & Decision-Making
Combining environmental and object data, JetMax uses LLMs for multimodal reasoning to output actionable decisions.

Intelligent Reasoning & Calculation
Using large visual models to recognize text and formulas, JetMax completes logical reasoning and calculations, driving physical actions.
Al Large Model x OpenClaw

Cross-Platform Collaboration
Issue commands in your words anytime via apps like Telegram, turning your daily communication tool into a dedicated robot console.

Intelligent Information Aggregation
Following your commands, JetMax scans the environment in real time, extracts feature information, and generates status reports.

Proactive Response
When encountering unexpected anomalies, JetMax thinks autonomously and quickly executes remedial strategies.

Autonomous Task Decomposition
Provide a task goal, and JetMax automatically deduces and generates specific action steps to handle complex scenarios.

Task Planning & Fault Tolerance
If the sorting area changes, JetMax triggers a self-healing mechanism to replan its route and try again.

Spatial Vector Memory
The system records historical targets and scenes. For similar tasks, JetMax reuses past strategies for precise execution.
Full-Stack ROS Development Ecosystem — Key ROS2 Features


Cross-Platform Interconnected Control


HTS-30HM Magnetic Encoder Bus Servo

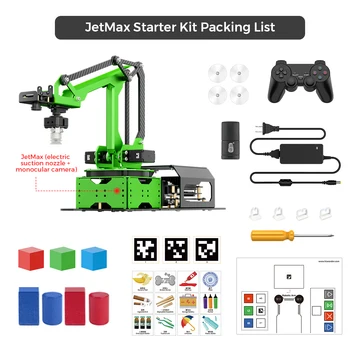
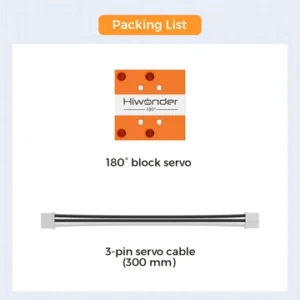
Packing List

Technical Specifications
| Brand | Hiwonder |
|---|---|
| Product name | JetMax large AI model open-source robotic arm |
| Kit | Starter Kit, without controller (host controller not included) |
| Dimensions | 490 × 165 × 252 mm |
| Product weight | Starter Kit 1.90kg |
| Body material | Metal and carbon fiber materials |
| Body DOF | 4 DOF +1 DOF |
| Sub controller | STM32 robot controller |
| End effectors | Electric suction nozzle |
| Camera | Monocular camera (0.3MP USB HD camera) |
| Power solution | 12V 5A DC adapter |
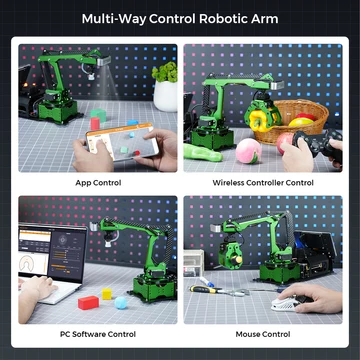
| Control methods | App control, PC software control, wireless controller control, mouse control |
| Operating system | Ubuntu 22.04.5 LTS + ROS 2 Humble |
| Software | PC host software + iOS/Android app |
| Communication method | USB / WiFi / Ethernet |
| Programming tools | Python / C / C++ / JavaScript |
| Servo model | HTS-30HM magnetic coding bus servo / LFD-01M anti-stall servo |
| Included materials | Development manual, tutorials, ROS 2 source code, system images, supporting software |
Frequently Asked Questions
Which version is this?
This is the JetMax Starter Kit without controller. The Starter Kit has an electric suction nozzle and a monocular camera, and the host controller is not included.
What is included in the Starter Kit packing list?
JetMax (electric suction nozzle + monocular camera), suction cups, color blocks (40×40mm), cuboids (30×30×60mm) + cylinders (Ø30×45mm), QR code cards (40×40mm), waste sorting cards (40×40mm), a map (600×430mm), a wireless controller, a card reader, a 12V 5A power adapter (DC5.5×2.5), an accessory pack and a user manual.
What software environment does it run?
It runs Ubuntu 22.04.5 LTS with ROS 2 Humble and supports Python, C, C++, and JavaScript programming, with PC host software and an iOS/Android app.
How does JetMax use AI?
It integrates vision, voice, and text AI models and the OpenClaw agent, supporting both online API integration and offline local deployment.
Which servos does it use?
It uses the HTS-30HM magnetic coding bus servo and the LFD-01M anti-stall servo, with a 12-bit magnetic encoder in the HTS-30HM.
The full sheet
Related products
-
·XBM·00
-
·XBM·01
-
·XBM·02
-
·XBM·03

There are no reviews yet.