
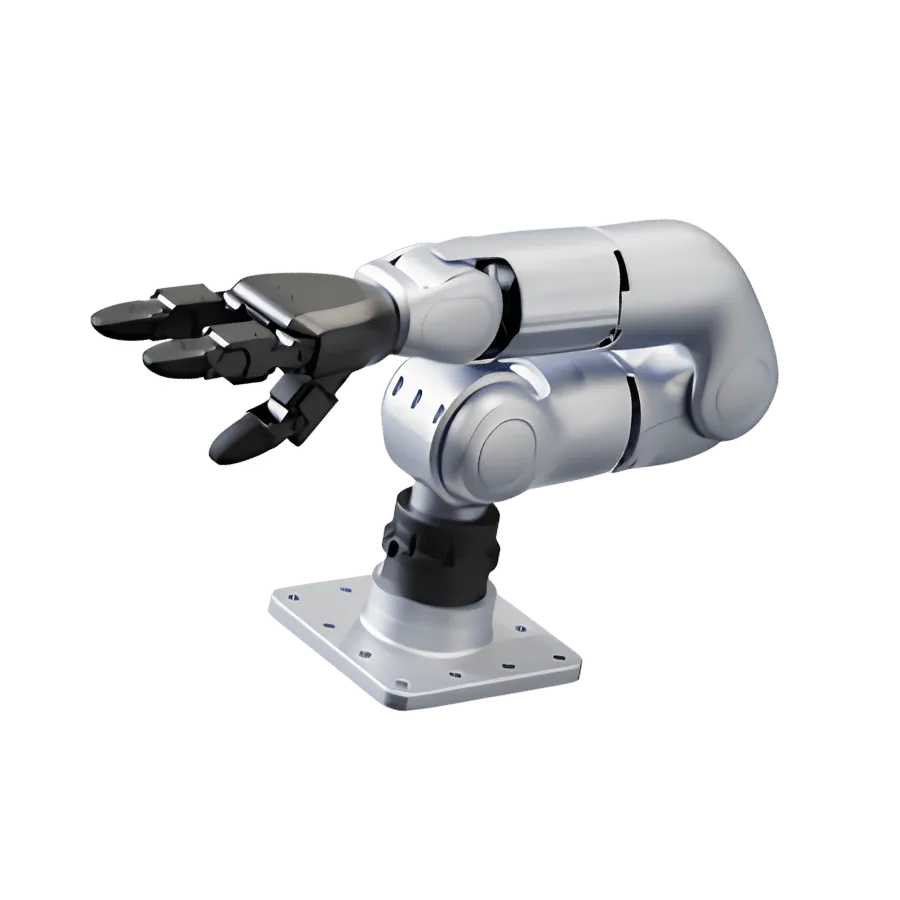
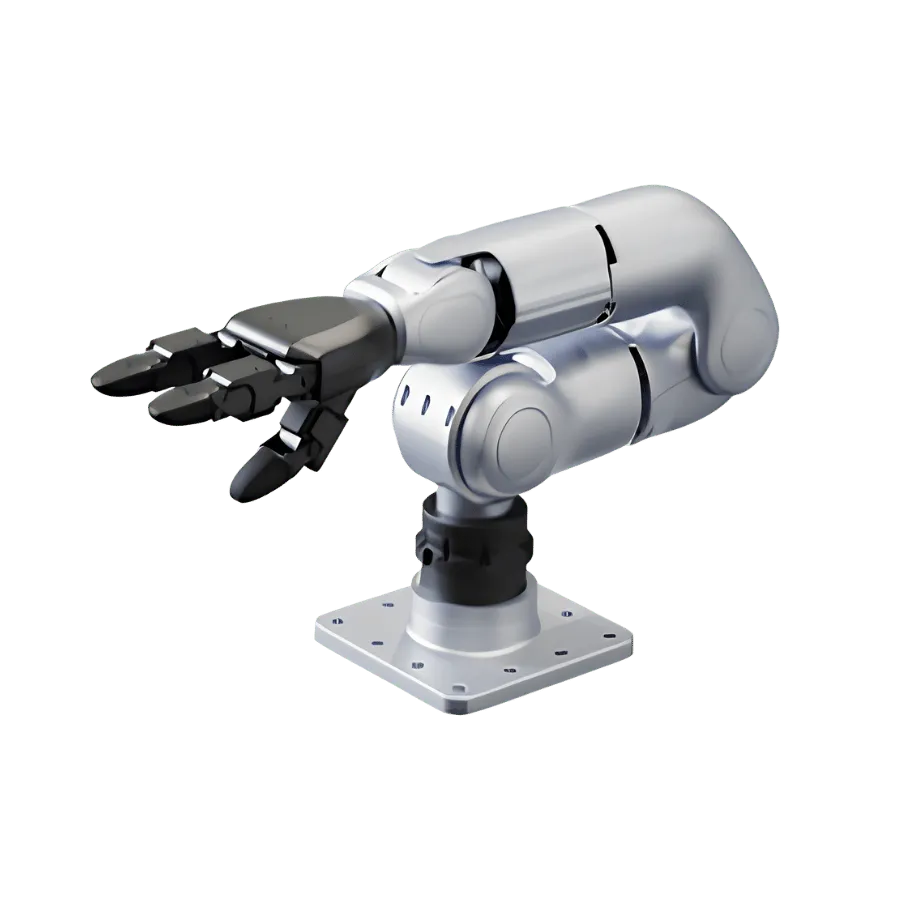
R1-7a Professional C Bionic 7-Axis Dexterous Robotic Arm with Dex3-1 Three-Finger Hand
- 7-DOF bionic robotic arm: 470mm arm length, 650mm working radius (with dexterous hand), approx. 5.5kg metal and engineering-plastic body
- Rated payload 2kg, max payload approx. 4kg, max joint torque approx. 60 N·m, 180° elbow fold
- Ultra-wide joint ranges: J1 ±156°, J2 0°~180°, J3 -20°~200°, J4 0°~180°, J5 ±130°, J6 ±30°, J7 ±90°
- Low-inertia high-speed inner-rotor PMSM joint motors, crossed-roller bearings and dual encoders on every joint
- Dex3-1 force-controlled three-finger hand (non-tactile): 7 DOF, approx. 650g, 12~58V, USB, with RGB camera
- Total DOF 14 (arm 7 + dexterous hand 7); RGB camera included
- 24V~60V external power, peak 700W / typical ≤50W; XT30 power port and CAN/485; works upright, side or inverted from -20℃ to 50℃
- Includes power & data module accessory kit (power adapter not included); 12-month warranty; left-arm and right-arm versions, right arm default for single-arm use
- Trusted dealerDirect manufacturer partnership
- Pan-India deliveryInsured shipping, all states
- Post-sale supportTraining + service included
What makes it work
R1-7a Professional C Bionic 7-Axis Dexterous Robotic Arm
The R1-7a is a 7-DOF bionic dexterous robotic arm for research, education and service-robot development: 470mm arm length, 650mm working radius (with dexterous hand), approx. 5.5kg, with dual-encoder joints and a 180° elbow fold. This version is equipped with a Dex3-1 force-controlled three-finger dexterous hand (non-tactile) with RGB camera.

High-Precision 7-Axis Bionic Joints
7-axis coordinated motion. Flexible and precise movement. Enables dexterous reach-around operations even in confined spaces. Multi-angle fine-tuning of the end-effector, balancing motion flexibility and repeat positioning accuracy for smoother path-planning under complex working conditions.
High-Rigidity Integrated Body
Adopting a composite body of metal and high-strength engineering plastic, it balances overall lightweight design and structural rigidity. Featuring outstanding deformation-resistance, the main body maintains stability during long-hour operations, adapts to continuous operation across diverse scenarios, and provides a solid mechanical foundation for high-precision motion output.
Compact & Lightweight
Desktop-class lightweight design. Weighs only about 5.5 kg, plug-and-play.
Open-Source Programming & Expansion Interfaces
Robotic arm control programs and interfaces will be open-sourced iteratively. Various end-effectors can be rapidly swapped at the arm tip.
Ideal Assistant for Laboratory & Education
Optimized for a wide range of scientific research and educational scenarios.
Dual-Arm Collaboration · High-Efficiency Operation
Two robotic arms work in synergy to realize material sorting and assembly tasks.
Intelligent Interaction · Robot Body Maintenance
Multiple flexible degrees of freedom to perform complex self-maintenance operations.
Service Simulation · Intelligent Hands-On Operation
Replicate real-life household tasks to explore service robot application scenarios.
What Is Included
R1-7a 7-axis robotic arm
Dex3-1 force-controlled three-finger dexterous hand (non-tactile, with RGB camera) ×1
Power & data module accessory kit ×1 (power must be supplied by the user via the XT30 port; power adapter not included)
12-month warranty on the entire unit
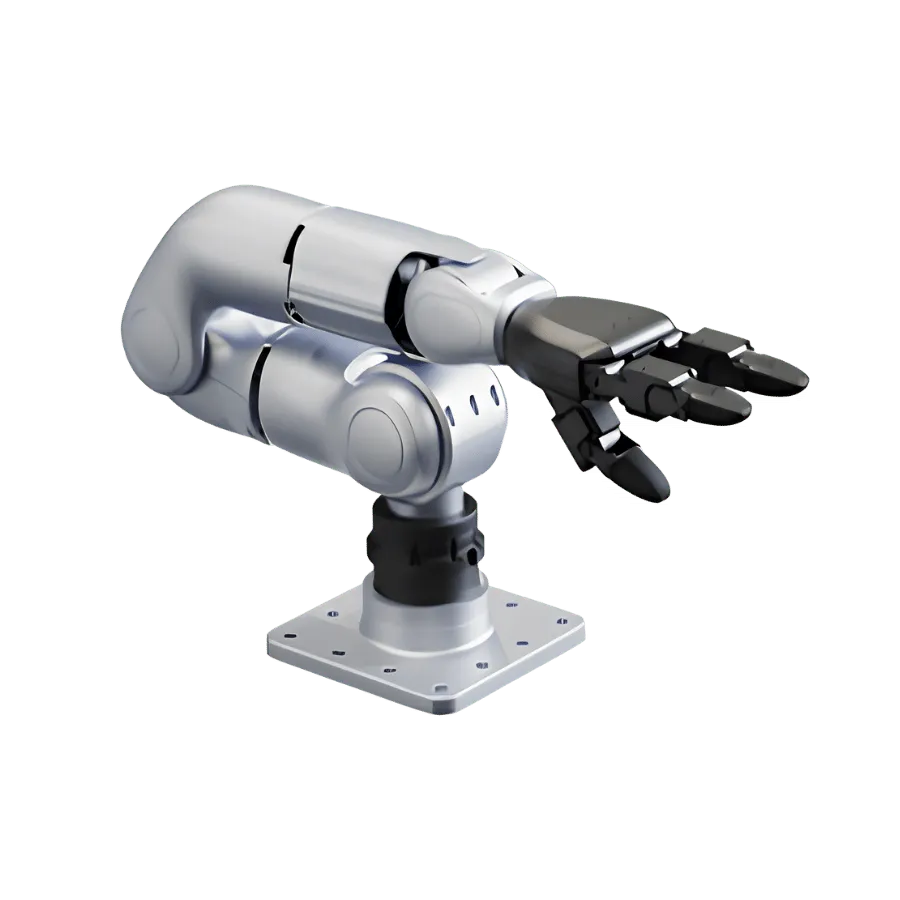
RGB camera included. The R1-7a comes in left-arm and right-arm versions (mirror images); for single-arm applications, default to the right-arm SKU.
Technical Specifications — R1-7a Professional C
| Model | R1-7a Robotic Arm |
|---|---|
| Total DOF (joint motors) | 7 |
| Extended Arm Length | 470mm |
| Working Radius | 650mm (with dexterous hand) |
| Weight | Approx. 5.5kg |
| Material | Metal body + engineering plastic |
| Rated Payload | 2kg |
| Max Payload | Approx. 4kg |
| Max Joint Torque | Approx. 60 N·m |
| Elbow | 180° elbow fold |
| Max Joint Speed | >180°/s |
| Joint Output Bearing | Industrial crossed-roller bearing (high precision, high load capacity) |
| Joint Motor | Low-inertia high-speed inner-rotor PMSM; bionic joint motor with high torque and high burst output |
| Joint Motor Models | J1/6010, J2/6010, J3/6014, J4/6014, J5/6014, J6/5010, J7/5010 |
| Joint Feedback | Dual encoders |
| Force Feedback & Collision Detection | Yes |
| Control Interface | Position / force control |
| Control | SDK / host computer |
| User OS | Ubuntu |
| Power Supply Voltage | 24V ~ 60V (external power supply) |
| Power Consumption | Peak 700W; typical ≤50W |
| Communication | CAN / 485 |
| External Interfaces | XT30 power port ×1; CAN/485 ×1 (CAN port requires adapter board) |
| Operating Temperature | -20℃ ~ 50℃ |
| Mounting | Upright, side, inverted |
| J1 | -156° ~ 156° |
|---|---|
| J2 | 0° ~ 180° |
| J3 | -20° ~ 200° |
| J4 | 0° ~ 180° |
| J5 | -130° ~ 130° |
| J6 | -30° ~ 30° |
| J7 | -90° ~ 90° |
| Weight | Approx. 650g |
|---|---|
| Dimensions | 175mm × 88mm × 77mm |
| DOF per Hand | 7 (thumb 3, index finger 2, middle finger 2) |
| Operating Voltage | 12~58V |
| Quiescent Current | 58V @ 0.2A |
| Communication Interface | USB |
| Total DOF (arm + end effector) | 14 (arm 7 + dexterous hand 7) |
| Camera | RGB camera included |
| Accessory Kit | Power & data module accessory kit ×1 |
|---|---|
| Power Adapter | Not included (supply power via the XT30 port) |
| Warranty | 12 months on the entire unit |
| Arm Versions | Left-arm and right-arm (mirror images); right arm is default for single-arm use |
Frequently Asked Questions
What is the R1-7a Professional C?
The R1-7a is a 7-DOF bionic dexterous robotic arm for research, education and service-robot development: 470mm arm length, 650mm working radius (with dexterous hand), approx. 5.5kg, with dual-encoder joints and a 180° elbow fold. This version is equipped with a Dex3-1 force-controlled three-finger dexterous hand (non-tactile) with RGB camera.
What are the payload and reach of the R1-7a Professional C?
Rated payload is 2kg and max payload is approx. 4kg. Extended arm length is 470mm and working radius is 650mm with a dexterous hand. The arm weighs approx. 5.5kg.
What end effector and camera does the R1-7a Professional C include?
It is equipped with a Dex3-1 force-controlled three-finger dexterous hand (non-tactile) with RGB camera. Total DOF is 14 (arm 7 + dexterous hand 7). RGB camera included.
What are the power and interface requirements?
Power supply is 24V ~ 60V from an external supply through the XT30 port (peak 700W, typical ≤50W). Communication is CAN/485, with control via SDK / host computer. The power adapter is not included; the user supplies power via the XT30 port.
Is the R1-7a Professional C available for left and right arms, and what is the warranty?
The R1-7a comes in left-arm and right-arm versions (mirror images). For single-arm applications the right-arm SKU is the default; choose per actual needs when a left/right distinction is required. The entire unit carries a 12-month warranty.
The full sheet
Related products
-
·LND·00
-
·LND·01
 Unitree Go2 Pro - Robot Dog (Without Controller)Original price was: ₹423,728.₹398,305Current price is: ₹398,305. (Excl. GST)Add to cart
-
·LND·02
-
·LND·03

There are no reviews yet.