
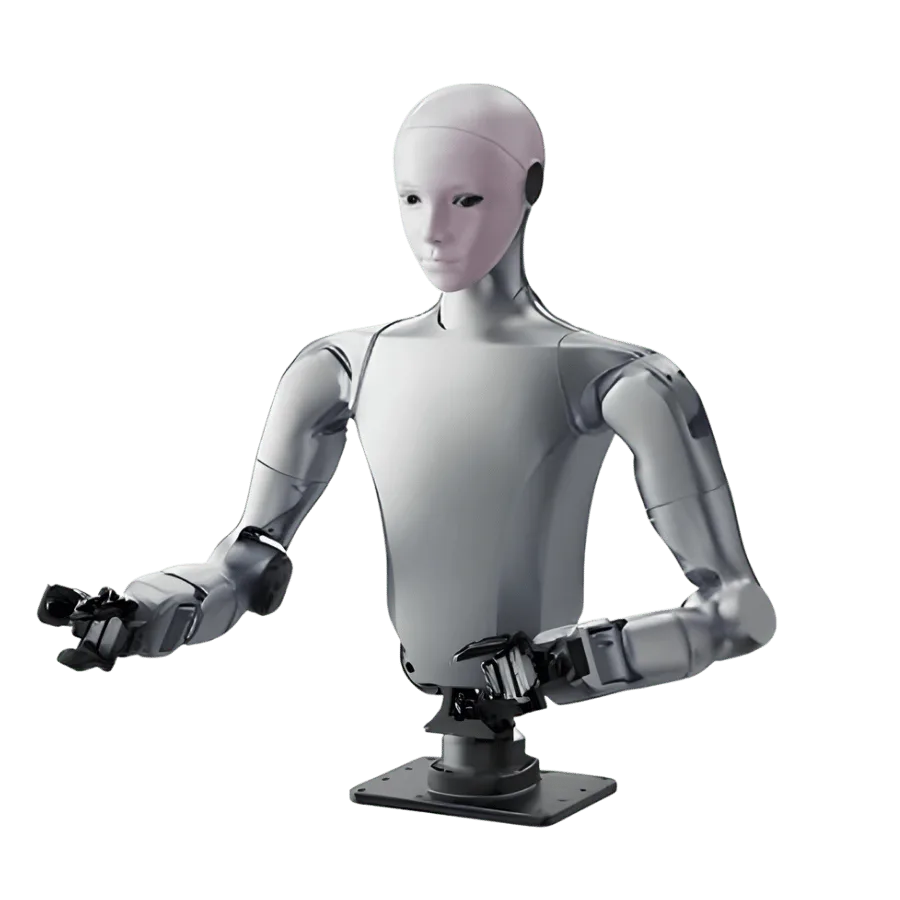
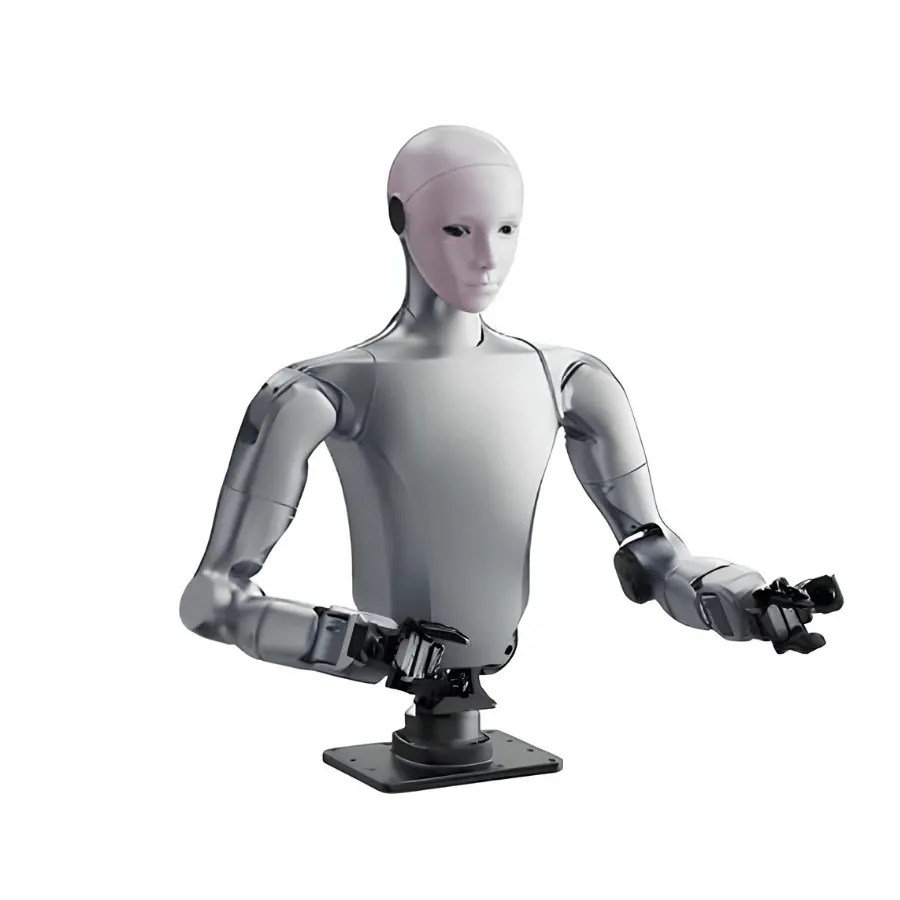
Unitree H2-A Standard A
- Fixed-base dual-arm humanoid for industrial, commercial, research and embodied AI work
- Variant: Standard A with Dex1-1 Plus two-finger grippers ×2 and wrist cameras
- 19 DOF excluding end-effector, 21 DOF with grippers
- Single arm: ~15 kg peak and ~7 kg rated load, 600 mm reach
- Gripper: 5~120 N adjustable force, 0.1 mm resolution, 90 mm stroke
- Intel Core i5 and i7 onboard, with optional Jetson Thor and Orin NX slots
- About 8 hours on battery or 7×24 h on direct power, with OTA updates and a 12-month warranty
- Trusted dealerDirect manufacturer partnership
- Pan-India deliveryInsured shipping, all states
- Post-sale supportTraining + service included
What makes it work
H2-A Standard A Dual-Arm Humanoid Robot
Redefining Industrial Mobile Manipulation
From Research Labs to Production Lines — Accelerating the Large-Scale Deployment of Humanoid Robotics
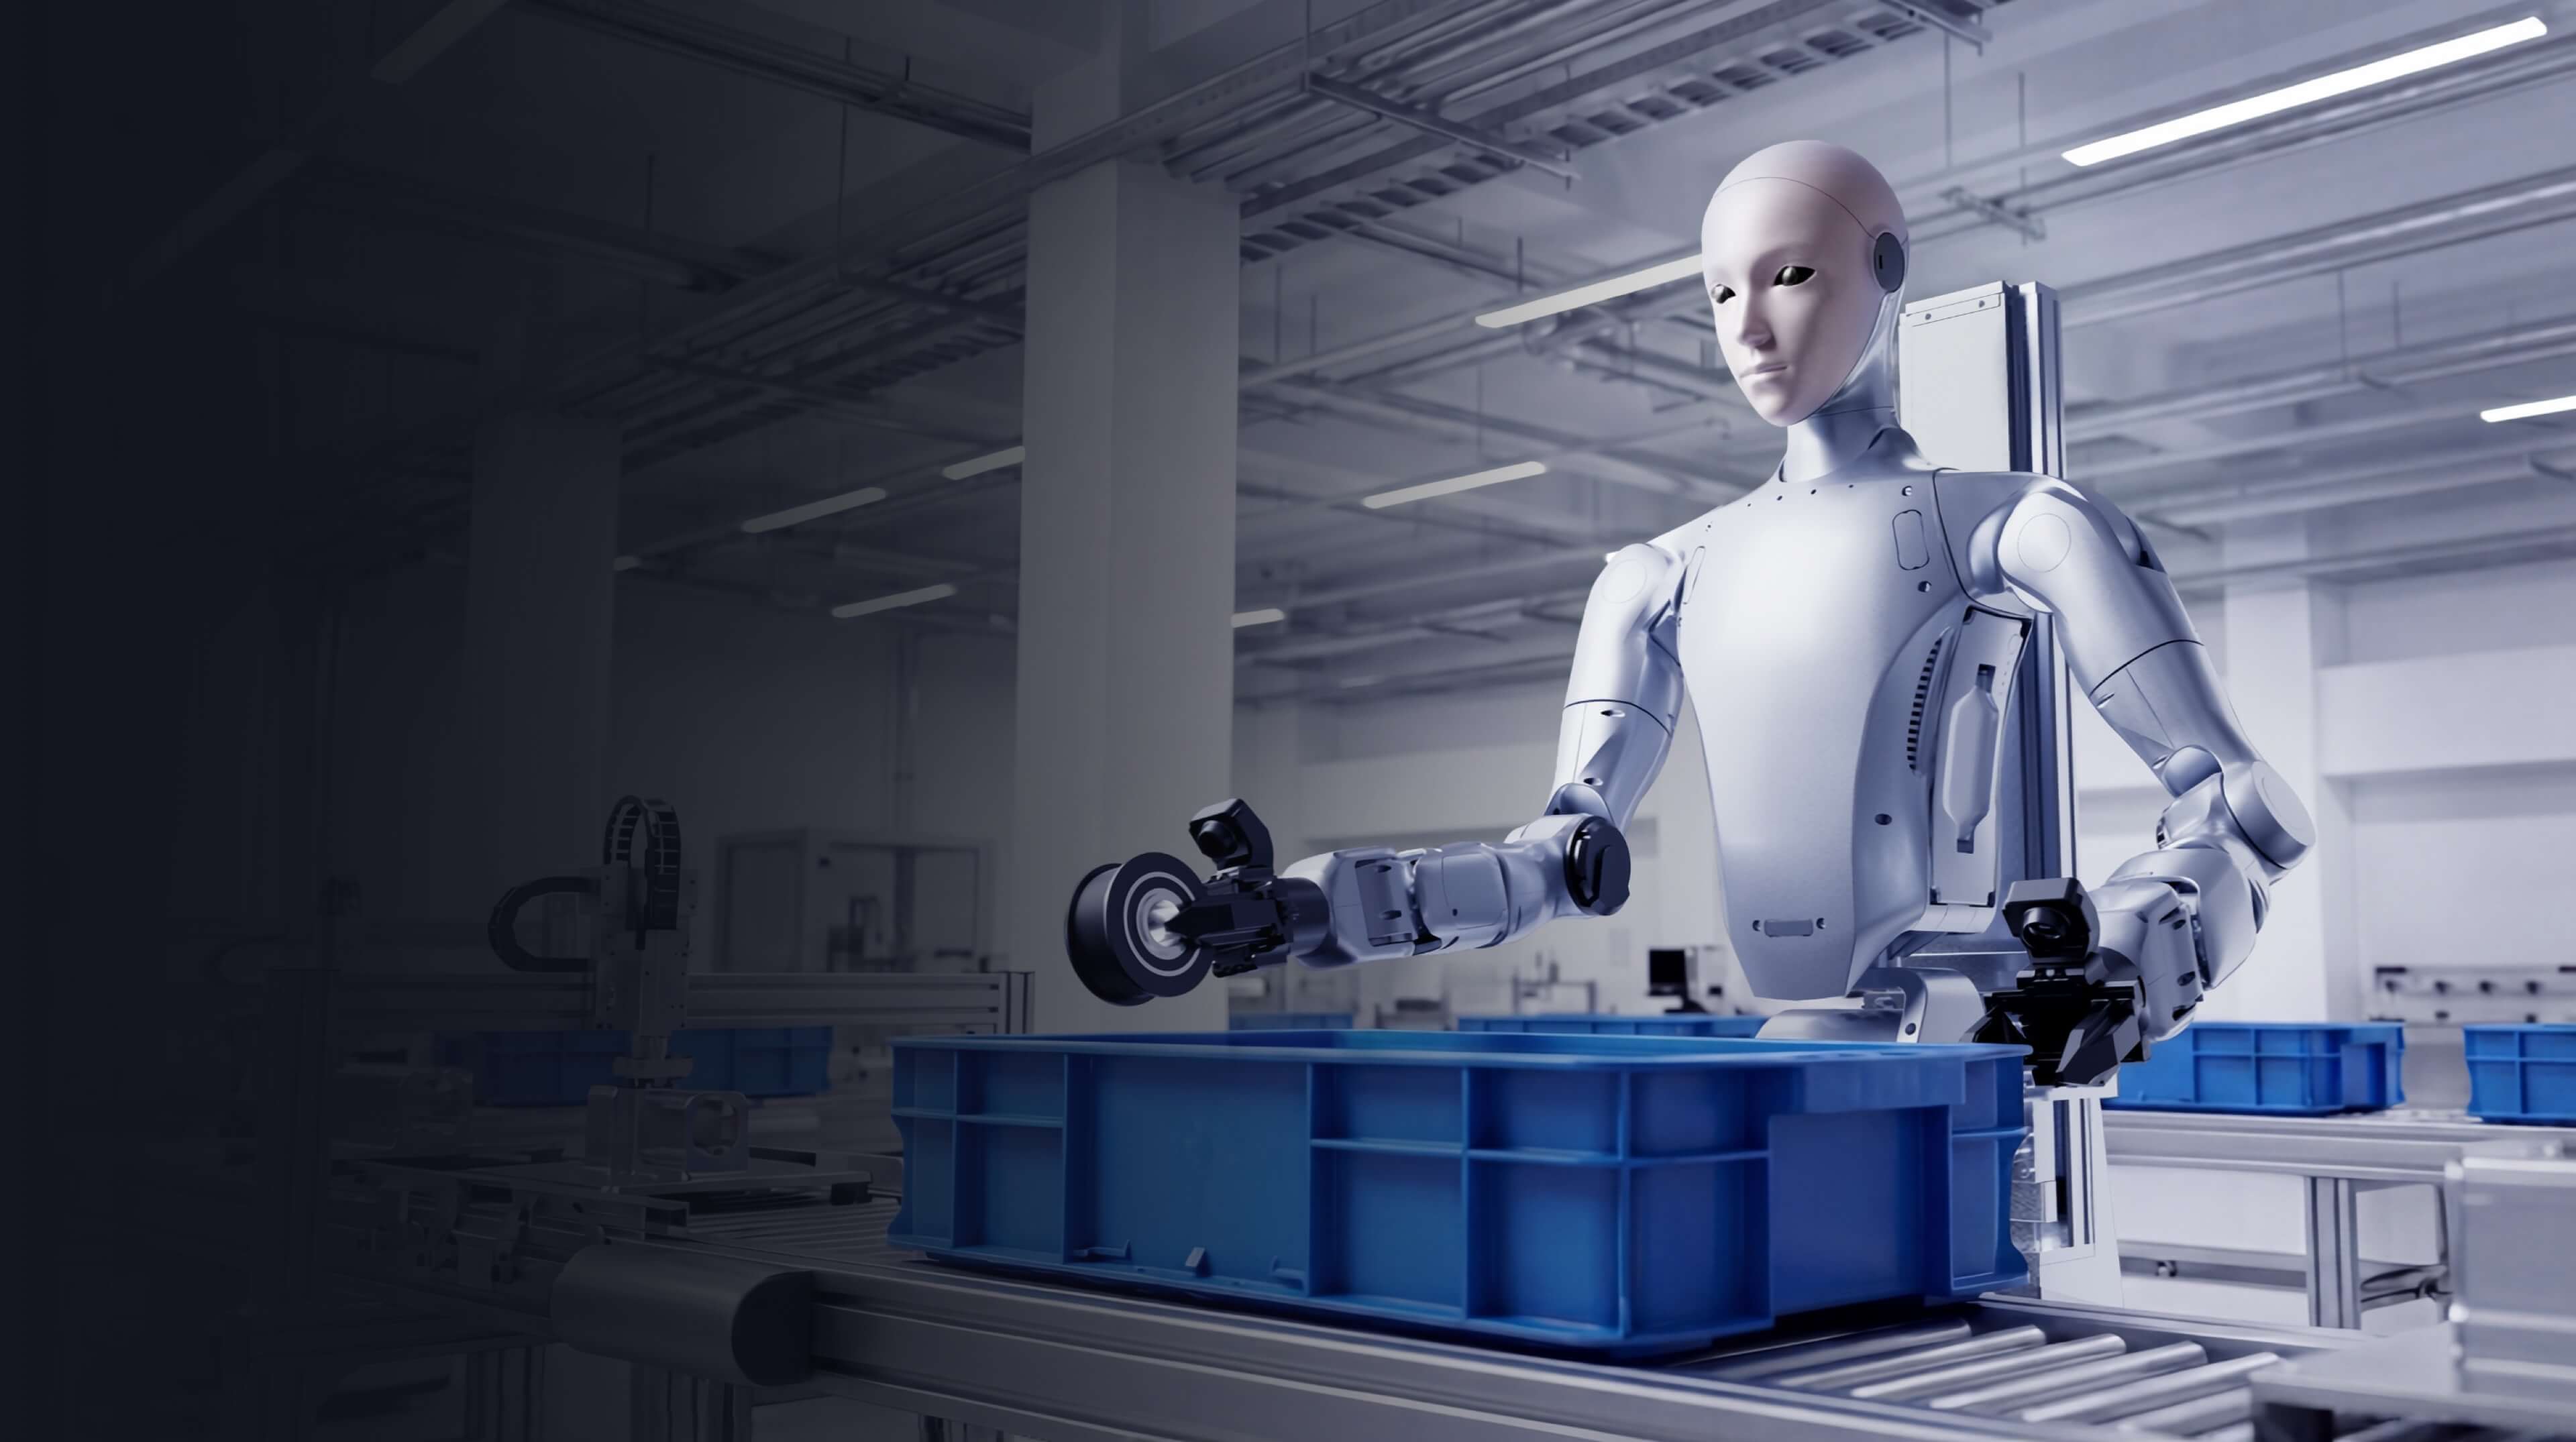
Fixed BaseDex1-1 gripper21 DOF Total
H2-A Standard — Fixed Base
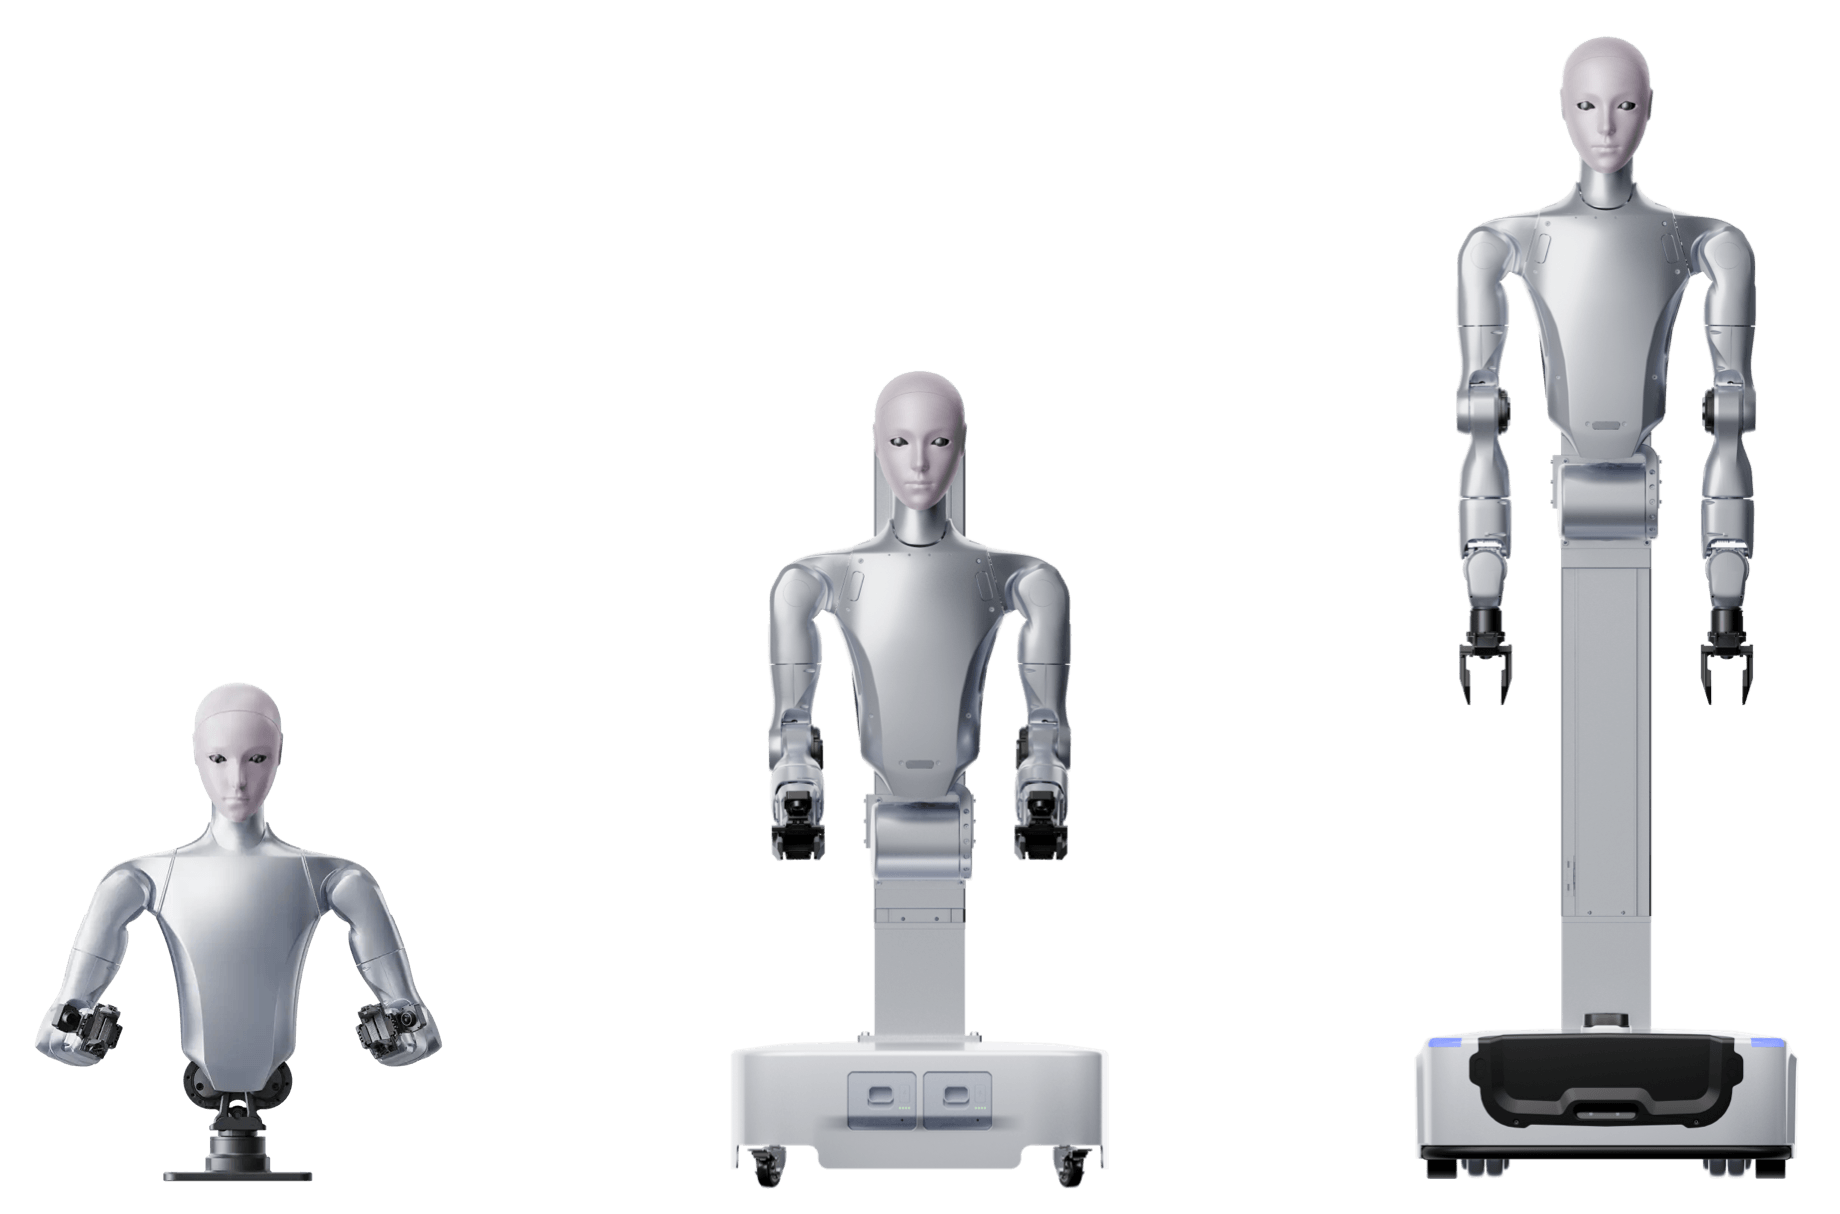
The H2-A Standard is the fixed-base model of the dual-arm humanoid robot series, designed for industrial operations, commercial services, research and development, and embodied intelligence training.
Configurable as a precision workstation for diverse production environments.
High-Performance Embodied AI Platform
Fully In-House Technology Stack
From self-developed actuators and force-controlled joints to motion control algorithms, the robot features an in-house technology stack with tightly integrated hardware and software. Supports secondary development and system customization for rapid deployment across industrial, commercial and research applications.
Multi-DOF Agile Motion
Featuring multiple highly integrated force-controlled joints, including a 3-DOF waist (pitch, yaw, roll), the robot maintains outstanding stability and flexibility in confined and complex environments.
Multimodal Perception
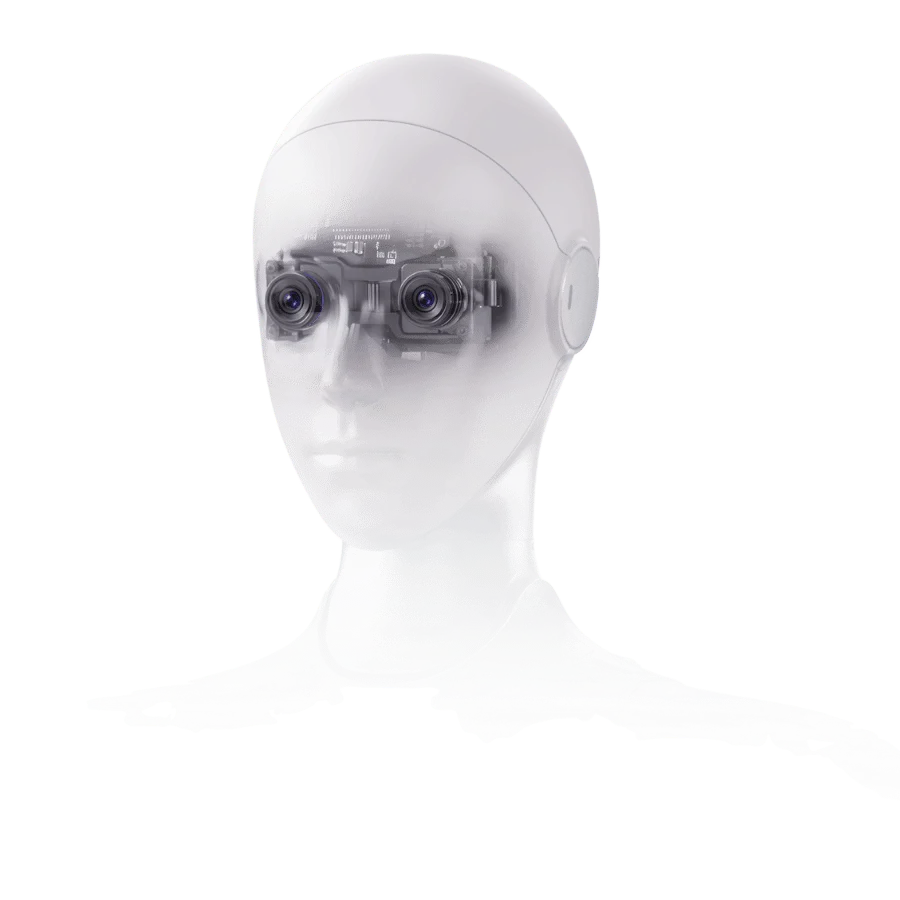
Integrates vision, force feedback and voice interaction to build a multimodal perception system, enabling intelligent environmental awareness and natural human–robot interaction.
Biomimetic Design & Full-Body Mobility
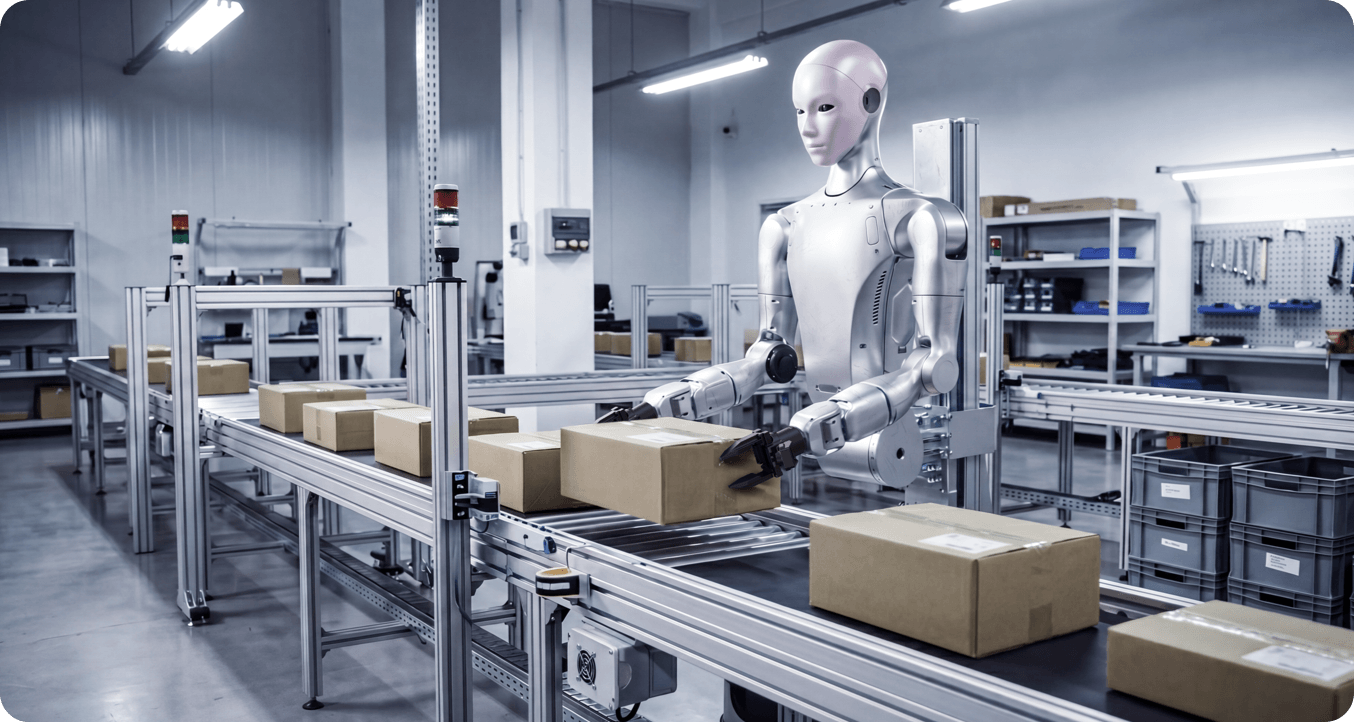
Mechanical Performance & Flexible Deployment
Supports a rated payload of up to 7 kg per arm, enabling efficient handling and assembly of heavy industrial components.
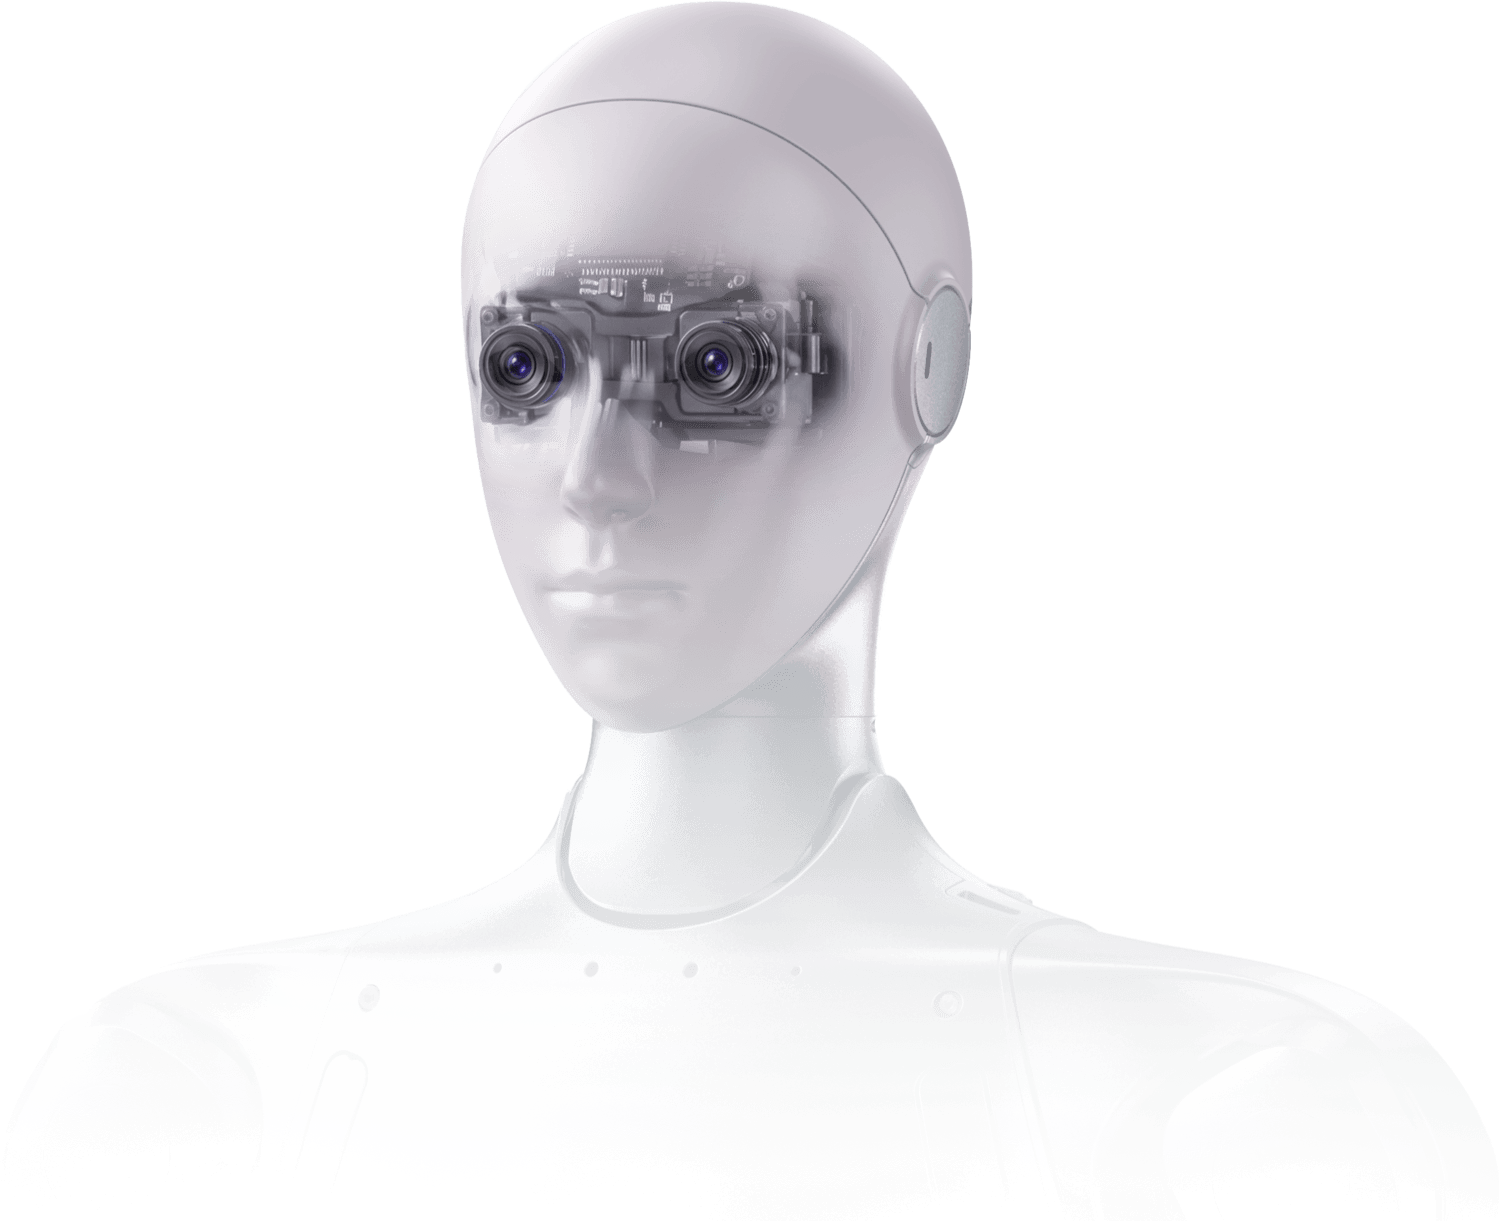
Multimodal Perception & Natural Interaction
Integrating binocular vision with natural language interaction, the robot enables intuitive and natural human–robot collaboration.
Multi-Type End Effectors & Flexible Adaptation
Supports multiple end-effectors including grippers, three-finger hands and five-finger dexterous hands. Quick-change design enables rapid adaptation to different precision requirements and workload conditions.
This version: Dex1-1 Plus Version two-finger gripper ×2.
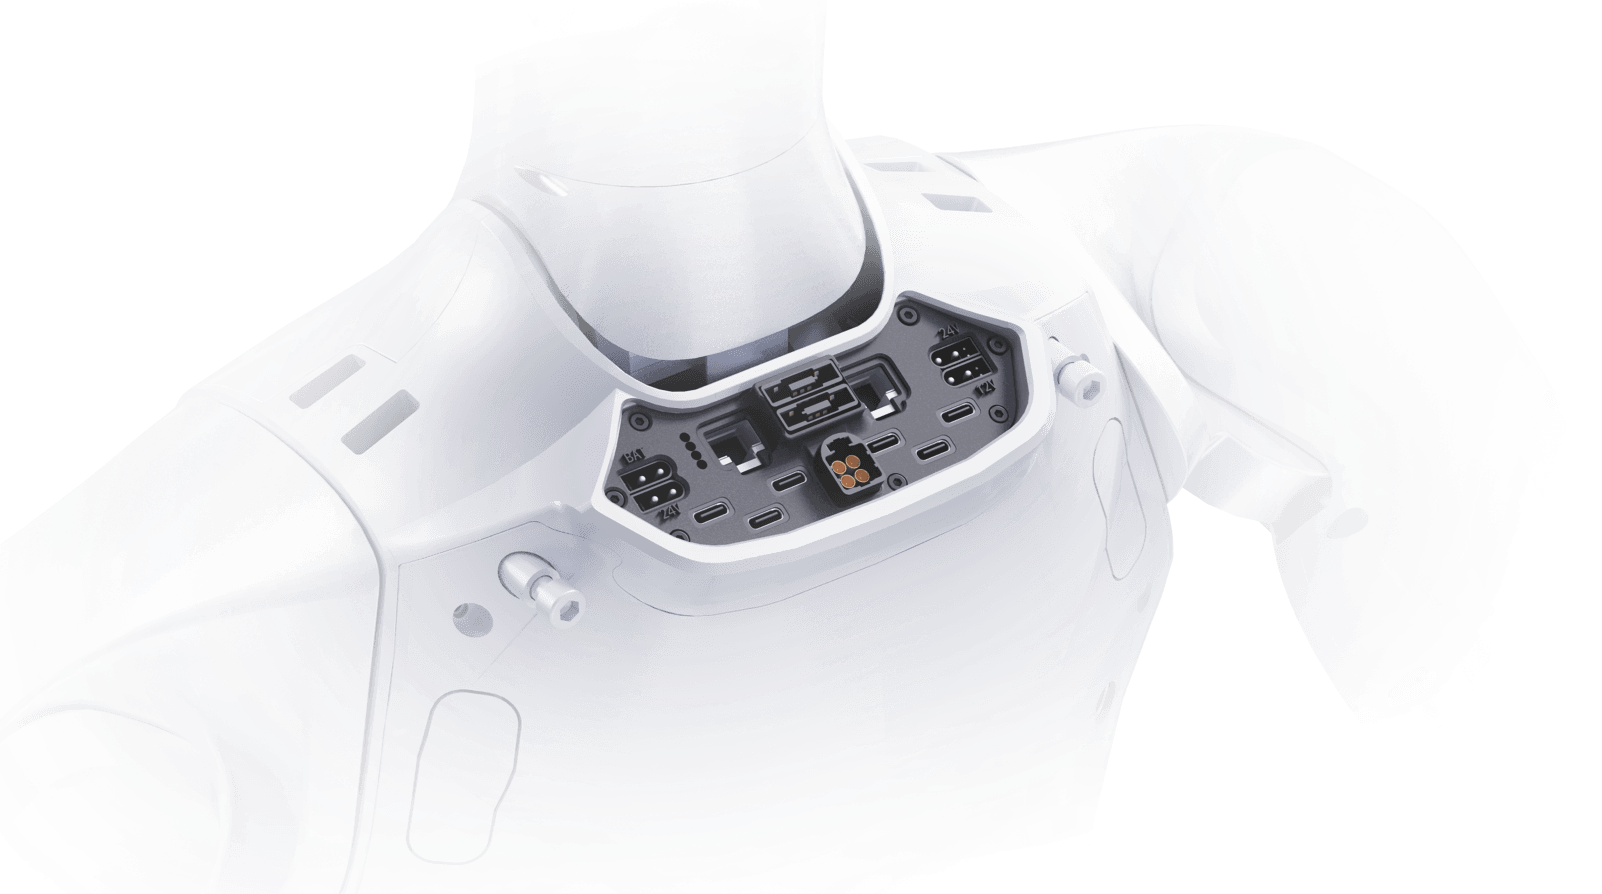
Open Development & Rapid Deployment
Comprehensive SDKs and APIs enable developers to focus on application innovation while reducing development cycles from months to weeks.
H2-A Standard A — Version Highlights
Dex1-1 Plus Version two-finger gripper ×2.
| End Effector | Dex1-1 Plus Version two-finger gripper ×2 (with wrist camera) |
|---|---|
| Dimensions | 143×78×67mm |
| Weight | 550g |
| Stroke | 90mm |
| Fingertip Position Resolution | 0.1mm |
| Gripping Force | 5~120N, adjustable |
| Grasping Load | 20kg (form-fitting) / 5kg (friction) |
| Min. Full-Stroke Closing Time | 0.24s |
| Claw Length | 80mm |
| Communication | High-speed 485 |
| Wrist RGB Camera | FOV D 130° / H 120° / V 81°, resolution 1920×1080 |
| Total DOF | 21 (7×2 (arms) + 3 (waist) + 2 (head) + 1×2 end-effector) |
Technical Specifications — H2-A Standard A
| Overall Dimensions | 780×444×200mm |
|---|---|
| Weight (incl. upper body battery) | 34.4kg |
| DOF (excl. end-effector) | 19 (arms 7×2 + waist 3 + head 2) |
| DOF (incl. end-effector) | 21 (7×2 (arms) + 3 (waist) + 2 (head) + 1×2 end-effector) |
| Arm DOF (excl. end-effector) | 7 per arm |
| Waist DOF | 3 (pitch, yaw, roll) |
| Head DOF | 2 |
| Waist Range of Motion | Yaw ±155° / Pitch +25°/−30° / Roll ±30° |
| Single-Arm Max Load | Peak ~15kg, rated ~7kg |
| Single-Arm Reach (excl. end-effector) | 600mm |
| Joint Output Bearing | Industrial-grade cross-roller bearing (high precision, high load-carrying capacity) |
| Joint Motor | Low-inertia high-speed inner-rotor permanent magnet synchronous motor (enhanced dynamic response and thermal performance) |
| Max Arm Joint Torque | 120N·m |
| Overall Material | Aerospace-grade aluminum, titanium alloy and high-strength engineering plastics |
| PC1 | Intel Core i5 (platform functions) |
|---|---|
| PC2 | Intel Core i7 (user development) |
| PC3 | Empty slot, similar to B2 card-slot form (optional NVIDIA Jetson Thor ×1, available for a fee) |
| PC4 | Empty slot, similar to B2 card-slot form (optional Intel Core i7 ×1 or NVIDIA Jetson Orin NX ×1, available for a fee) |
| High-Performance Computing Module | Multiple brands and models available, such as Thor |
| Head Camera | Wide-angle humanoid binocular camera ×1 |
| Wrist Cameras | Wrist HD camera ×2 |
| Voice Interaction | Microphone array and high-power speaker for natural voice interaction |
| Wireless | WiFi 6, Bluetooth 5.2 |
| Cooling | Air cooling |
| Power Supply | Standard upper body battery with charger, plus standard external power supply (the universal version must be fitted with the upper body battery) |
|---|---|
| Battery | Quick-release battery 75.6V/15Ah (972Wh) |
| Battery Endurance | Approx. 8 hours (depends on actual working conditions) |
| Direct Power Supply | 7×24 hours |
| End Effector | Dex1-1 Plus Version two-finger gripper ×2 (with wrist camera) |
|---|---|
| Dimensions | 143×78×67mm |
| Weight | 550g |
| Stroke | 90mm |
| Fingertip Position Resolution | 0.1mm |
| Gripping Force | 5~120N, adjustable |
| Grasping Load | 20kg (form-fitting) / 5kg (friction) |
| Min. Full-Stroke Closing Time | 0.24s |
| Claw Length | 80mm |
| Communication | High-speed 485 |
| Wrist RGB Camera | FOV D 130° / H 120° / V 81°, resolution 1920×1080 |
| Handheld Remote Controller | Yes |
|---|---|
| Smart OTA Update | Yes |
| Secondary Development | Yes |
| Warranty | 12 Months |
[1] The maximum load of the arm varies greatly under different arm extension postures.
[2] For end-effector selection, please contact our sales team.
[3] For more information, please read the secondary development manual.
[4] The above parameters may vary in different scenarios and configurations; please subject to actual situation.
[5] The humanoid robot features a complex structure and extremely powerful power. Users must maintain a sufficient safety distance between humans and the robot. Use with extreme caution.
[6] The product appearance is subject to change. Please refer to the final product.
[7] Some features are under development and will be released gradually.
[8] This product is a civilian robot. We kindly request that all users refrain from making any dangerous modifications or using the robot in a hazardous manner.
[9] Please visit the manufacturer's official website for more related terms and policies, and comply with local laws and regulations.
Frequently Asked Questions
What is the H2-A Standard A?
The H2-A Standard A is a dual-arm humanoid robot on a fixed base, fitted with Dex1-1 Plus Version two-finger gripper ×2, with wrist cameras. Tactile sensing: No.
What are the dimensions and weight of the H2-A Standard A?
It measures 780×444×200mm and weighs 34.4kg including the upper body battery.
How many degrees of freedom does the H2-A Standard A have?
Excluding the end-effector it has 19 DOF (arms 7×2, waist 3, head 2). With the 1-DOF end-effector on each side, the total is 21 DOF.
What payload and reach does the H2-A Standard A offer?
Each arm has a peak load of about 15kg and a rated load of about 7kg (load varies with arm extension), with a single-arm reach of 600mm excluding the end-effector.
How is the H2-A Standard A powered, and is it open for development?
It runs about 8 hours on the upper body battery (depending on working conditions) or continuously on direct power (7×24H). It supports secondary development and smart OTA updates, includes a handheld remote controller and carries a 12-month warranty.
The full sheet
Related products
-
·LND·00
-
·LND·01
-
·LND·02
-
·LND·03

There are no reviews yet.