
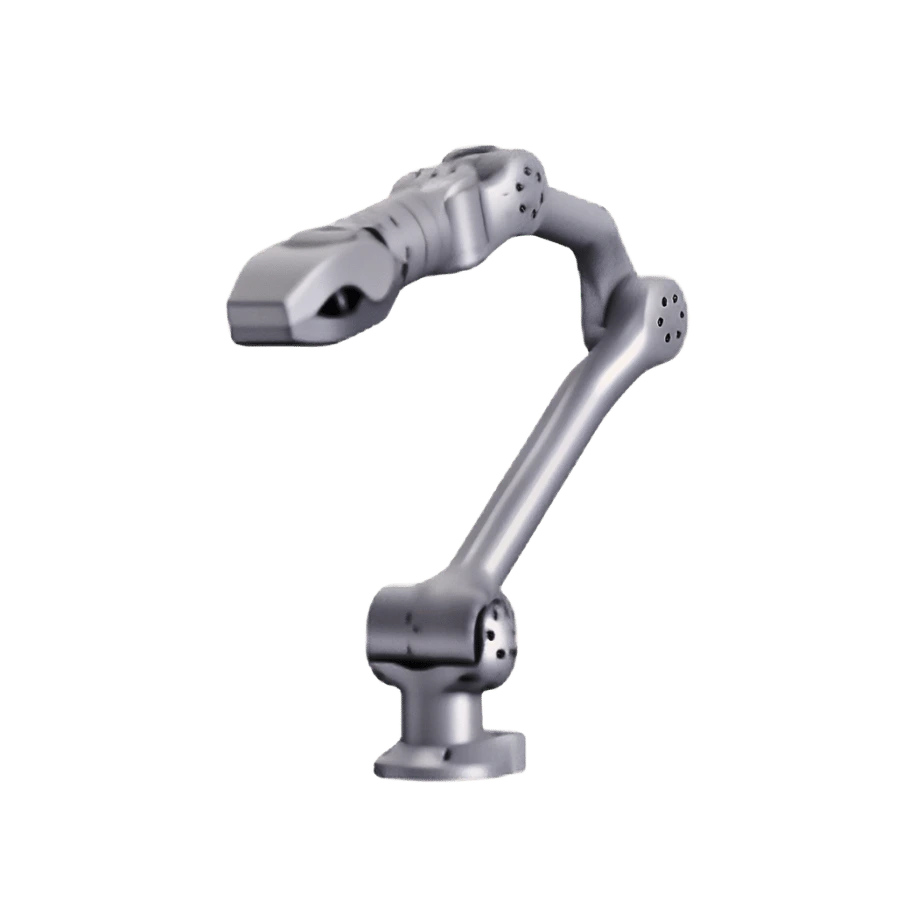
Z1 Pro (With Gripper)
- 6-DOF robotic arm with 4.5kg weight, 3kg or more payload and 740mm reach for mobile robot on-board use
- Repeat positioning accuracy of about 0.1mm for precise, repeatable motion
- Joint ranges: J1 ±150°, J2 0°–180°, J3 -165°–0°, J4 ±80°, J5 ±85°, J6 ±160°
- Sensitive collision detection, manual drag teaching, position control and force control
- Ethernet interface, Ubuntu user OS, 24V supply (>20A), max power 500W
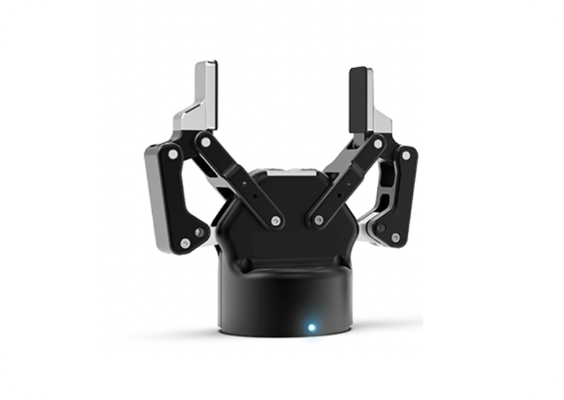
- Z1 mechanical gripper: 139×80×68mm, 700g–750g, 200N max jaw force, 150N fingertip force, 90° opening, 0.5s open/close, 24V, 70W peak, RS485
- Gripper dimensions 139mm × 80mm × 68mm with a 90° maximum opening angle
- Joint motors with 33N·m max torque, 15-bit encoder and 1kHz control frequency
- Trusted dealerDirect manufacturer partnership
- Pan-India deliveryInsured shipping, all states
- Post-sale supportTraining + service included
What makes it work
Z1 Pro (With Gripper)
Perfect synergy with mobile platforms. Compact and lightweight 6-DOF robotic arm
Compact, Dexterous and Precise
Compact & Lightweight
Designed as an on-board arm for mobile robots.
Dexterous & Flexible
6 axes of motion with wide joint ranges.
Sufficient Payload
Payload of ≥3kg.
Sufficient Accuracy
Repeat positioning accuracy of about 0.1mm.
Joint Force Control
Position control and force control supported.
Collision Protection
Sensitive collision detection with force feedback.
Z1 Gripper
The z1 mechanical gripper.
Max jaw clamping force 200N, max opening angle 90°, open/close time 0.5s.
Open Programming Interface and Extended Interface
The manipulator control program and control interface will be successively opened, and different actuators can be quickly replaced at the end of the manipulator.
Joint Motor
High-torque, compact joint motors with force-control capability, 1 kHz control frequency and torque / angle / angular-velocity feedback.
Application
Mobile robots' on-board manipulator, e-commerce logistics, new consumption, daily life and more.
Technical Specifications — Z1 Pro (With Gripper)
| Model | Z1 Pro |
|---|---|
| Degrees of Freedom | 6 axis (6 DOF) |
| Weight | 4.5kg |
| Payload | ≥3kg |
| Reach | 740mm |
| Repeat Positioning Accuracy | About 0.1mm |
| Power Supply | 24V, current >20A |
| Max Power | 500W |
| Interface | Ethernet |
| User OS | Ubuntu |
| Force Feedback & Collision Detection | Provided (sensitive collision detection) |
| Teaching | Manual drag teaching |
| Control Interface | Position control + force control |
| Joint 1 (J1) | ±150° |
|---|---|
| Joint 2 (J2) | 0° ~ 180° |
| Joint 3 (J3) | -165° ~ 0° |
| Joint 4 (J4) | ±80° |
| Joint 5 (J5) | ±85° |
| Joint 6 (J6) | ±160° |
| Backlash | ~6 arcmin |
|---|---|
| Communication | RS485 |
| Max Torque | 33 N·m |
| Encoder | 15-bit |
| Weight | 405g |
| Force Control Accuracy | ~0.2 N·m |
| Size | Φ65 × 52mm |
| Control Frequency | 1 kHz |
| Reducer | Harmonic reducer |
| Bearing | Industrial-grade cross roller bearing |
| Reduction Ratio | 60+ |
| Voltage | 24V (recommended) |
| Gripper Type | Z1 mechanical gripper |
|---|---|
| Dimensions | 139mm × 80mm × 68mm |
| Weight | 700g ~ 750g |
| Max Jaw Clamping Force | 200N |
| Max Fingertip Clamping Force | 150N |
| Max Opening Angle | 90° |
| Open / Close Time | 0.5s |
| Rated Voltage | 24V |
| Peak Power | 70W |
| Communication | RS485 |
Frequently Asked Questions
What is the Z1 Pro (With Gripper)?
The Z1 Pro is a compact, lightweight 6-DOF robotic arm built for mobile robot on-board use, with sensitive collision detection, manual drag teaching, and position and force control. It comes with the Z1 mechanical gripper.
What are the weight and payload of the Z1 Pro (With Gripper)?
The arm weighs 4.5kg and carries a payload of 3kg or more, with a reach of 740mm and repeat positioning accuracy of about 0.1mm.
What are the joint ranges of the Z1 Pro (With Gripper)?
J1 ±150°, J2 0° to 180°, J3 -165° to 0°, J4 ±80°, J5 ±85°, J6 ±160°.
What control and teaching features does the Z1 Pro (With Gripper) support?
It supports sensitive collision detection, manual drag teaching, and position control plus force control (force feedback), with an Ethernet interface and a 24V power supply.
What are the specifications of the gripper on the Z1 Pro (With Gripper)?
The Z1 mechanical gripper measures 139mm × 80mm × 68mm, weighs 700g to 750g, has a max jaw clamping force of 200N, max fingertip clamping force of 150N, a max opening angle of 90° and an open/close time of 0.5s. It runs on 24V with 70W peak power over RS485.
The full sheet
Related products
-
·LND·00
-
·LND·01
-
·LND·02
-
·LND·03

There are no reviews yet.