
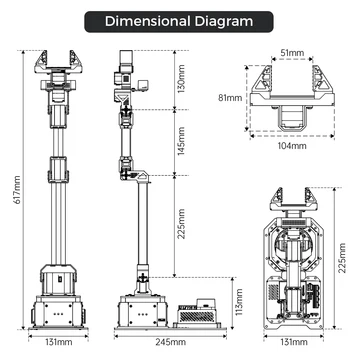
NexArm ROS2 Sliding Rail Warehouse Sandbox Kit (Without Raspberry Pi Controller)
- High-precision electric sliding rail with multi-tier shelving
- NexArm multi-DOF robotic arm with 3D depth vision and hand-eye coordination
- Visual control hub with dual-channel video feeds and one-key scene switching
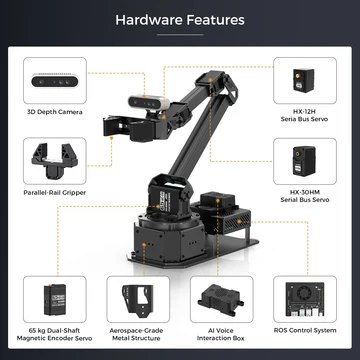
- ESP32 (ESP-WROOM) controller, HX-12H / HX-30HM / HX-65HM bus servos
- Ubuntu 22.04 + ROS 2 Humble, Python, C and C++
- Includes the accessory pack for kits without Raspberry Pi 5
- 8.8 kg, 12V 5A power supply
- Variant: Without Raspberry Pi Controller
- Trusted dealerDirect manufacturer partnership
- Pan-India deliveryInsured shipping, all states
- Post-sale supportTraining + service included
What makes it work
NexArm ROS2 Sliding Rail Warehouse Sandbox Kit (Without Raspberry Pi Controller) – Electric Sliding Rail, ESP32 ROS2 Kit with VLA, 3D Vision & Multimodal AI
The Sliding Rail Warehouse Sandbox Kit is an all-in-one experimental platform purpose-built for advanced ROS education and embodied AI research.
Product Description
The Sliding Rail Warehouse Sandbox Kit is an all-in-one experimental platform purpose-built for advanced ROS education and embodied AI research. Featuring an advanced modular architecture, it natively fuses multimodal large models, OpenClaw agents, ACT, VLA, machine vision, and inverse kinematics into a complete validation loop spanning foundational concepts to high-level embodied algorithms.
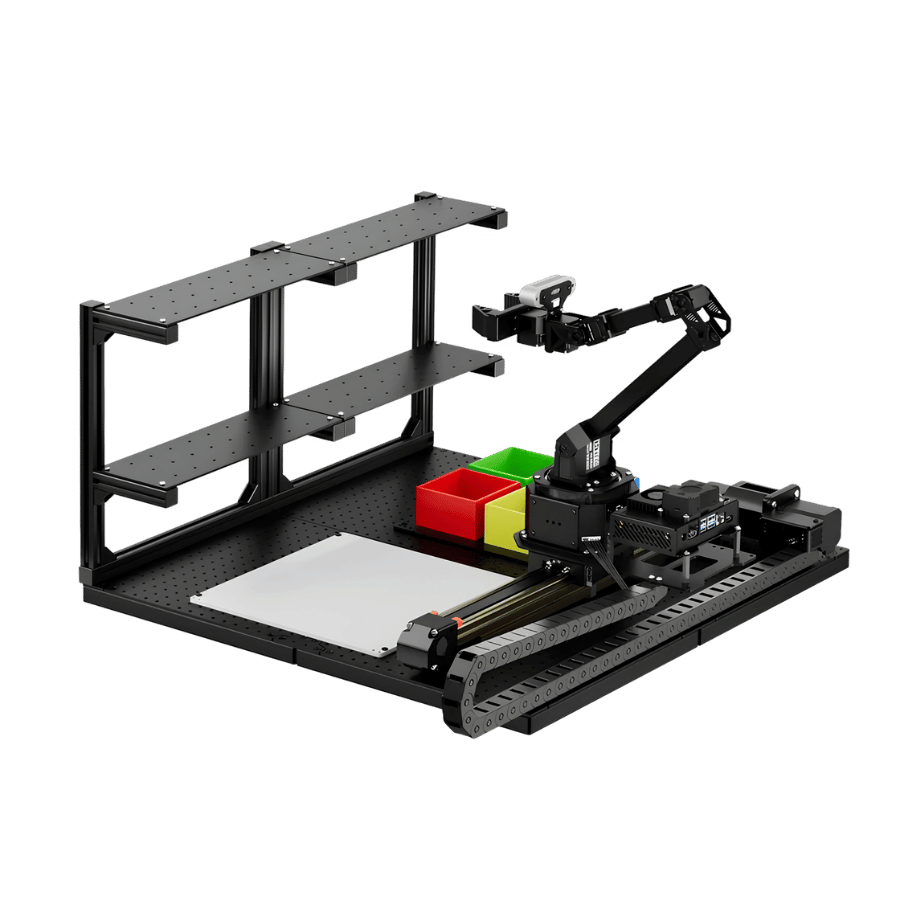
Featuring high-precision electric sliding rails and multi-tier shelving, the kit accurately replicates industrial warehousing—covering multi-station transfer, automated sorting, and inventory control. Powered by DC geared motors and PVC belts, it offers smooth, plug-and-play transport with adjustable speed and direction for effortless automated logistics.
Available Options
Controller
Key Features & Applications

Multi-DOF Robotic Arm Manipulation
Featuring a multi-DOF joint design paired with trapezoidal acceleration/deceleration, NexArm ROS ensures smooth, jitter-free motion. It effortlessly executes multi-angle grasping, transport, and placement.

Large AI Model & OpenClaw
Fusing the OpenClaw agent with multimodal AI models across speech, language, and vision, the NexArm ROS robotic arm executes complex remote tasks like visual scene understanding, dynamic object tracking, and data aggregation and analysis.

3D Depth Vision & Hand-Eye Coordination
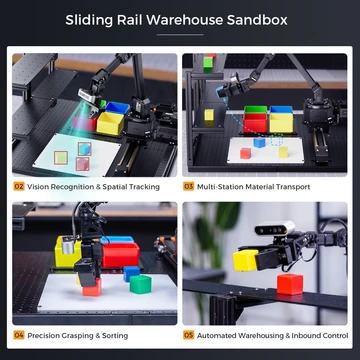
Fusing RGB and depth data allows the NexArm ROS to perceive object colors and point cloud information. Leveraging inverse kinematics, it enables advanced AI projects including arbitrary 3D grasping, sorting, and transporting.

Visual Control Hub
Featuring dual-channel real-time video feeds, one-key scene switching, and custom hardware parameter configuration, this kit makes controlling and monitoring material transport and sorting intuitive and effortless—delivering an efficient interactive platform for smart warehousing training.
Sliding Rail Warehouse Sandbox
Integrating precision linear electric rails with multi-tier shelving, this setup supports multi-station material handling, automated warehouse sorting, and inbound inventory control—fully replicating industrial warehousing and logistics workflows.

Sandbox Configurations

Multiple Configuration Options
Supports mobile suspended chassis and electric sliding rails to precisely simulate smart warehousing, logistics sorting, and automated production lines for rapid Embodied AI algorithm validation.

NexArm ROS Robotic Arm
Integrating multimodal large models, advanced machine vision, inverse kinematics, and natural interaction, it supports visual calibration, basic picking, and sorting operations. It offers a flexible development environment for ROS onboarding and rapid algorithm validation, covering full-pipeline embodied AI experimental needs.

Suspended Mobile Chassis
NexArm ROS is integrated with a suspended tank or suspended omnidirectional Mecanum wheel chassis. Beyond supporting remote mobile control via wireless controller or app, the setup drives efficient mobile tracking and autonomous line following.

Sorting Sandbox
Combining computer vision, localization, path planning, and precision grasp control, this sandbox accurately identifies features like color and shape to rapidly classify and sort cluttered items. It serves as an ideal hands-on platform for teaching automated sorting and smart logistics.

Dual-Arm Conveyor Development Kit
This highly integrated sandbox features a dual-arm 3D vision system, an AI edge computing controller, and motorized drive mechanisms. It is engineered for dual-arm collaborative experimentation and embodied AI algorithm validation.

Hardware Specifications


Product Videos
Packing List


Technical Specifications

| Product model | NexArm ROS Sliding Rail Warehouse Sandbox Kit |
|---|---|
| Weight | 8.8kg |
| Material | Metal brackets |
| ESP32 controller | ESP-WROOM main chip |
| Control Methods | ROS topics/nodes, Python programming, app control, PC software control |
| Camera | Depth camera |
| Power supply | 12V 5A DC power adapter |
| Operating system | Ubuntu 22.04 + ROS 2 Humble |
| Software | iOS/Android app, Windows PC software |
| Communication | USB, Wi-Fi, Ethernet |
| Programming tools | Python, C, C++ |
| Servo model | HX-12H / HX-30HM / HX-65HM intelligent bus servos |
| Included materials | Comprehensive tutorials, ROS source code, ESP32 source code, system images, supporting softwares |
Frequently Asked Questions
What does the Without Raspberry Pi Controller version include?
It includes the Sliding Rail Warehouse Sandbox Kit packing list plus the "Accessory Pack for Kits without Raspberry Pi 5" (top and bottom covers, Raspberry Pi 5 expansion board, cooling fan, cables and screws). The Raspberry Pi 5 board itself is not included.
What does the sliding rail add to the sandbox?
A high-precision electric linear sliding rail with multi-tier shelving supports multi-station transport, automated inventory sorting and inbound control, replicating industrial warehousing workflows.
How does the robotic arm perceive objects?
It fuses RGB and depth data from a 3D depth camera to perceive color and point cloud information, enabling 3D grasping, sorting and transporting.
Which software and programming tools are supported?
It runs Ubuntu 22.04 + ROS 2 Humble, with Python, C and C++, plus iOS/Android app and Windows PC software.
How is the kit controlled?
Through ROS topics/nodes, Python programming, app control or PC software control, over USB, Wi-Fi or Ethernet.




There are no reviews yet.