
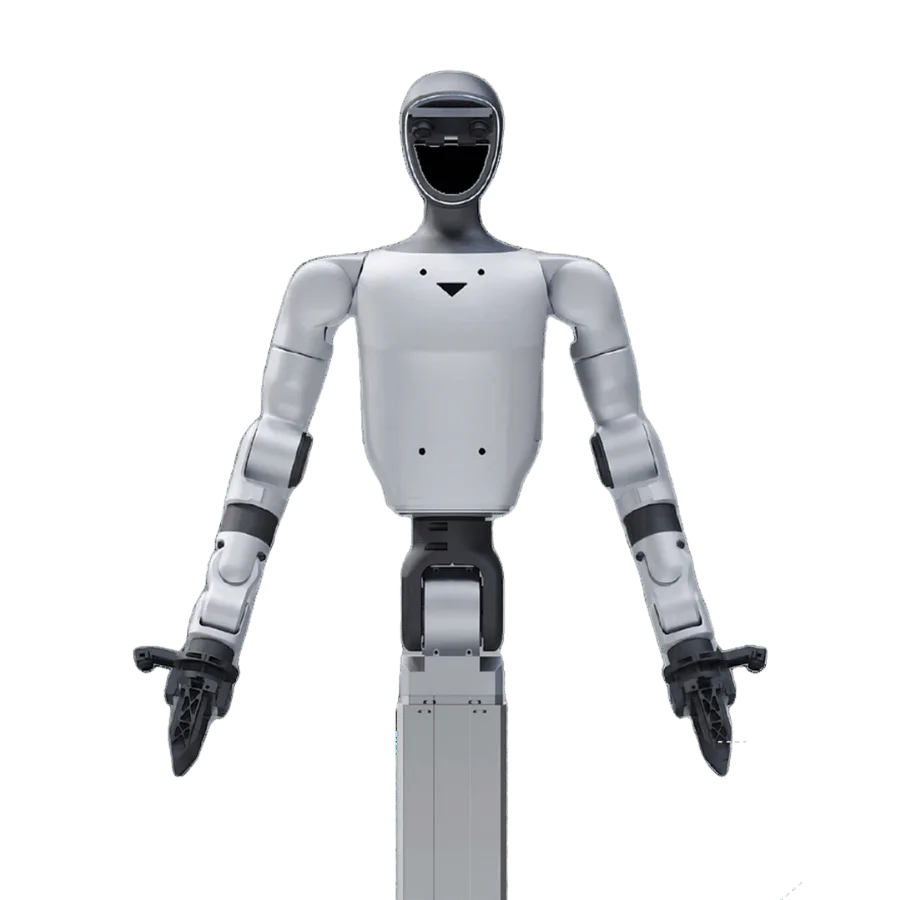
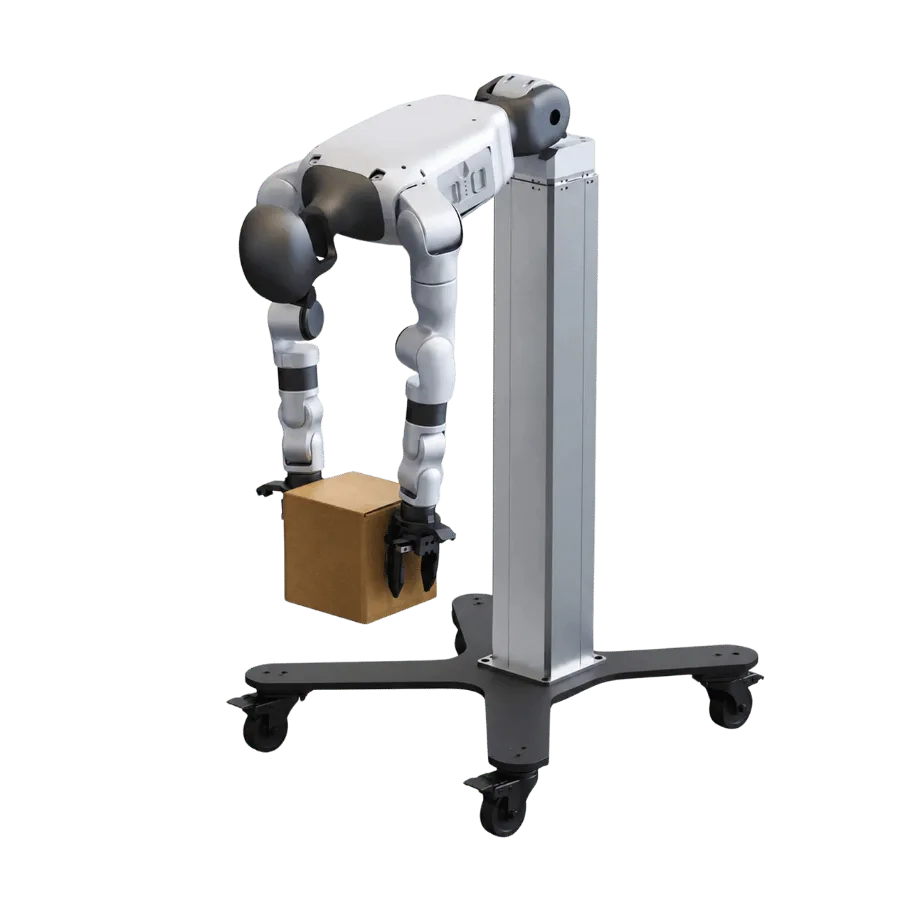
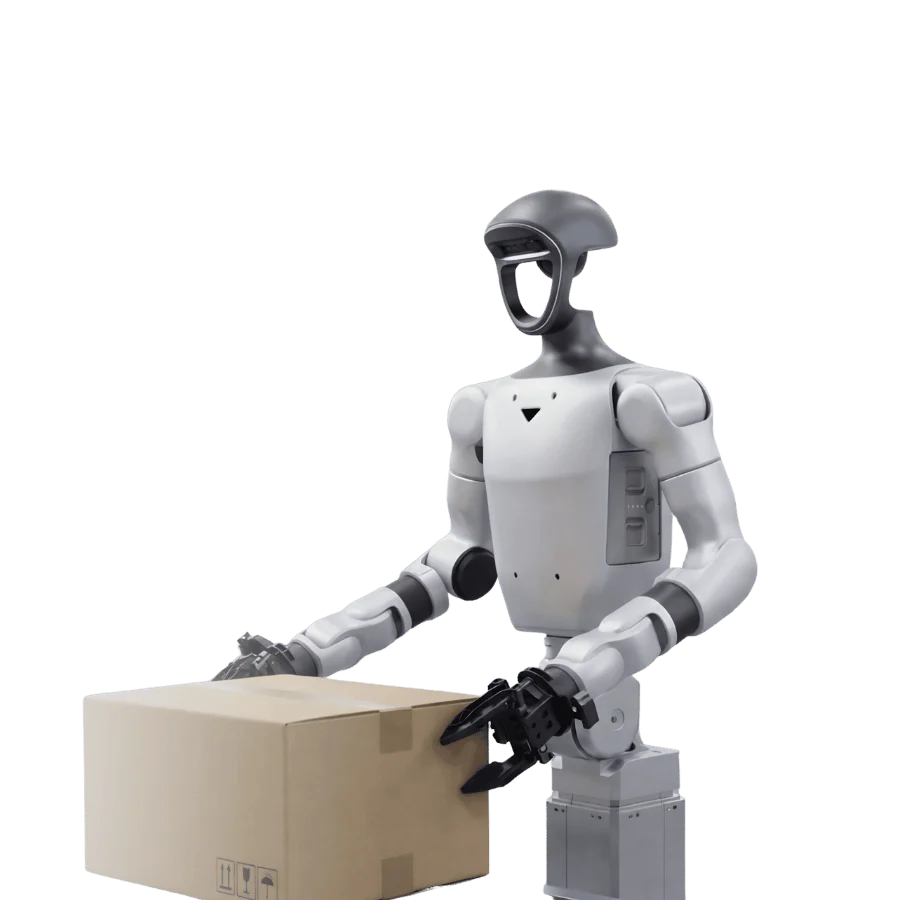
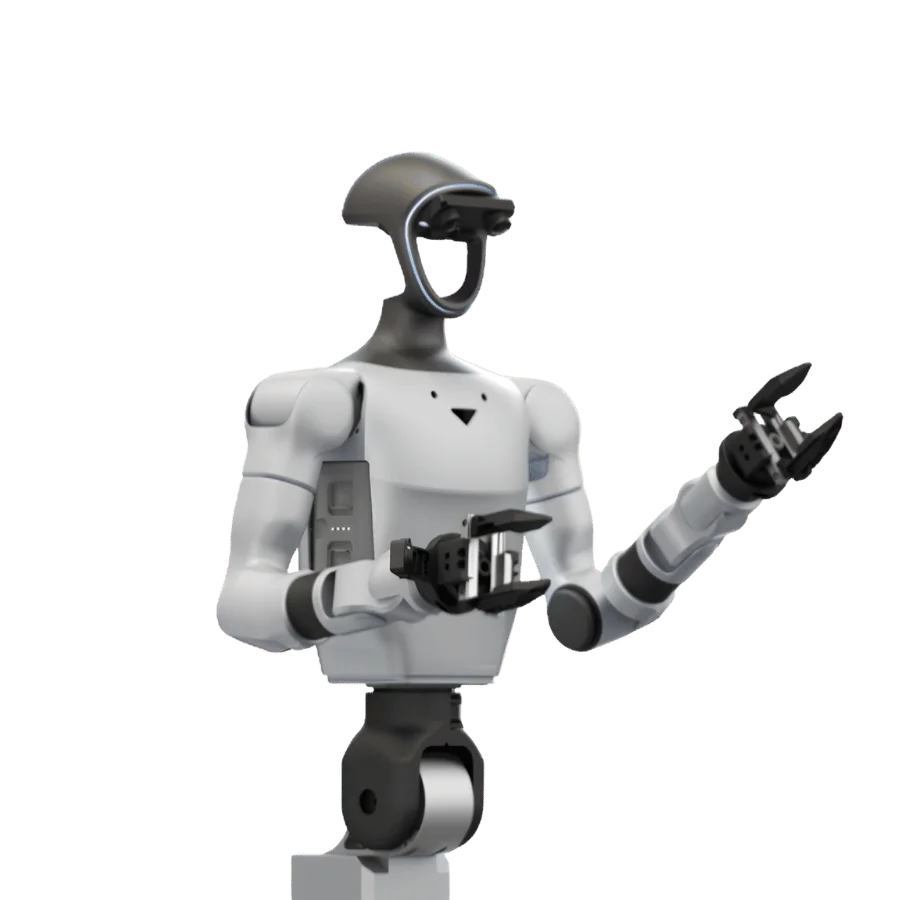
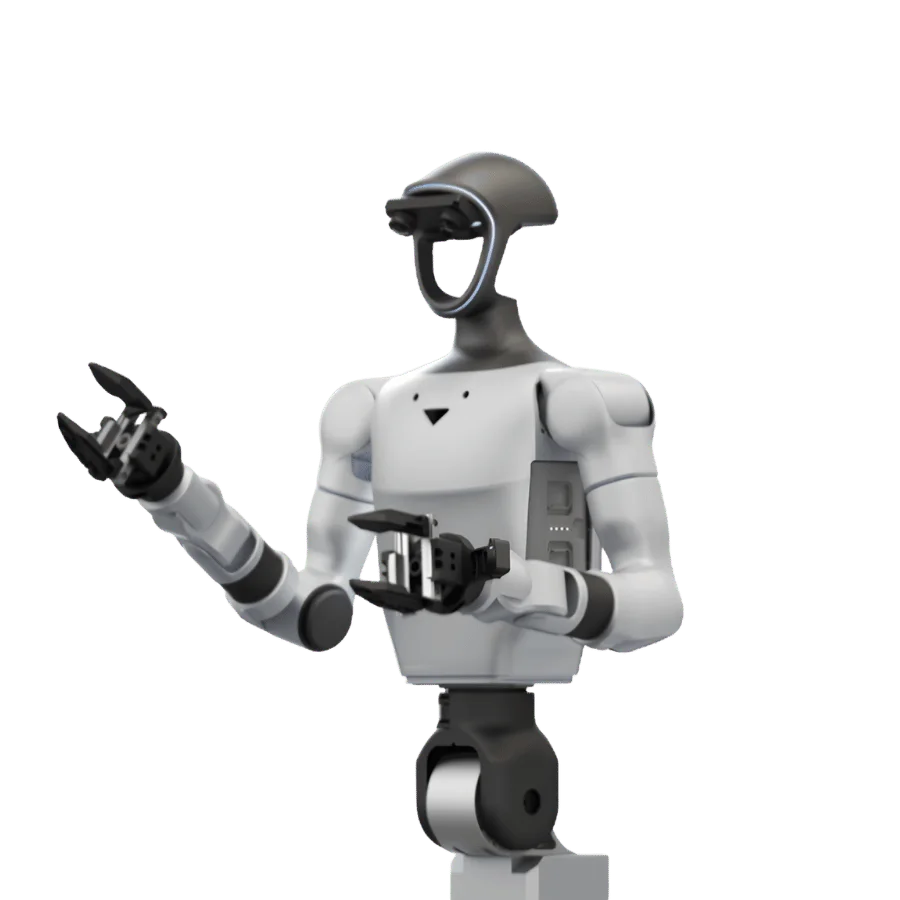
Unitree G1-D Standard F
- Two Wuji 5-finger dexterous hands (non-tactile), each with an RGB camera and 20 active DOF
- Back-drivable serial direct-drive joints, with full opposition and lateral abduction supported
- 1000 Hz x 20 axes MIT force-position hybrid control over EtherNet (1000BASE-T)
- Peak fingertip force of 15N or more, open/close speed of 4 cycles/s or more, and joint backlash under 1°
- 57 DOF whole machine: arms 7×2, waist 2, column 1, hands 20×2
- Arm payload ~3kg with ~0.45m reach, and a lift column with 420mm stroke, 1mm accuracy and ~2m max operating height
- 8-core CPU plus Jetson Orin 16G (100 Tops), 2h quick-release battery, OTA upgrades
- Trusted dealerDirect manufacturer partnership
- Pan-India deliveryInsured shipping, all states
- Post-sale supportTraining + service included
What makes it work
G1-D Standard F
End-to-End Platform for Humanoid Robot · Data & Training
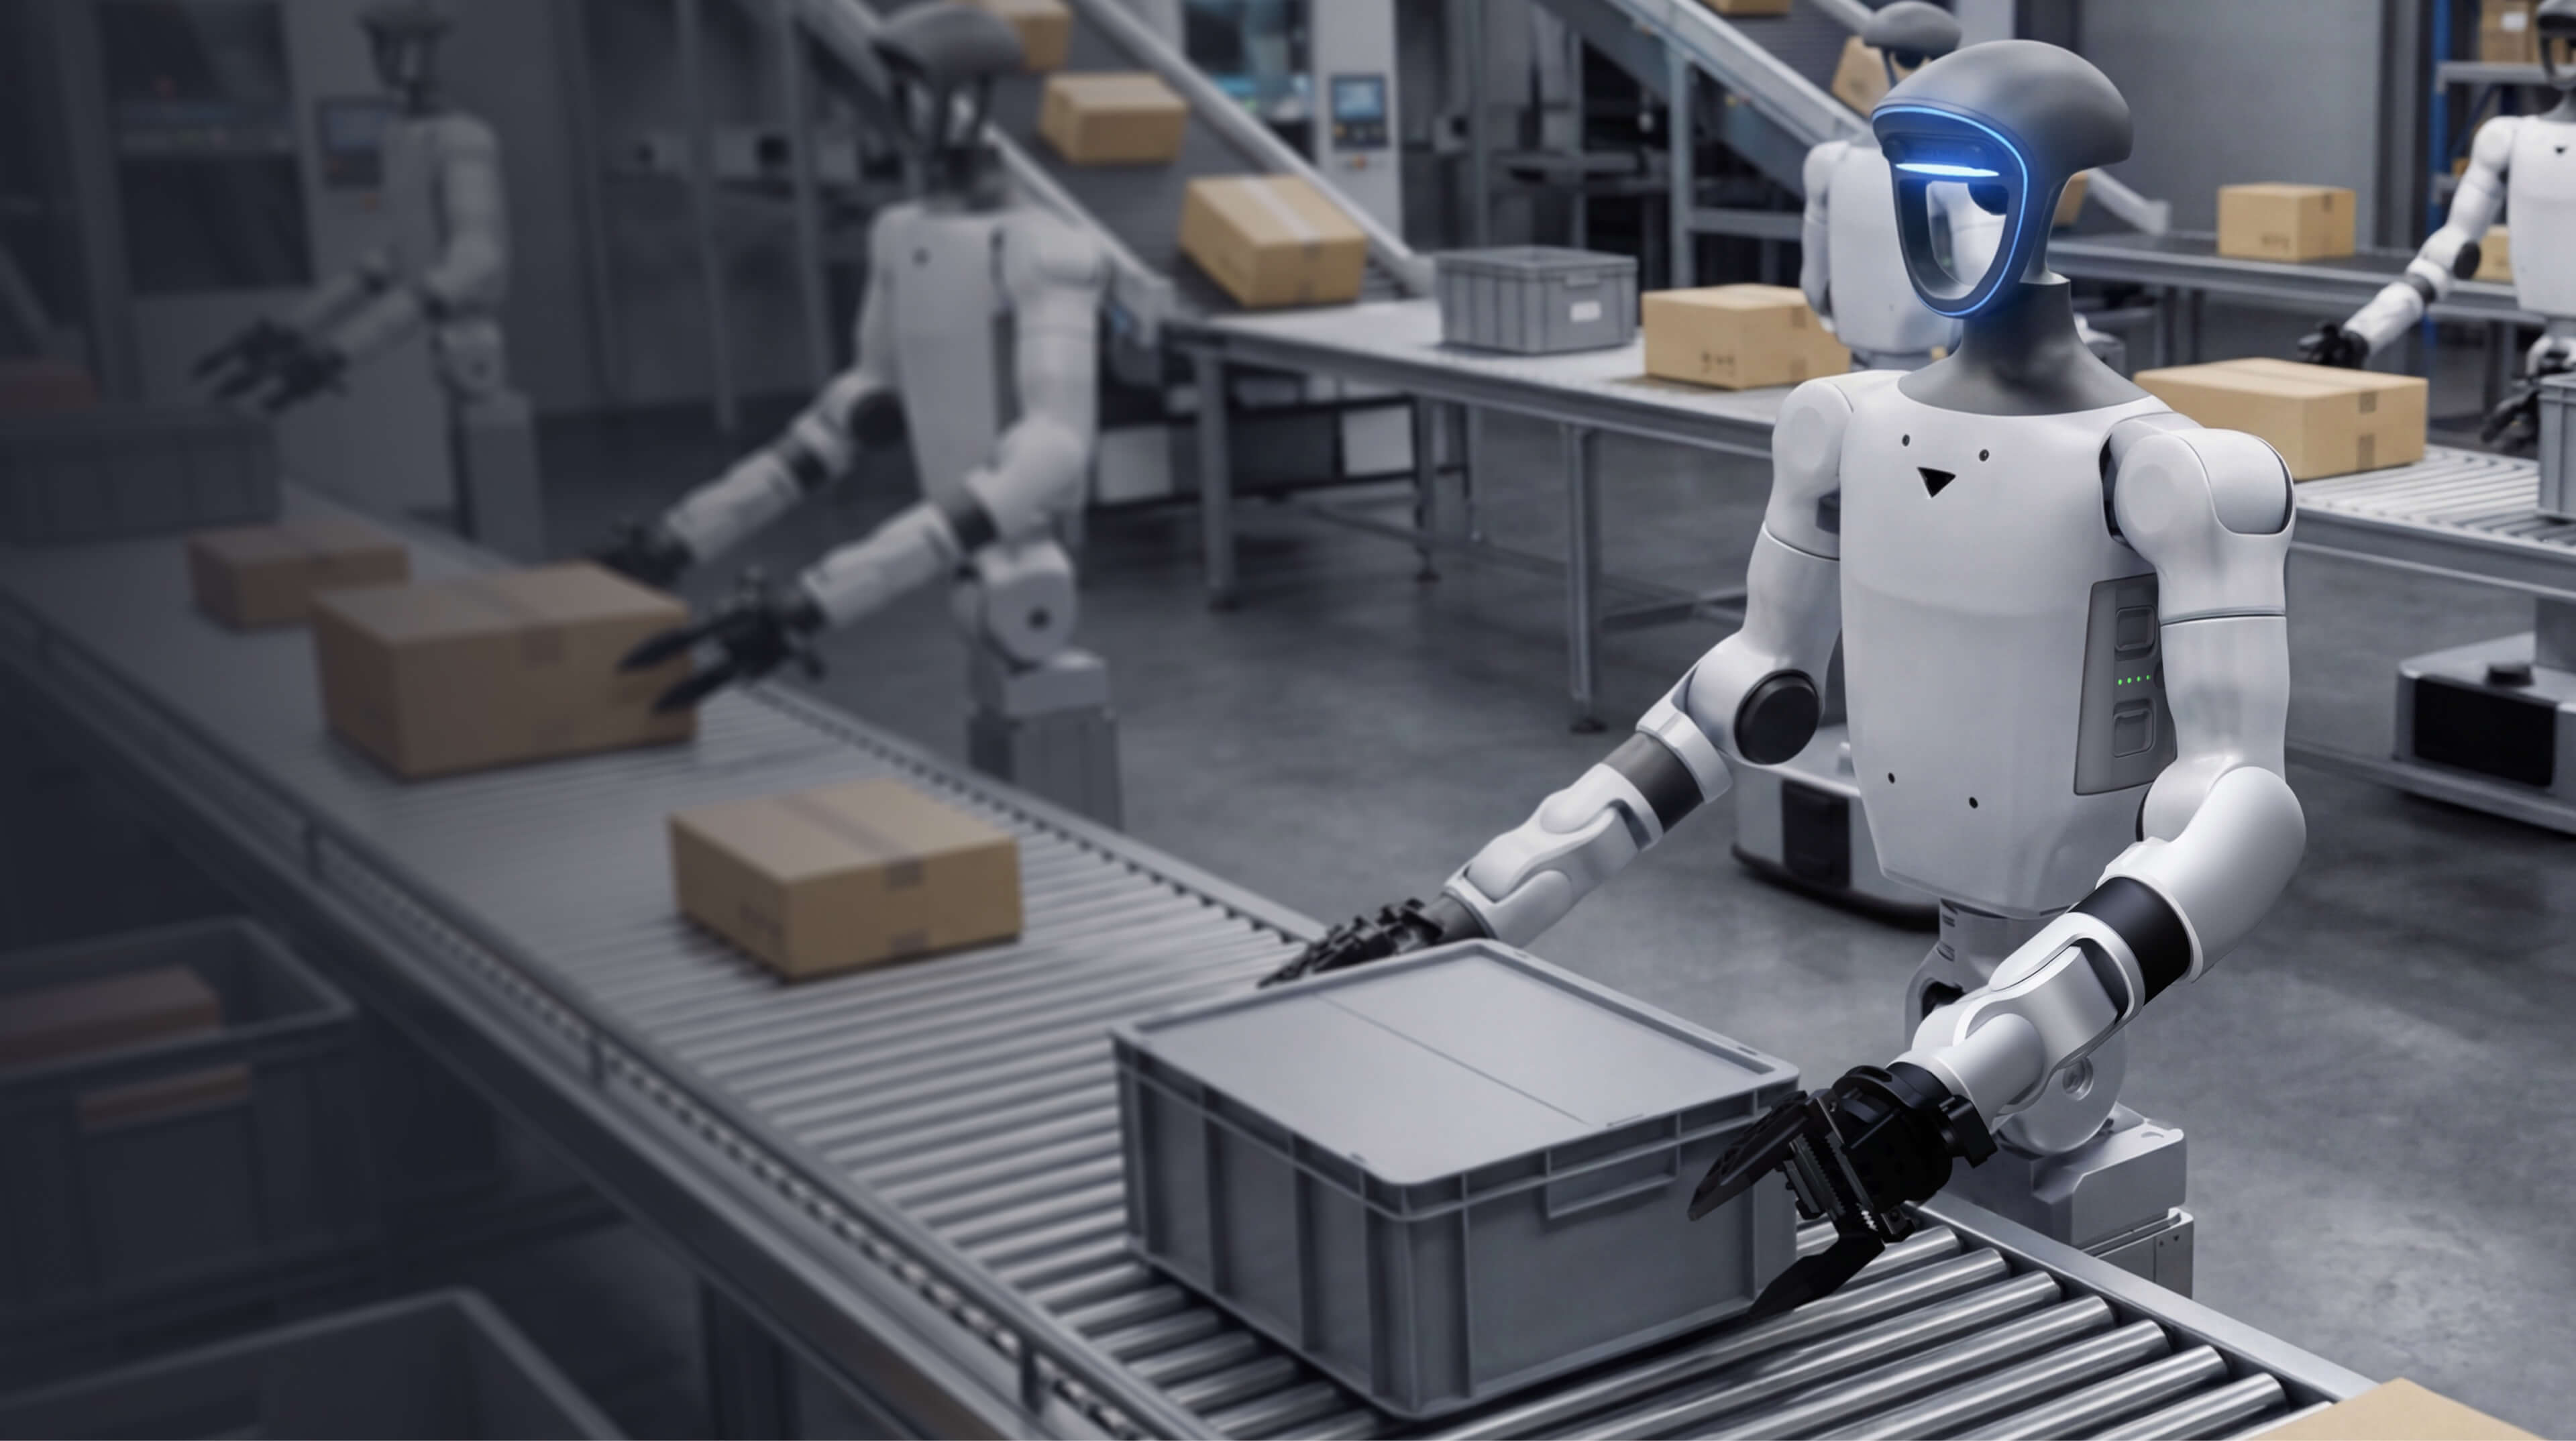
Core Components
High-Performance Humanoid Robot
Proprietary humanoid platforms built with in-house actuators, gearboxes, encoders and sensors.
Streamlined Data Acquisition Tools
One platform for the whole data pipeline: collection, processing, labeling, review and data asset management.
Comprehensive Model Training & Inference Tools
Distributed training, custom model development and smooth deployment, with support for all major open-source frameworks.
Higher-DOF Robot Platform
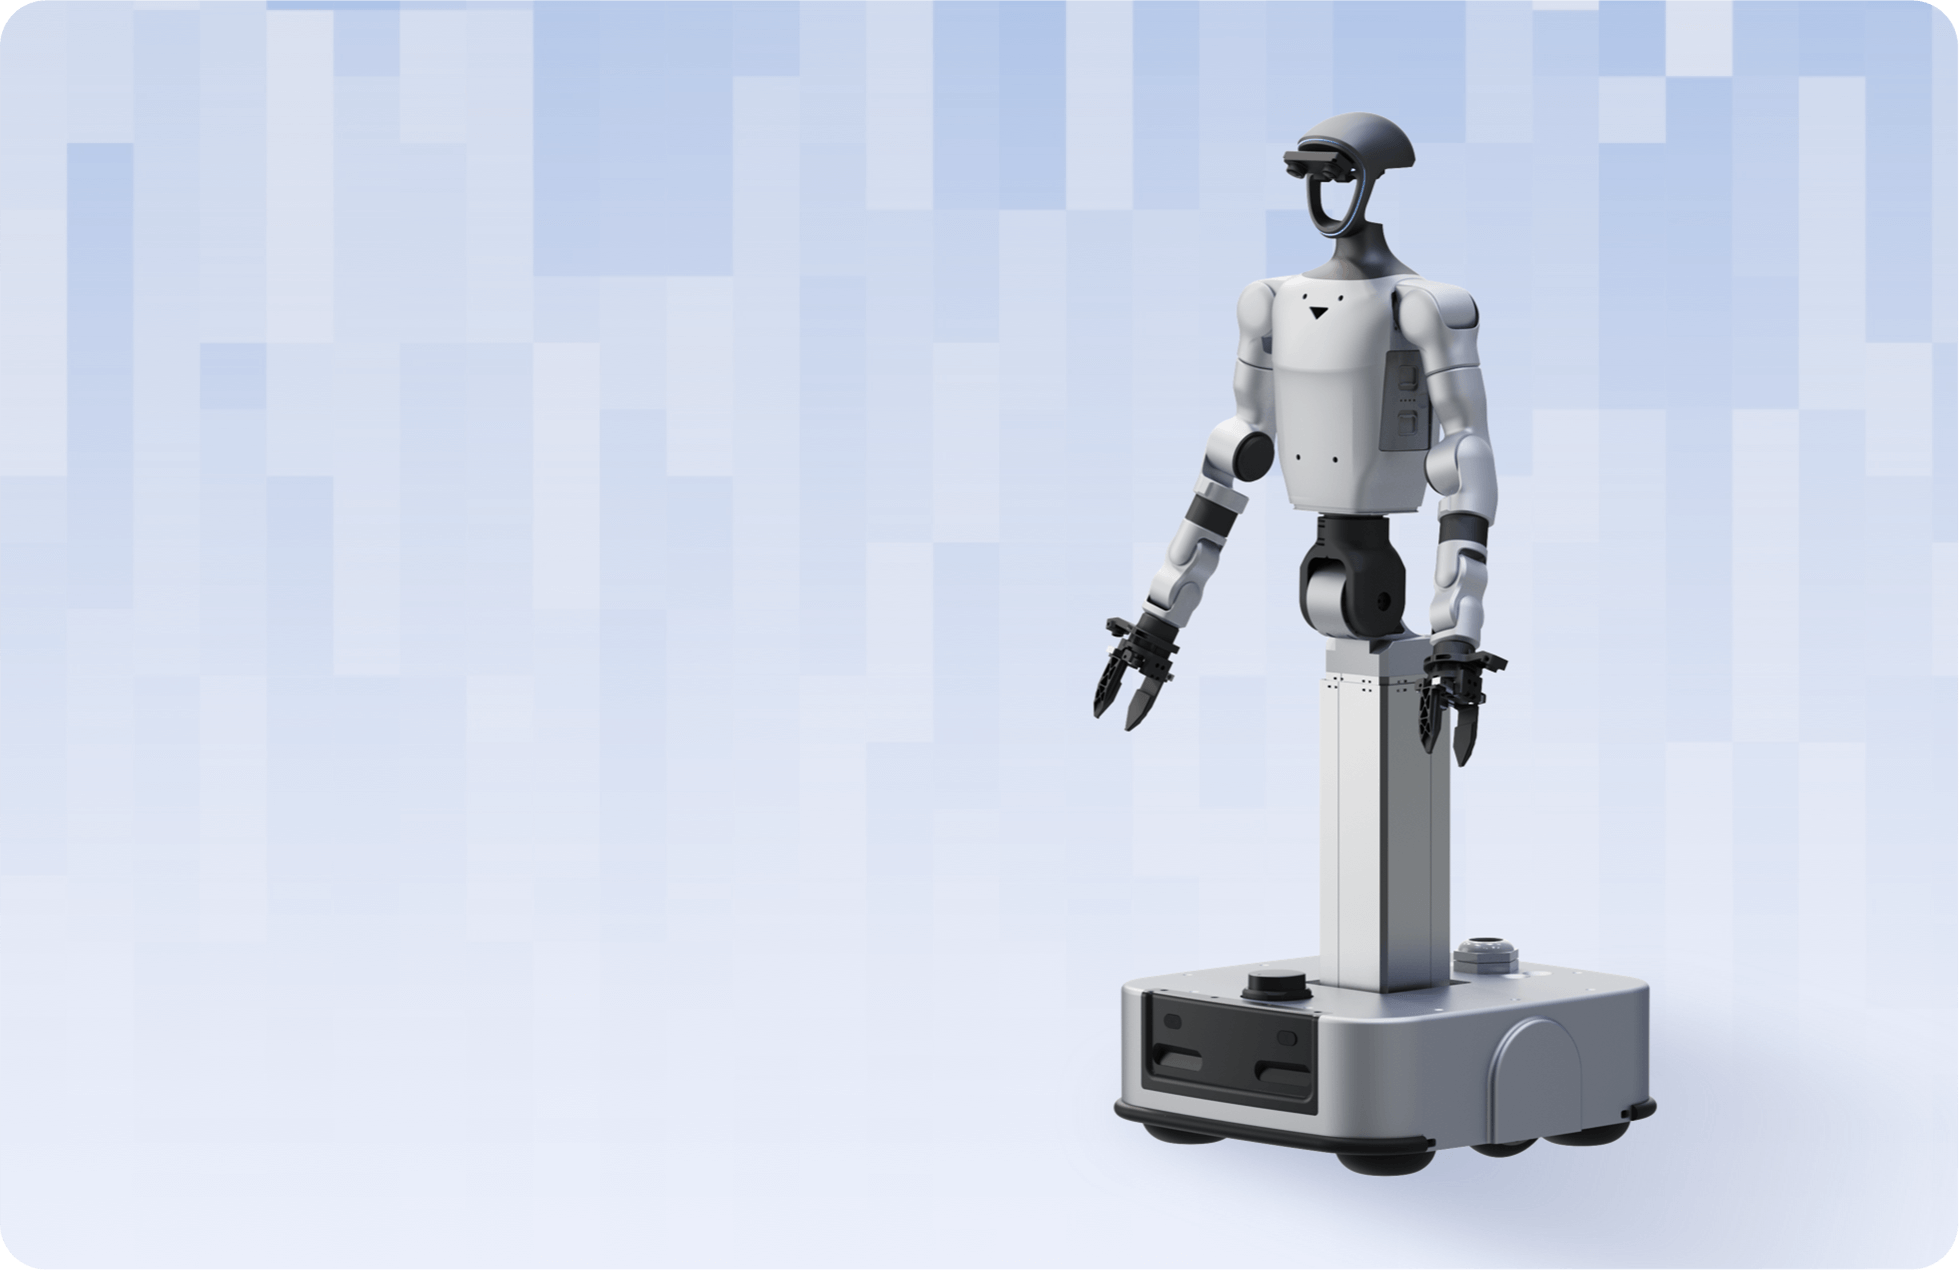
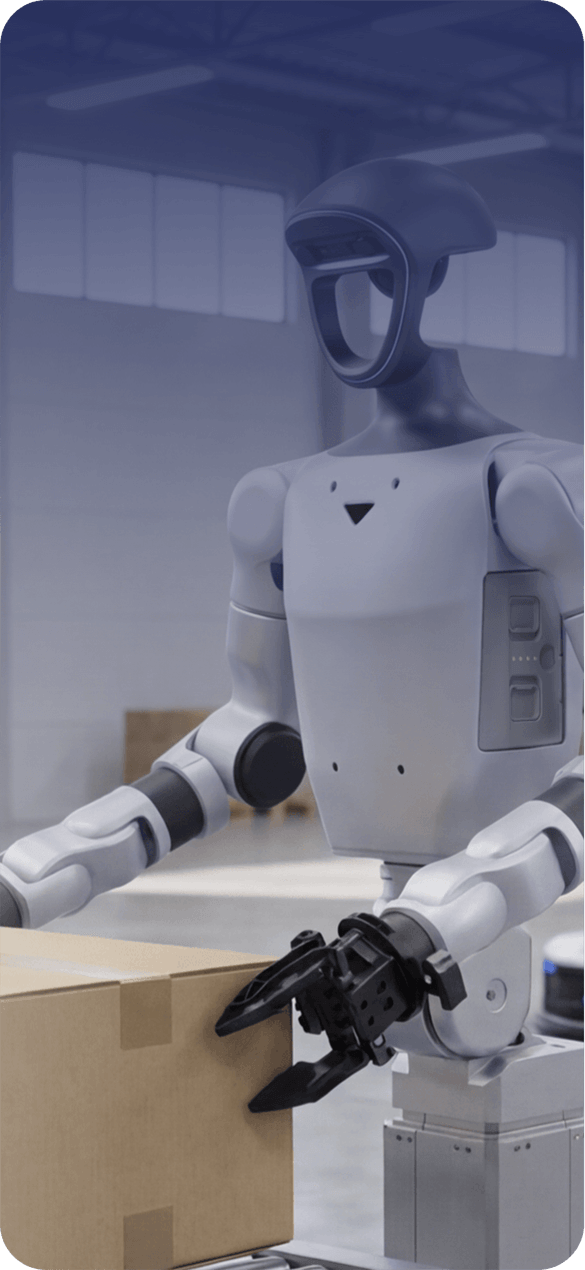
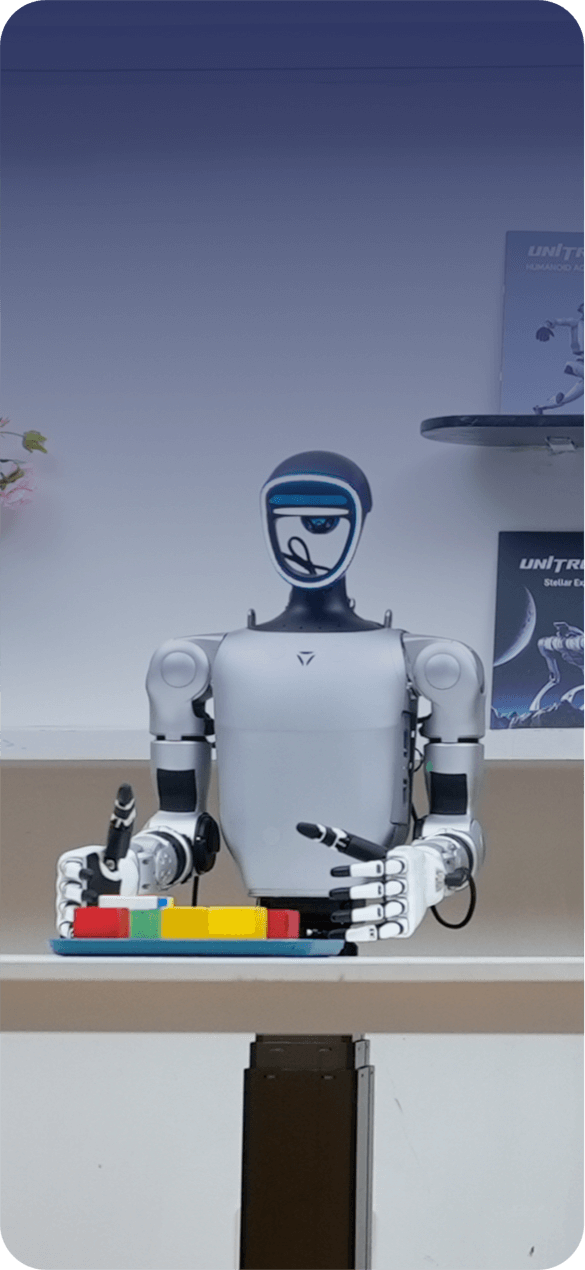
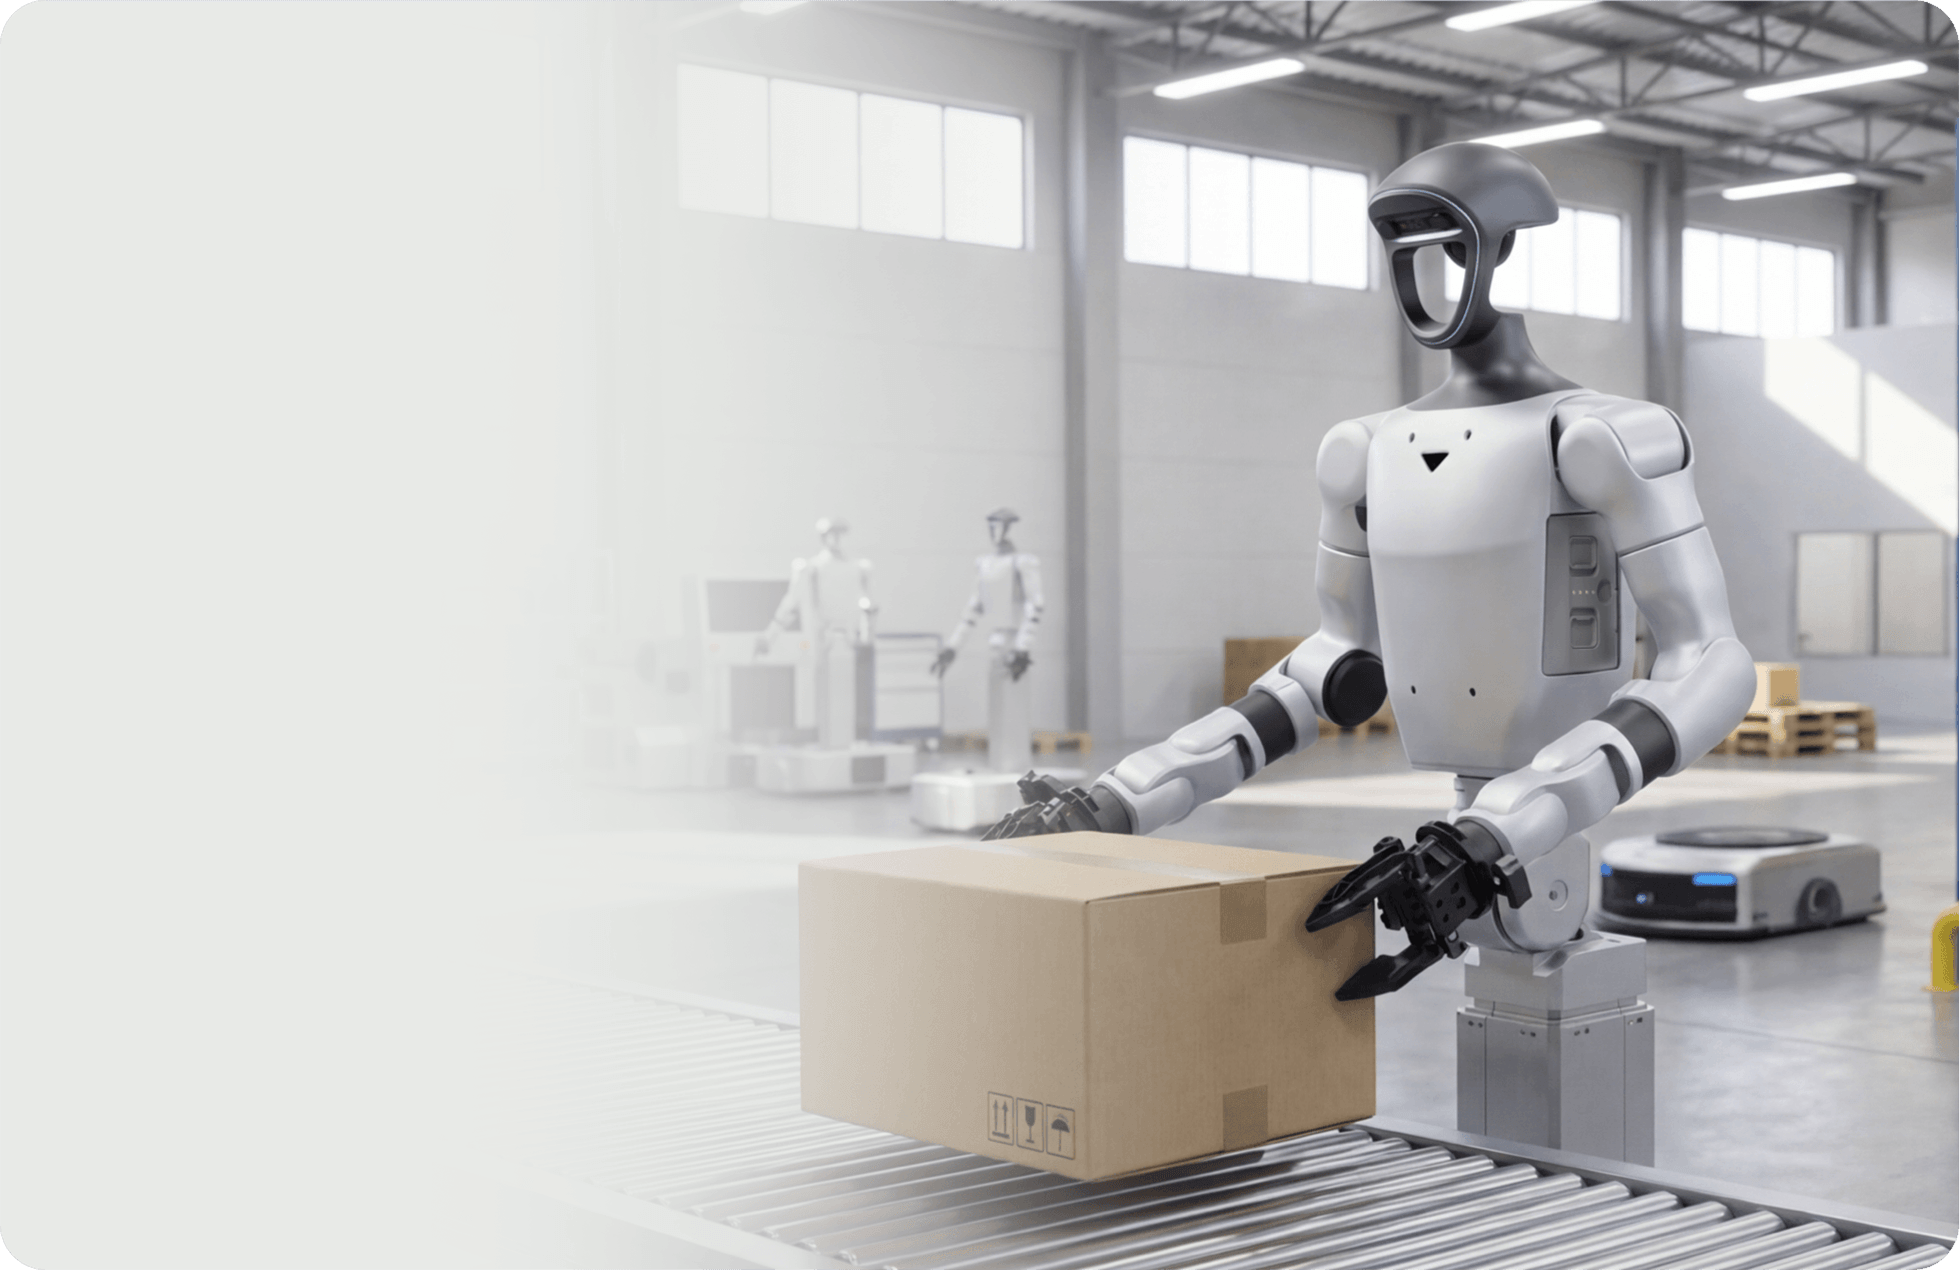
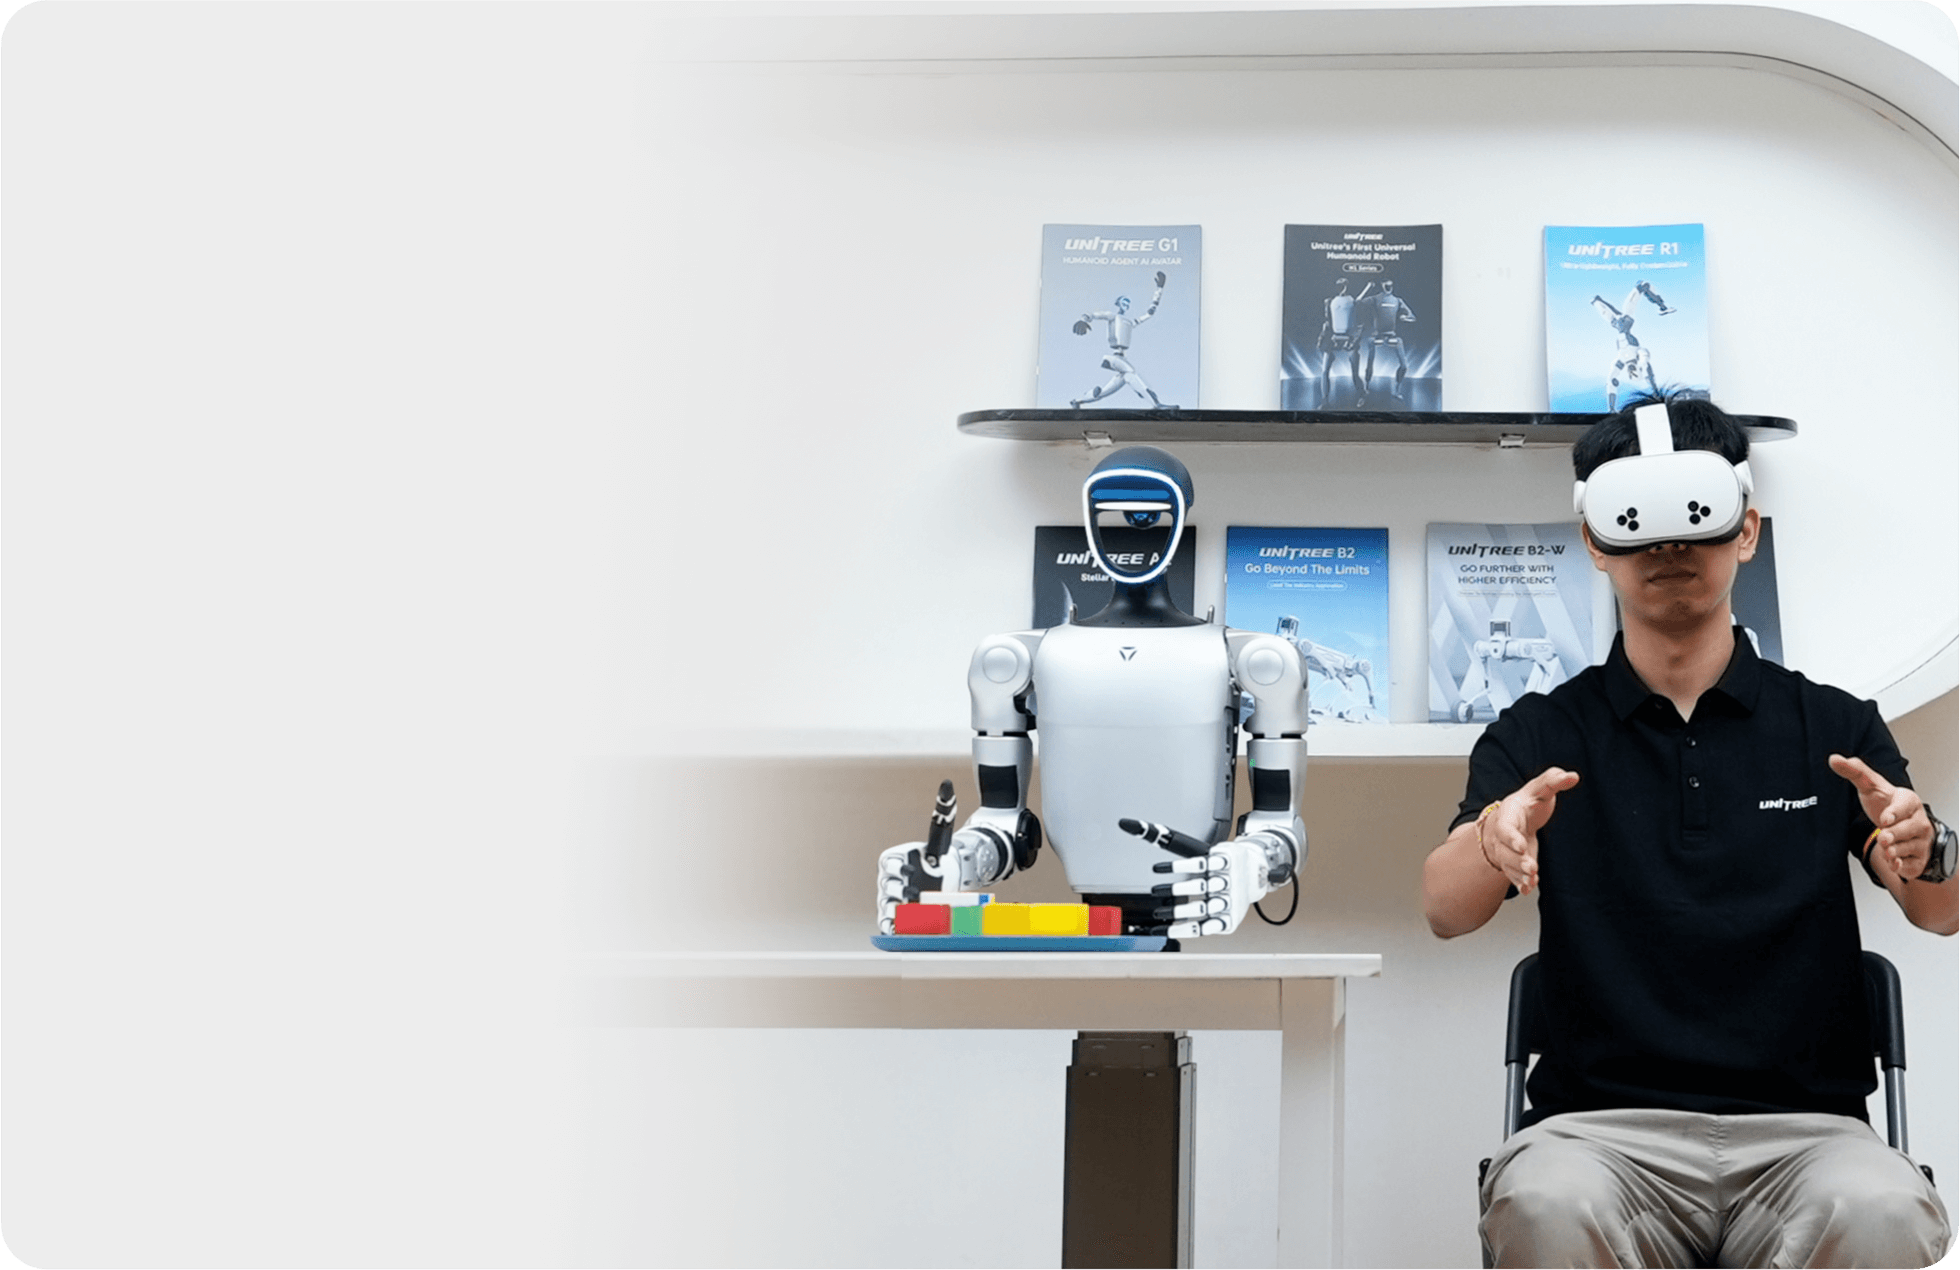
- Expanded Operational Workspace
- Lower-Latency Control Response
Streamlined Data Acquisition Tools
Standardized, flexible workflows cut collection costs and replace manual processes.
Visual Template Management for Efficient Collection
Project management, task allocation, progress tracking and status analysis in one platform. Templates generate collection tasks in one click, and the whole workflow can be tracked in real time.
Flexible Configurations with Diverse Platforms & End Effectors
Data can be collected across many robot platforms and end-effector configurations, and strong standardization turns data from varied devices into quality model training data.
High-Concurrency Architecture for Scalable Operations
Built for many robots collecting at once, with load-balanced scheduling that receives and processes large data streams in real time.
24/7 Online Collection, Stable and Reliable
A highly available service architecture supports round-the-clock collection, and broad format compatibility lets data be exported directly or converted to mainstream training formats, speeding up R&D.
Data Acquisition Pipeline
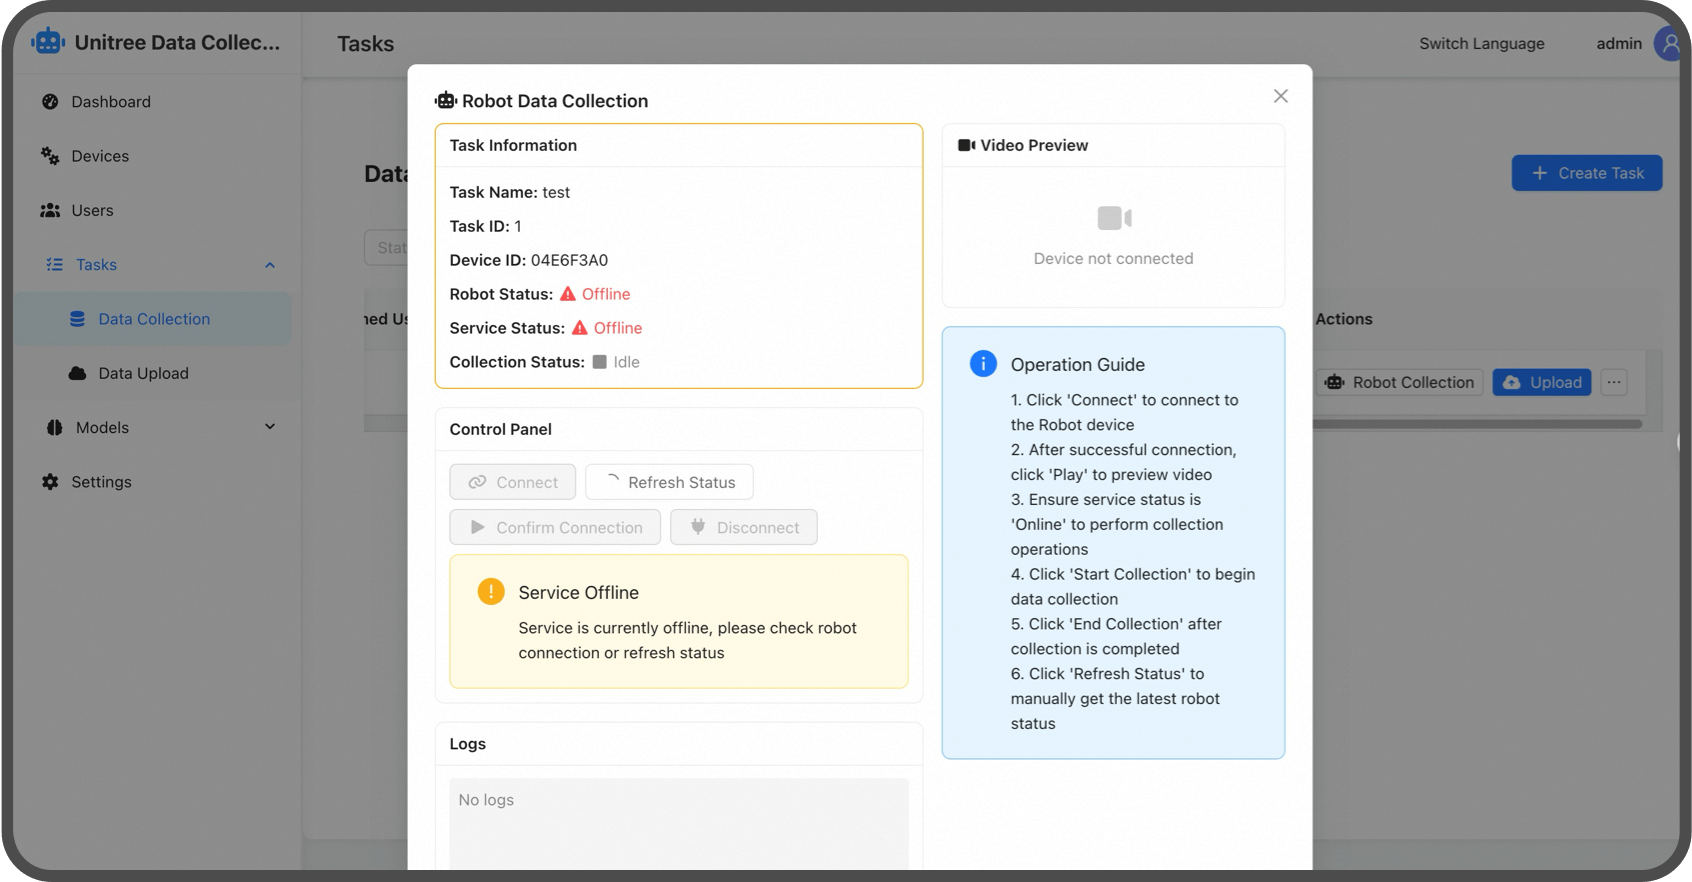
Creating New Collection Tasks
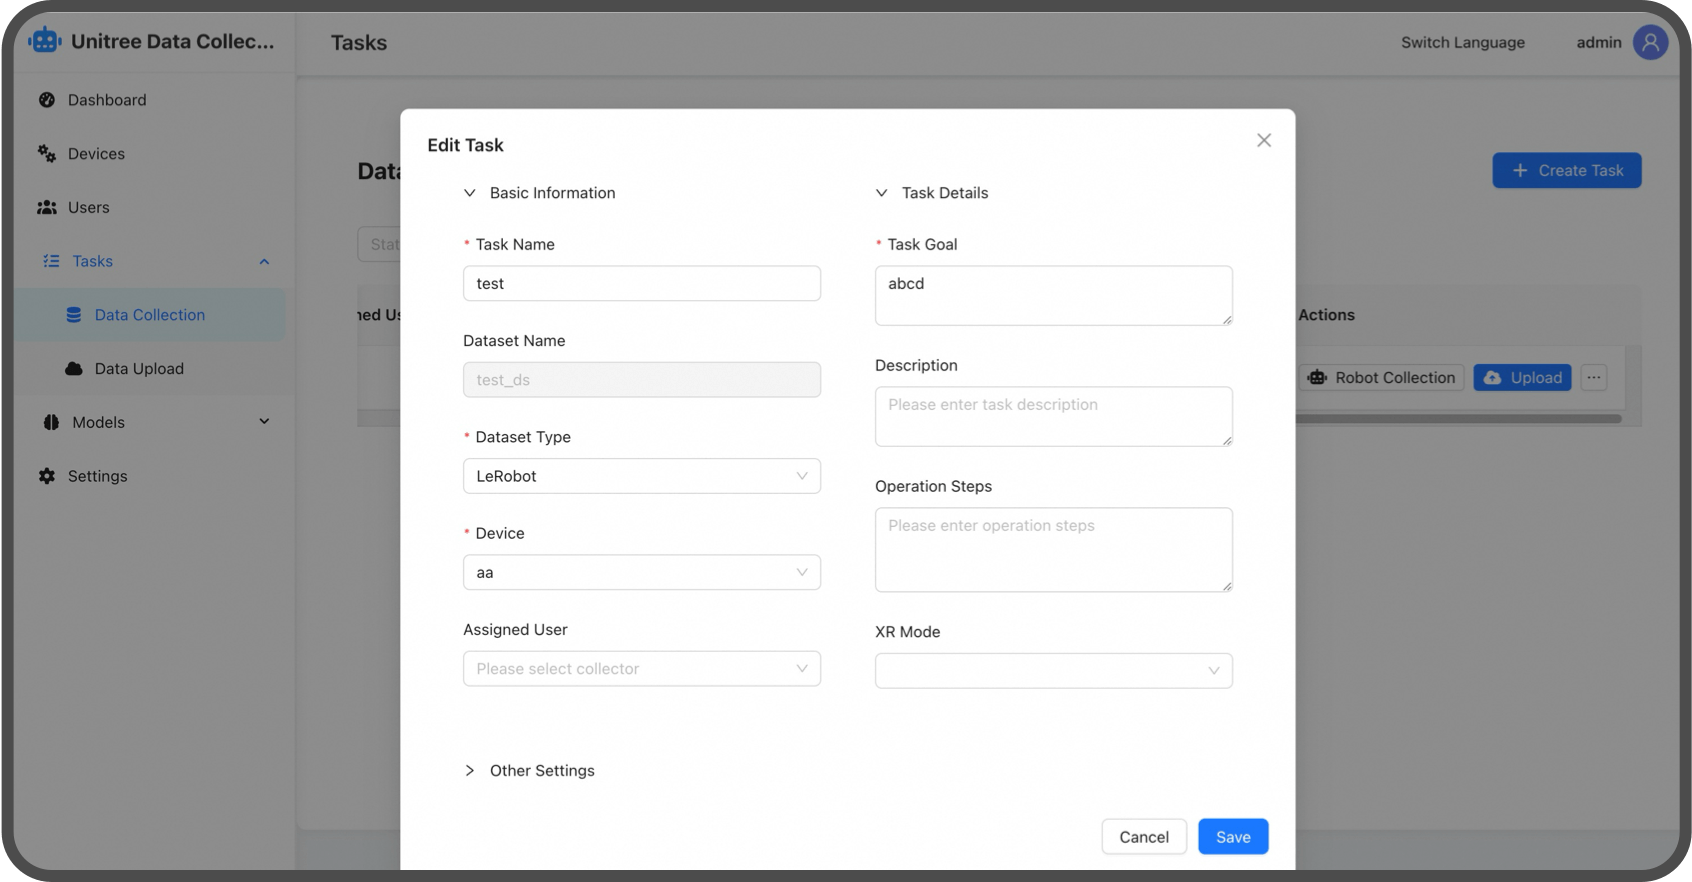
Task Editing and Assignment
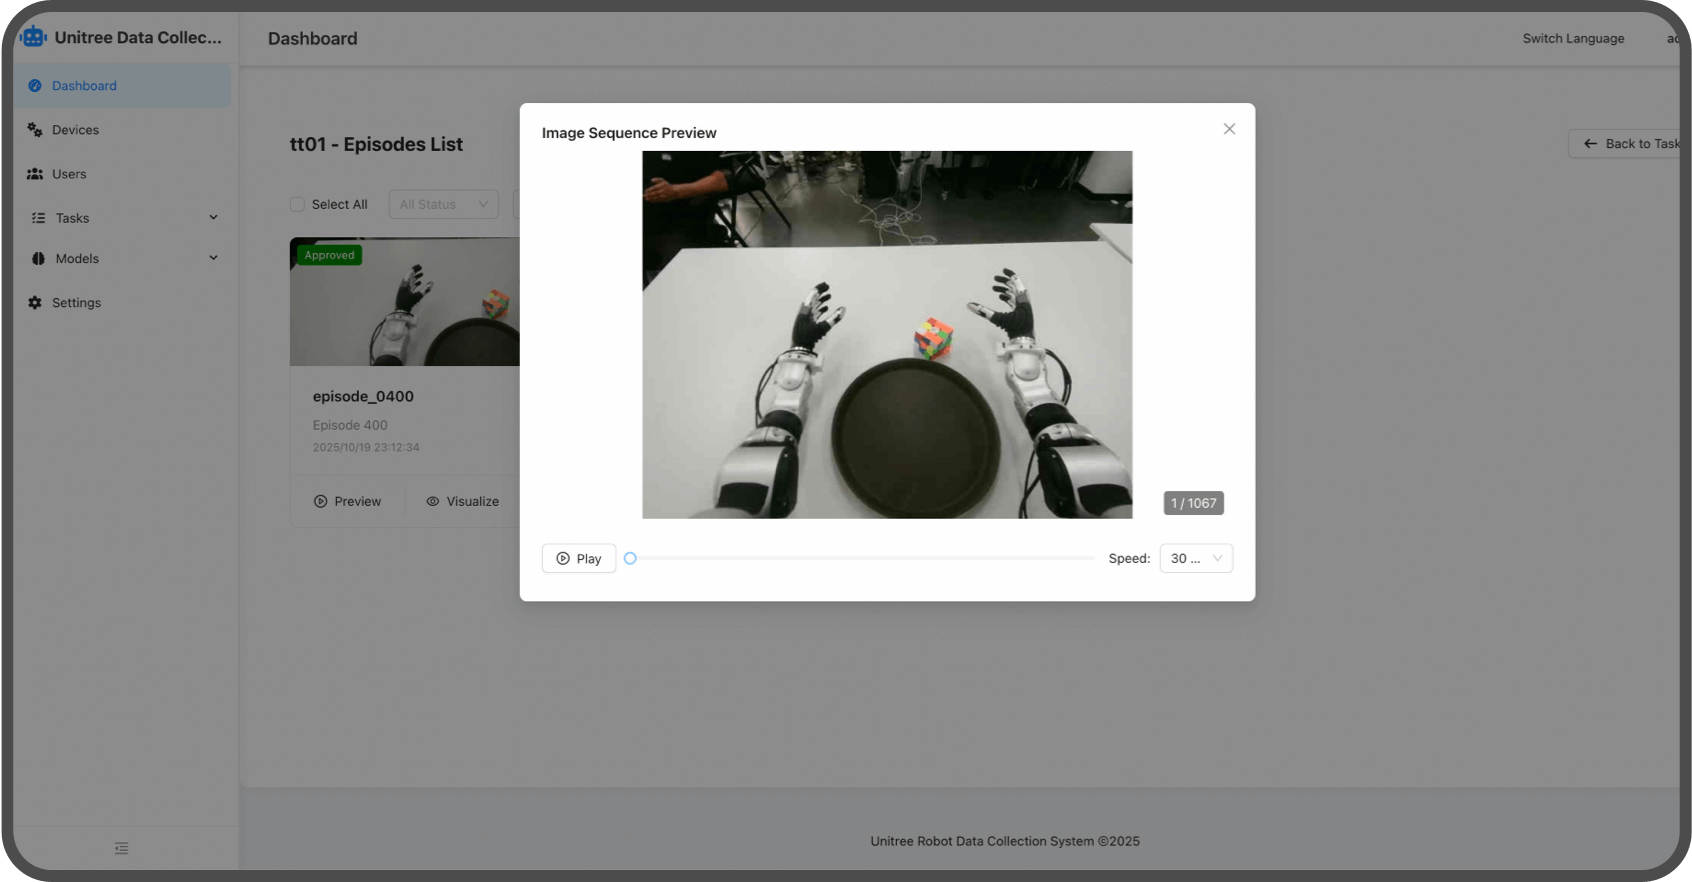
Data Acquisition and Annotation
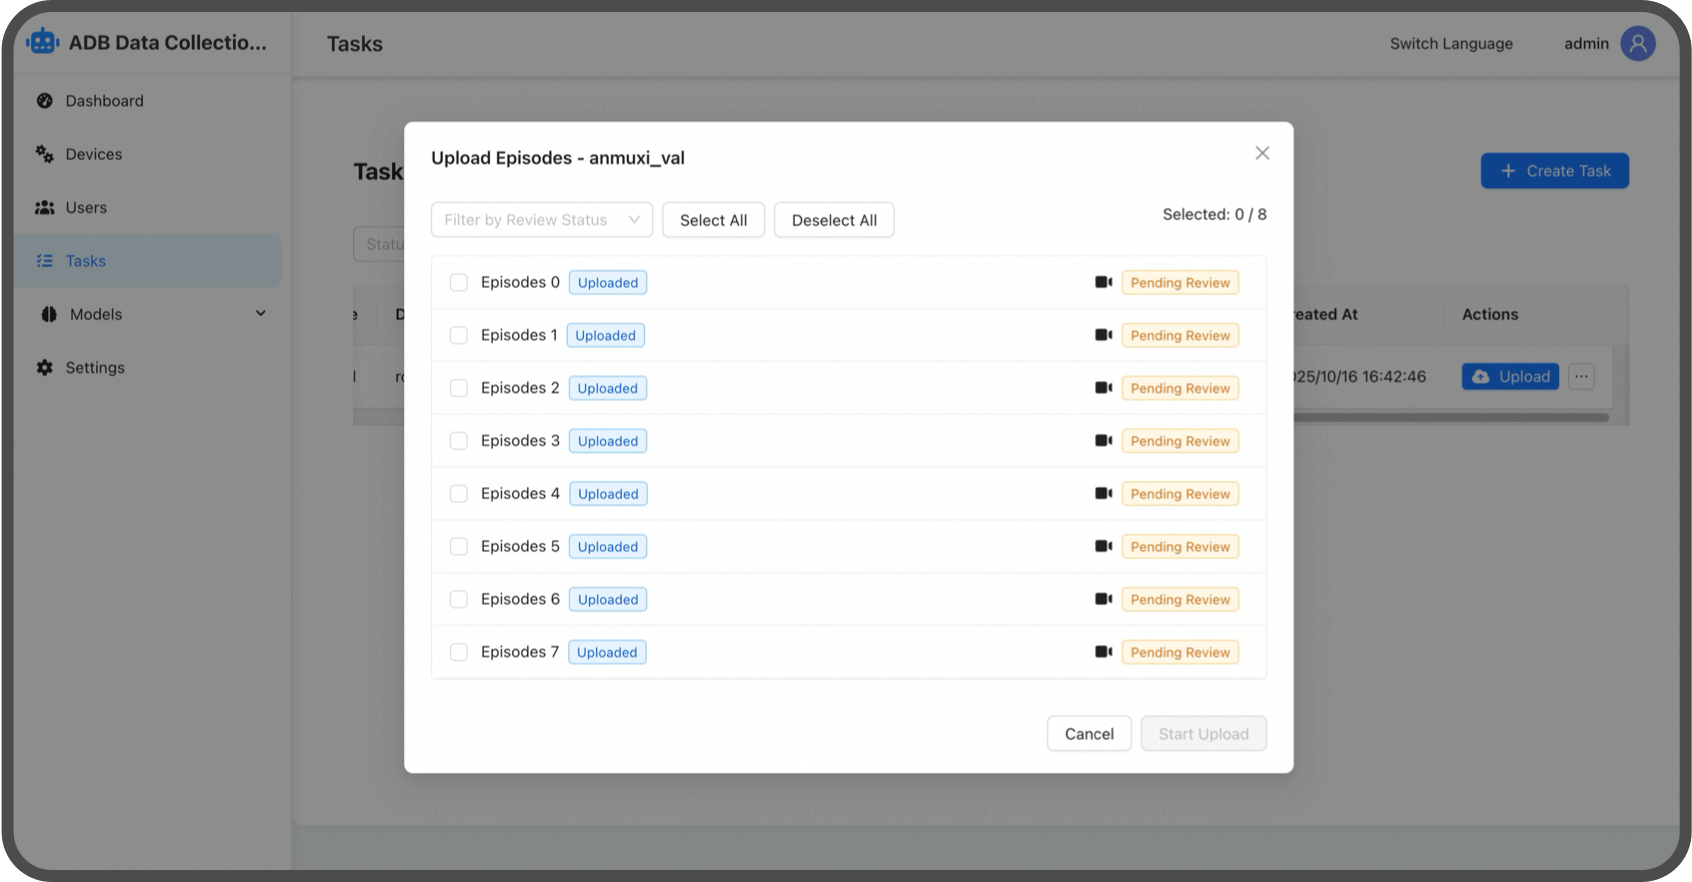
Data Upload and Review
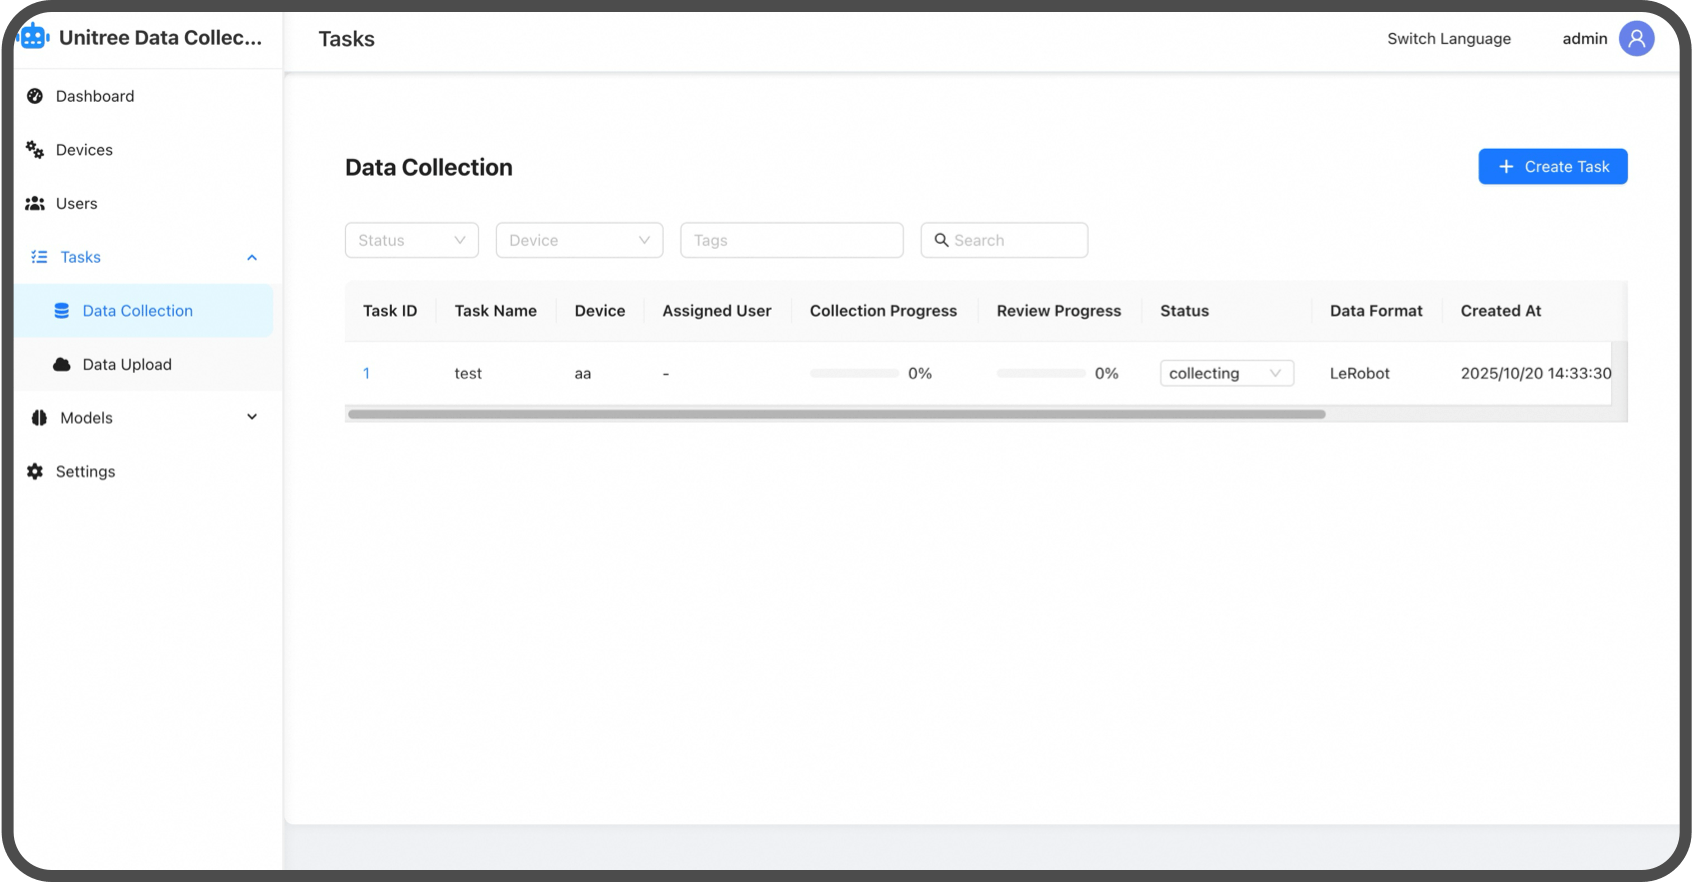
Data Storage
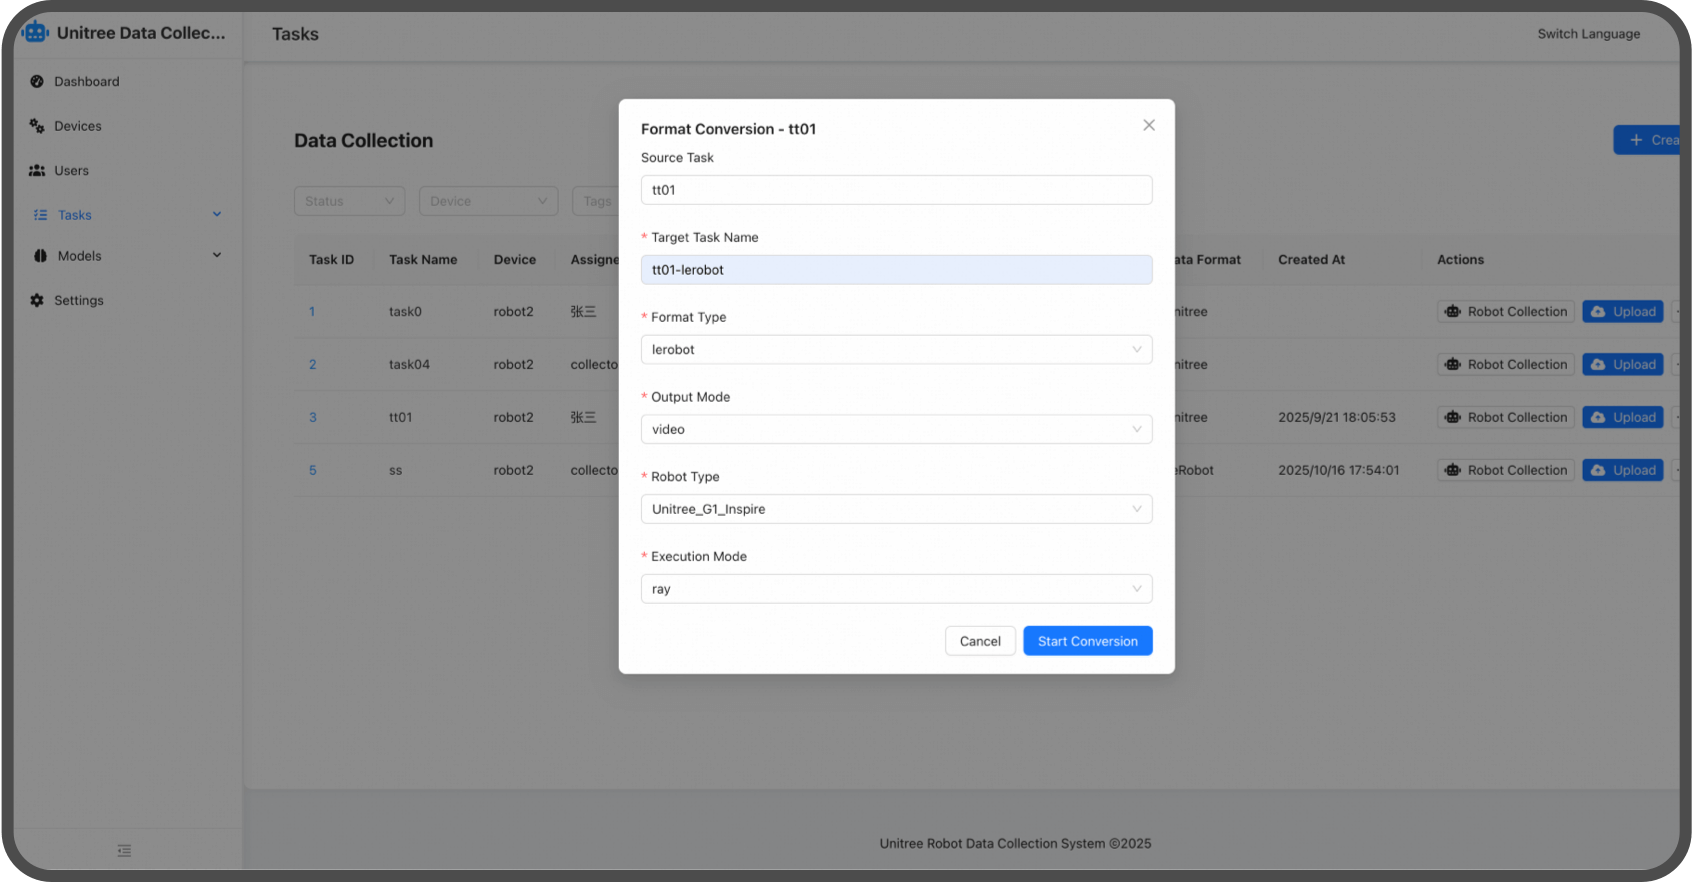
Data Export
Comprehensive Model Training & Inference Tools
An end-to-end workflow from data processing to one-click model deployment, integrating mainstream open-source robot model frameworks.
Rich Ecosystem with Mainstream Model Support
An open model ecosystem with built-in community datasets, open-source dataset training and deep integration with leading open models such as PI and GROOT.
Simulation Environment for Model Evaluation
A high-fidelity 3D asset library for building realistic simulations and quickly generating evaluation plans to validate algorithms.
User-Friendly Design for Rapid Deployment
Deploys out of the box. Start model development with one-click training, evaluate with built-in simulation, and move algorithms onto real machines smoothly.
Distributed Training for High Efficiency
A high-performance distributed architecture with elastic scheduling and parallel acceleration that scales with workload, reaching up to 90% GPU utilization.
Training and Inference Pipeline
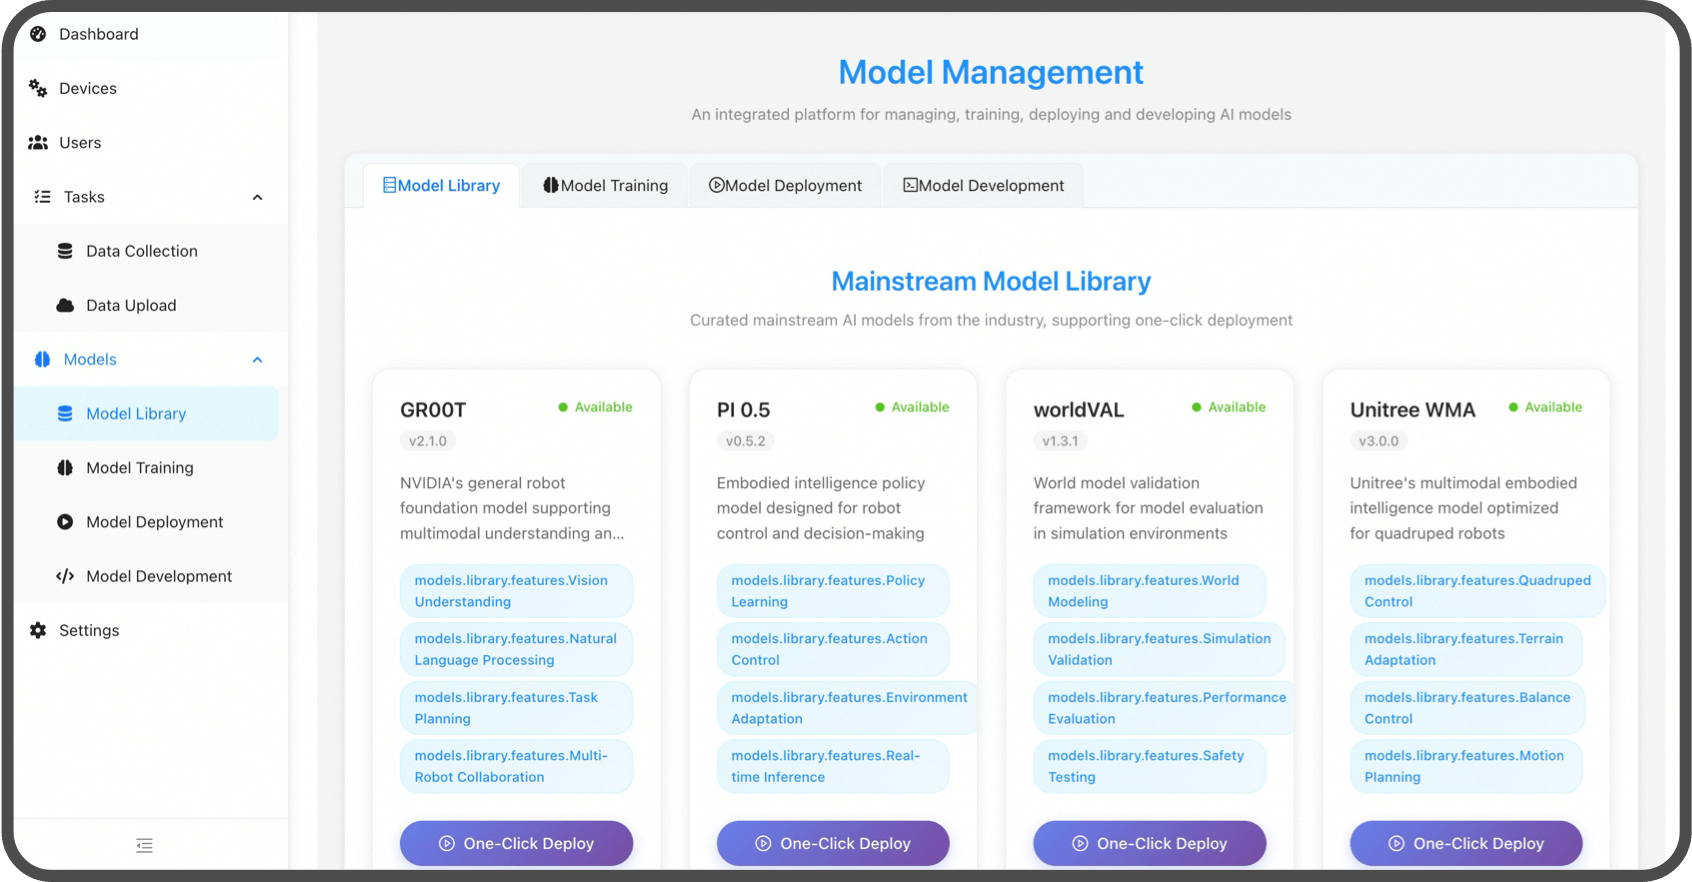
Model Architecture Selection
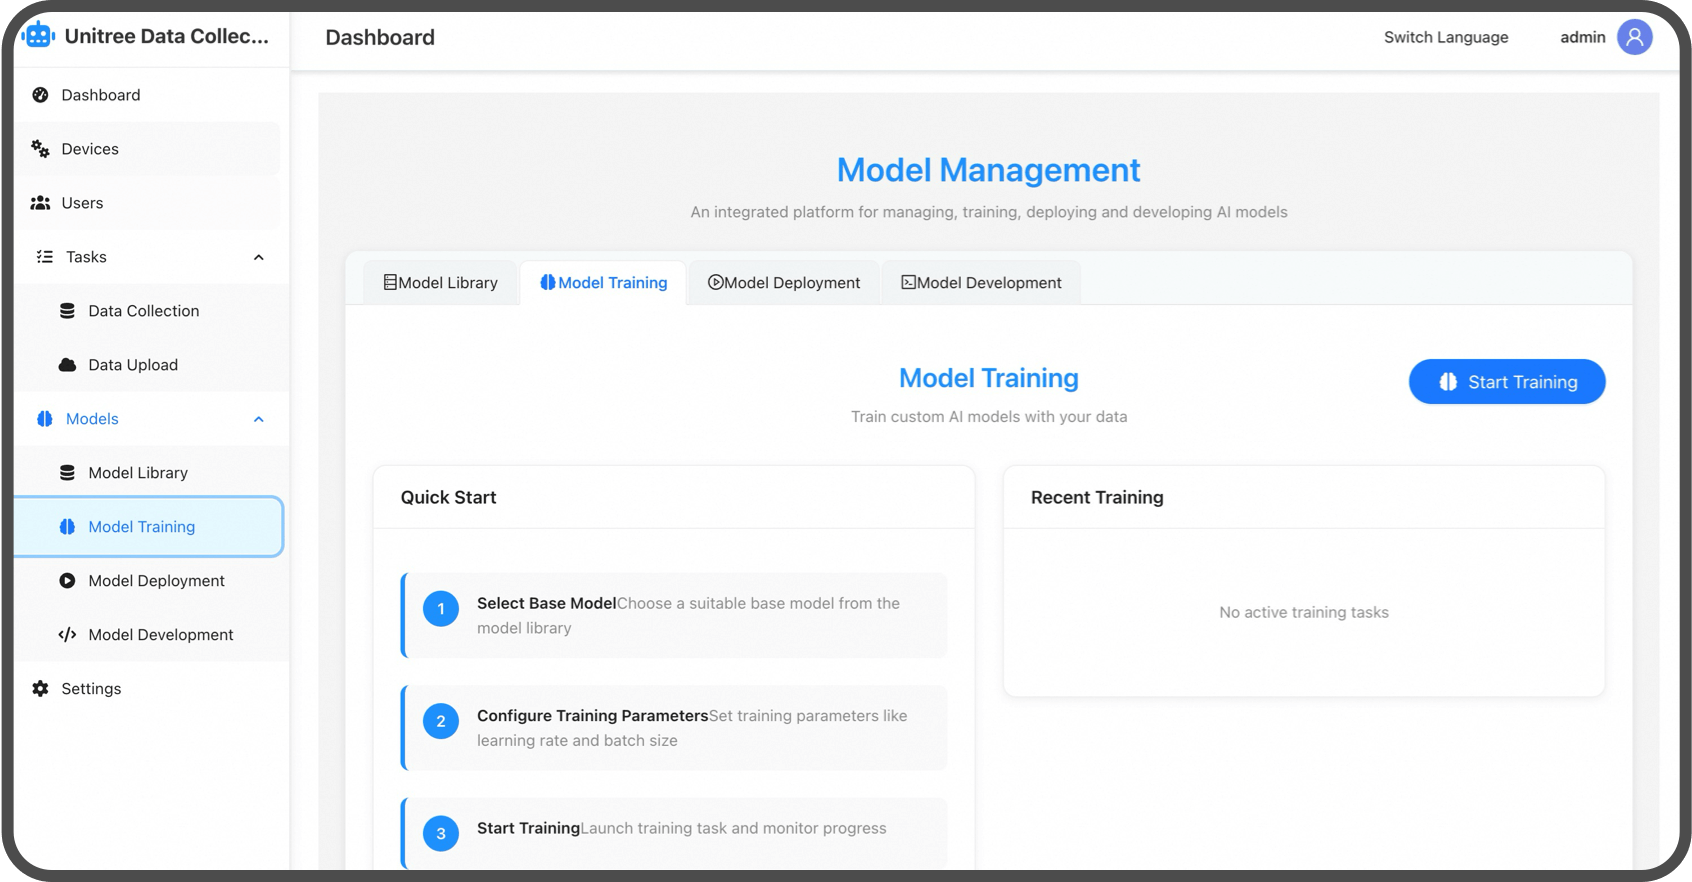
Training Configuration
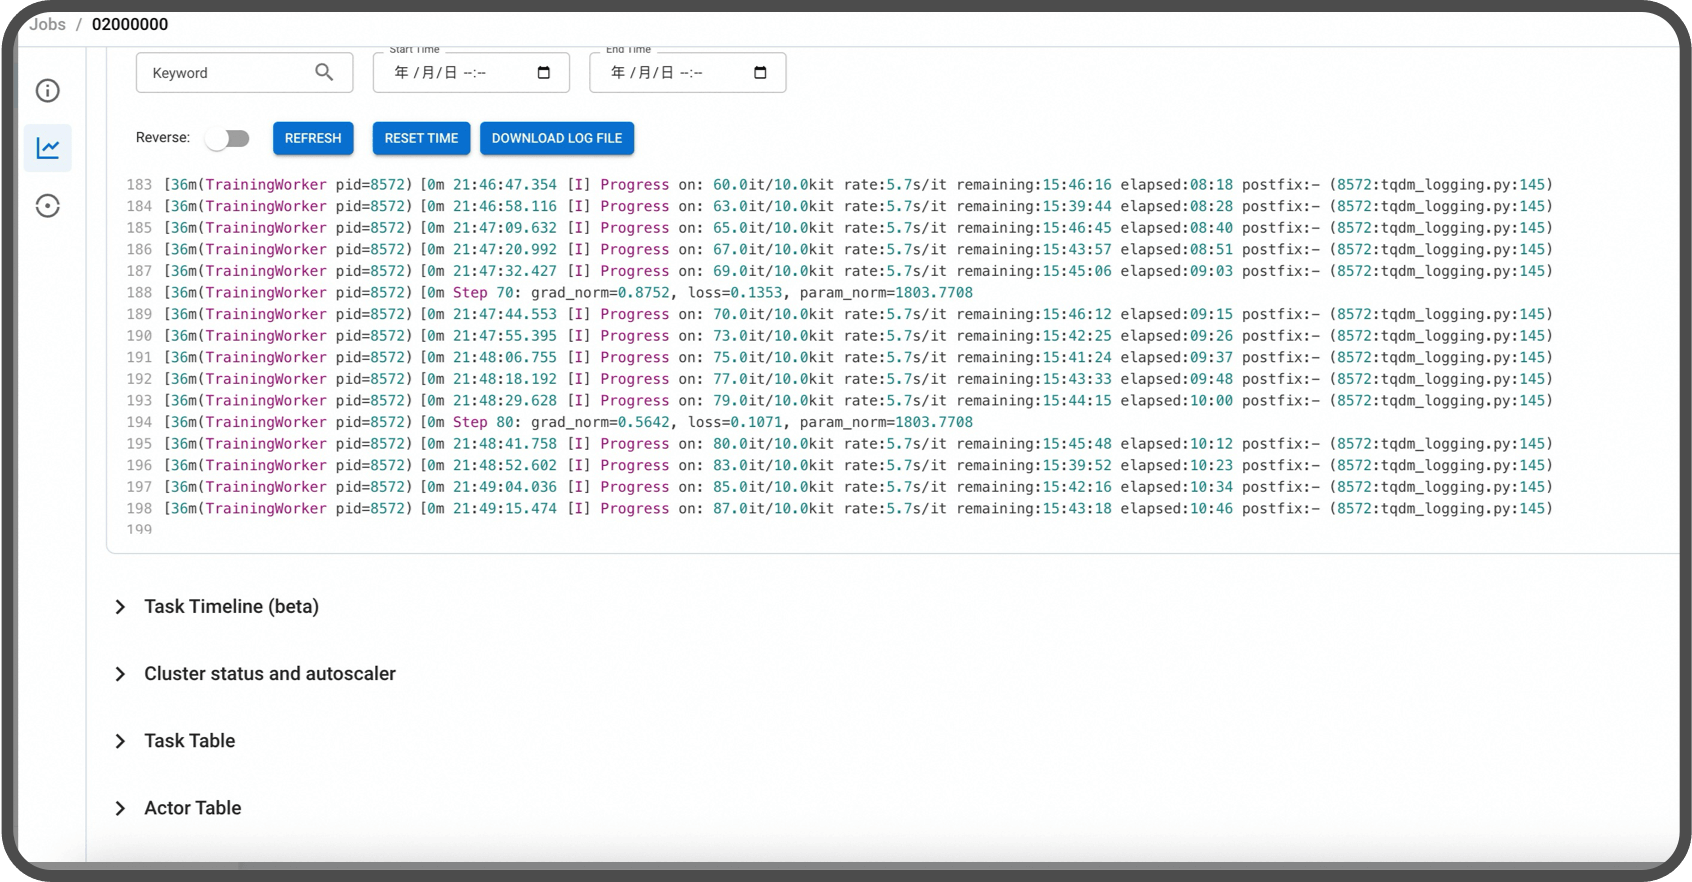
Real-Time Monitoring
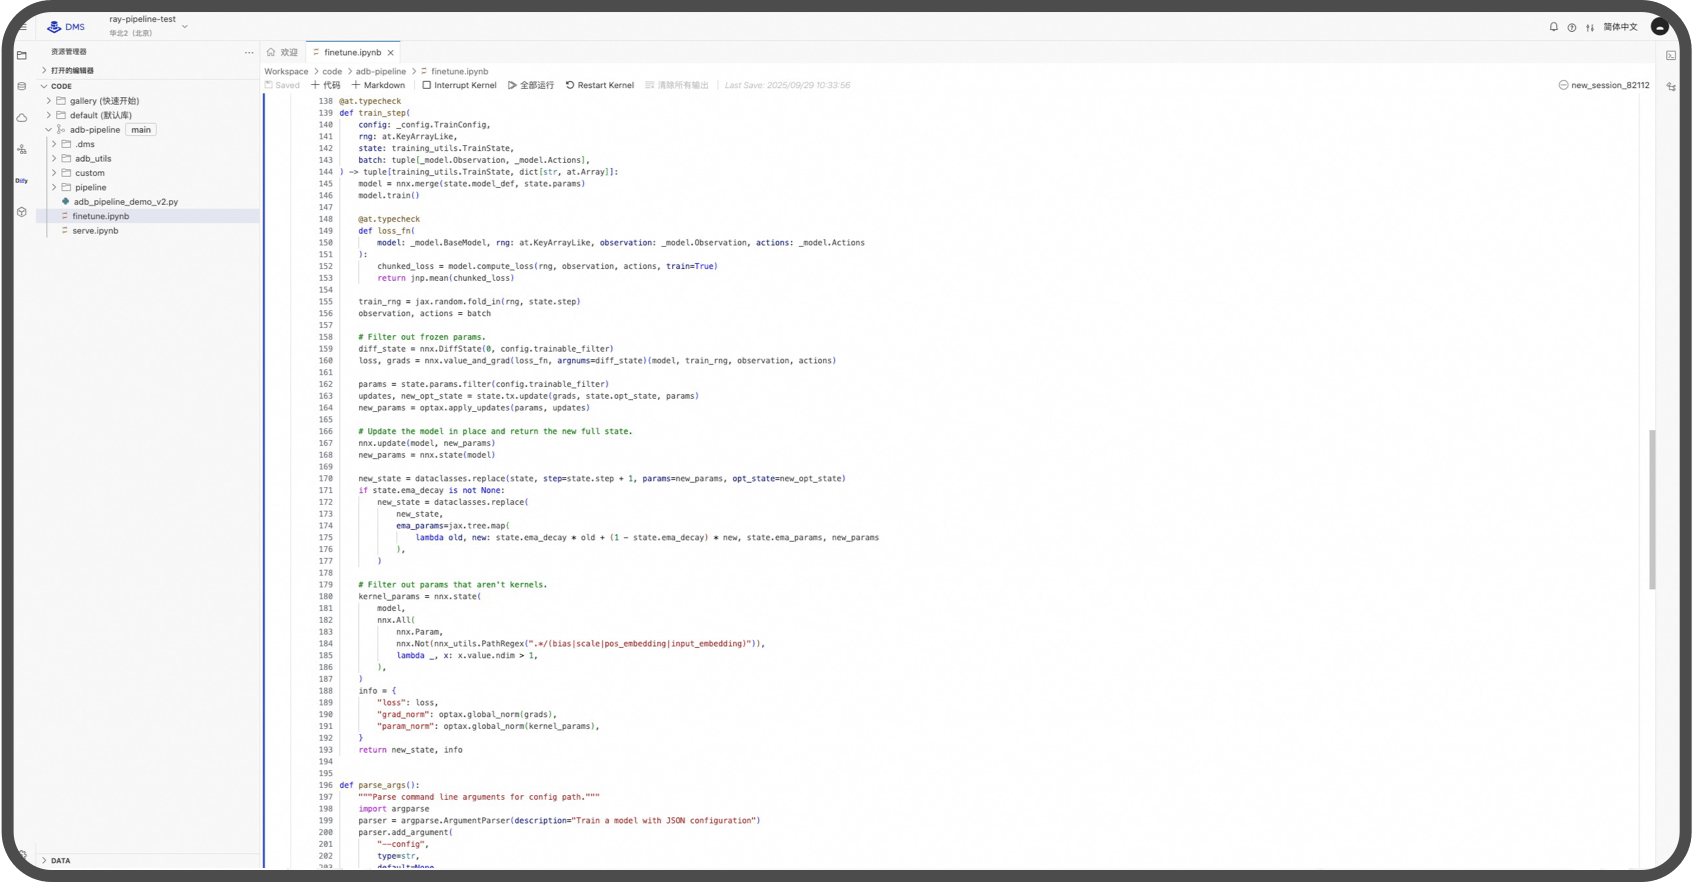
Parameter Editing
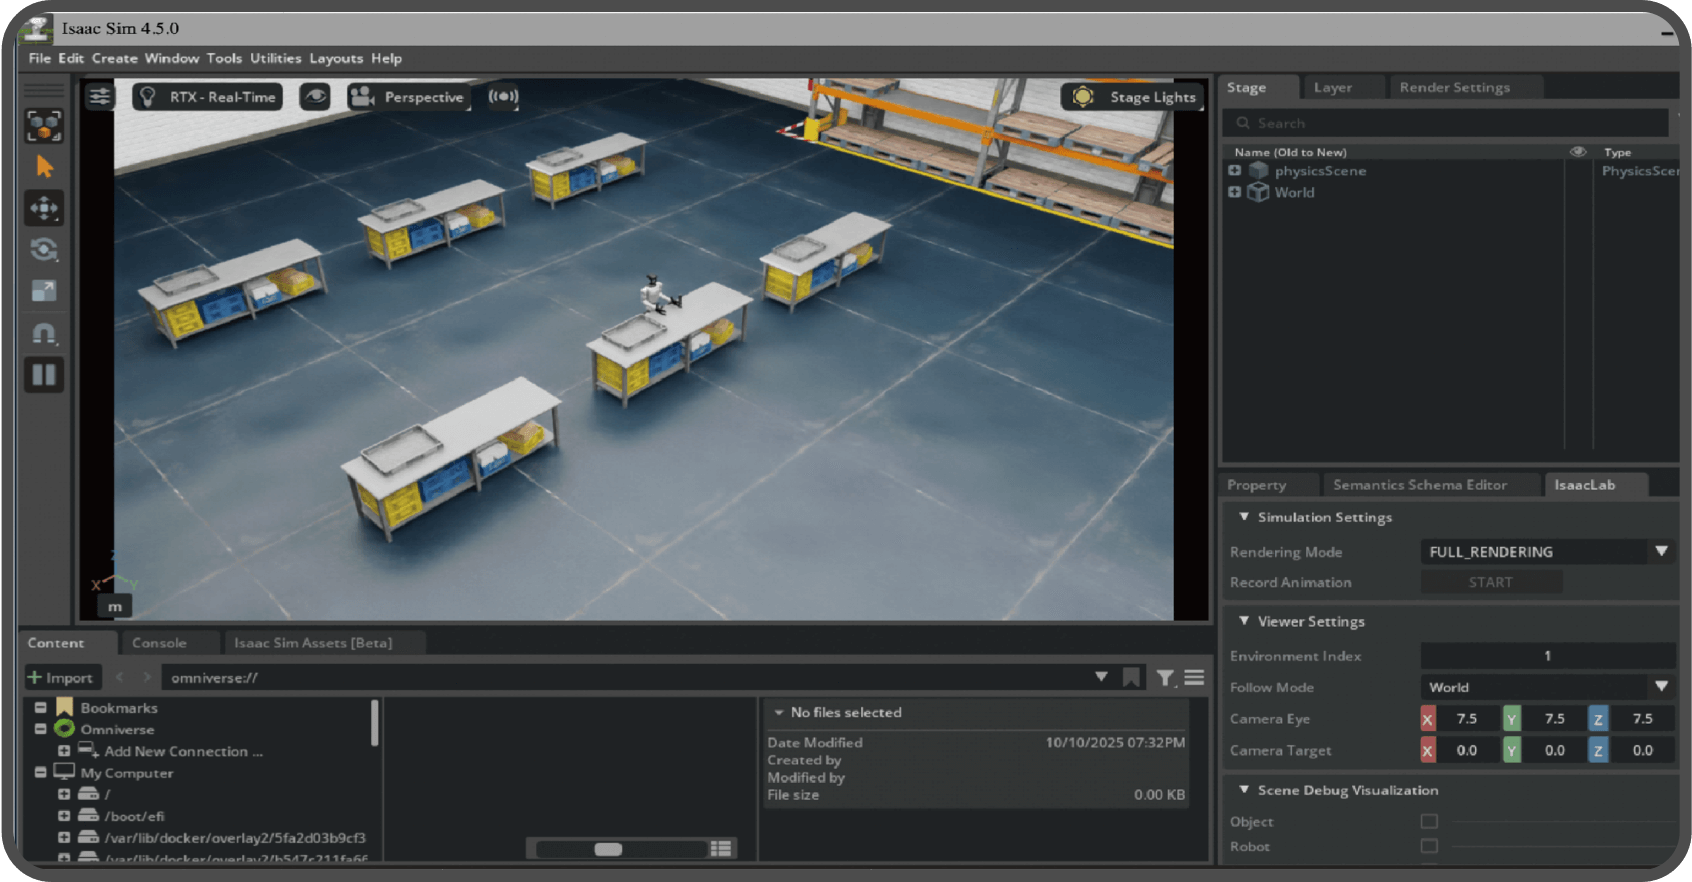
Simulation Testing
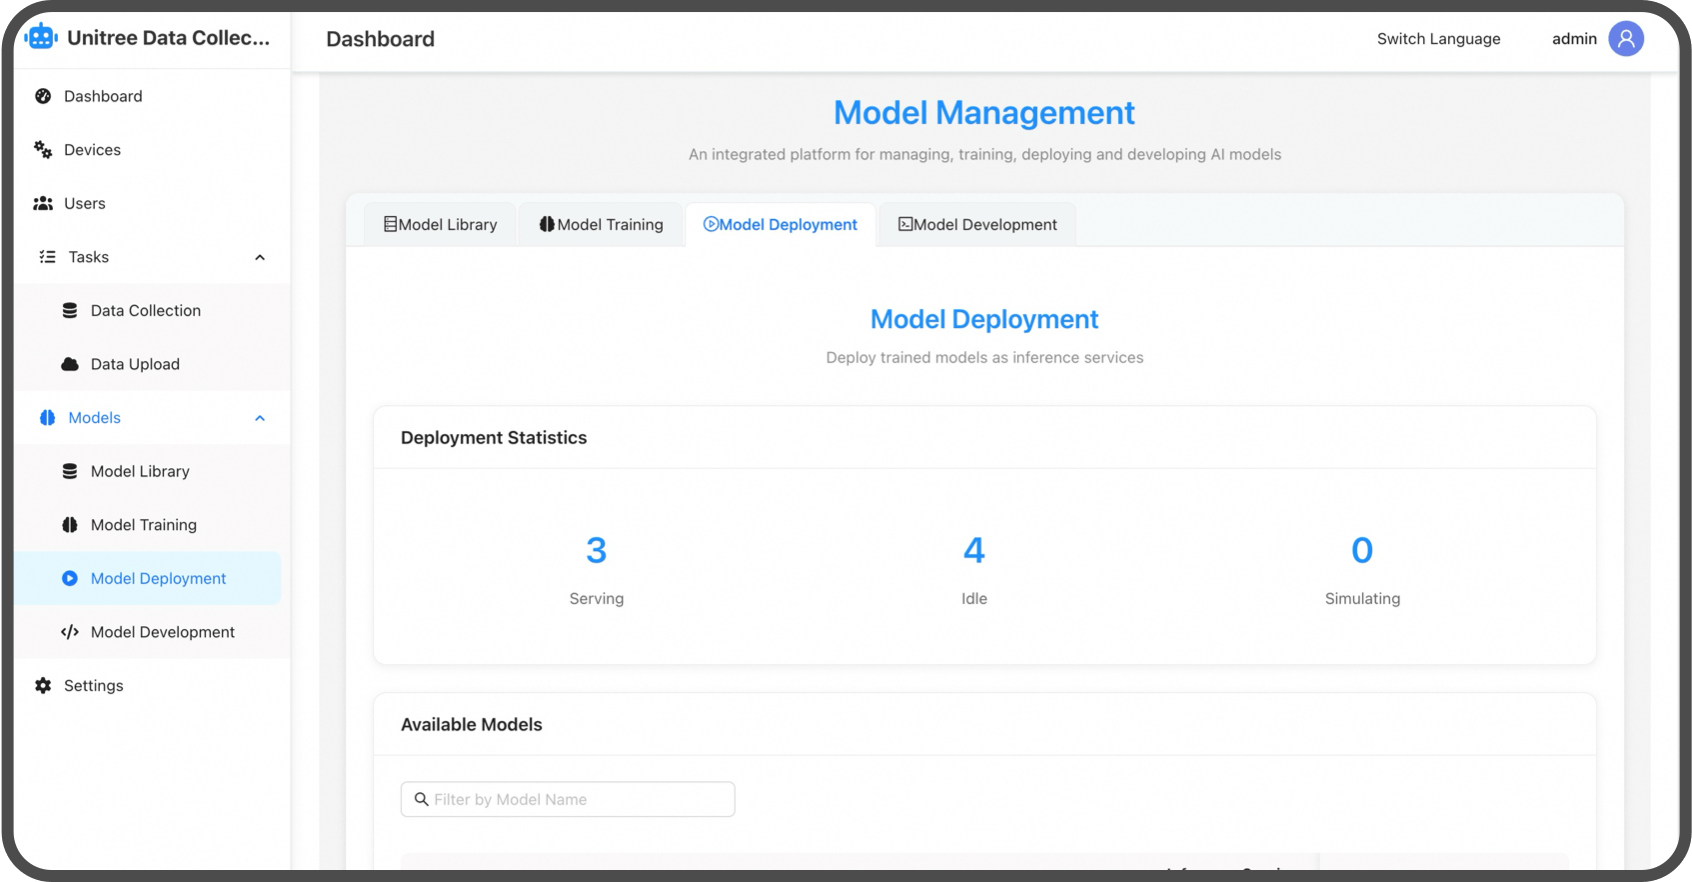
Model Export & Deployment
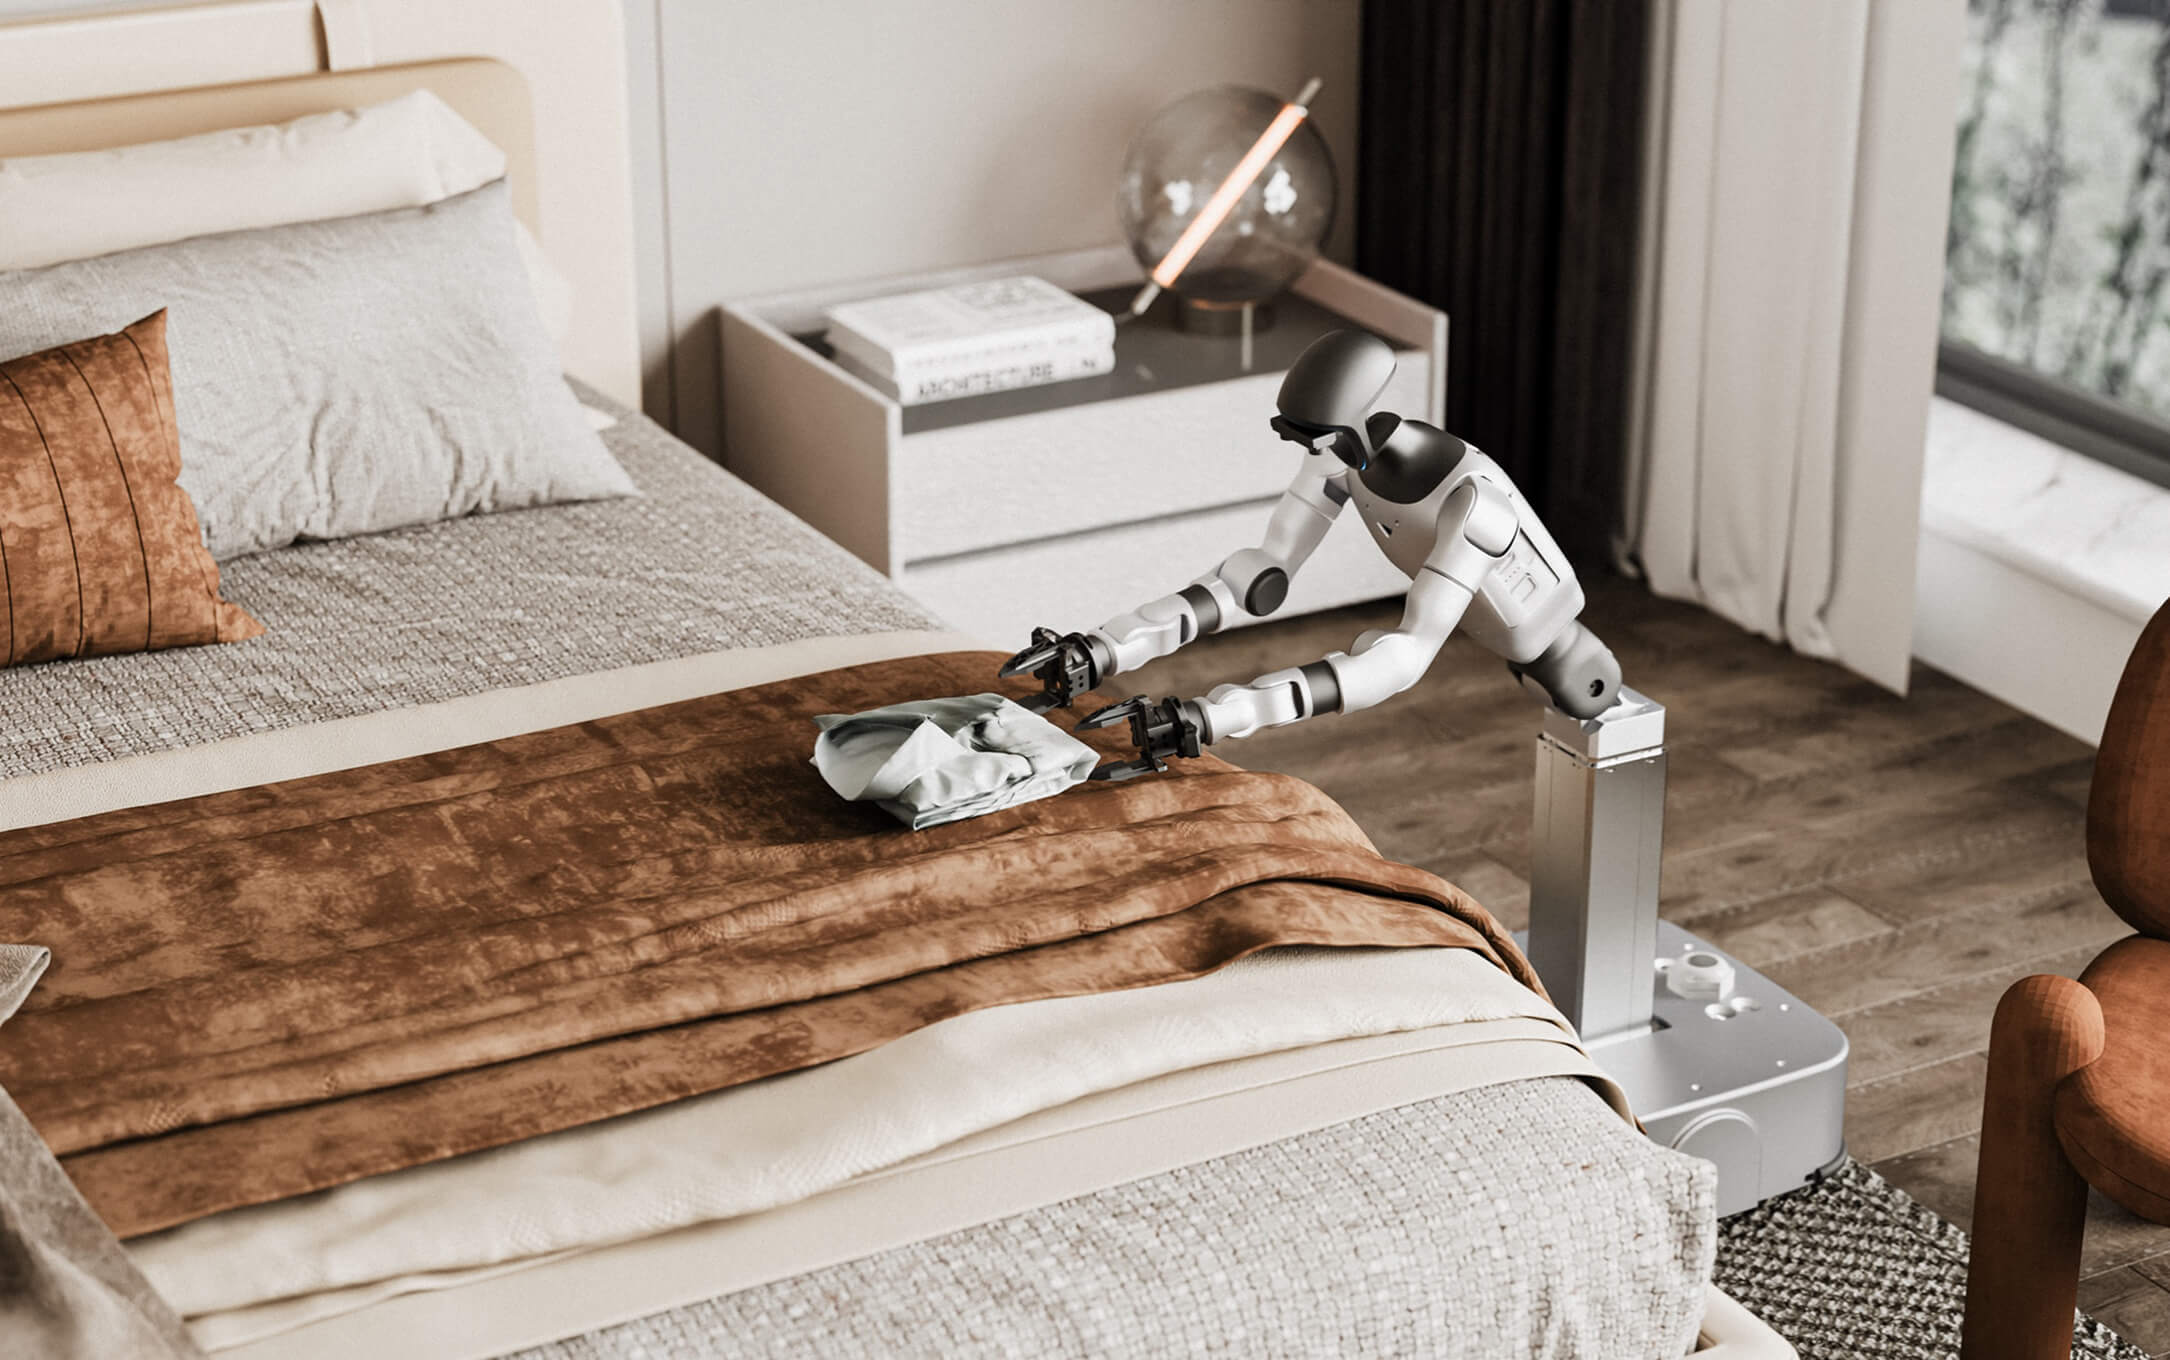
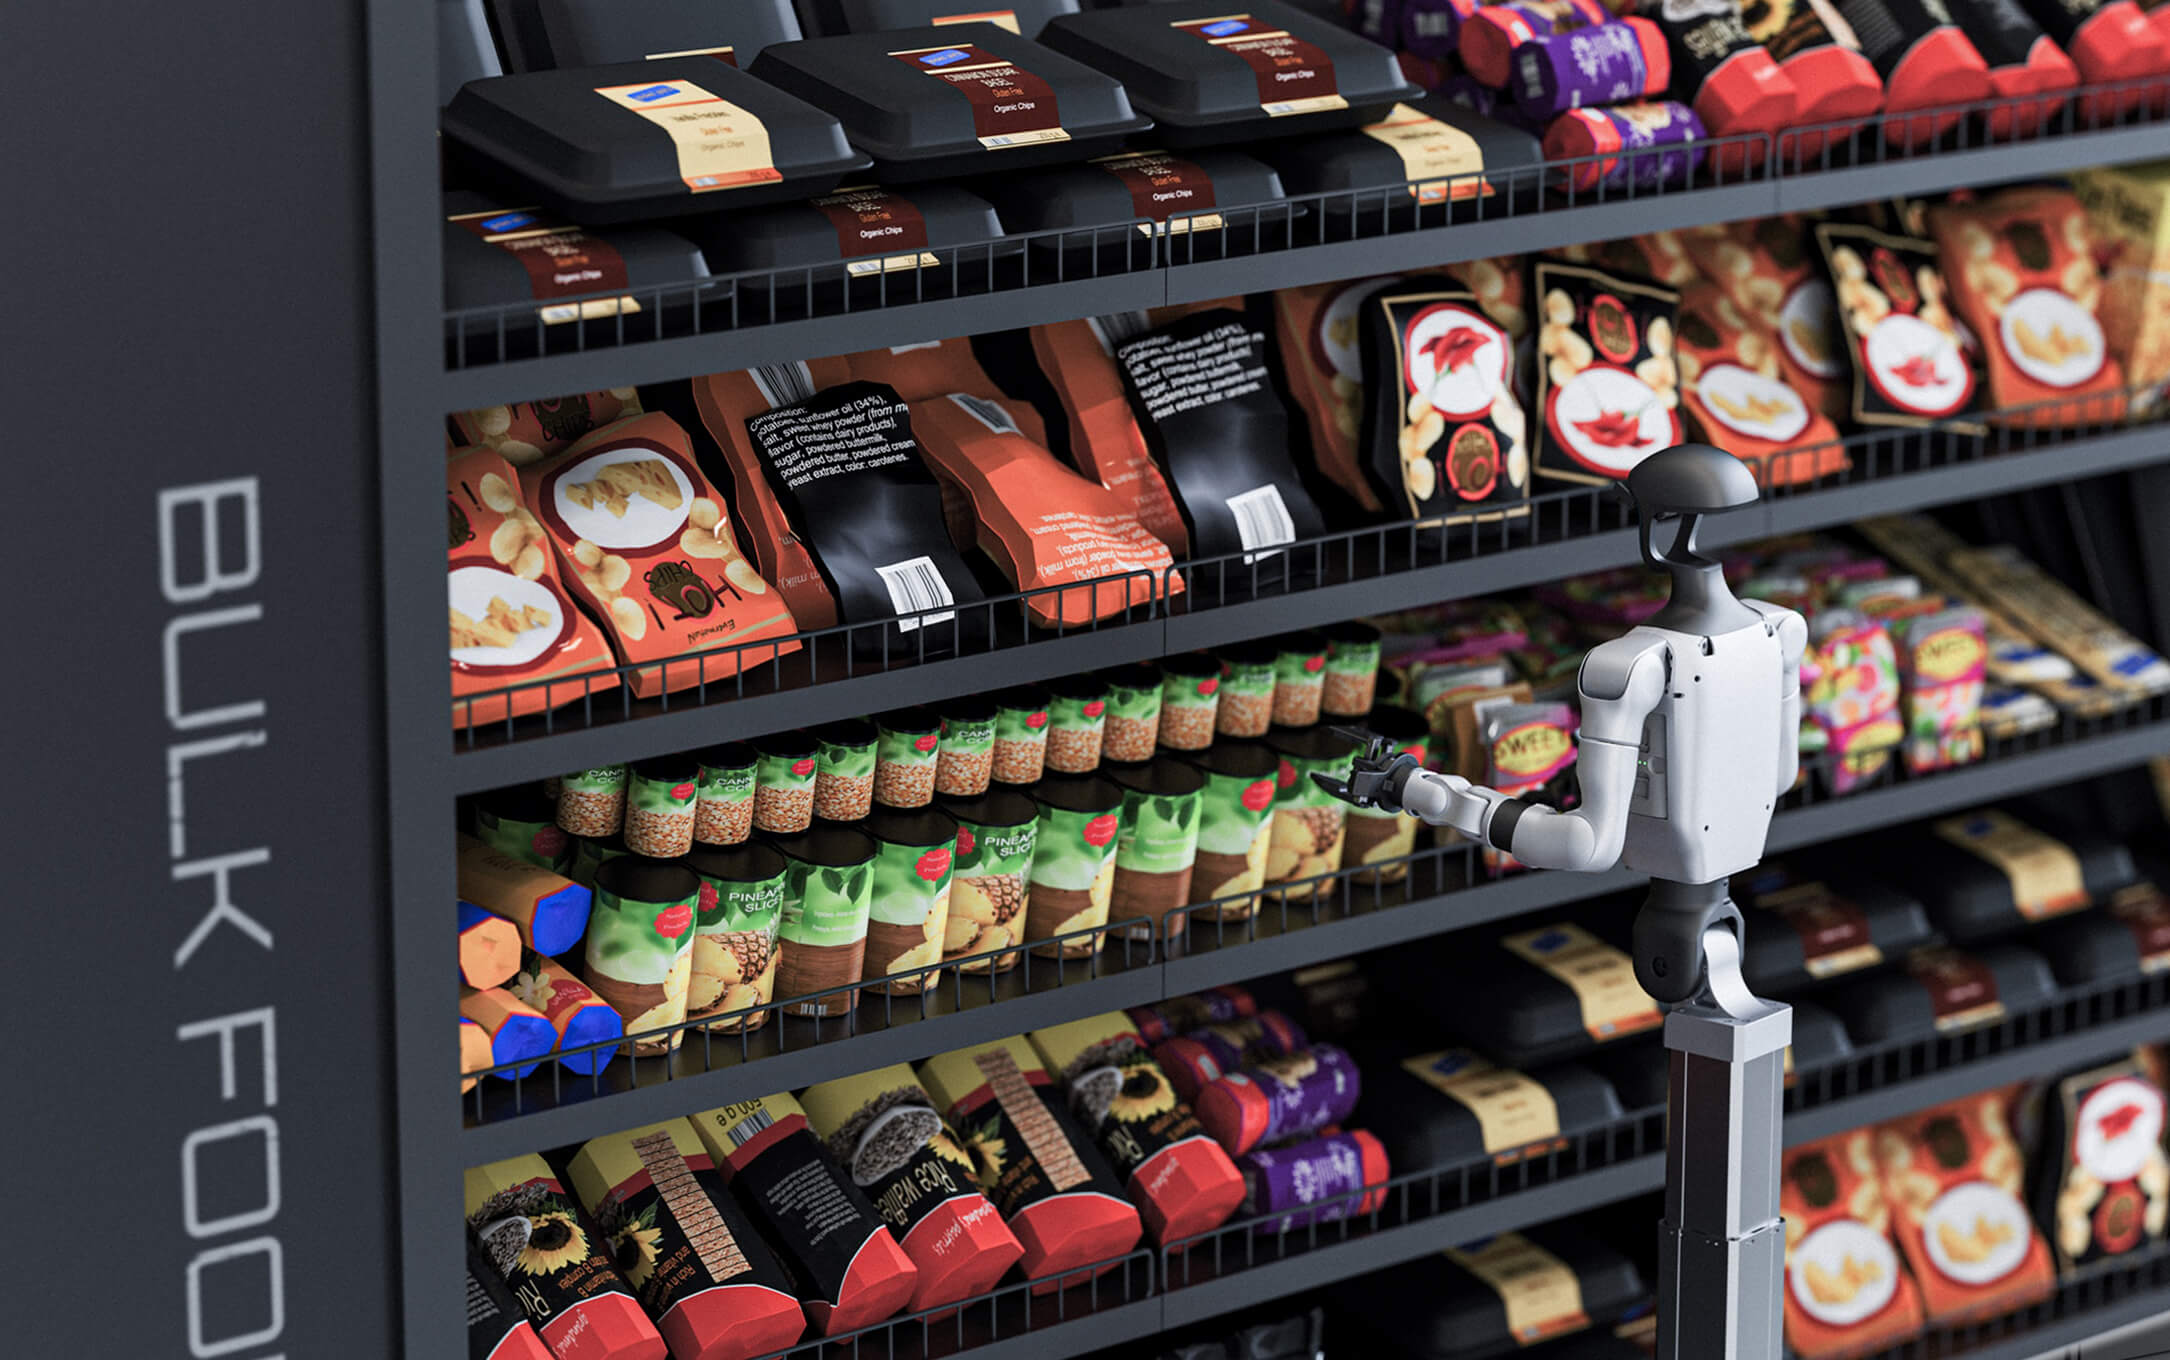
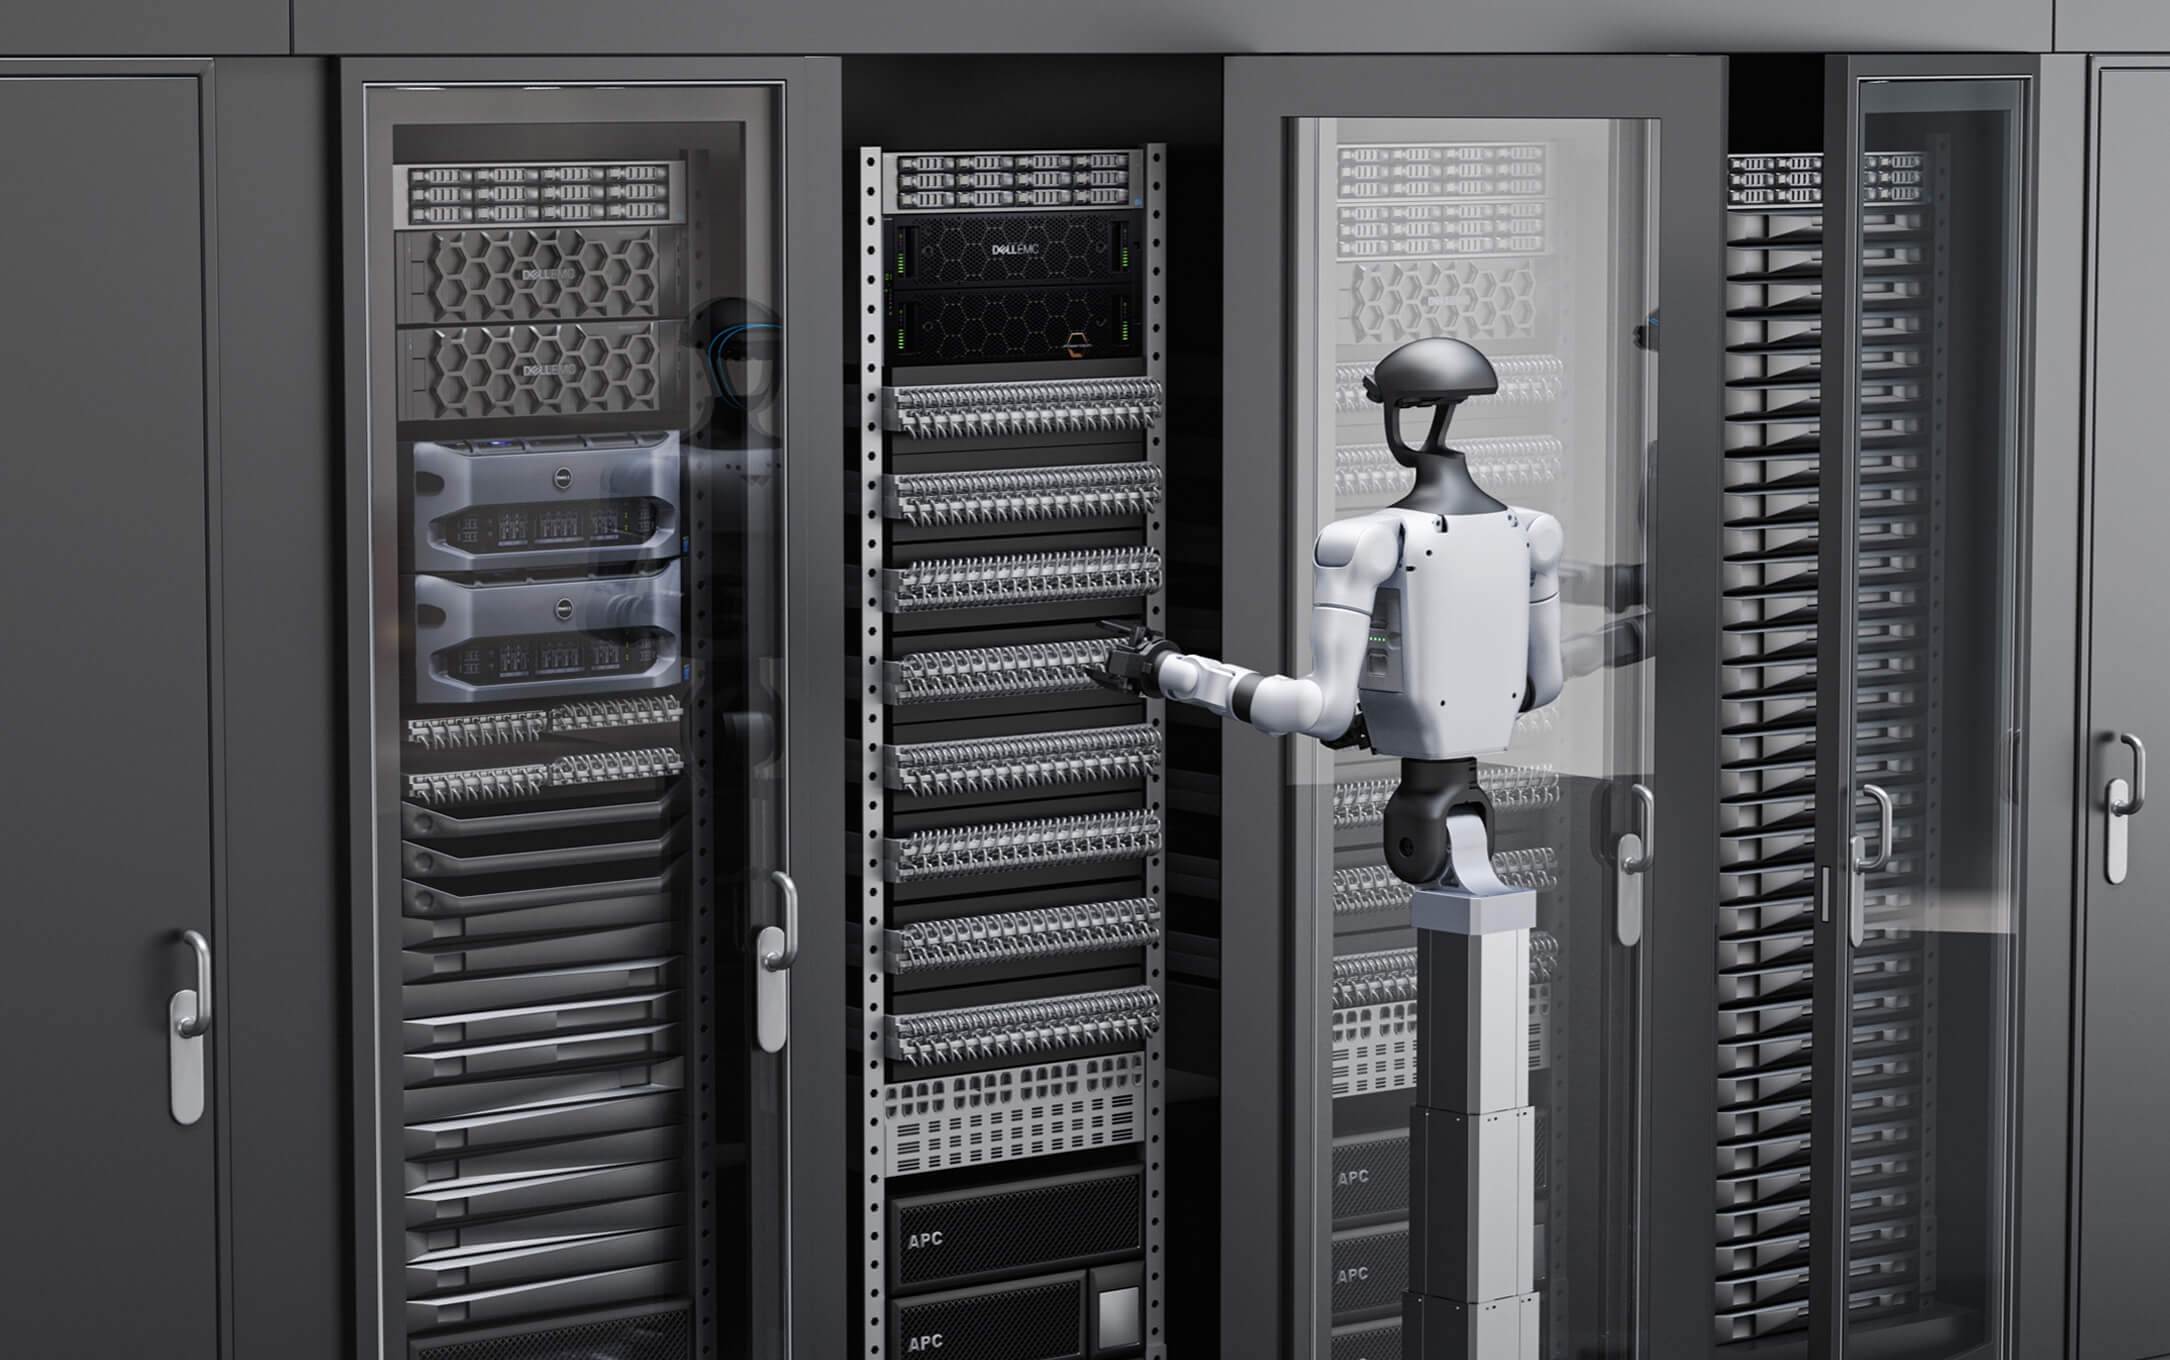
Application scenario
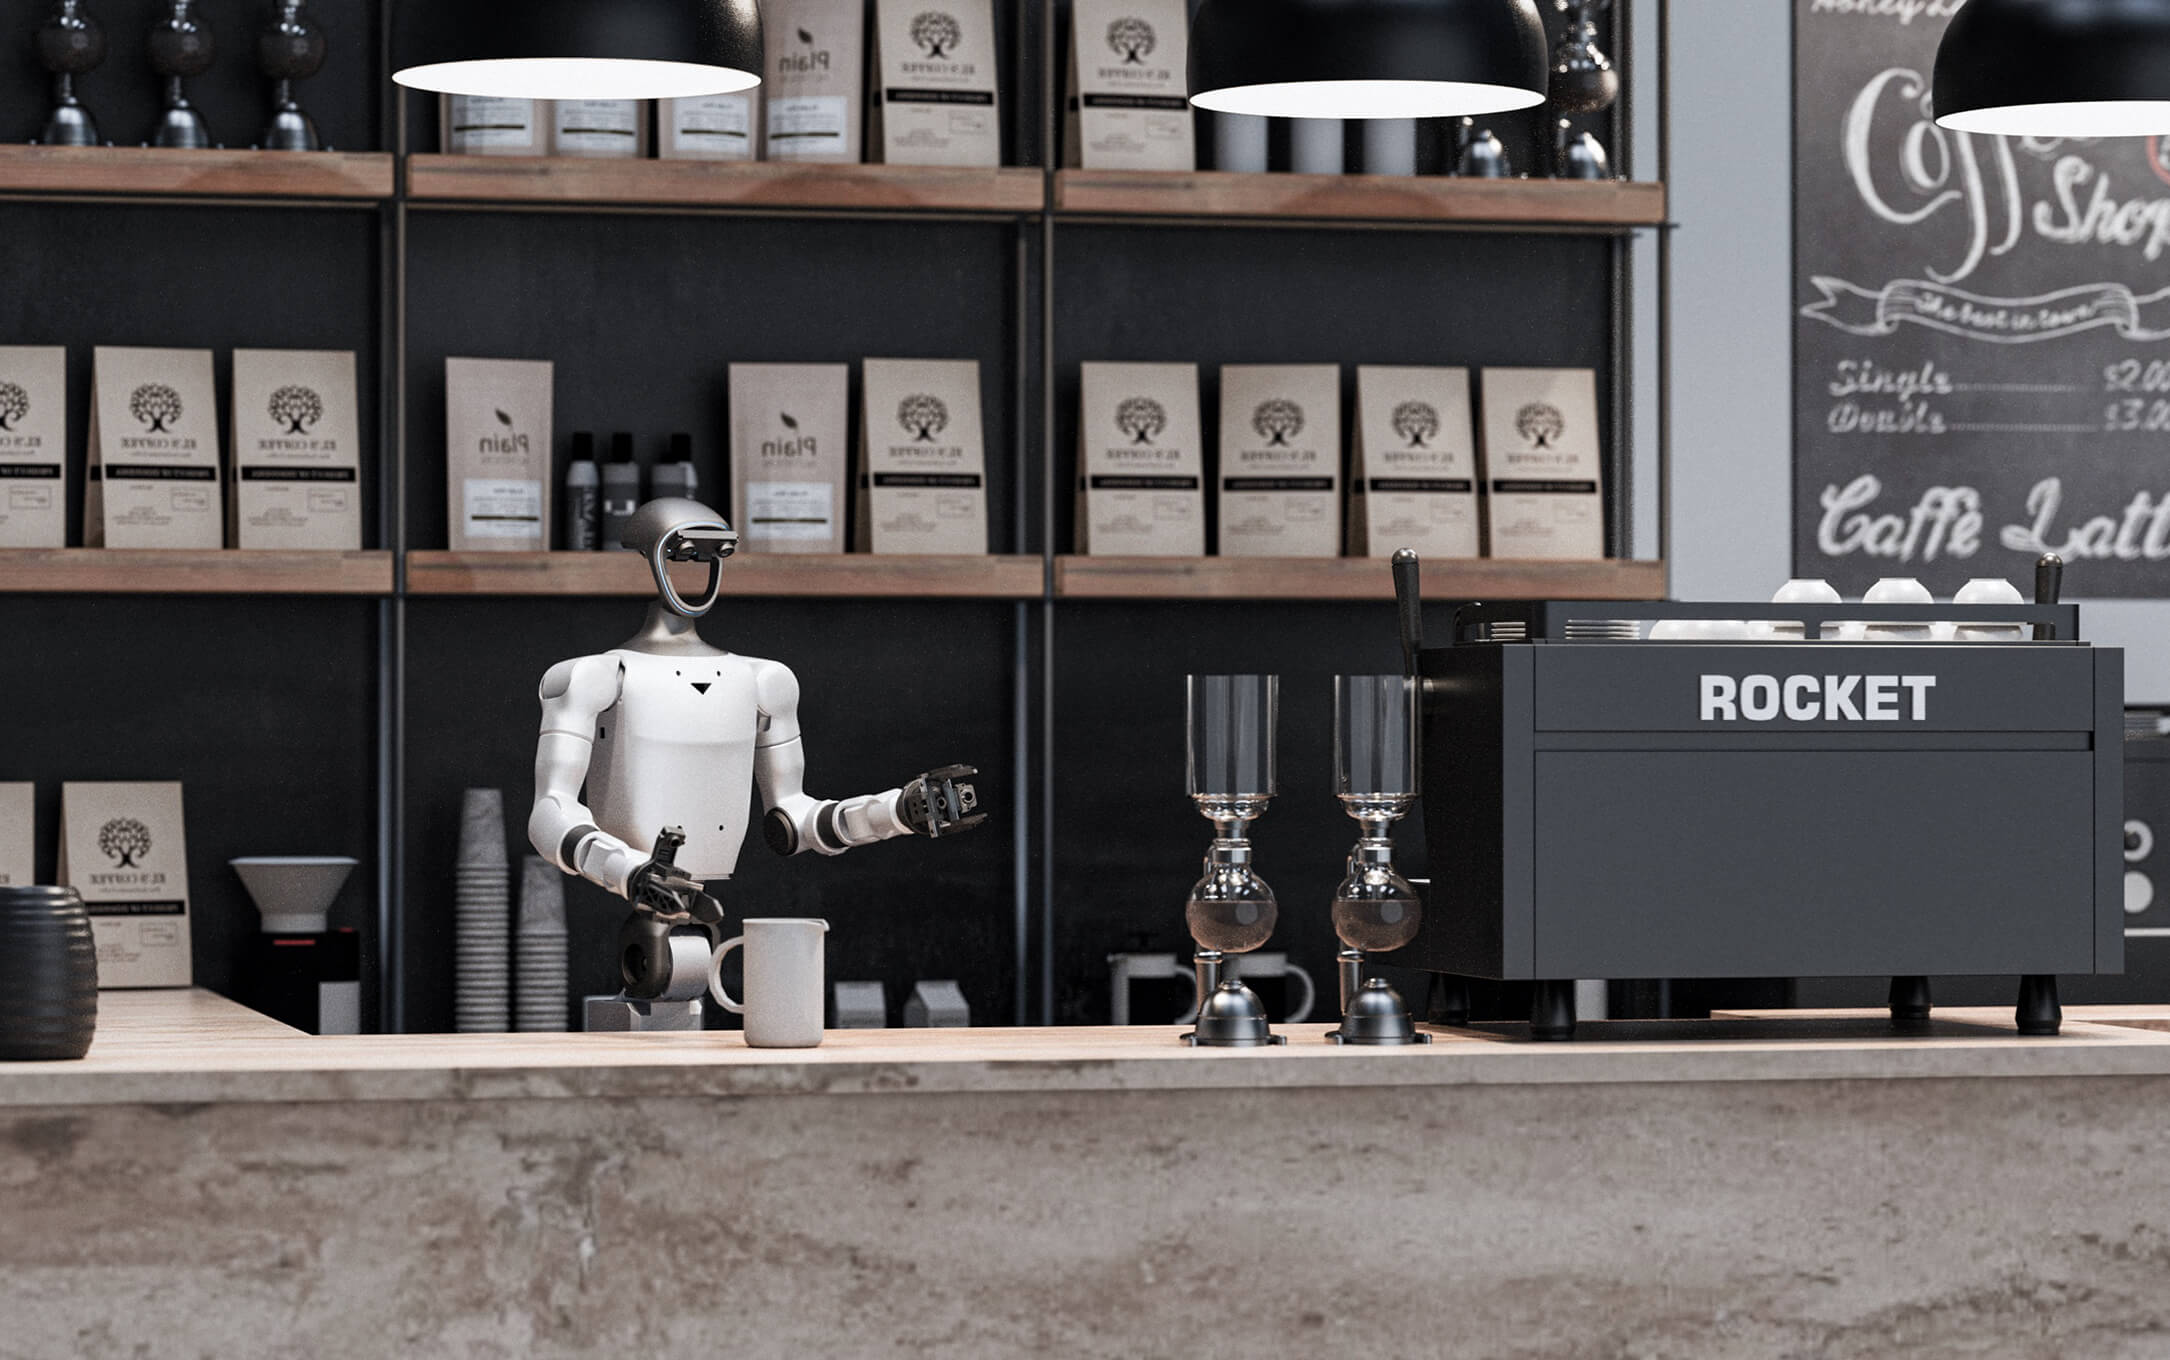
UnifoLM-WMA-0: A World-Model-Action (WMA) Framework
An open-source world-model–action architecture spanning multiple robot embodiments, designed for general-purpose robot learning. Its core is a world model that understands the physical interactions between robots and their environments.
Decision-Making Mode: Action Generation Powered by Precise Prediction
From the current environment state and task goal, it predicts upcoming physical interactions. These predictions help the policy generate actions, reducing decision errors and improving the accuracy and sensibility of motion.
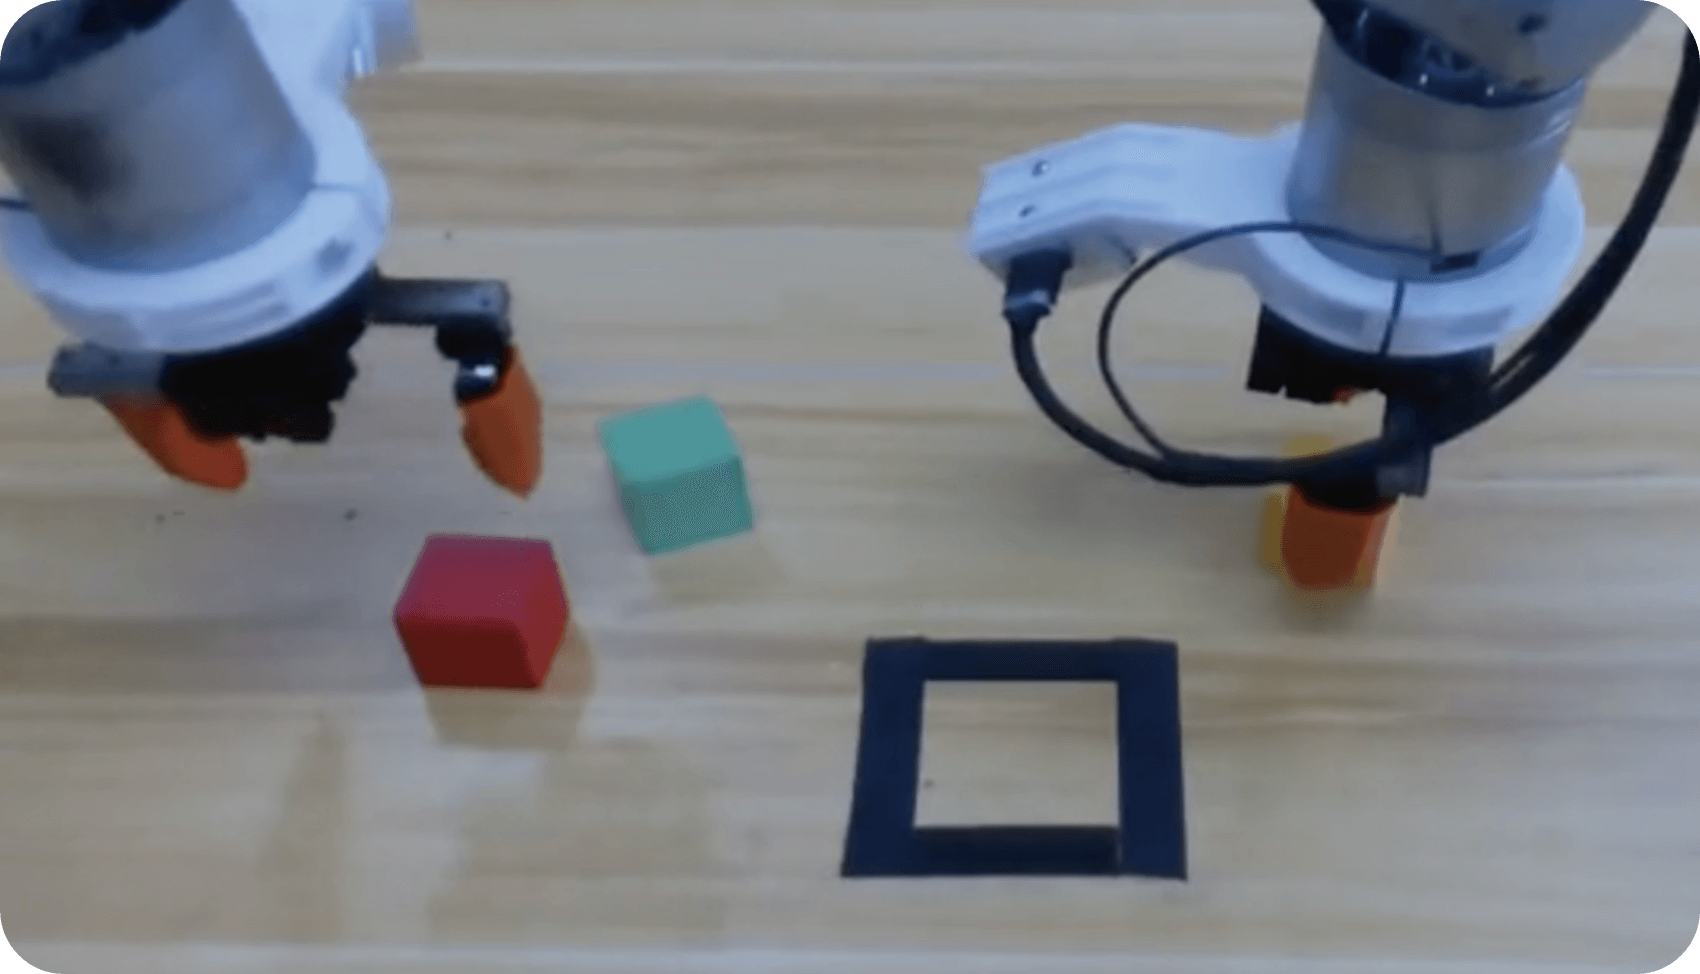
Simulation Mode: High-Fidelity Feedback for Data Generation
It works as an interactive simulator that returns realistic feedback to robot motion inputs, producing high-quality synthetic data that enriches training and speeds up learning.
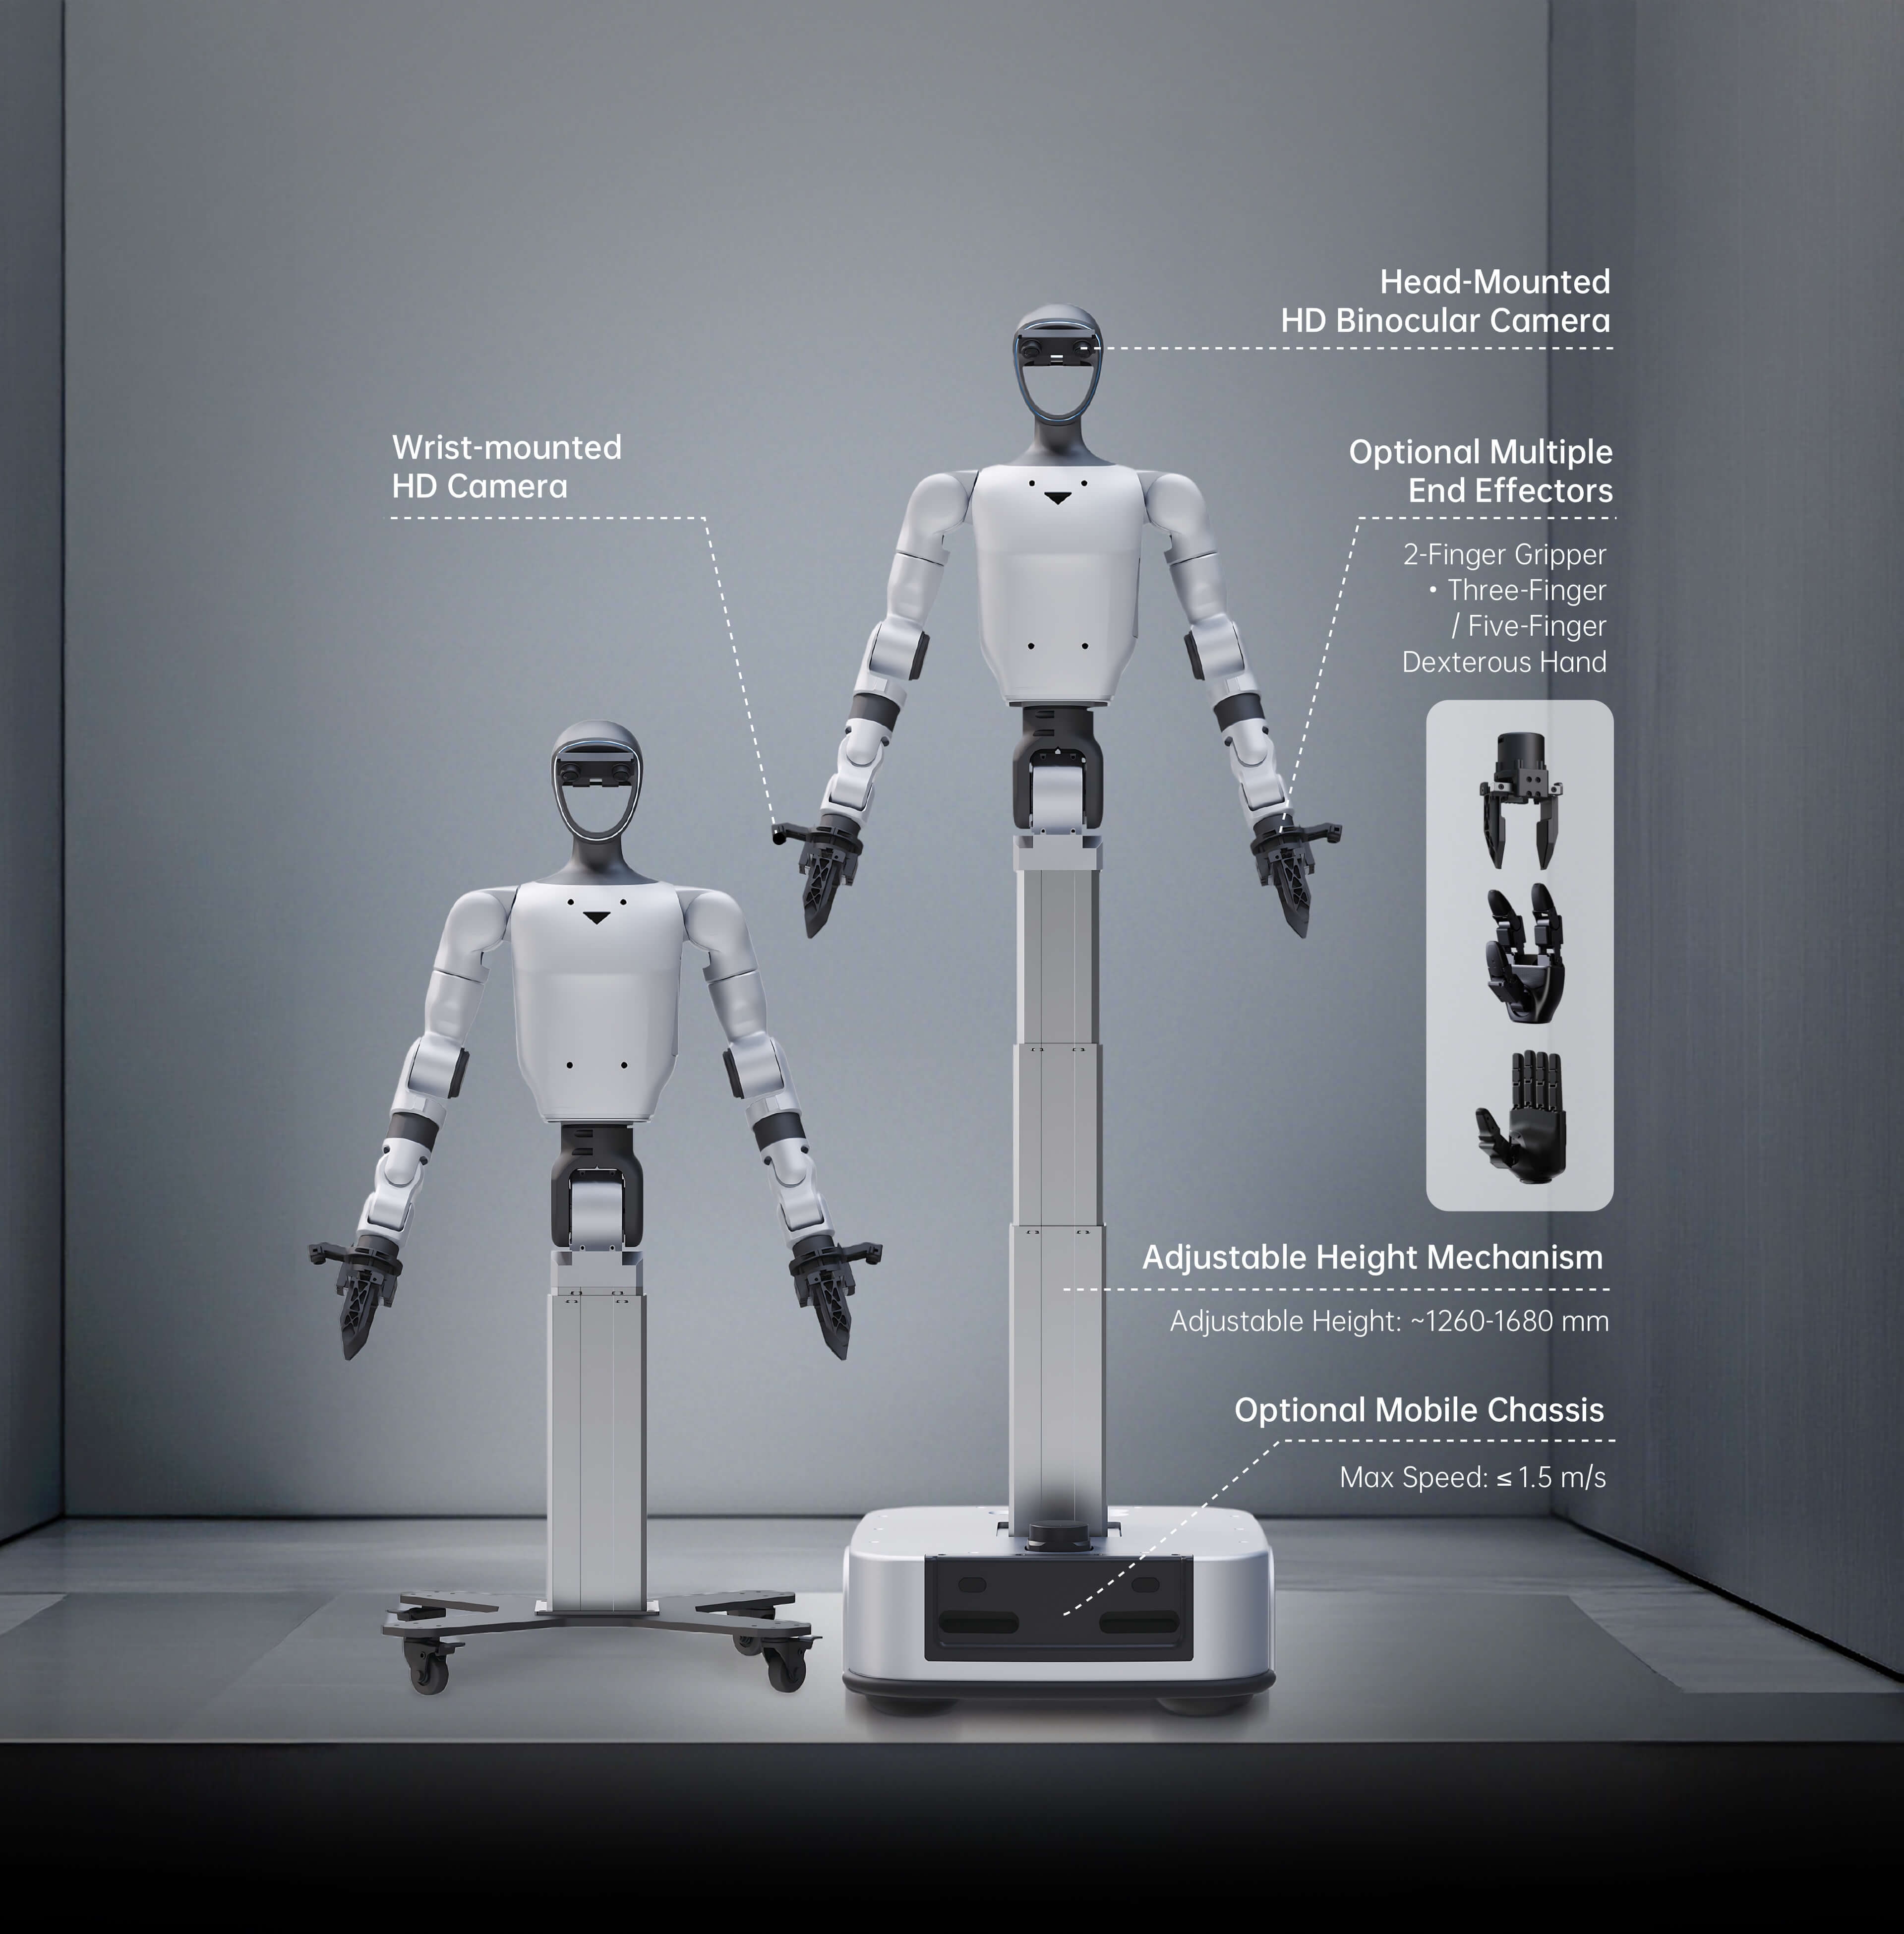
Technical Specifications
| Dimensions (HxWxD) | Min ~1260x620x620mm, Max ~1680x620x620mm |
|---|---|
| Weight (w/ battery) | ~90kg |
| DOF | 17 total (Arm 7*2 + Waist 2 + Column 1), 7 per arm |
| Payload / Reach | Payload: ~3kg (Arm), Reach: ~0.45m |
| Waist | 2 DOF, Range: Z ±155° / Y -2.5°~+135° |
| Lift | 420mm stroke, 1mm accuracy, 60mm/s max speed |
| Max operating height | ~2m |
| Sensors | Multiple perception sensors |
|---|---|
| Cooling | Local air cooling |
| Power | Battery or direct power cable; standard battery x1, battery charger x1 and direct power cable x1 included |
| Battery Life | 2h (Smart 9000mAh, quick-release) |
| Charger | 54V 5A |
| Compute | 8-core CPU, NVIDIA Jetson Orin 16G (100 Tops) |
| I/O | 4-mic array, 5W speaker, Wifi 6, BT 5.2 |
| Control | Handheld remote included |
| Software | OTA upgrades, secondary dev support |
| Includes | RGB camera |
|---|---|
| Active DOF | 20 DoF |
| Grasp configuration | Full opposition, lateral abduction supported |
| Kinematics | Serial direct-drive rotary joints, back-drivable |
| Dimensions | Approx. 185 x 80 x 40 mm (frame) |
| Minimum grasp diameter | 0 |
| Control frequency | 1000 Hz x 20 axes |
| Control mode | MIT force-position hybrid control |
| Communication protocol | EtherNet (1000BASE-T) |
| Peak fingertip force | >= 15 N |
| Open / close speed | >= 4 cycles/s |
| Joint backlash | < 1° |
| Operating voltage | 16-58 V DC |
| Force sensing range | 0~30N full scale, sensitivity 0.005N |
| Wrist RGB Camera | FOV D:130° H:120° V:81°; Resolution: 1920x1080 |
| Whole Machine DOF | 57 (Single Arm 7*2 + Waist 2 + Vertical Column 1 + Dexterous Hand 20*2 = 57) |
|---|---|
| Warranty | 12-month whole machine warranty |
Frequently Asked Questions
What is the G1-D Standard F?
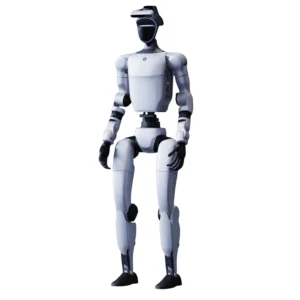
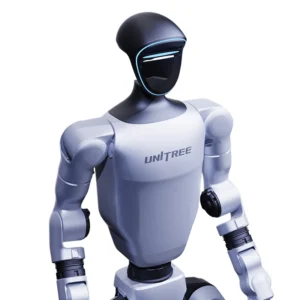
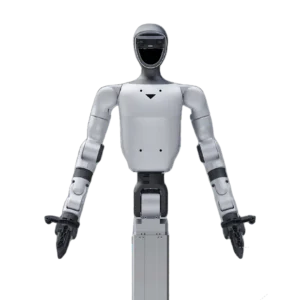
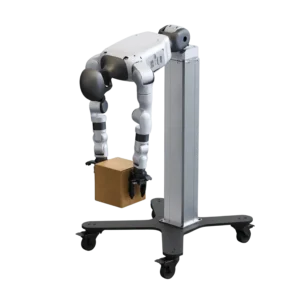
The G1-D Standard F is a G1-D humanoid robot platform with a 7-DOF dual-arm upper body, a 2-DOF waist and a lifting column, fitted with Wuji 5-Finger Dexterous Hand 2 (Non-tactile) x2. It is built around the end-to-end data and model training workflow described above.
What are the dimensions, weight and lift range of the G1-D Standard F?
Dimensions are min ~1260x620x620mm and max ~1680x620x620mm, and the weight with battery is ~90kg. The lift column has a 420mm stroke, 1mm accuracy and 60mm/s max speed, with a max operating height of ~2m.
What end effector does the G1-D Standard F come with?
It is fitted with two Wuji 5-finger dexterous hands (non-tactile), each with an RGB camera, 20 active DOF, serial direct-drive back-drivable joints, peak fingertip force of 15N or more, open/close speed of 4 cycles/s or more, and joint backlash under 1°.
How many degrees of freedom does the G1-D Standard F have?
The whole system has 57 DOF (Single Arm 7*2 + Waist 2 + Vertical Column 1 + Dexterous Hand 20*2 = 57). The robot body itself has 17 DOF (arm 7*2, waist 2, column 1).
What are the battery life, computing power and warranty of the G1-D Standard F?
Battery life is 2h with the Smart 9000mAh quick-release battery (54V 5A charger), the compute is an 8-core CPU plus NVIDIA Jetson Orin 16G (100 Tops), and OTA upgrades and secondary development are supported. The warranty is 12 months for the whole machine.

There are no reviews yet.