
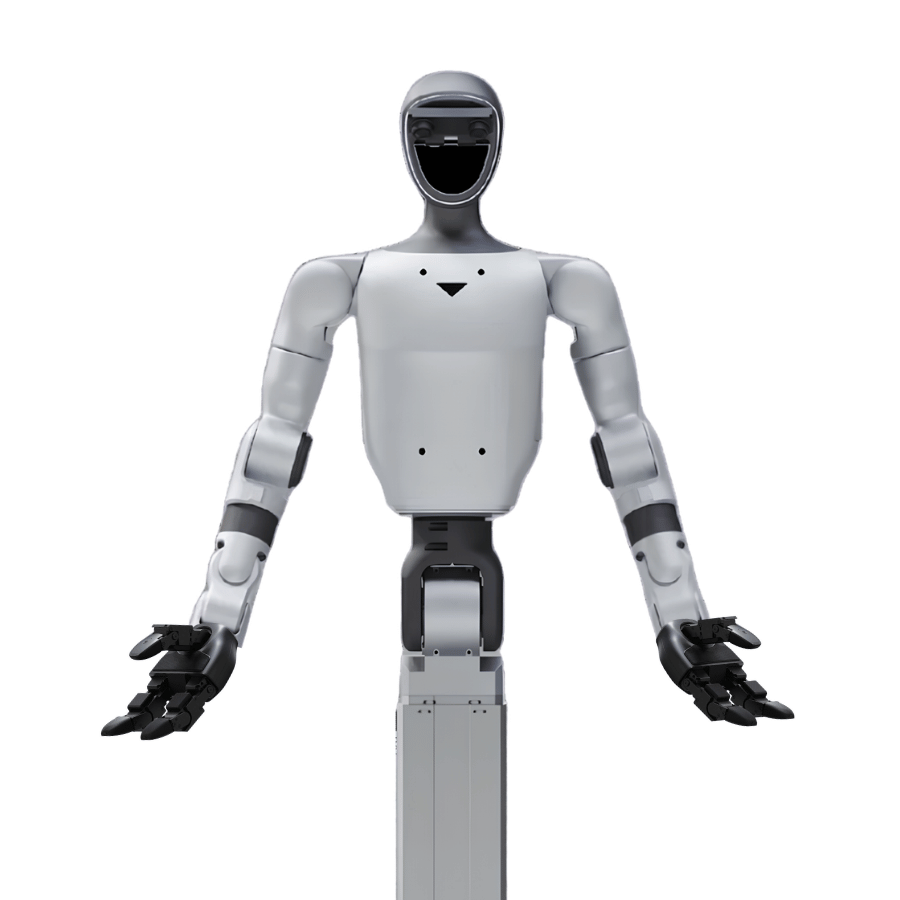
Unitree G1-D Flagship B Semi Humanoid Robot
- Mobile dual-arm semi humanoid platform for data collection and model training
- 33 DOF in total: arm 7×2, waist 2, column 1, hand 7×2, base 2
- Variant: Flagship B with Dex3-1 force-controlled 3-finger hands (no tactile) and RGB wrist cameras
- Other variants: A (Dex1-1 grippers), C (Dex3-1 tactile), D (Revo 2 Basic), E (Revo 2 Tactile), F (Wuji 5-finger)
- Dex3-1 hand: ~650g, 175×88×77mm, 7 DOF per hand, 12~58V, USB
- ~3kg arm payload, ~0.45m reach, 450mm lift, ~2m max operating height
- Wheeled base: 1.5m/s, 360° rotation, LiDAR and depth cameras, 6h runtime
- Trusted dealerDirect manufacturer partnership
- Pan-India deliveryInsured shipping, all states
- Post-sale supportTraining + service included
What makes it work
G1-D Flagship B
End-to-End Platform for Humanoid Robot · Data & Training
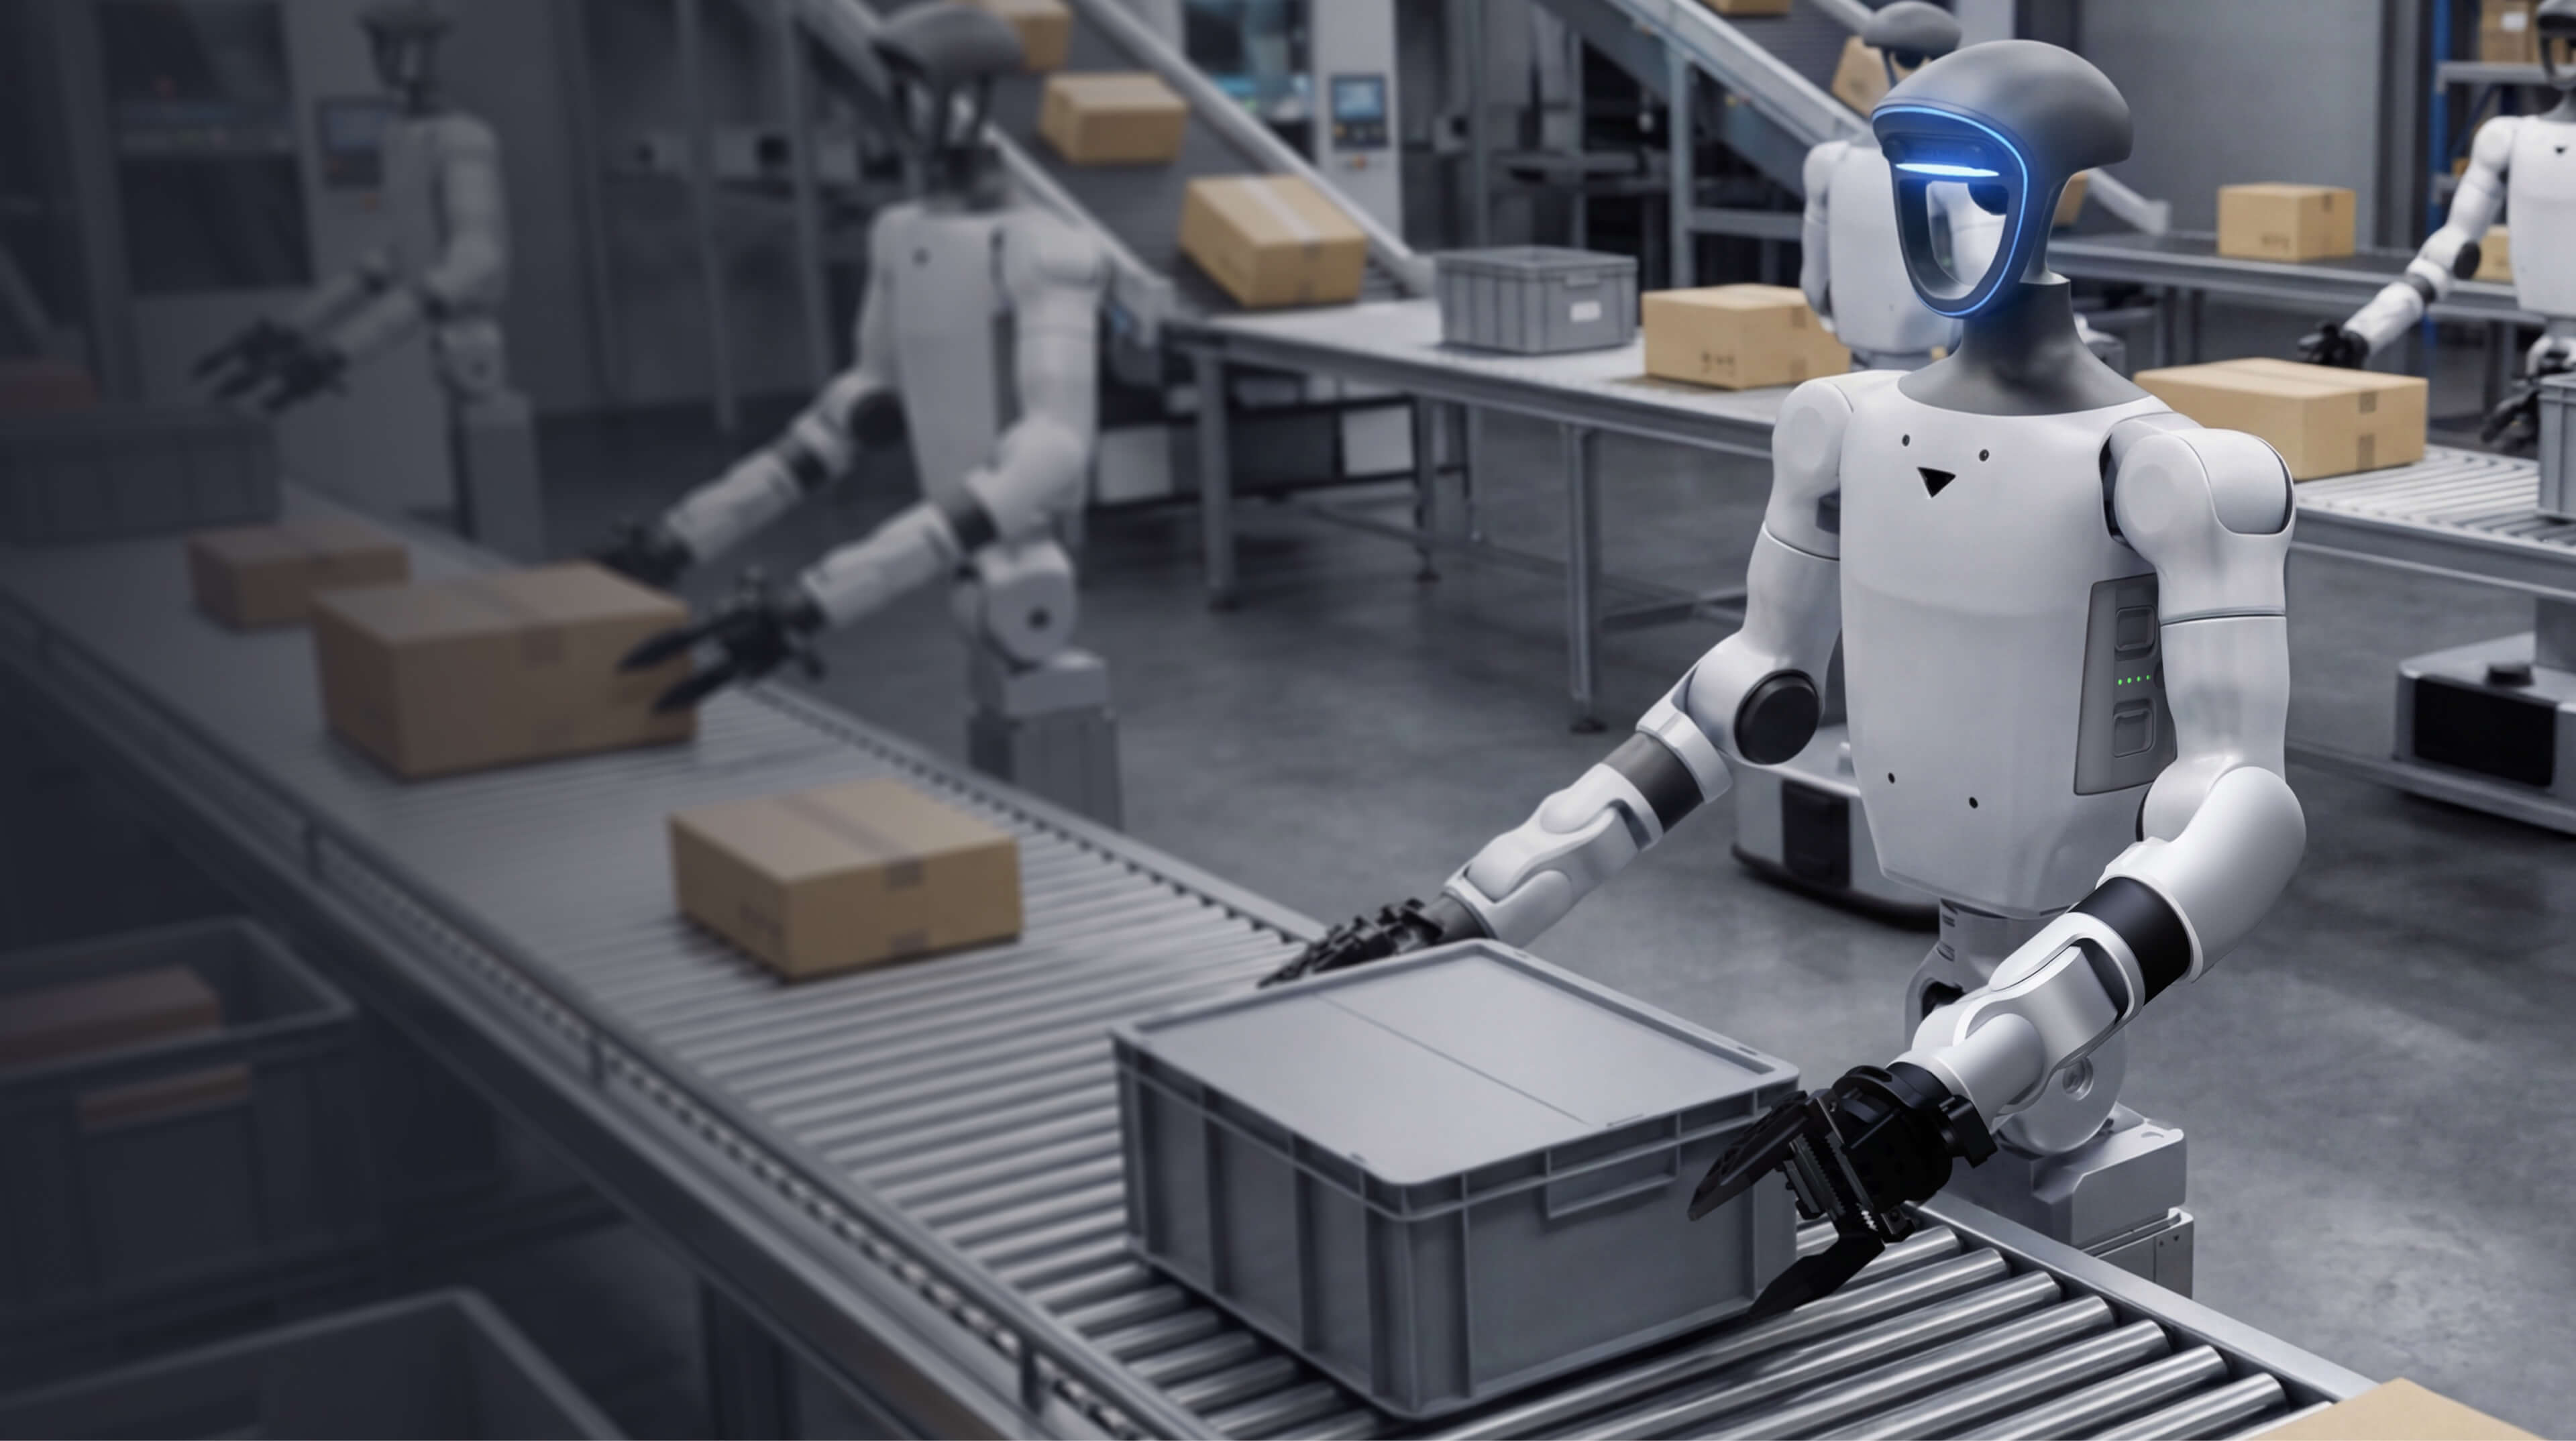
Core Components

High-Performance Humanoid Robot
Proprietary humanoid platforms built with in-house actuators, gearboxes, encoders and sensors.

Streamlined Data Acquisition Tools
One platform for the whole data pipeline: collection, processing, labeling, review and data asset management.

Comprehensive Model Training & Inference Tools
Distributed training, custom model development and smooth deployment, with support for all major open-source frameworks.
Higher-DOF Robot Platform
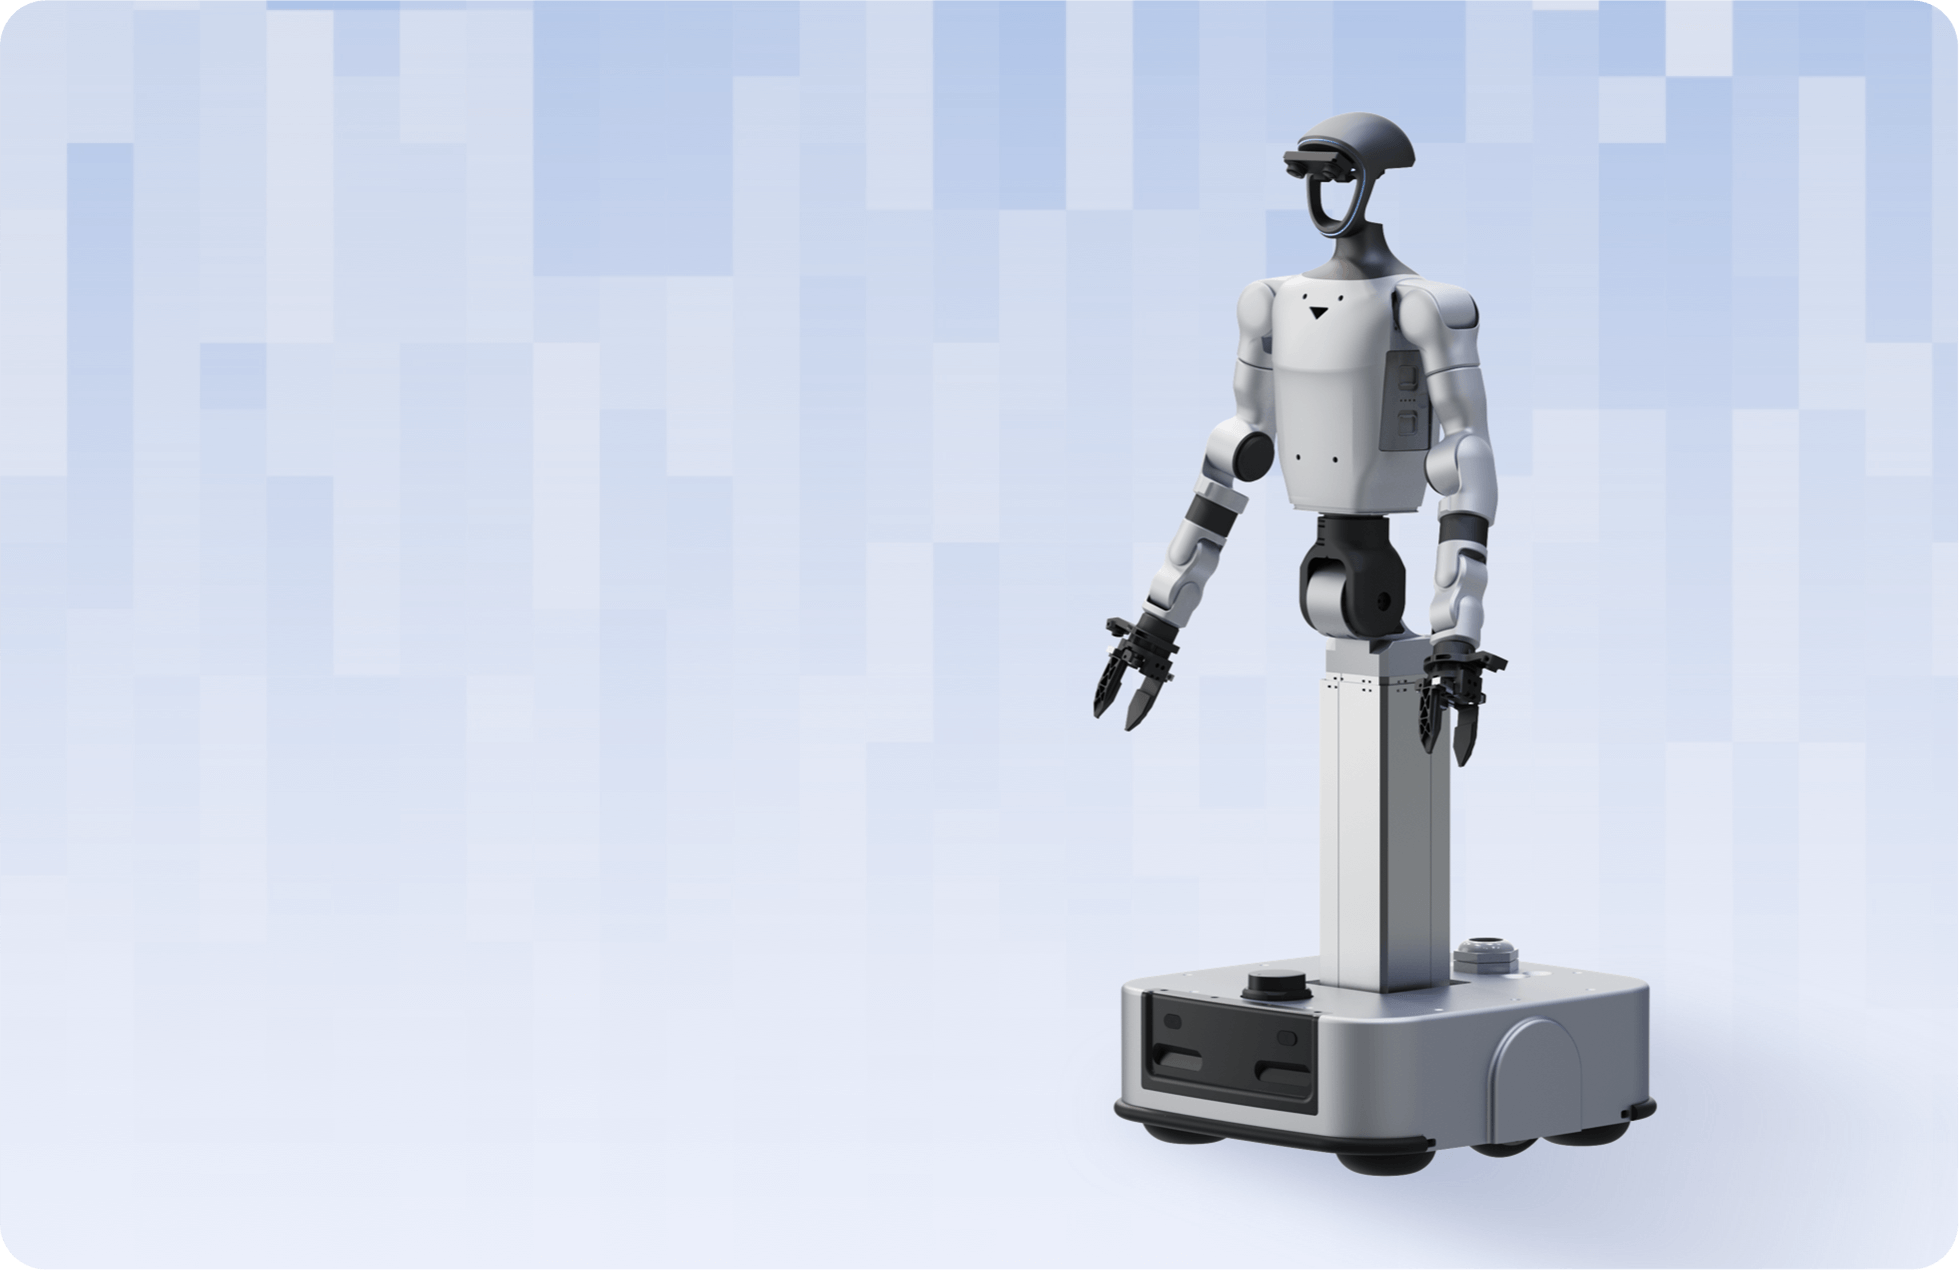
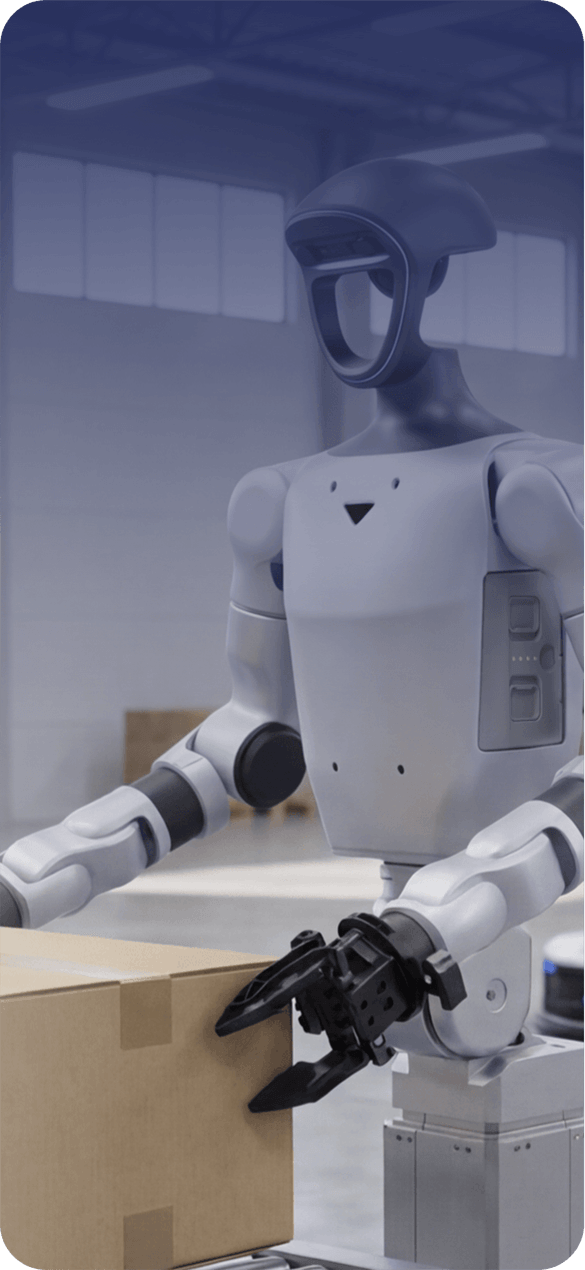
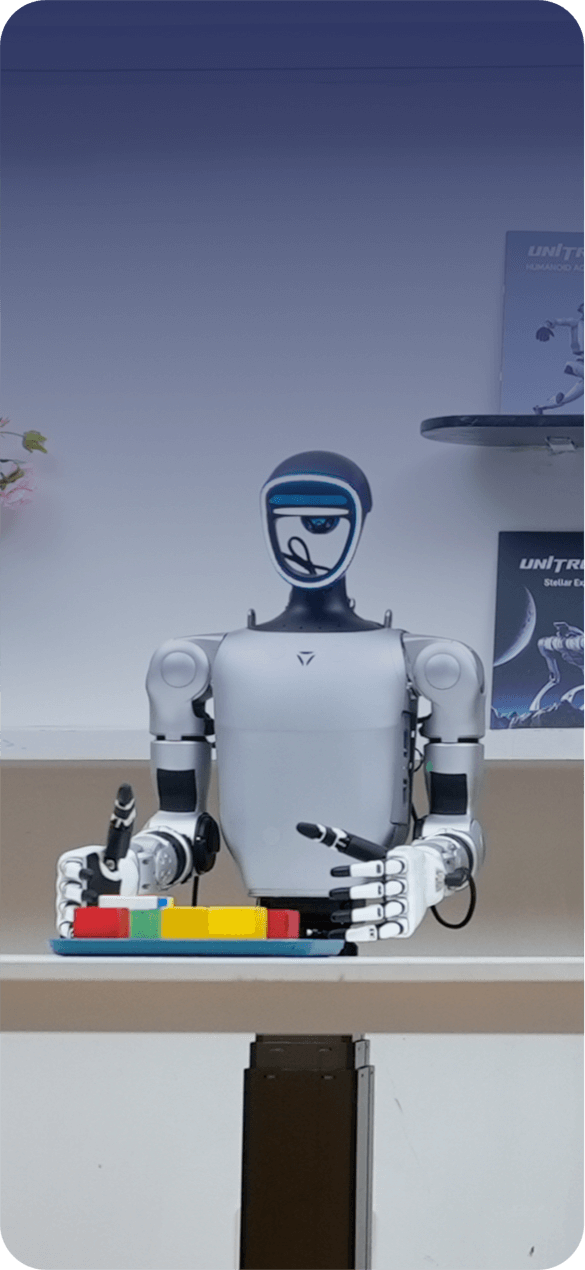
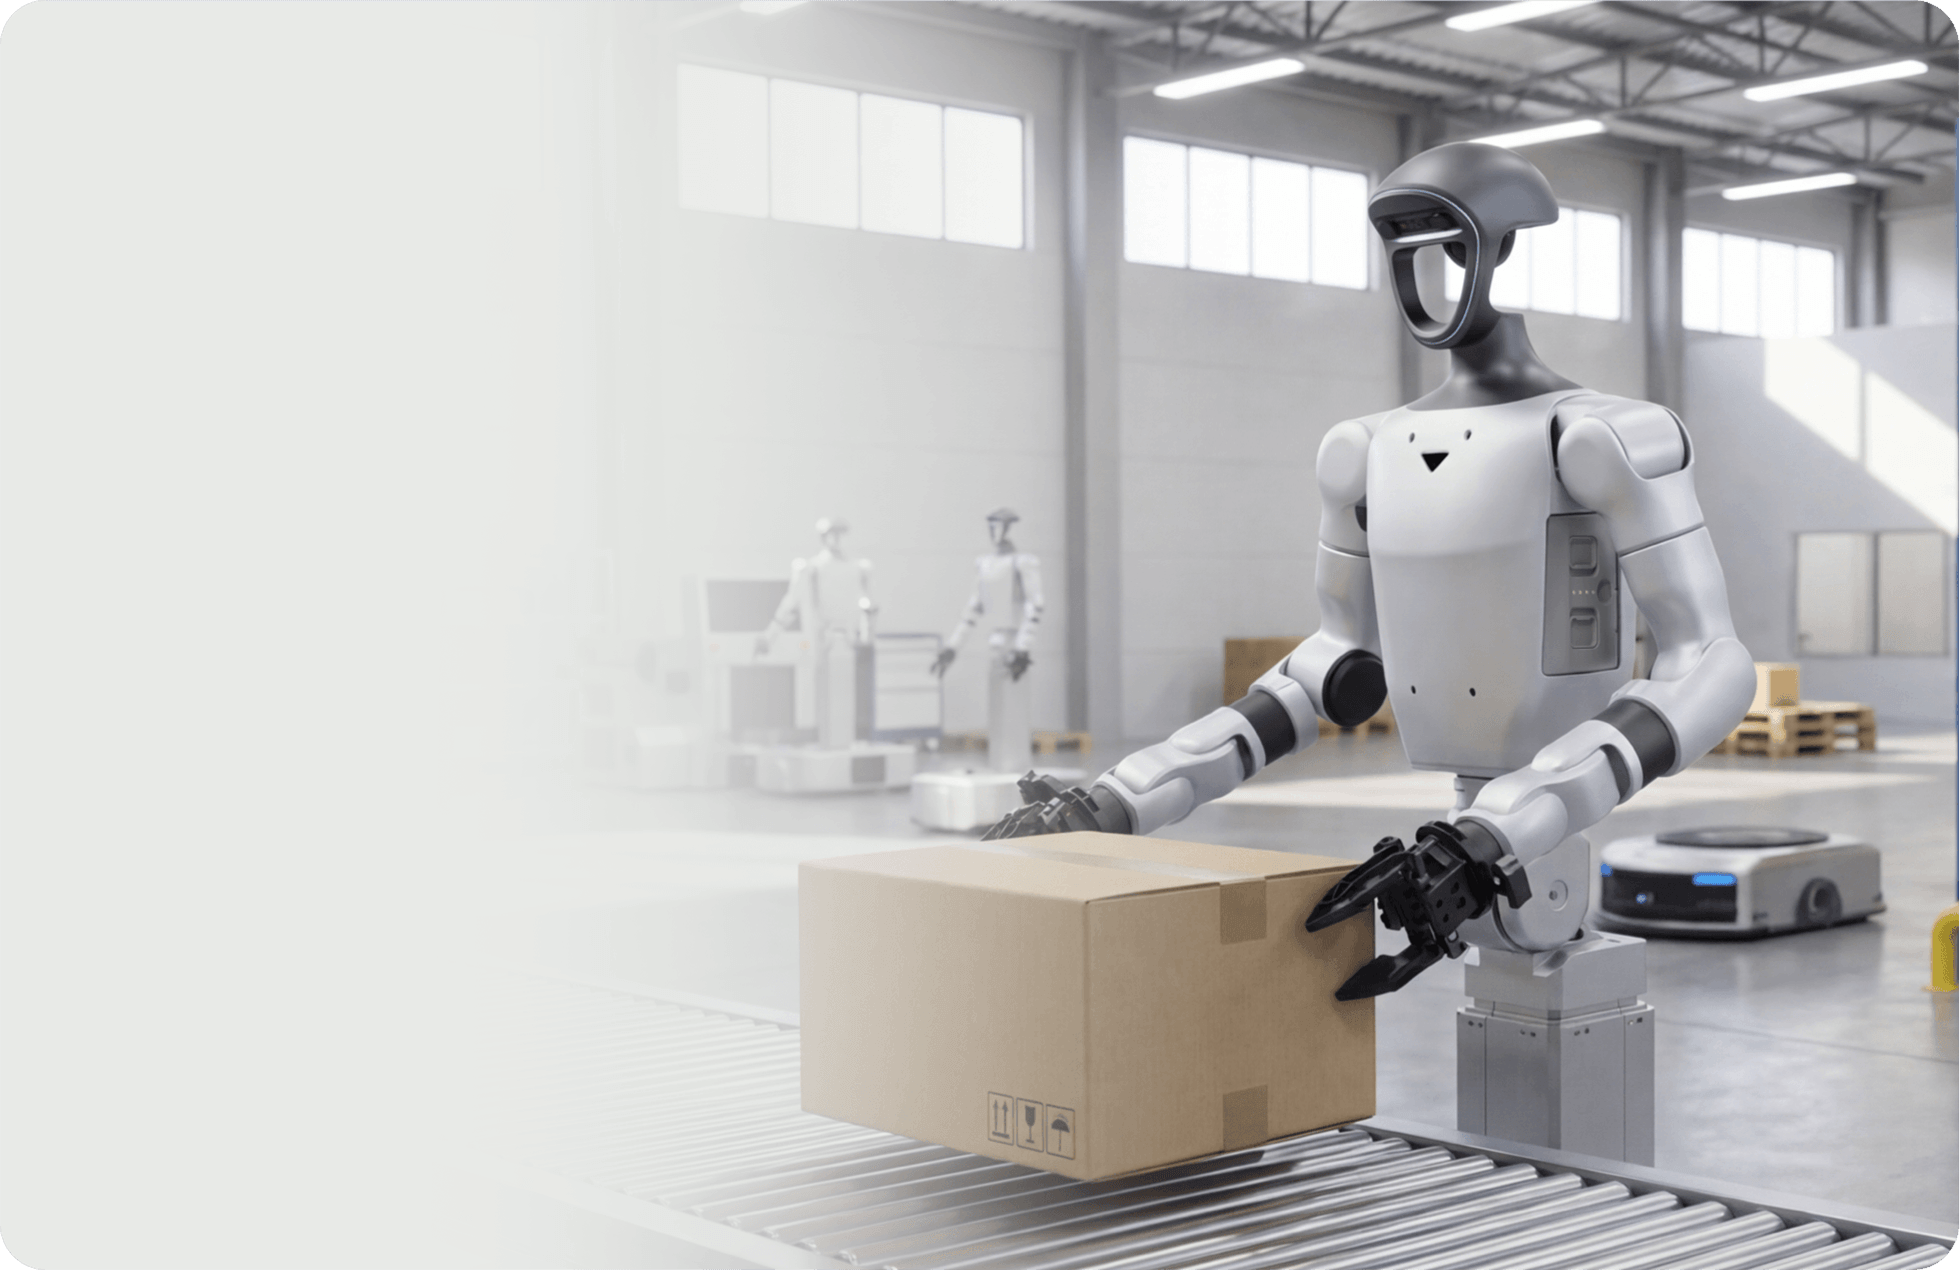
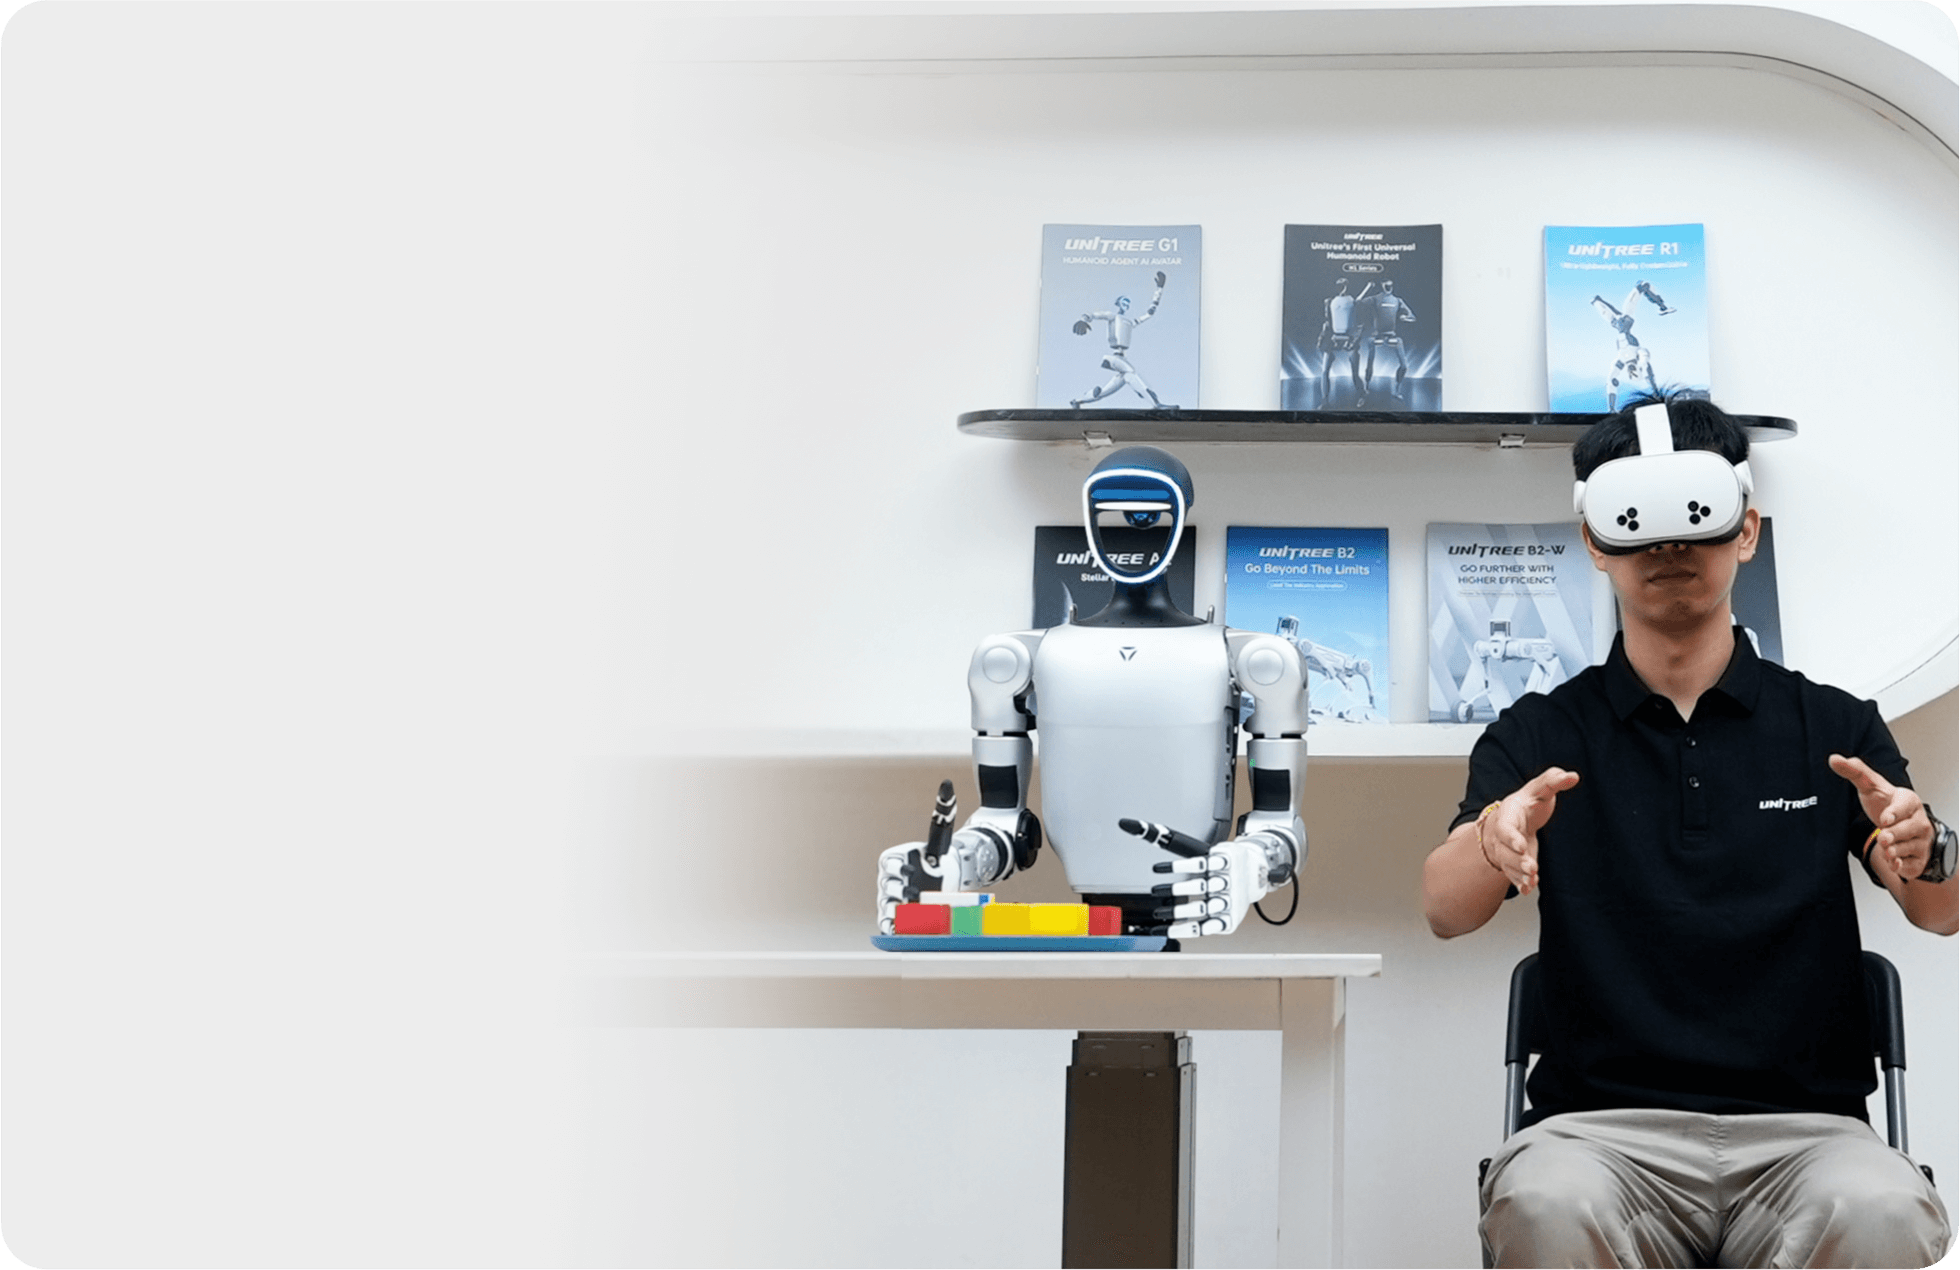
- Expanded Operational Workspace
- Lower-Latency Control Response
Streamlined Data Acquisition Tools
Standardized, flexible workflows cut collection costs and replace manual processes.

Visual Template Management for Efficient Collection
Project management, task allocation, progress tracking and status analysis in one platform. Templates generate collection tasks in one click, and the whole workflow can be tracked in real time.

Flexible Configurations with Diverse Platforms & End Effectors
Data can be collected across many robot platforms and end-effector configurations, and strong standardization turns data from varied devices into quality model training data.
High-Concurrency Architecture for Scalable Operations
Built for many robots collecting at once, with load-balanced scheduling that receives and processes large data streams in real time.
24/7 Online Collection, Stable and Reliable
A highly available service architecture supports round-the-clock collection, and broad format compatibility lets data be exported directly or converted to mainstream training formats, speeding up R&D.
Data Acquisition Pipeline
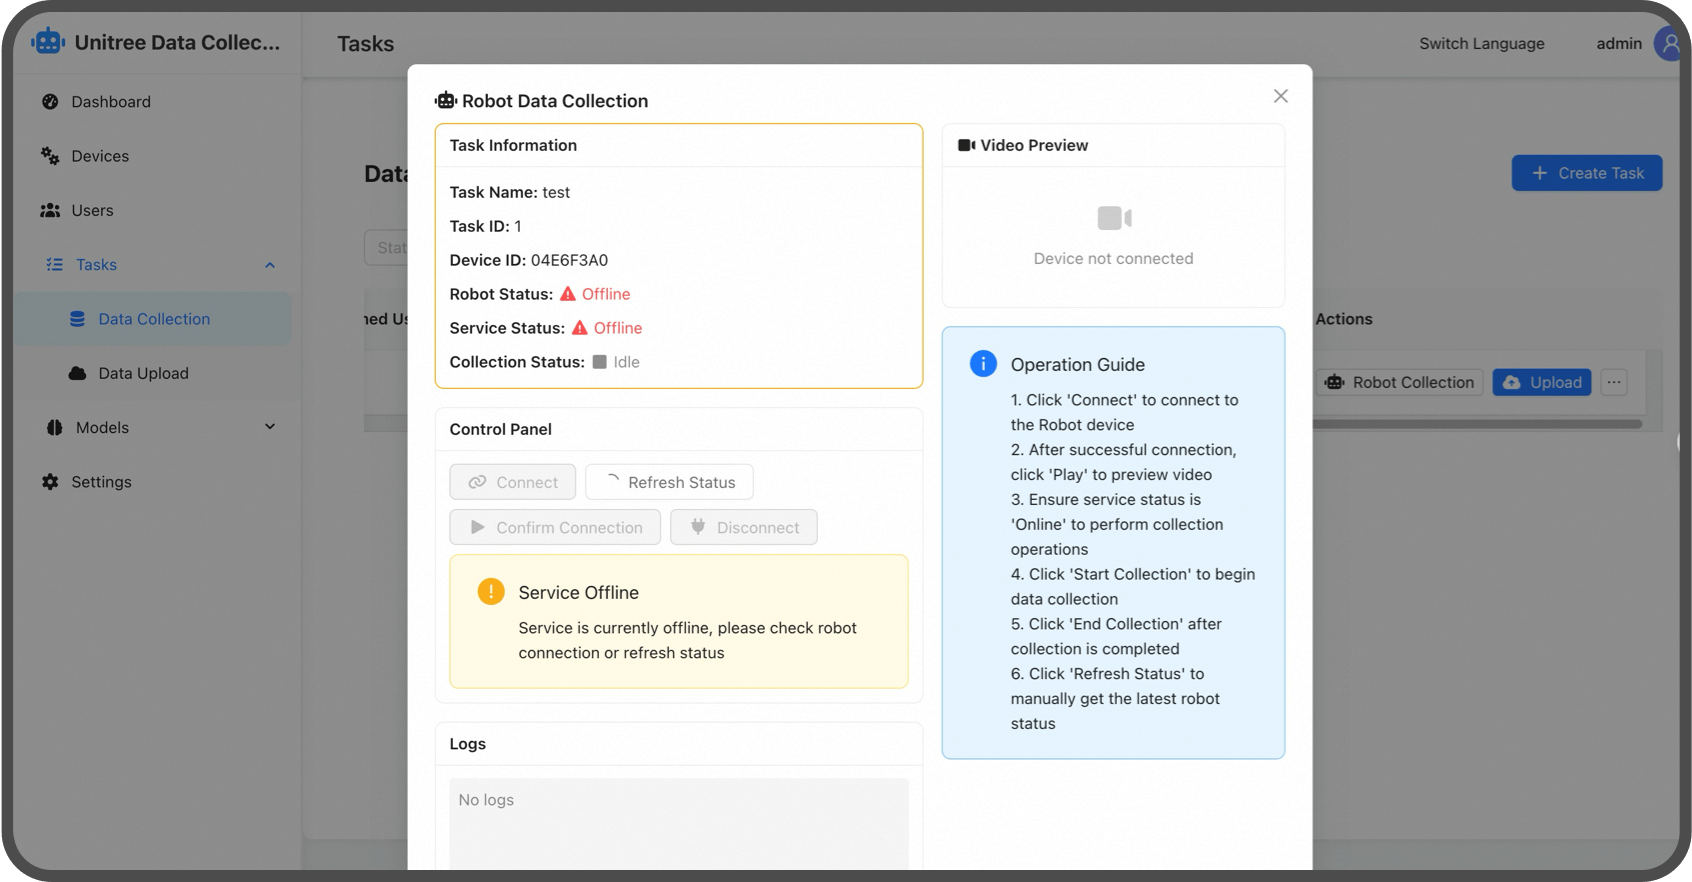
Creating New Collection Tasks
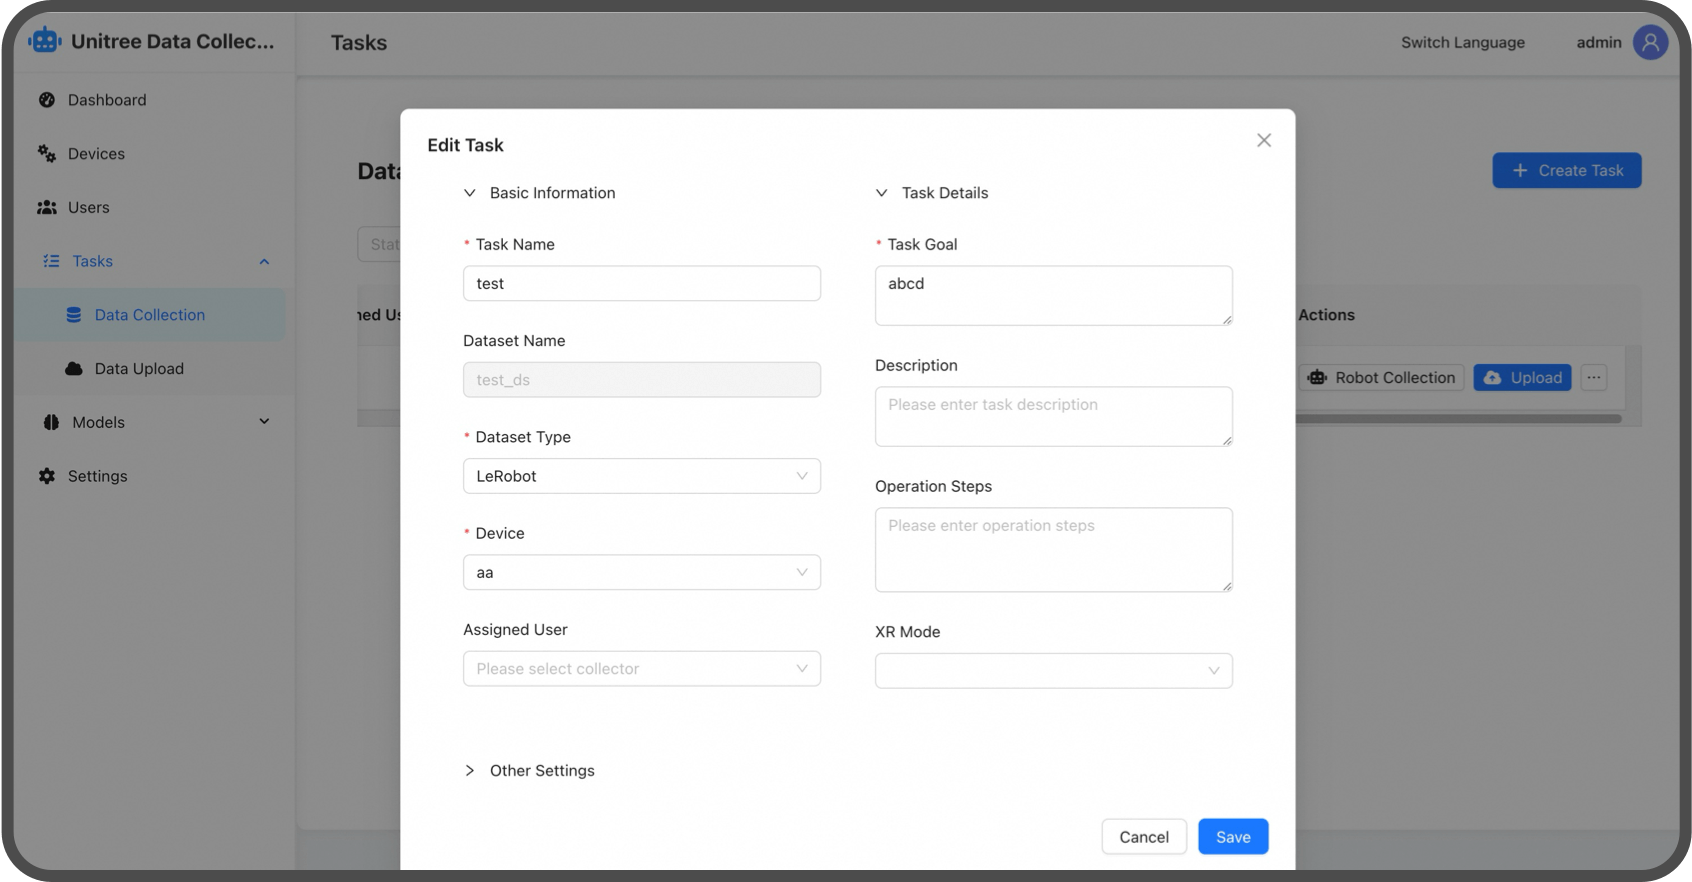
Task Editing and Assignment
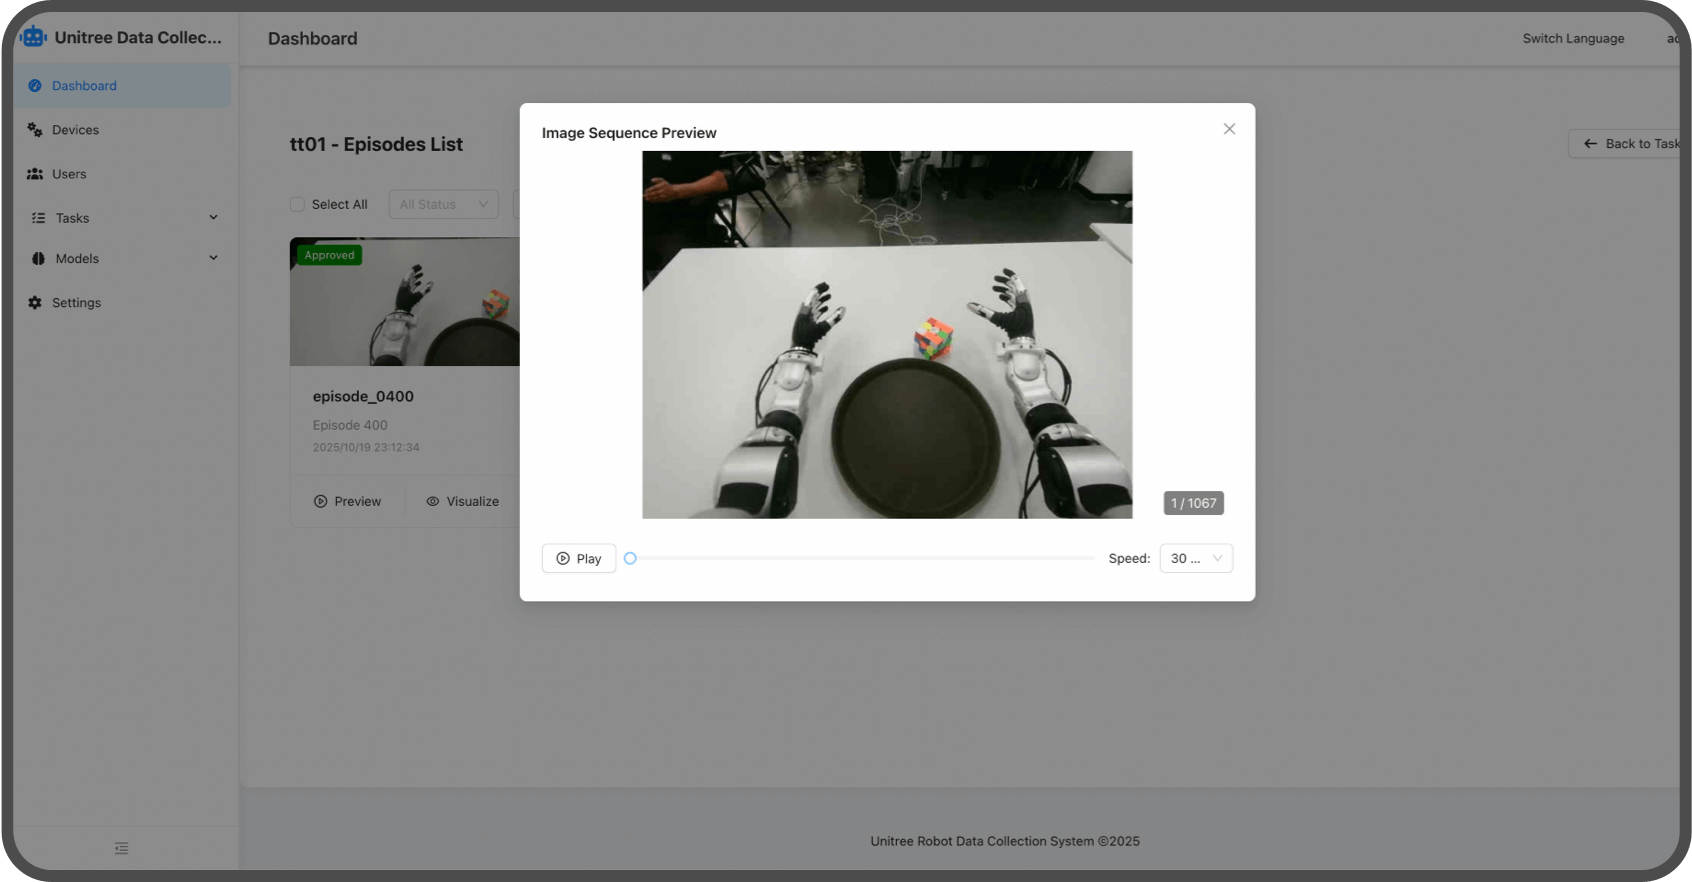
Data Acquisition and Annotation
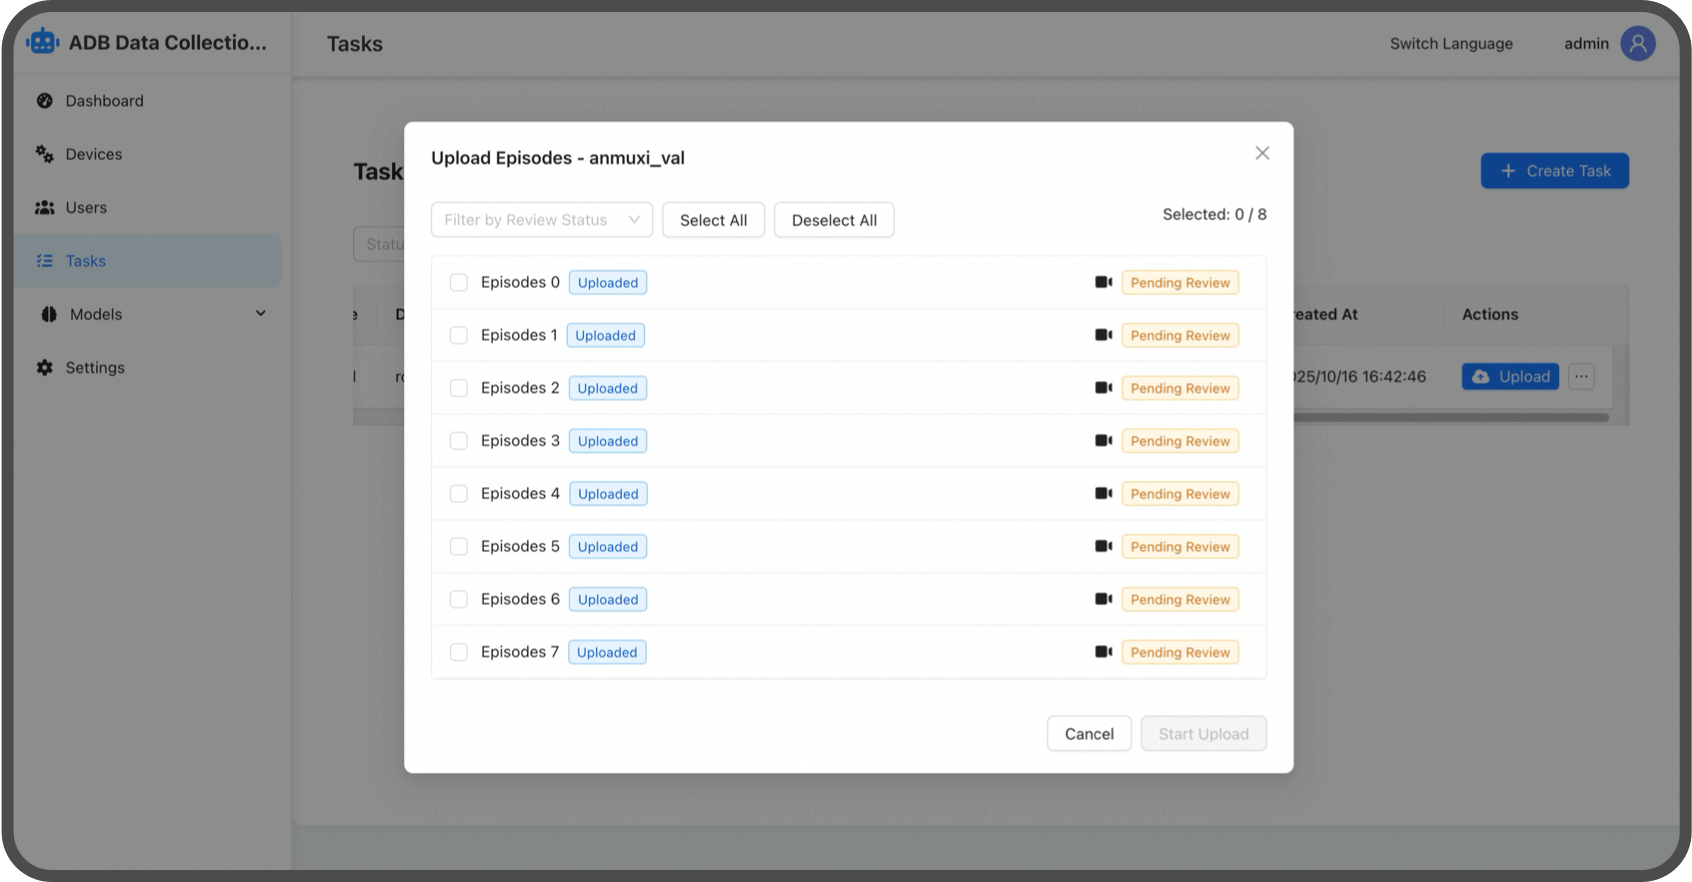
Data Upload and Review
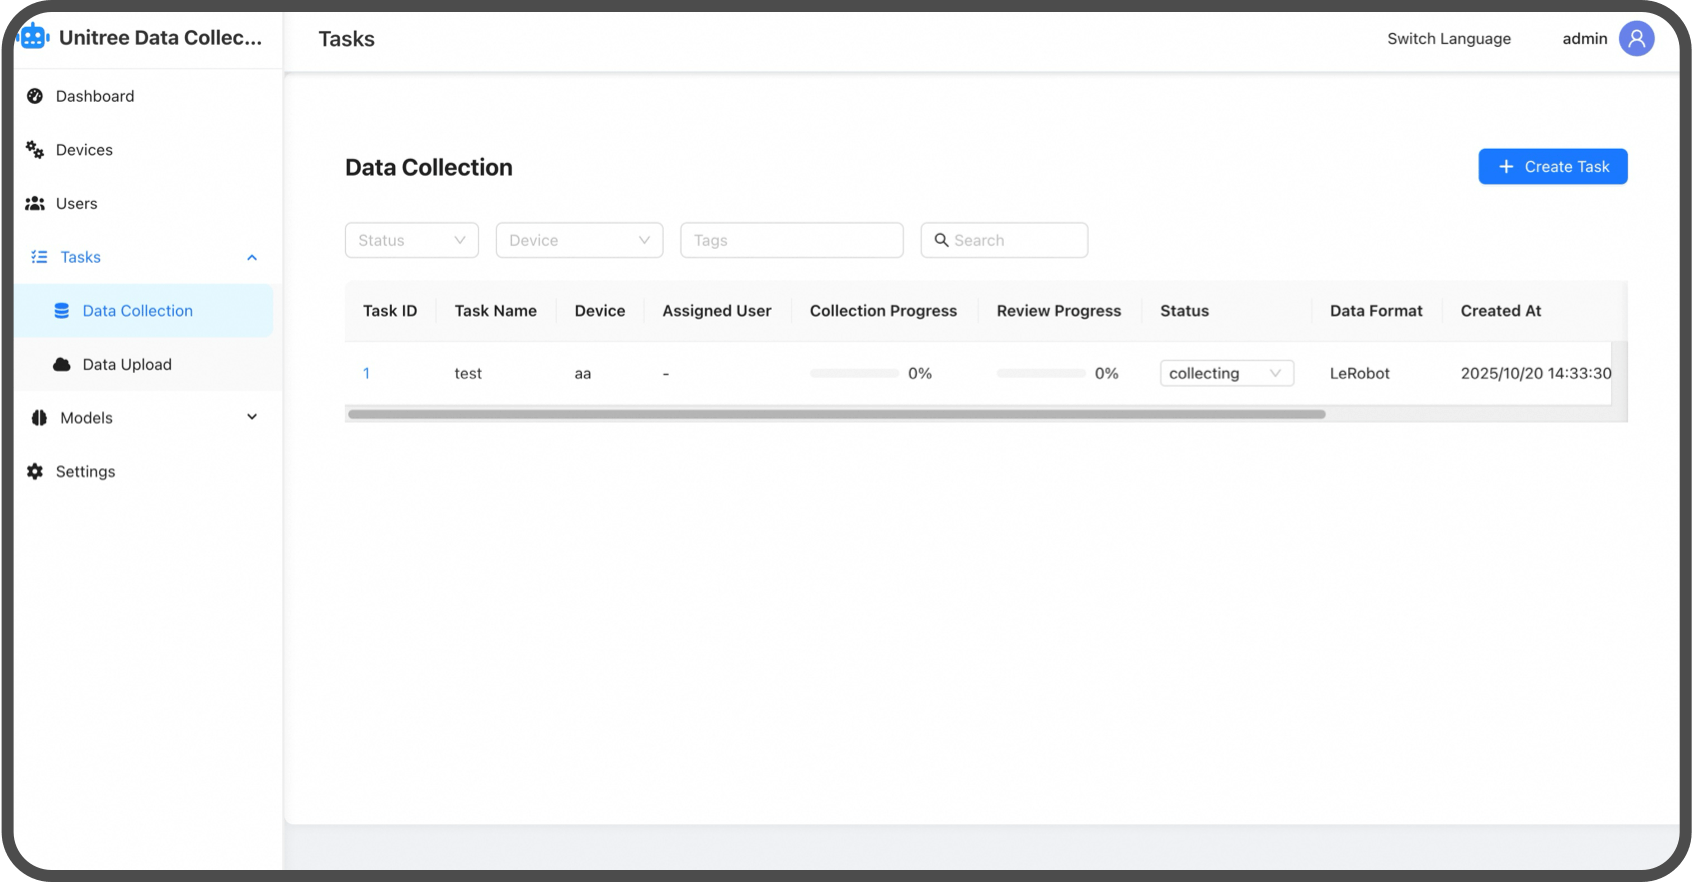
Data Storage
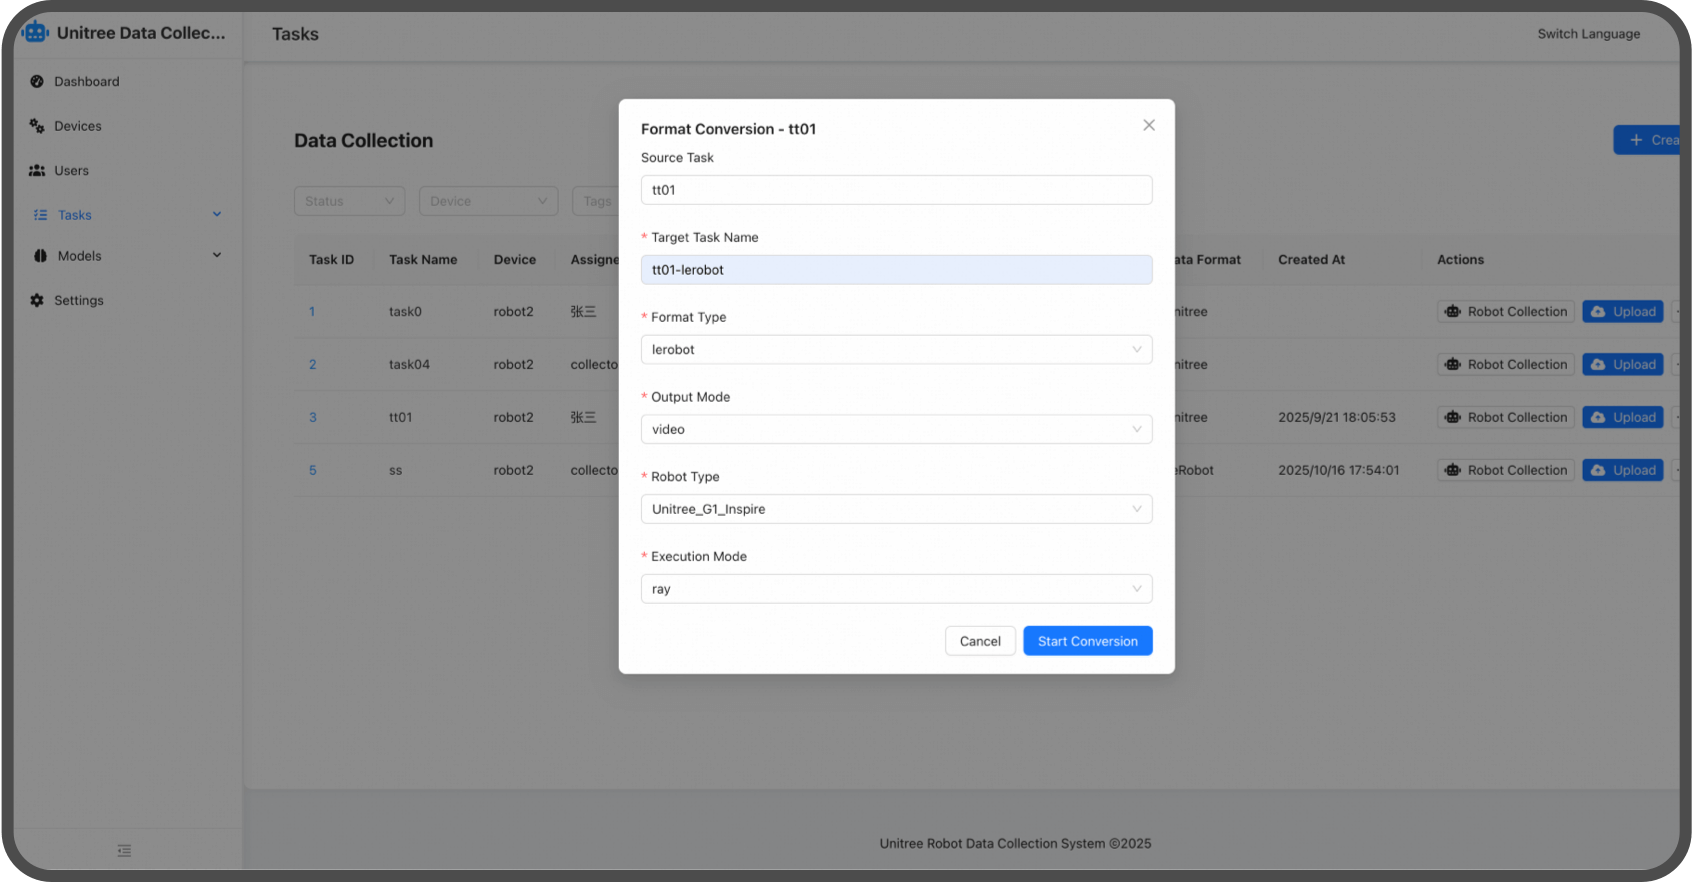
Data Export
Comprehensive Model Training & Inference Tools
An end-to-end workflow from data processing to one-click model deployment, integrating mainstream open-source robot model frameworks.

Rich Ecosystem with Mainstream Model Support
An open model ecosystem with built-in community datasets, open-source dataset training and deep integration with leading open models such as PI and GROOT.

Simulation Environment for Model Evaluation
A high-fidelity 3D asset library for building realistic simulations and quickly generating evaluation plans to validate algorithms.
User-Friendly Design for Rapid Deployment
Deploys out of the box. Start model development with one-click training, evaluate with built-in simulation, and move algorithms onto real machines smoothly.
Distributed Training for High Efficiency
A high-performance distributed architecture with elastic scheduling and parallel acceleration that scales with workload, reaching up to 90% GPU utilization.
Training and Inference Pipeline
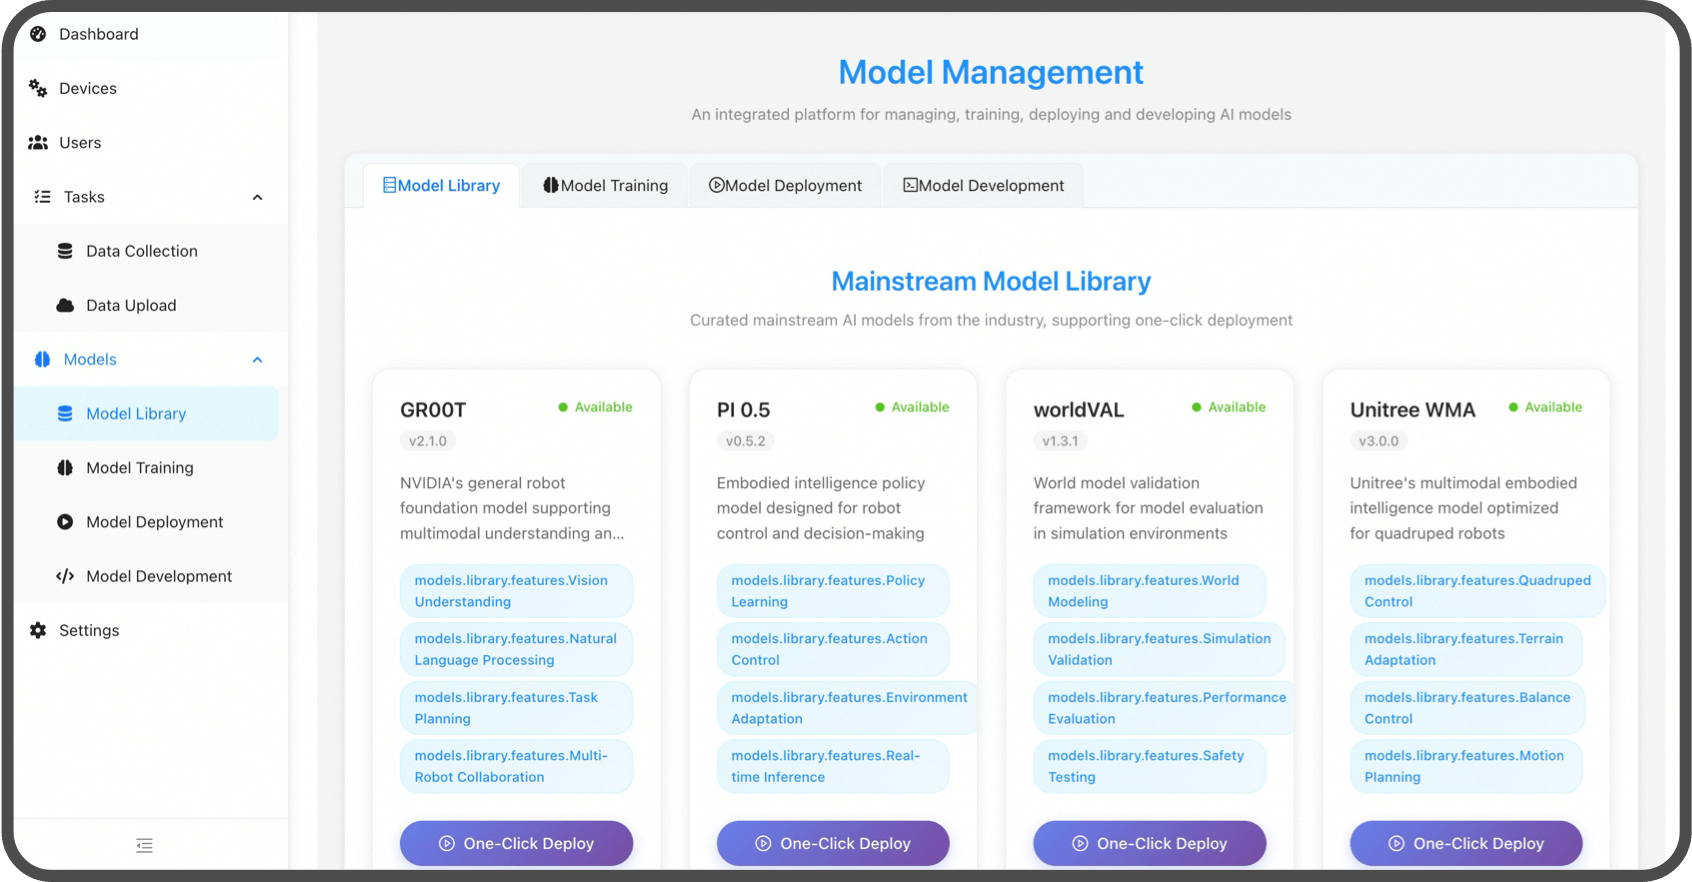
Model Architecture Selection
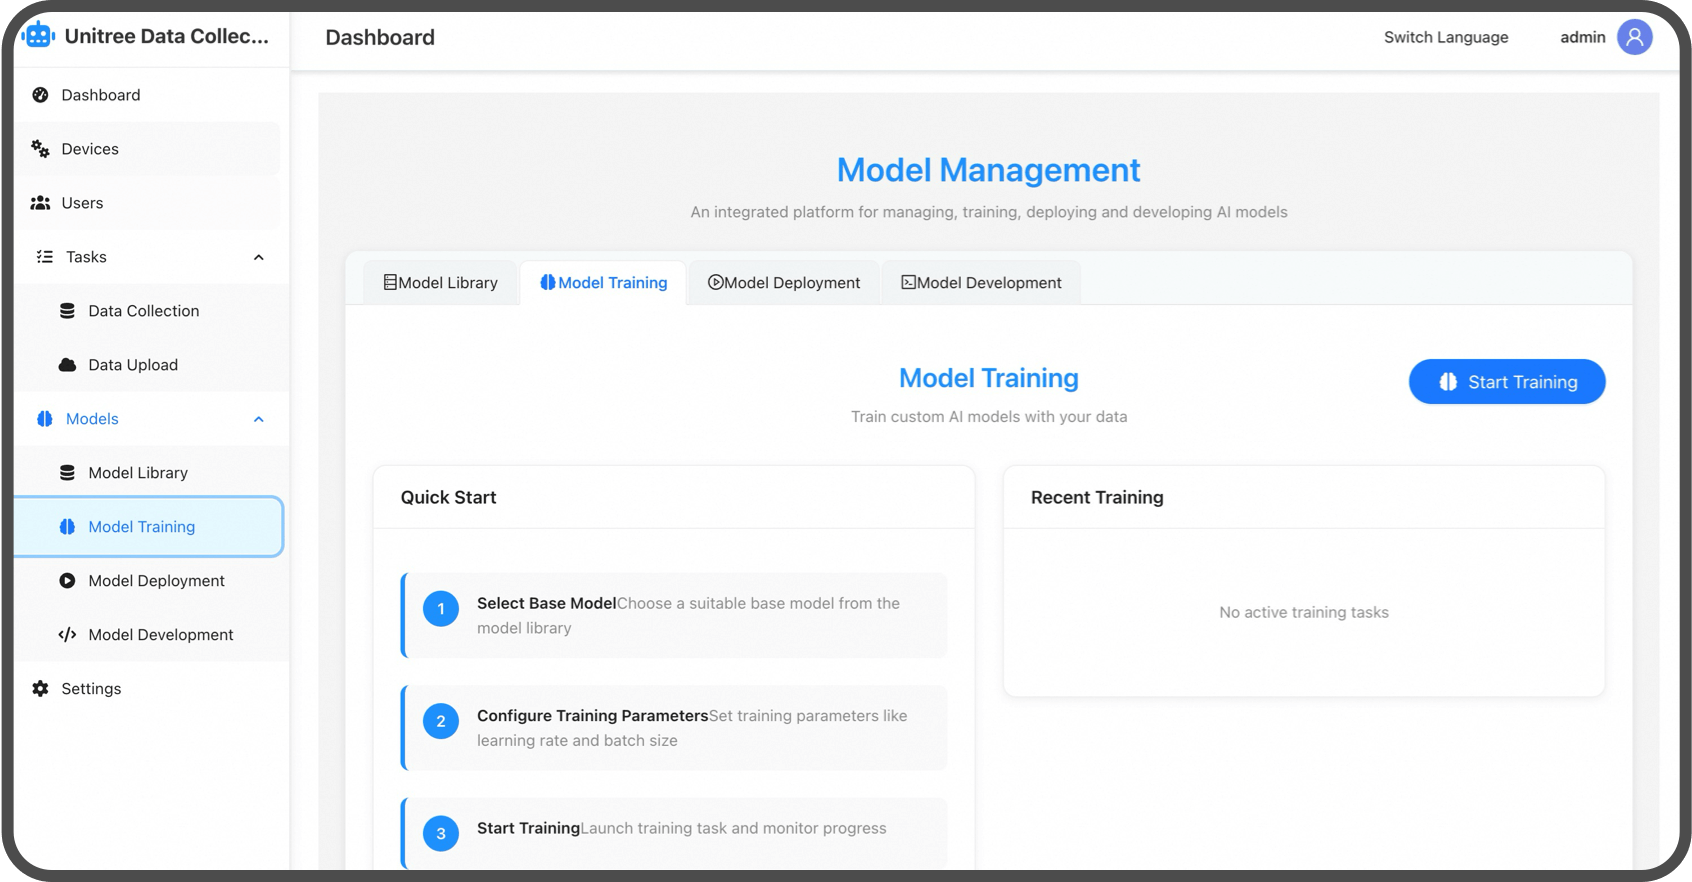
Training Configuration
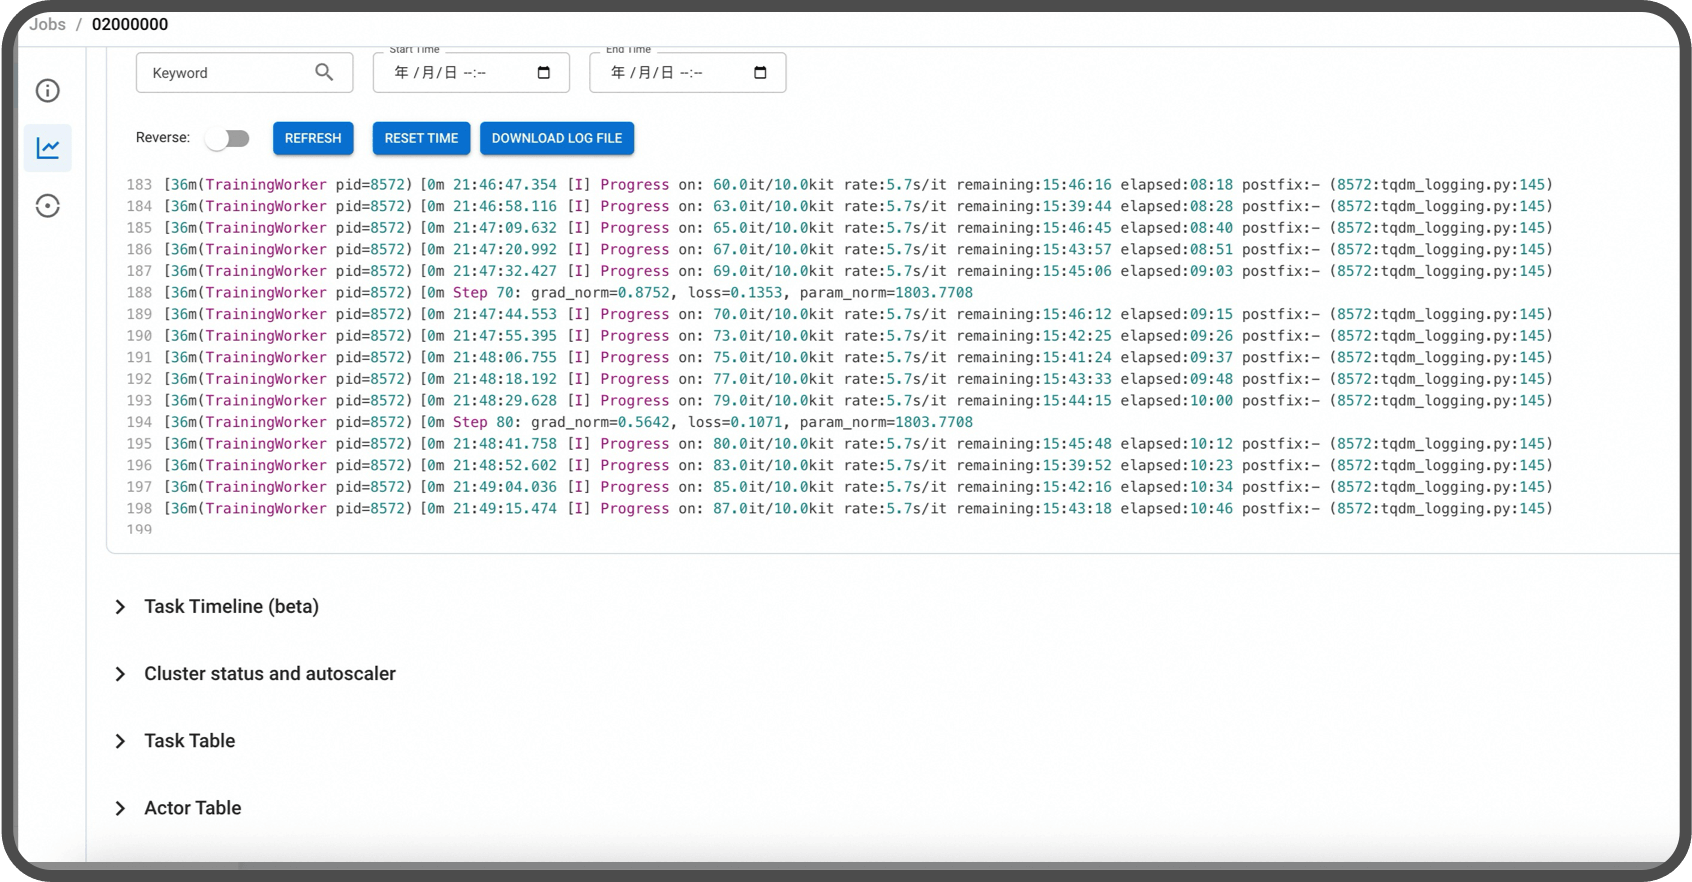
Real-Time Monitoring
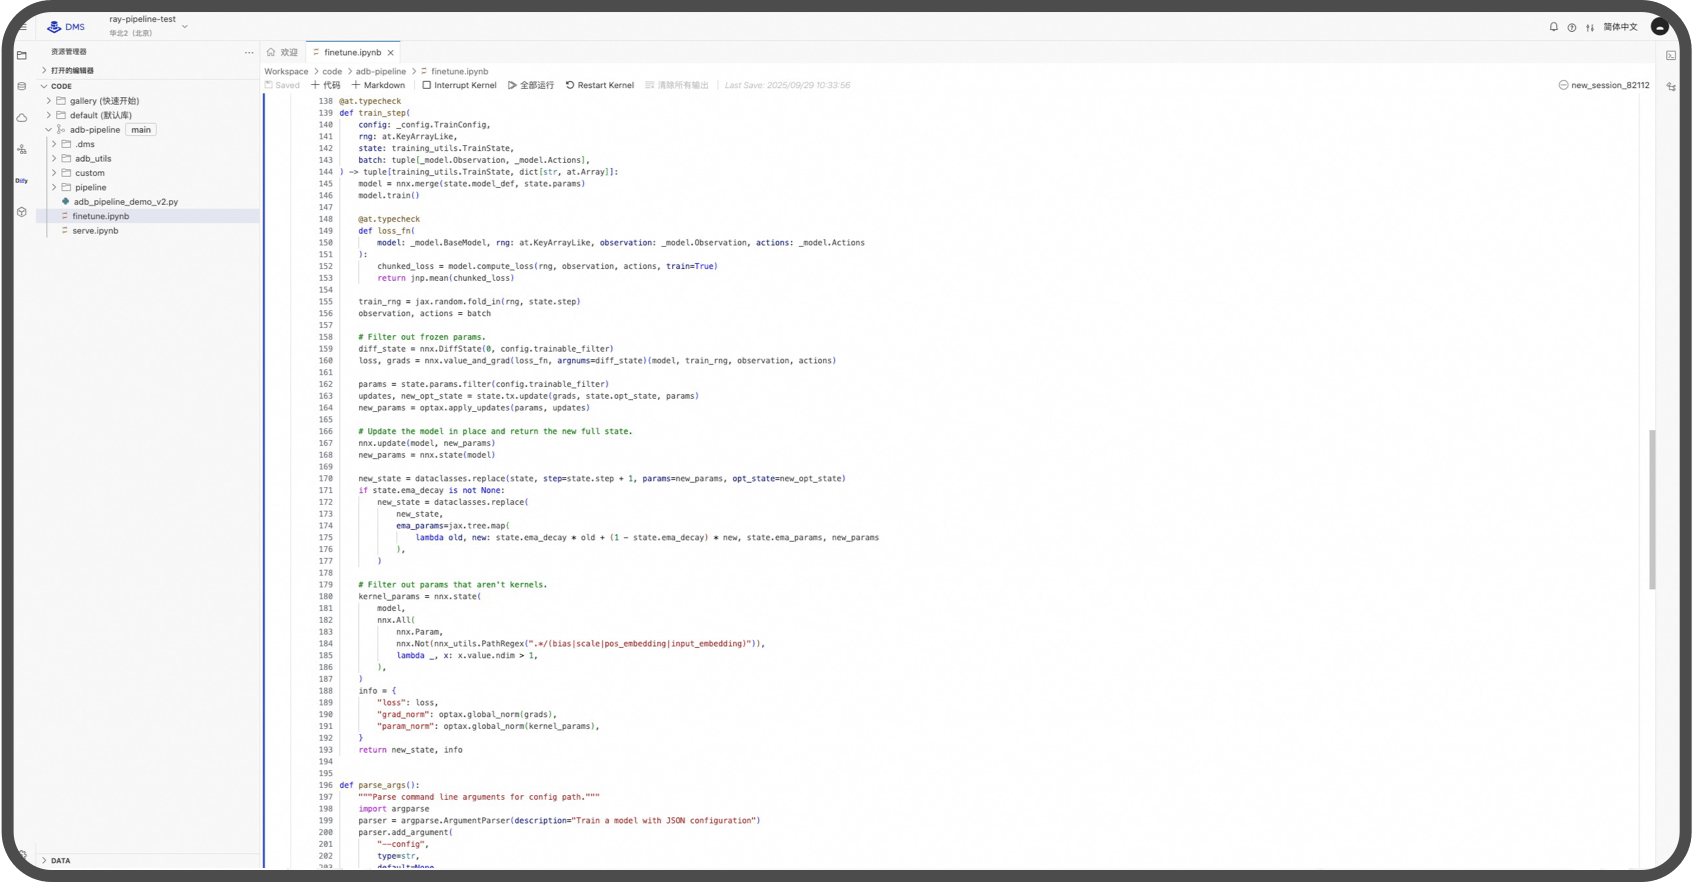
Parameter Editing
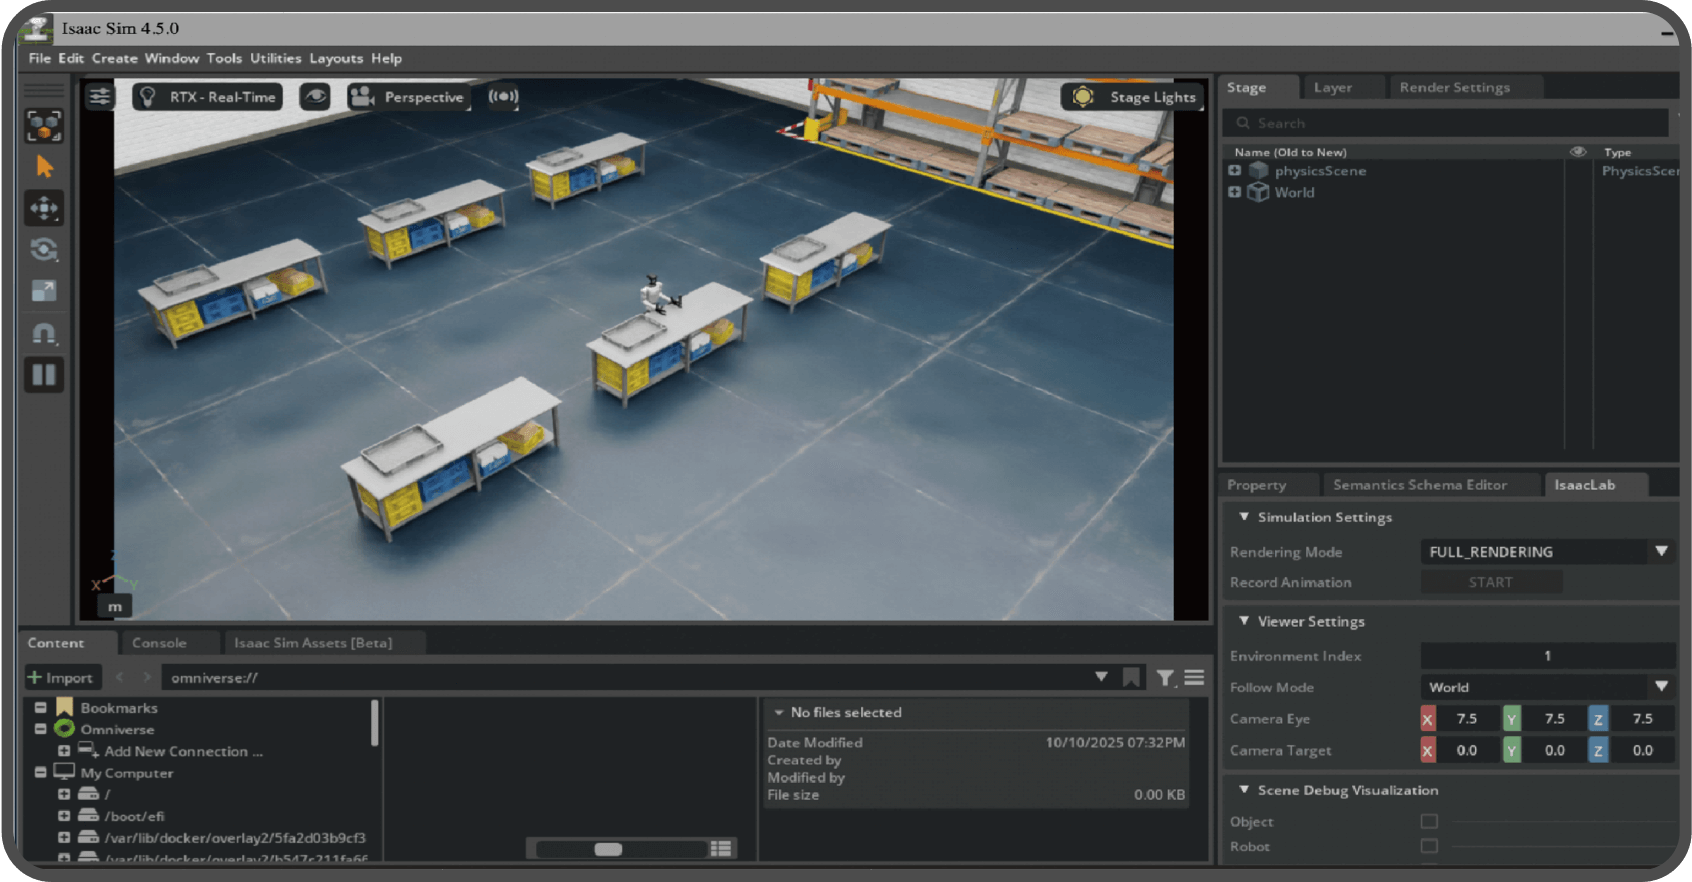
Simulation Testing
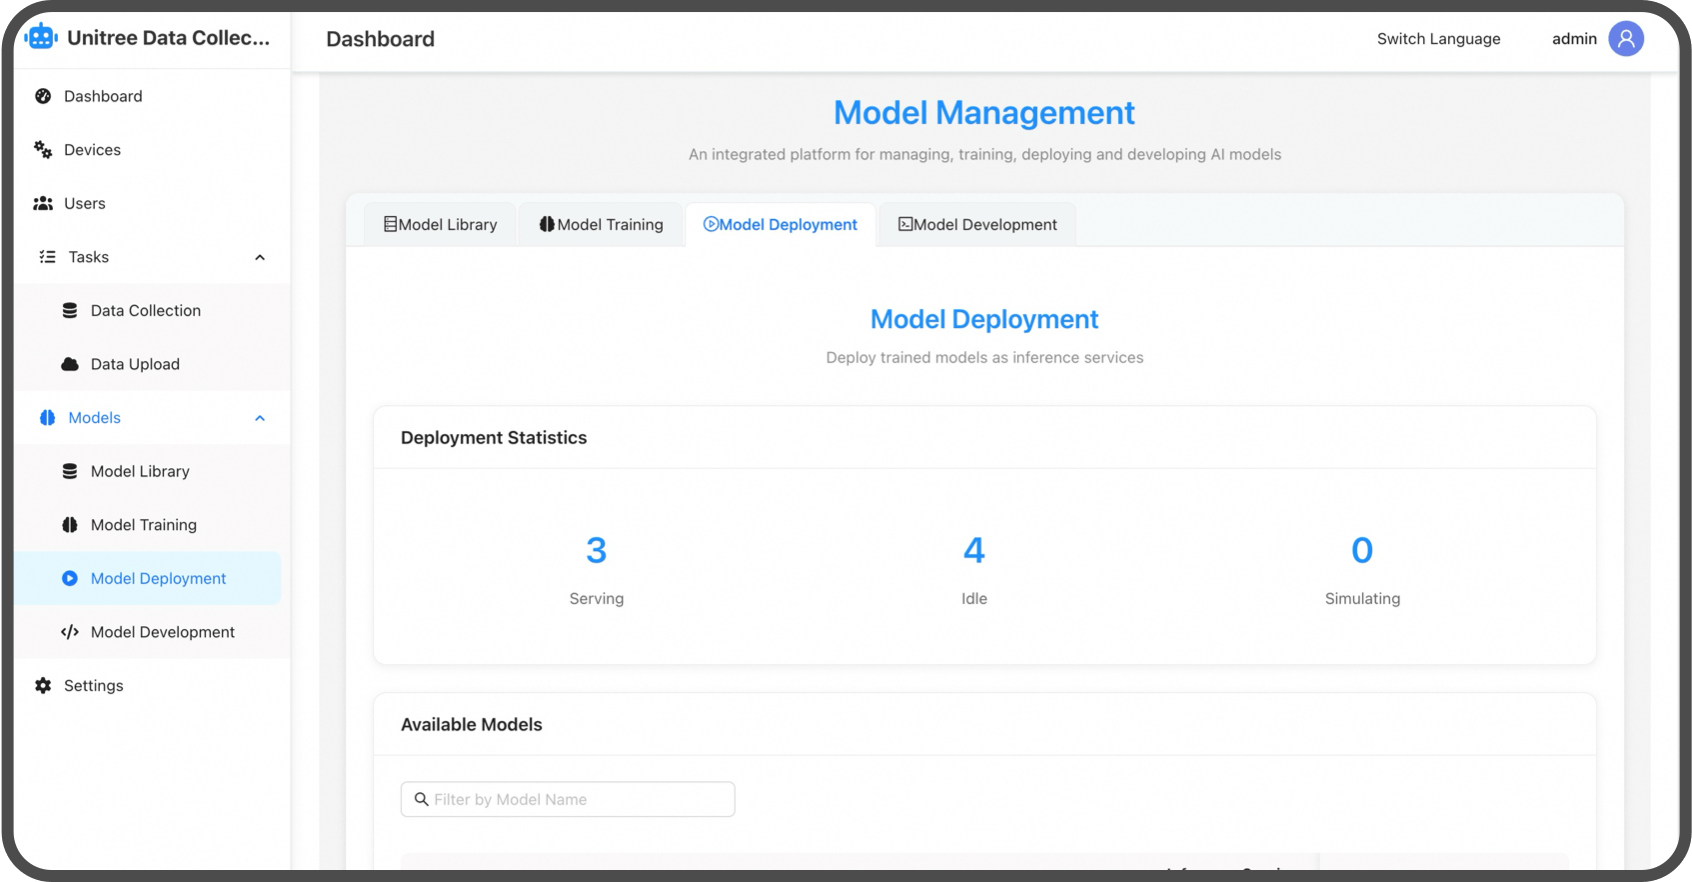
Model Export & Deployment
Application scenario
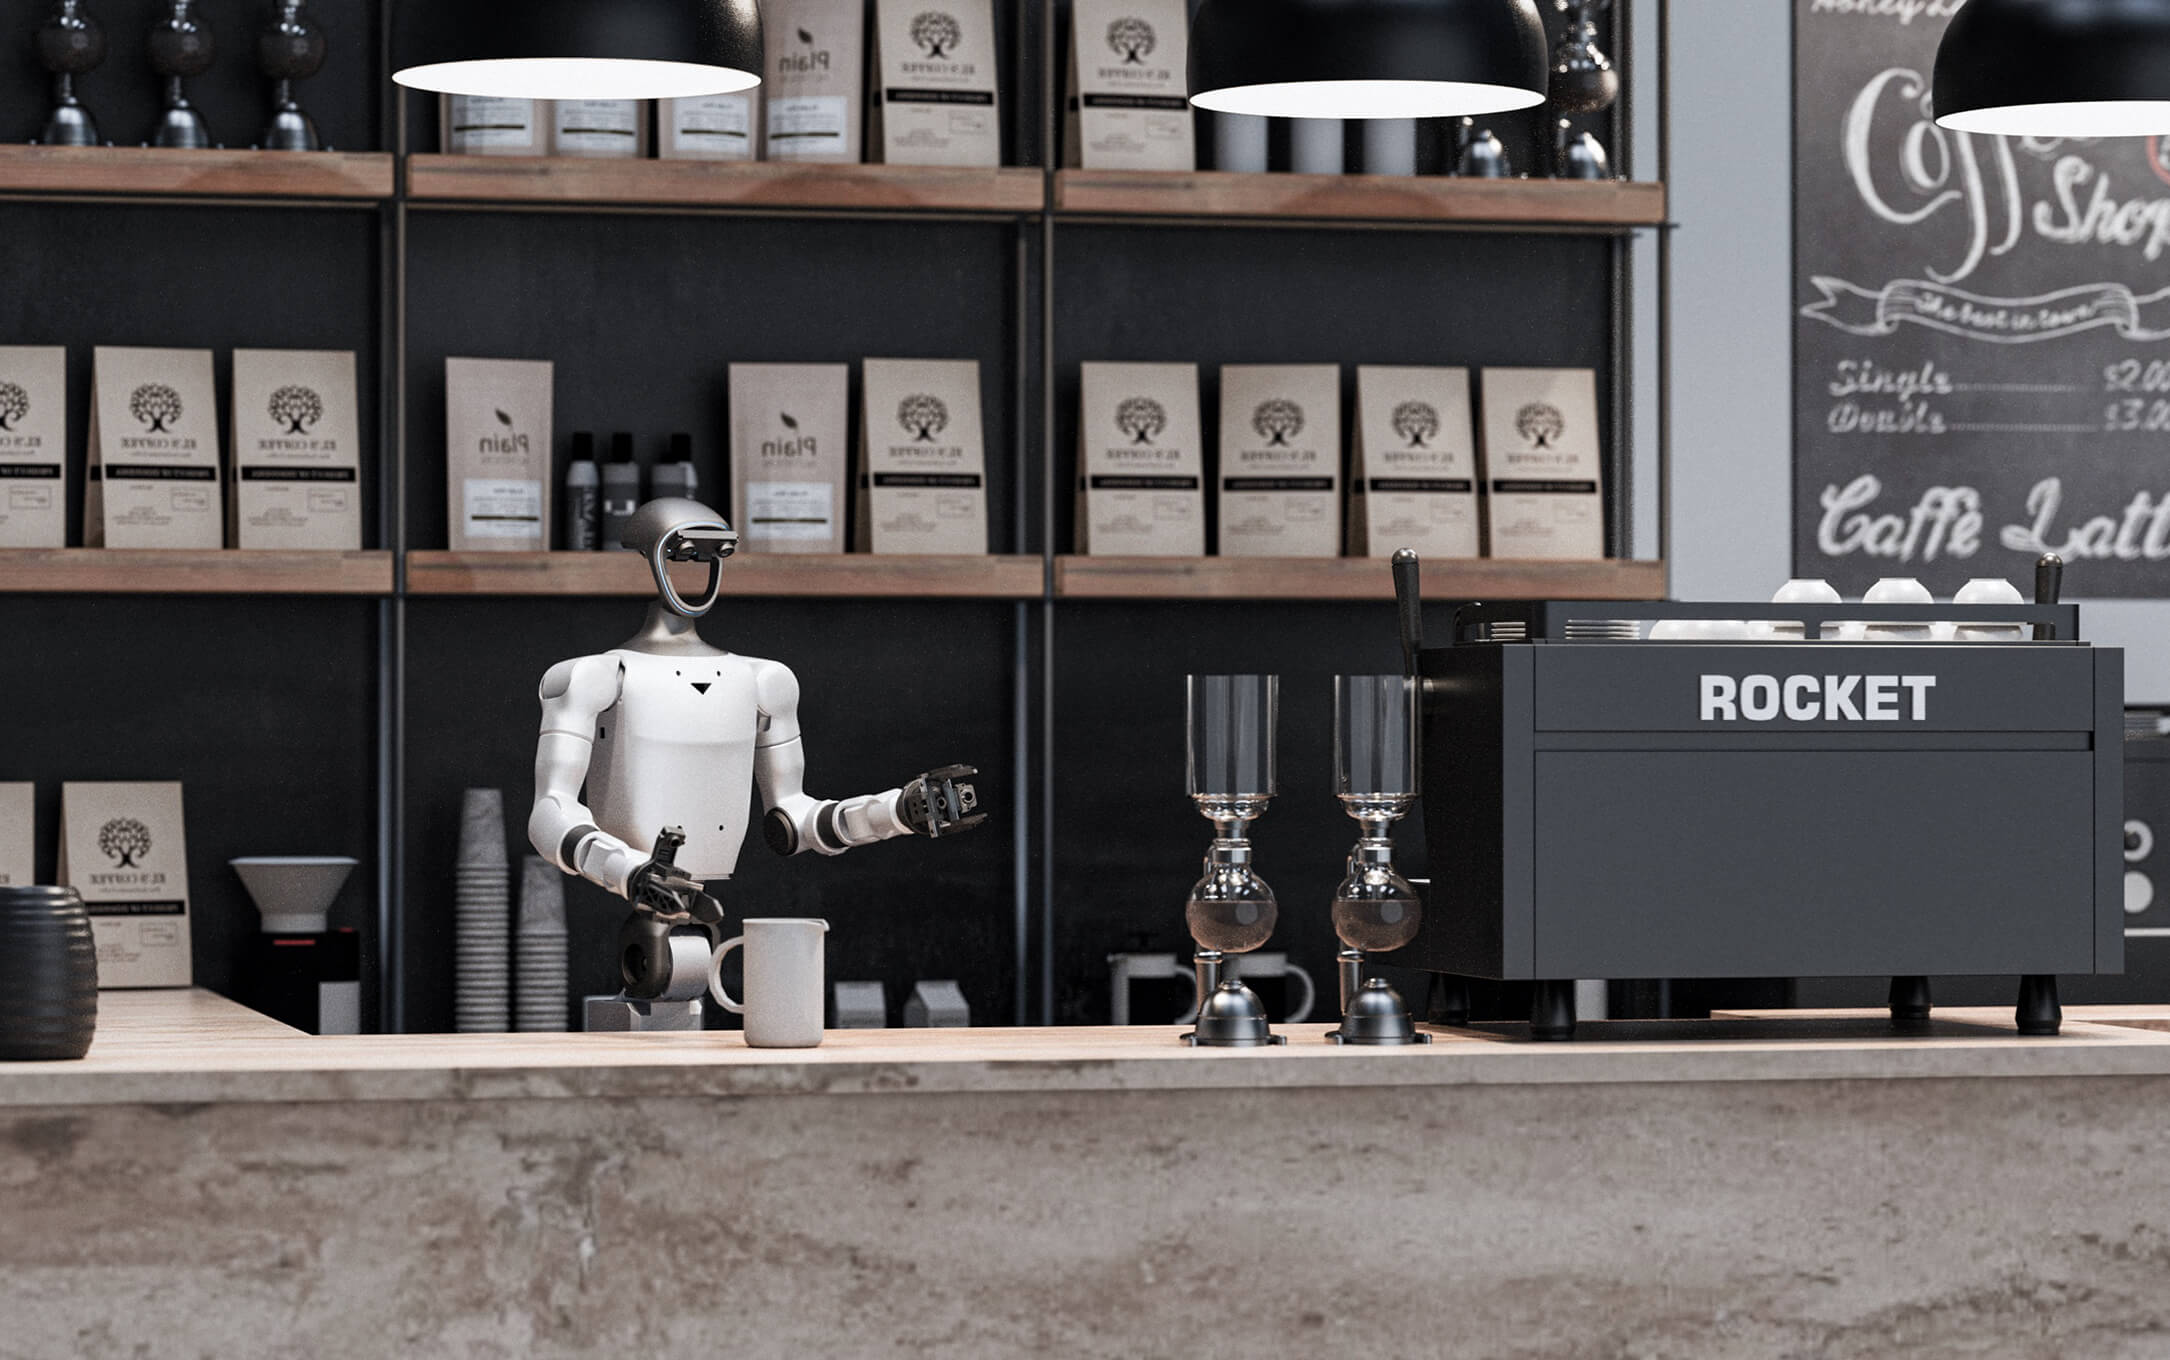
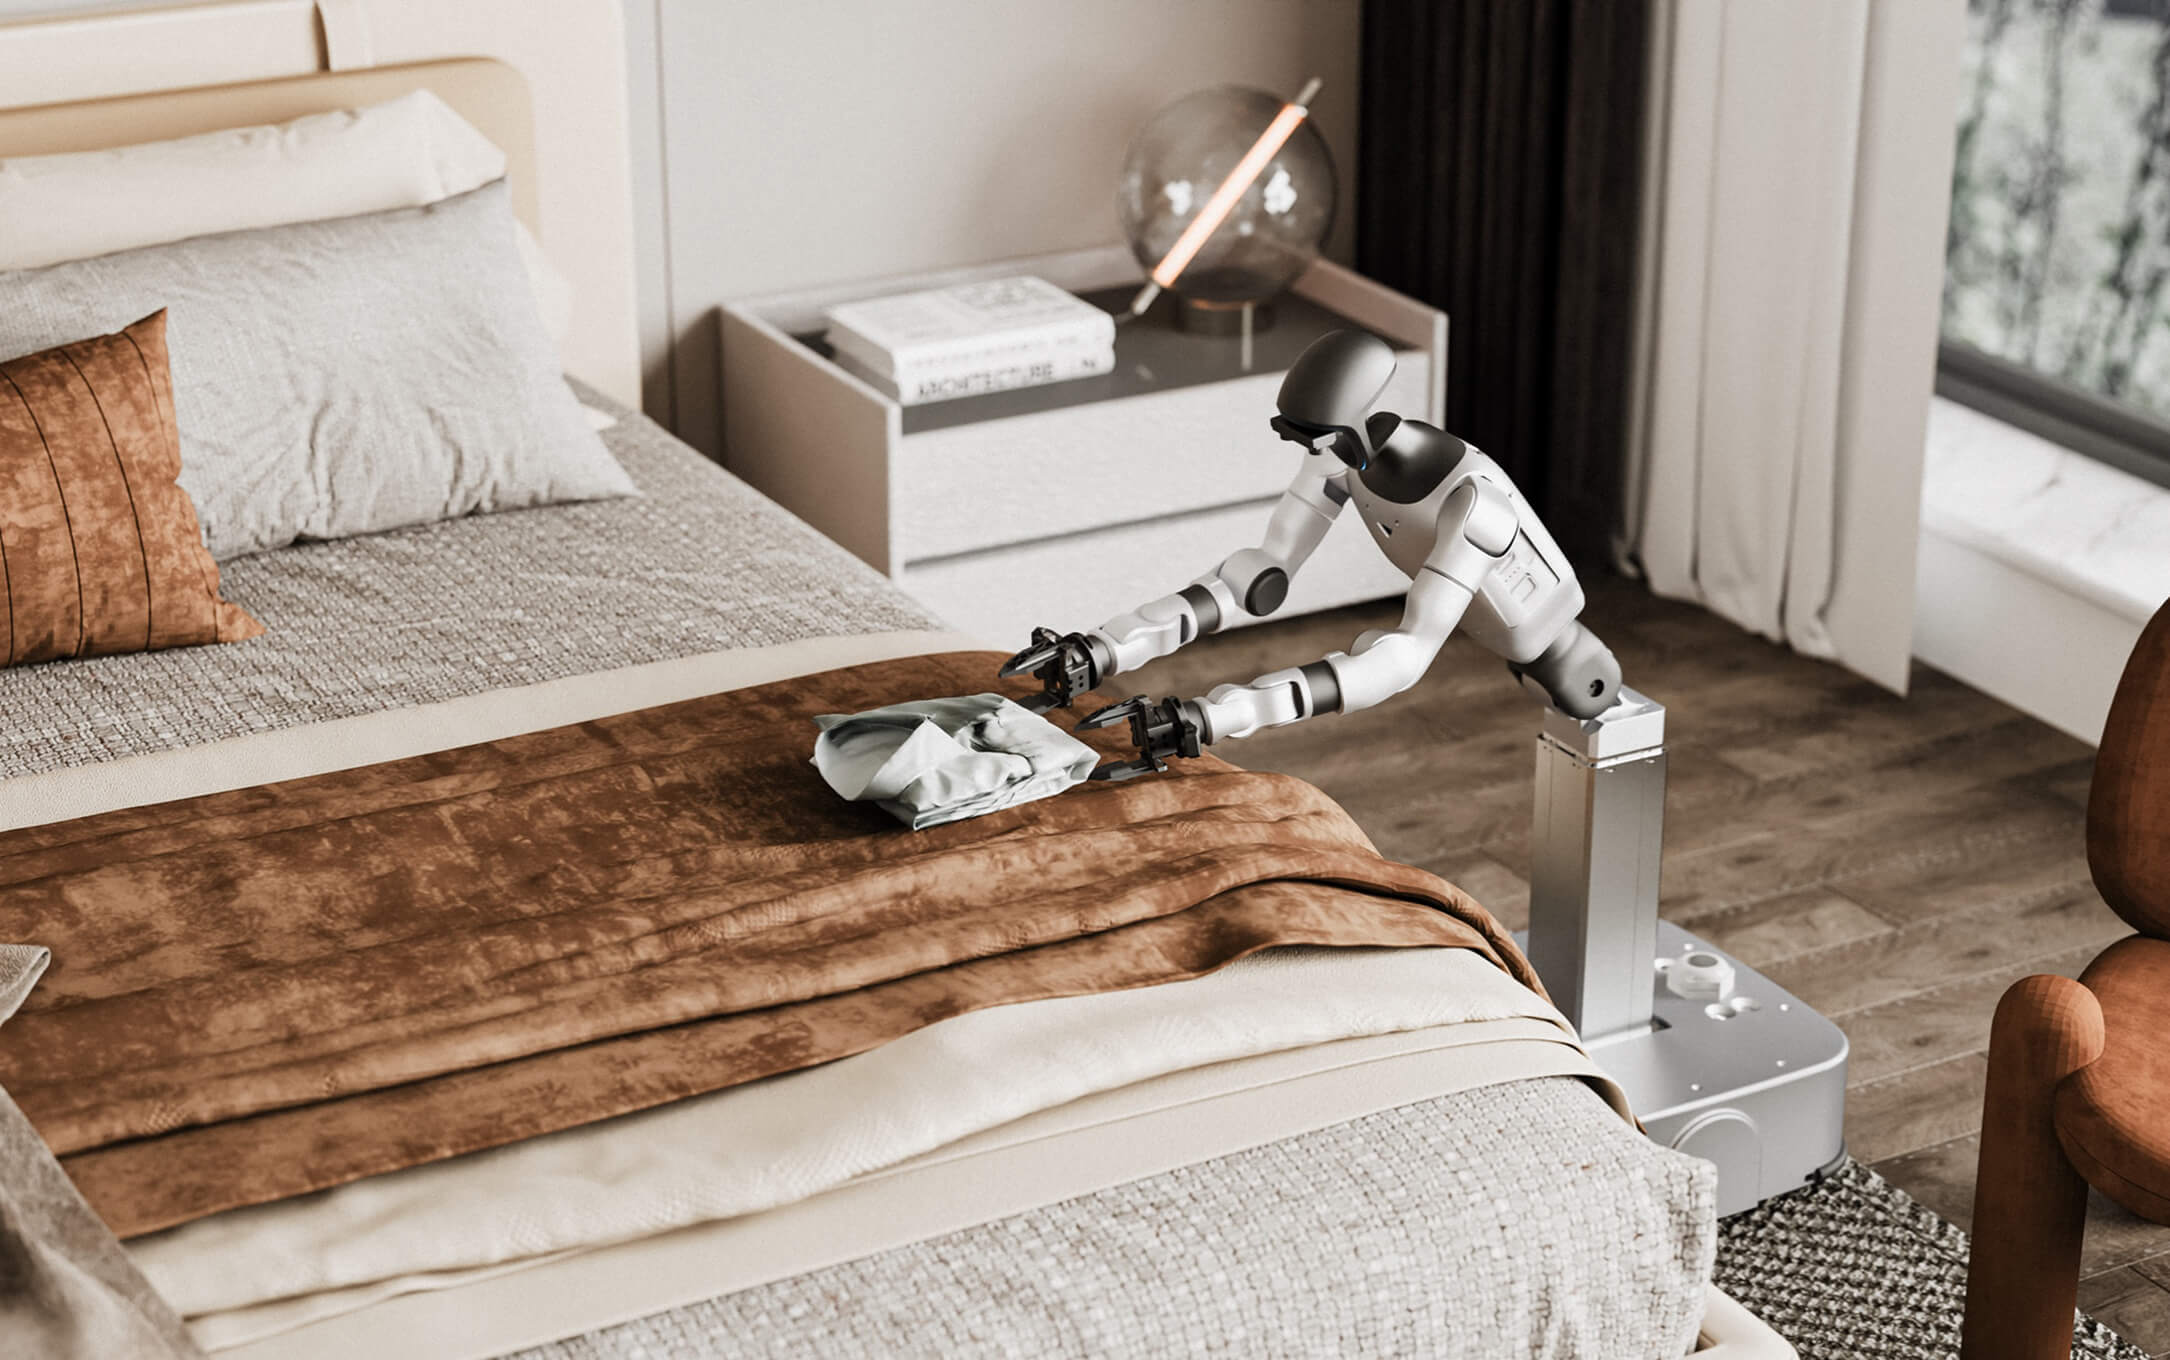
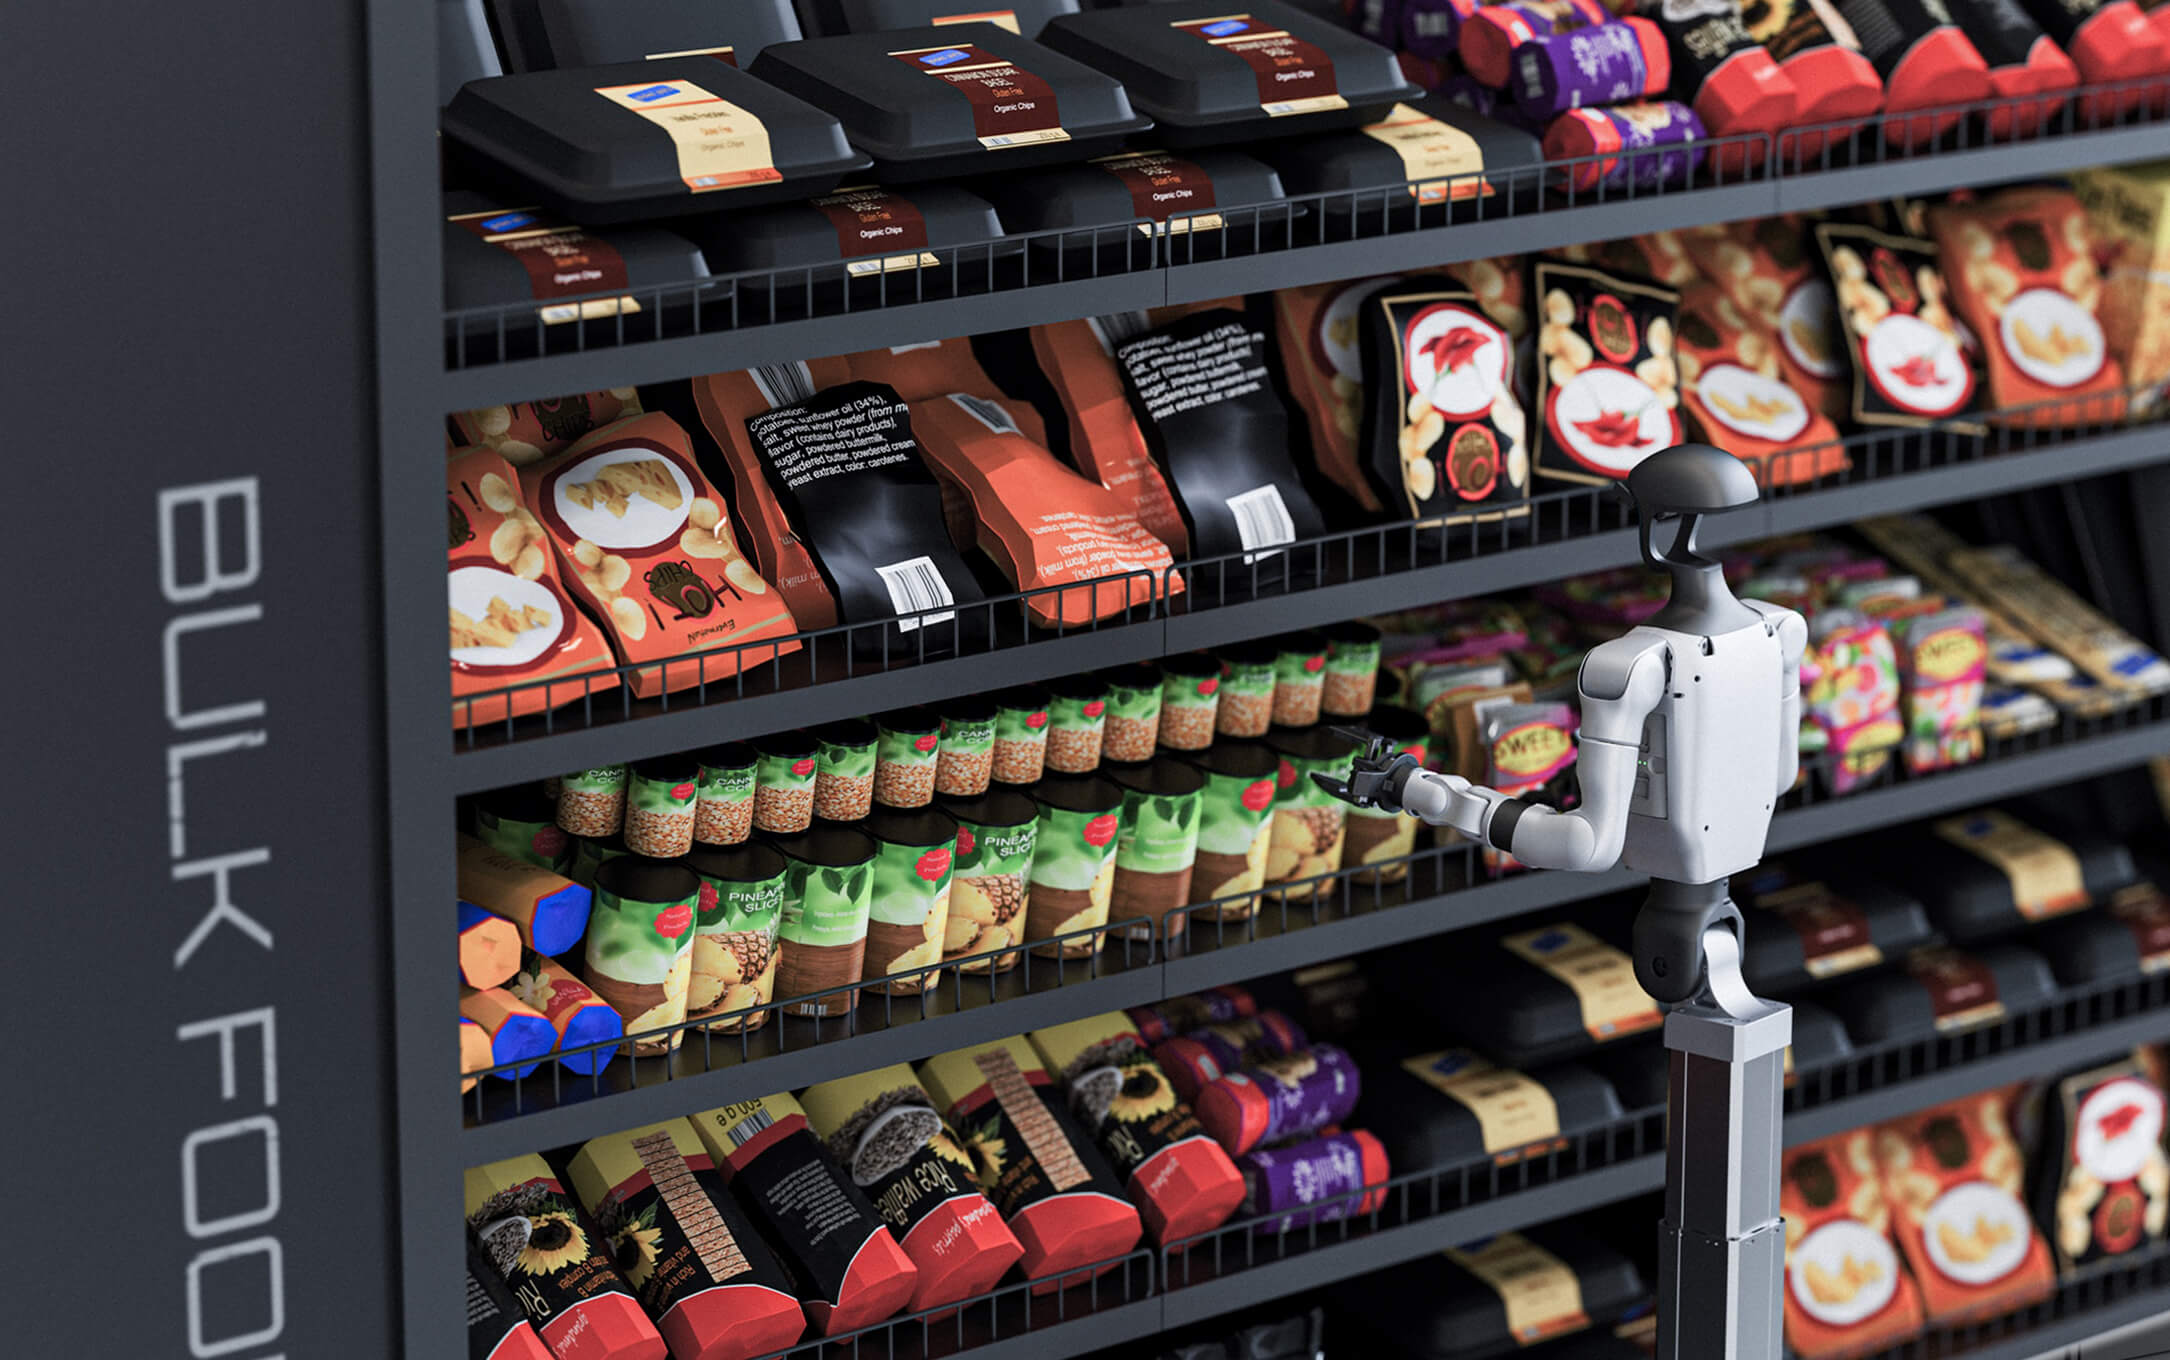
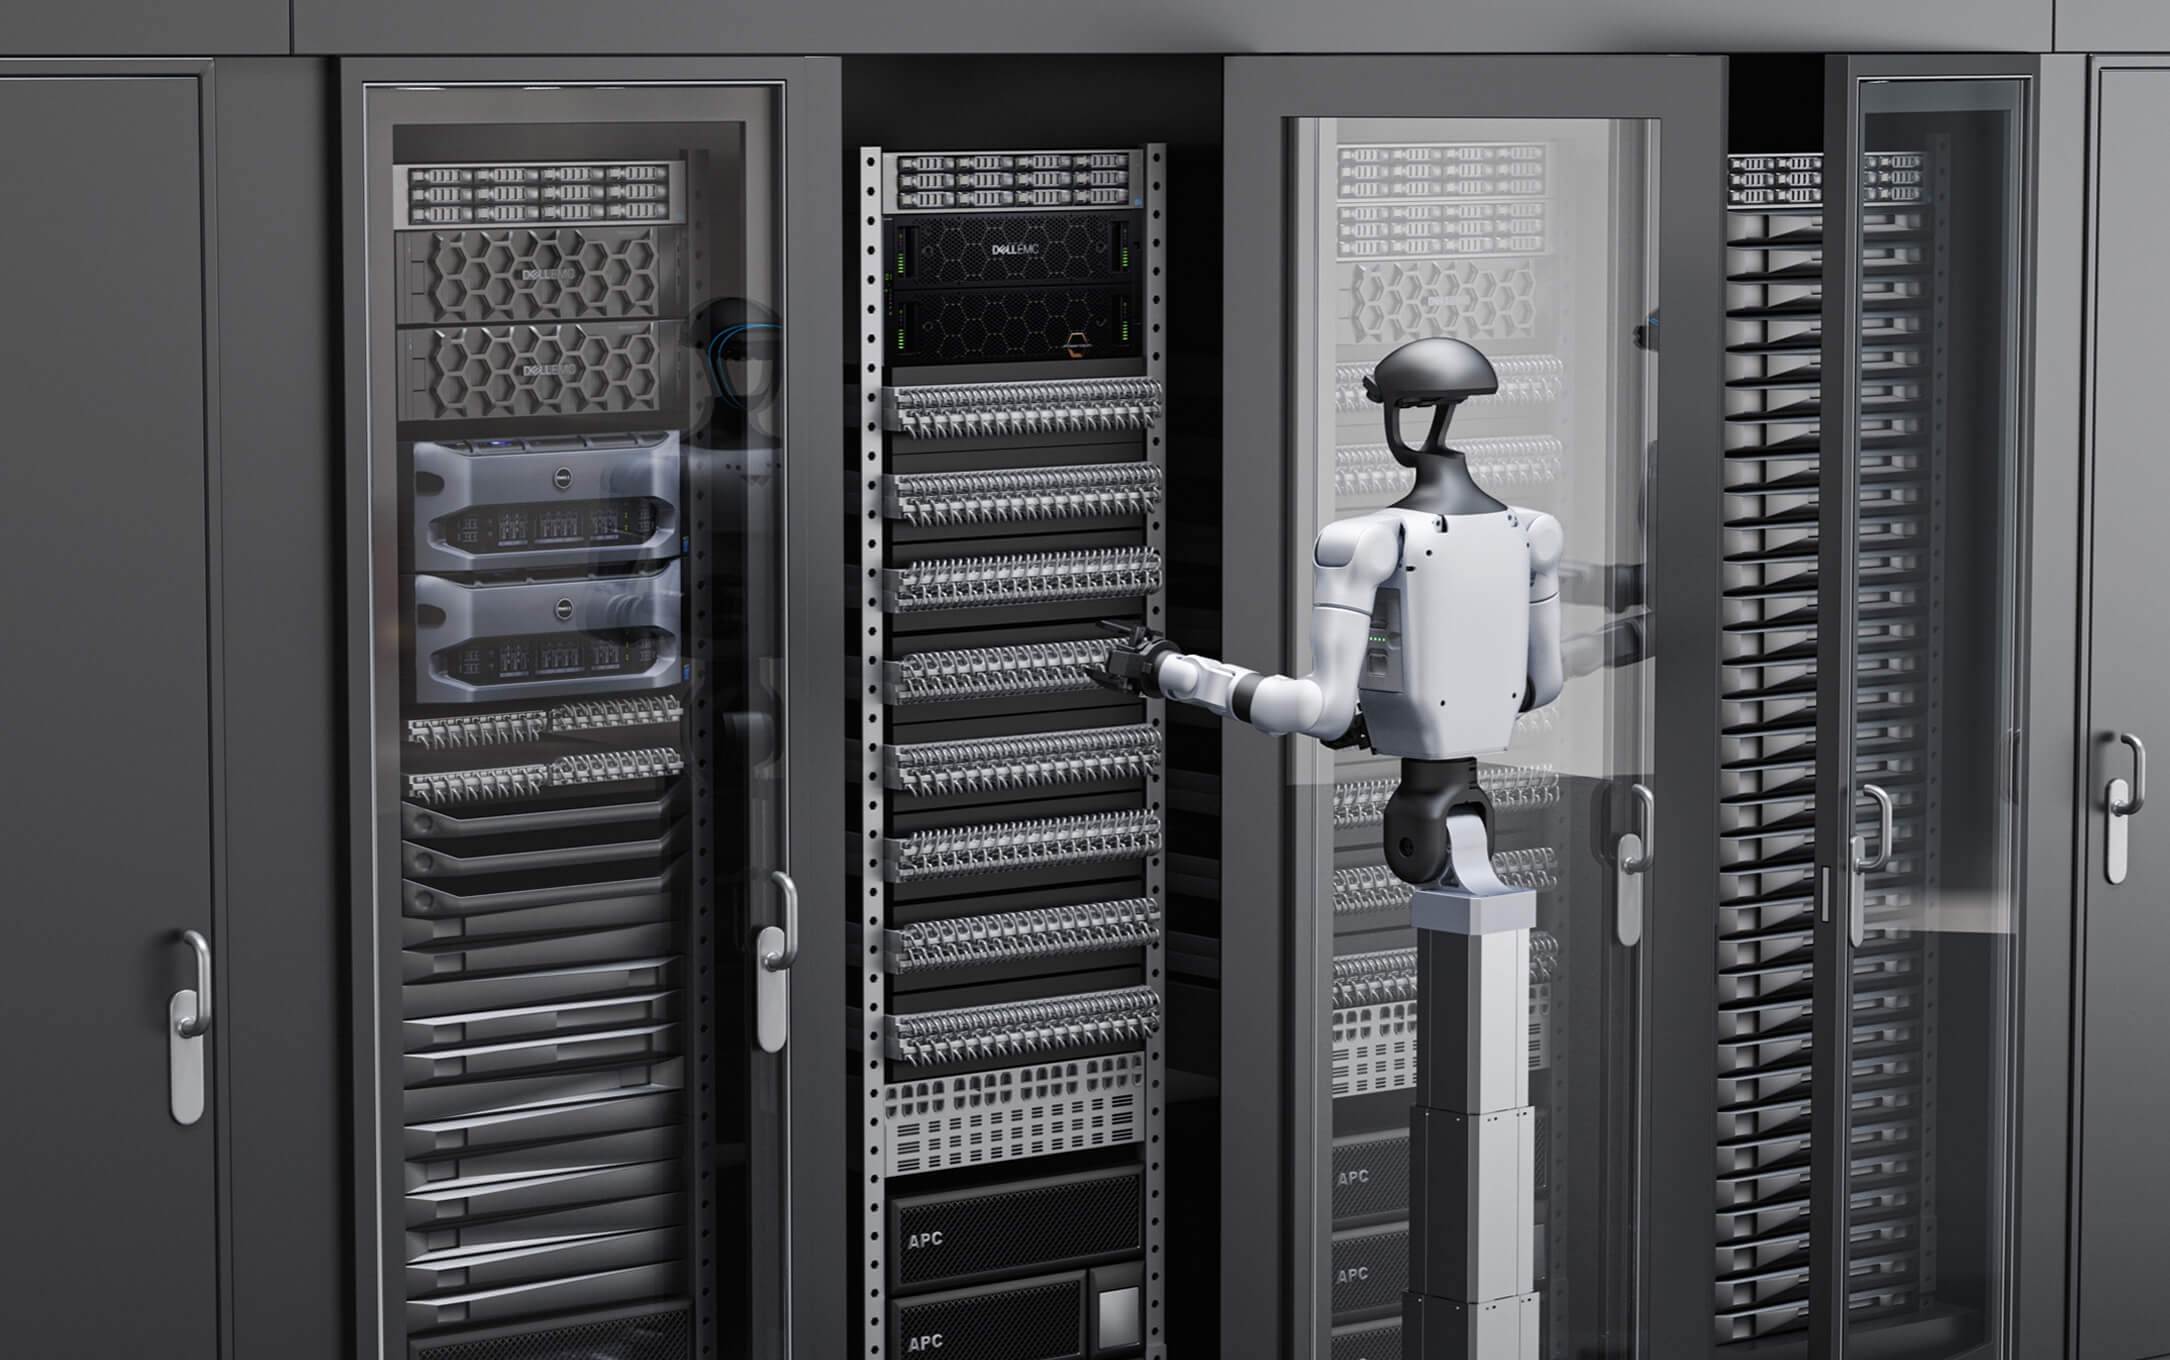
UnifoLM-WMA-0: A World-Model-Action (WMA) Framework
An open-source world-model–action architecture spanning multiple robot embodiments, designed for general-purpose robot learning. Its core is a world model that understands the physical interactions between robots and their environments.
Decision-Making Mode: Action Generation Powered by Precise Prediction
From the current environment state and task goal, it predicts upcoming physical interactions. These predictions help the policy generate actions, reducing decision errors and improving the accuracy and sensibility of motion.
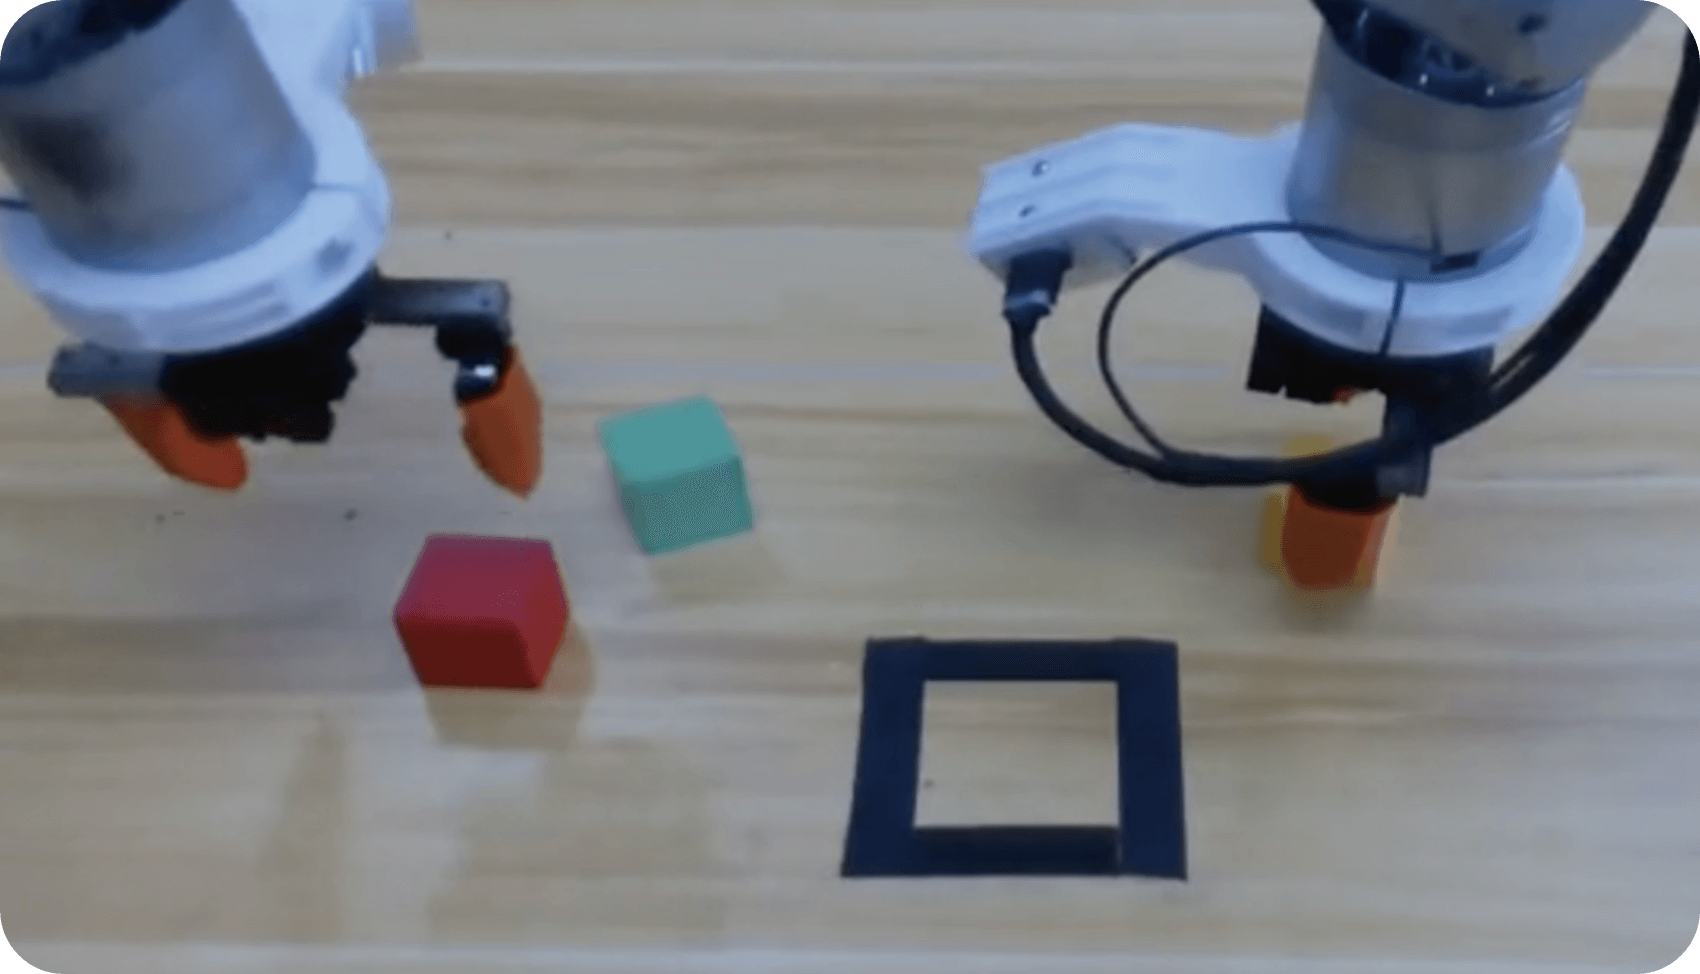
Simulation Mode: High-Fidelity Feedback for Data Generation
It works as an interactive simulator that returns realistic feedback to robot motion inputs, producing high-quality synthetic data that enriches training and speeds up learning.
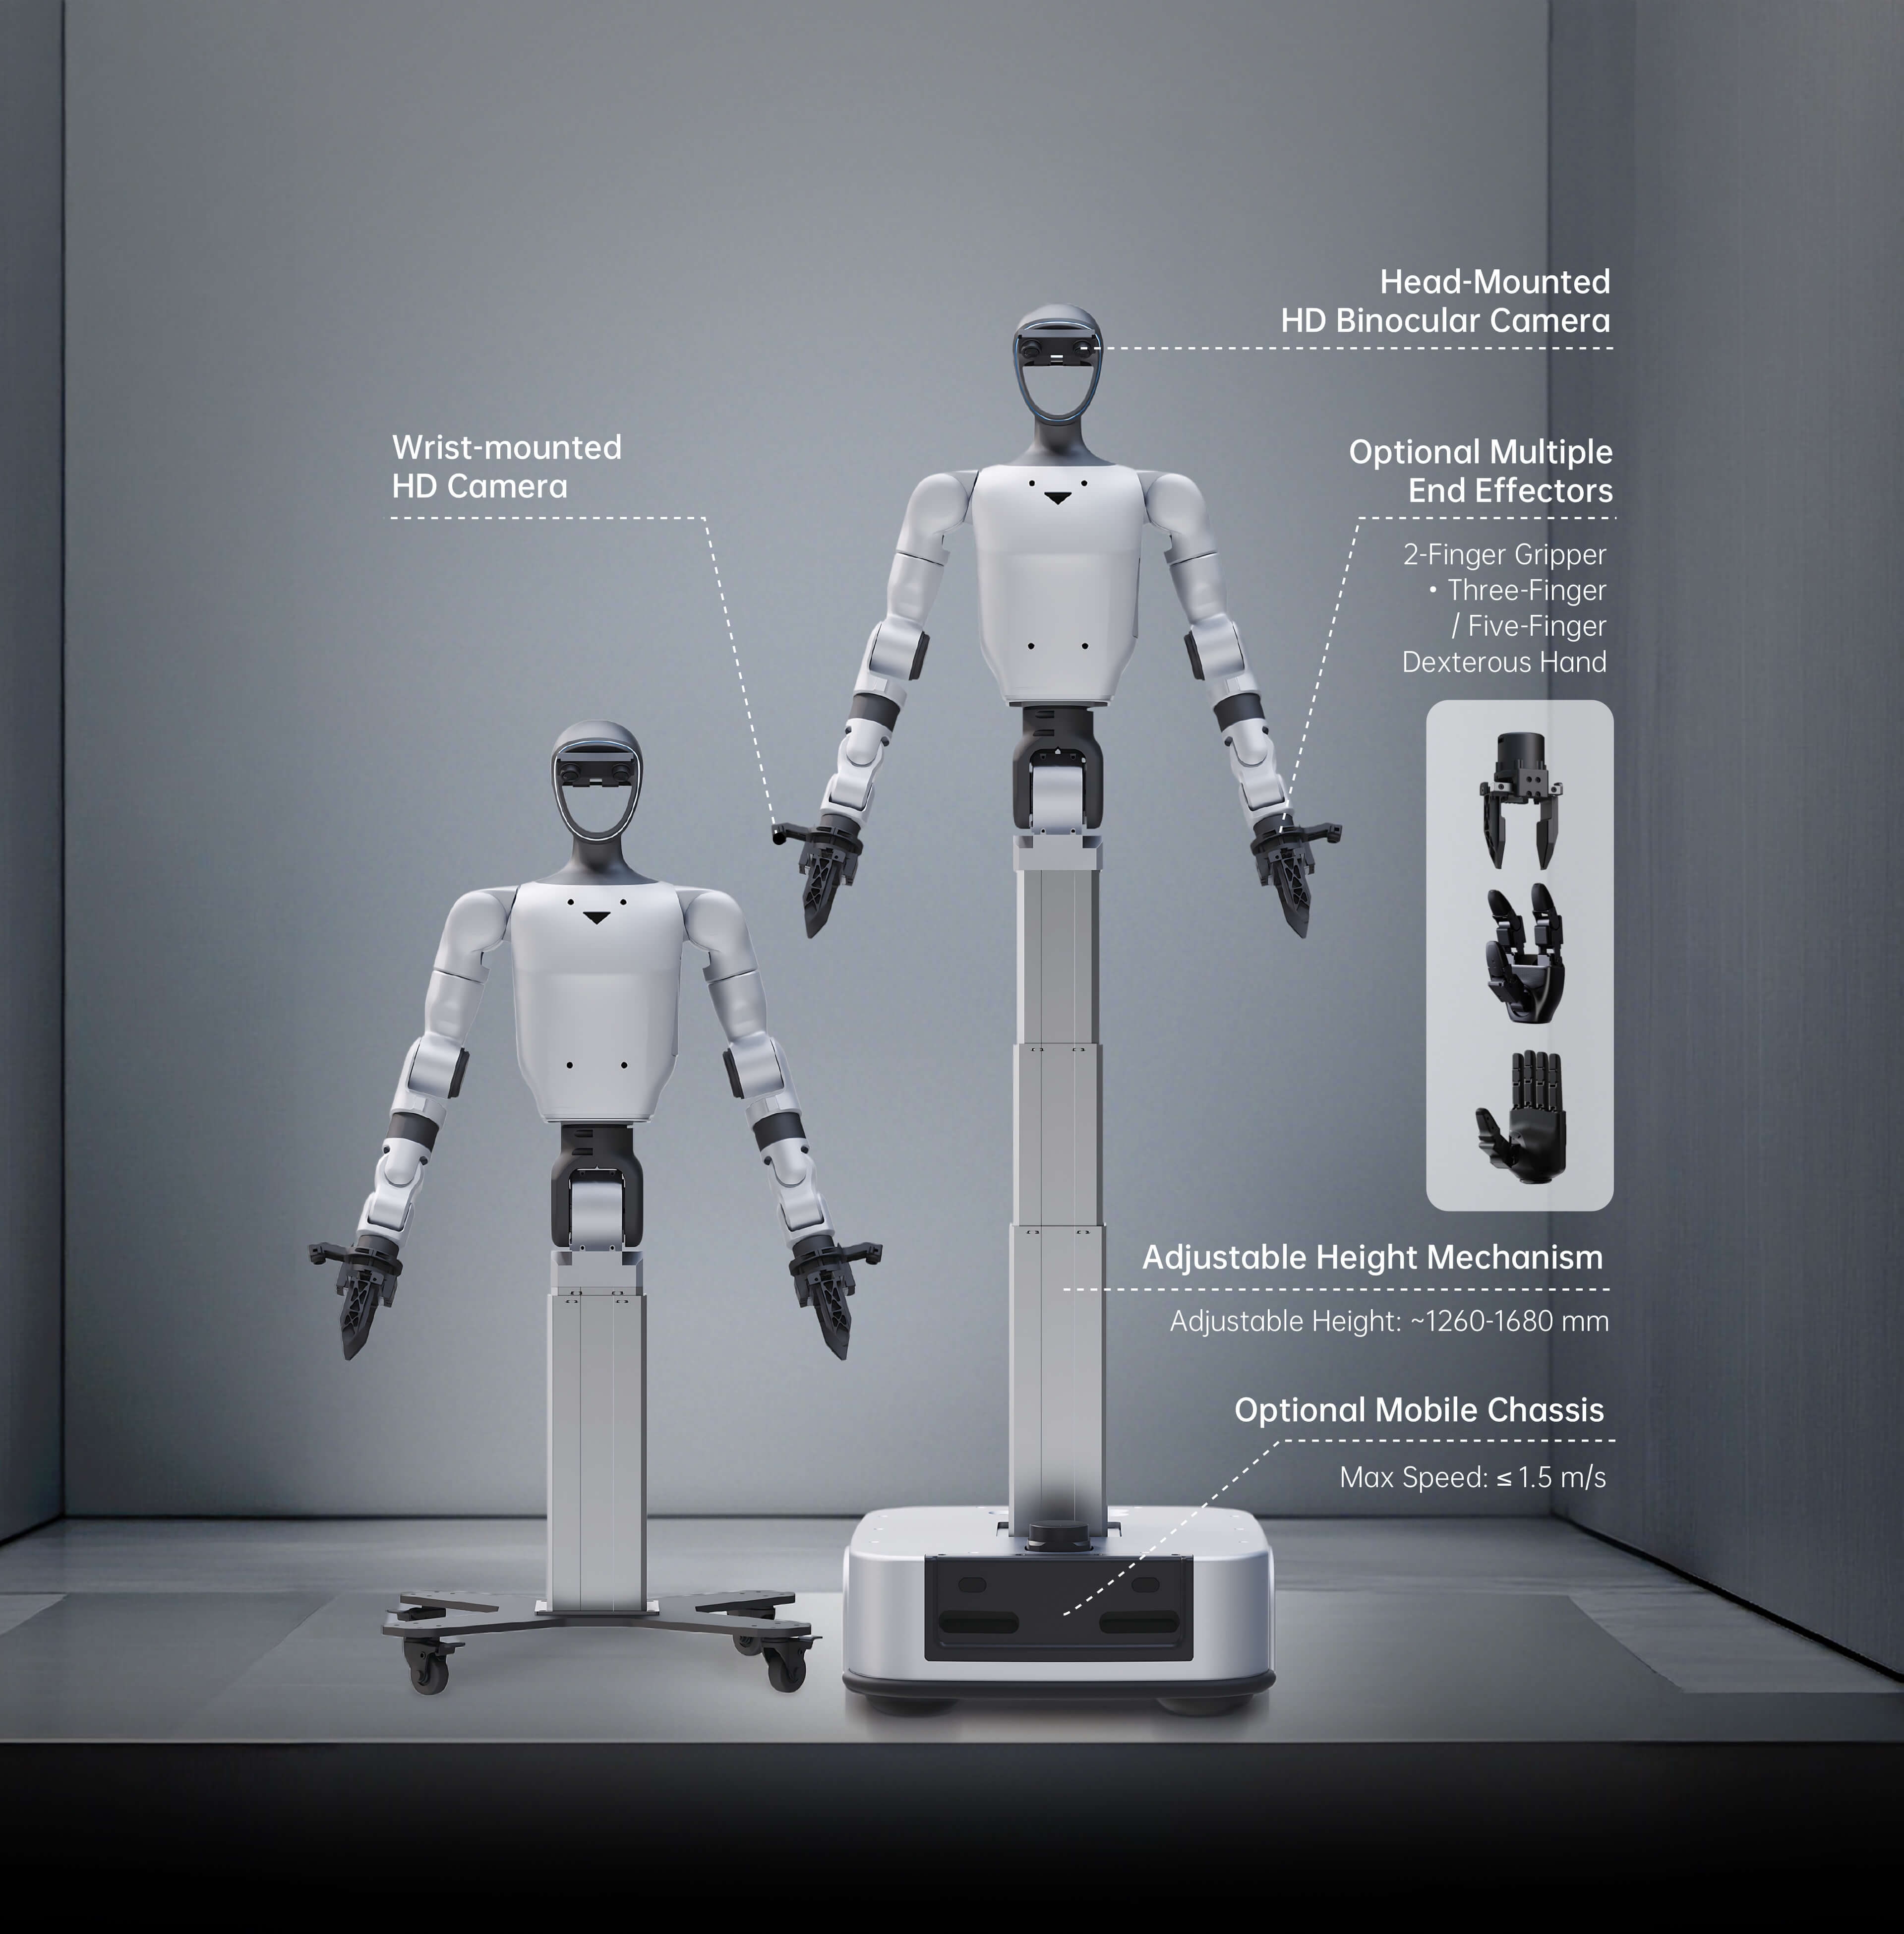
Technical Specifications
| Dimensions (HxWxD) | Min ~1260x525x570mm, Max ~1680x525x570mm |
|---|---|
| Weight (w/ battery) | ~90kg |
| DOF | 19 total (Arm 7*2 + Waist 2 + Column 1 + Base 2 = 19), 7 per arm |
| Payload / Reach | Payload: ~3kg, Reach: ~0.45m |
| Waist | 2 DOF, Range: Z ±155° / Y -2.5°~+135° |
| Lift | 450mm stroke, 1mm accuracy, 60mm/s max speed |
| Max operating height | ~2m |
| Sensors | Multiple perception sensors |
|---|---|
| Cooling | Local air cooling |
| Power | Base battery or charging pile; standard base battery x1, base direct-charge adapter x1 and charging pile x1 included |
| Runtime | 6h (Base) |
| Chargers | 51V 10A (Base pile) |
| Compute | 8-core CPU, NVIDIA Jetson Orin 16G (100 Tops) |
| I/O | 4-mic array, 5W speaker, Wifi 6, BT 5.2 |
| Control | Handheld remote included |
| Software | OTA upgrades, secondary dev support |
| Note | The upper body of this model cannot hold a battery |
| Head Binocular (1x) | FOV H:115°/V:80°/D:125°, Res: 3840x1200 |
|---|---|
| Wrist HD (2x) | FOV H:130°/V:60°/D:160°, Res: 1920*1080 |
| Base | 1x Laser Radar (LiDAR), 2x Depth Cameras, Physical Collision Sensor, Low-lying Obstacle Recognition Sensor |
| Size | 570x525x197mm |
|---|---|
| DOF | 2 |
| Drive | Dual-wheel differential, supports in-place 360° rotation |
| Speed | 1.5m/s |
| Power | Base battery (30Ah built-in, 6h runtime) or Charging Pile (51V 10A) |
| Includes | RGB camera |
|---|---|
| Weight | Approx. 650g |
| Dimensions | 175mm x 88mm x 77mm |
| Single Hand DOF | 7 (Thumb 3 DOF, Index finger 2 DOF, Middle finger 2 DOF) |
| Operating Voltage | 12~58V |
| Static Current | [email protected] |
| Communication Interface | USB |
| Wrist RGB Camera | FOV D:130° H:120° V:81°; Resolution: 1920x1080 |
| Whole Machine DOF | 33 (Single Arm 7*2 + Waist 2 + Column 1 + Dexterous Hand 7*2 + Base 2 = 33) |
|---|---|
| Warranty | 12-month whole machine warranty |
Frequently Asked Questions
What is the G1-D Flagship B?
The G1-D Flagship B is the mobile-base flagship of the G1-D humanoid robot platform: a 7-DOF dual-arm upper body, 2-DOF waist, lifting column and a dual-wheel differential base, fitted with Dex3-1 Force-Controlled 3-Finger Dexterous Hand (Non-tactile). It is built around the end-to-end data and model training workflow described above.
What are the dimensions, weight and lift range of the G1-D Flagship B?
Dimensions are min ~1260x525x570mm and max ~1680x525x570mm, and the weight with battery is ~90kg. The lift has a 450mm stroke, 1mm accuracy and 60mm/s max speed, with a max operating height of ~2m.
What end effector does the G1-D Flagship B come with?
It includes all functions of Flagship A and adds the Dex3-1 force-controlled 3-finger dexterous hand (non-tactile) with an RGB camera: approx. 650g, 175mm x 88mm x 77mm, 7 DOF per hand (thumb 3, index finger 2, middle finger 2), 12~58V, USB.
How many degrees of freedom does the G1-D Flagship B have?
The whole machine has 33 DOF (Single Arm 7*2 + Waist 2 + Column 1 + Dexterous Hand 7*2 + Base 2 = 33). The robot itself has 19 DOF excluding the end-effector: arm 7*2, waist 2, column 1 and base 2.
What are the battery runtime, base performance and warranty of the G1-D Flagship B?
The base runs about 6 hours on its built-in 30Ah battery or on the charging pile (51V 10A), moves at up to 1.5m/s with a dual-wheel differential drive and in-place 360° rotation, and carries a LiDAR, 2 depth cameras, a physical collision sensor and a low-lying obstacle sensor. The compute is an 8-core CPU plus NVIDIA Jetson Orin 16G (100 Tops). The warranty is 12 months for the whole machine.
The full sheet
Related products
-
·LND·00
-
·LND·01
-
·LND·02
-
·LND·03

There are no reviews yet.