
Unitree H2-D Flagship I
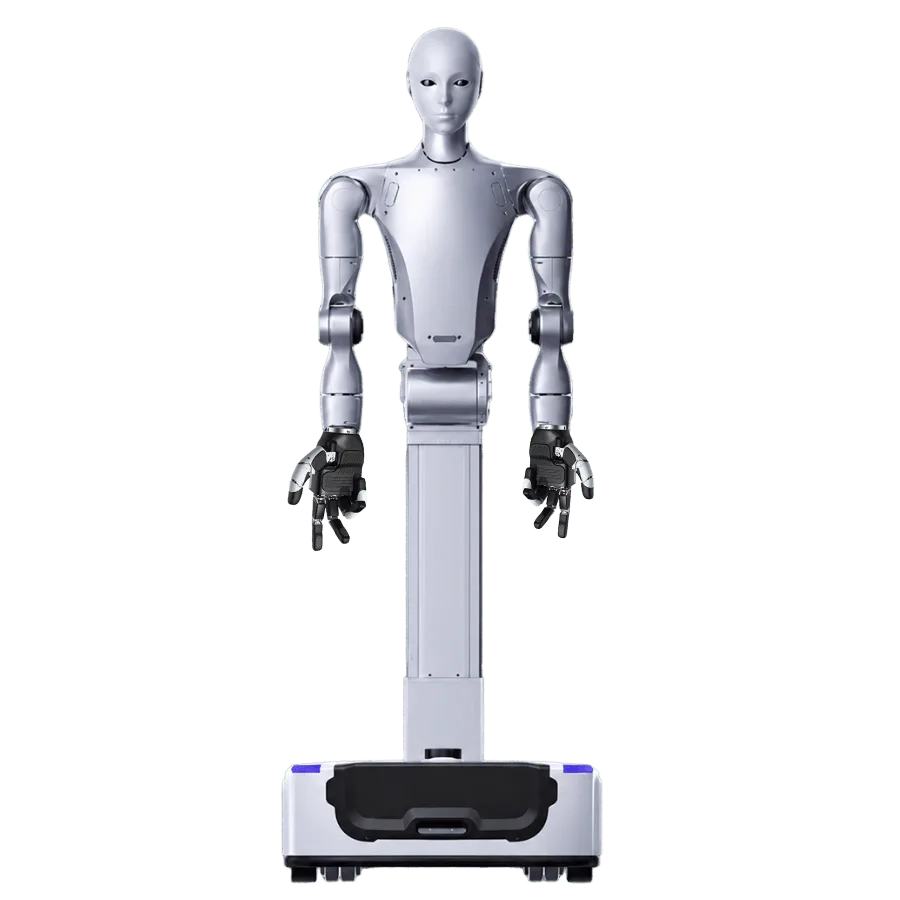
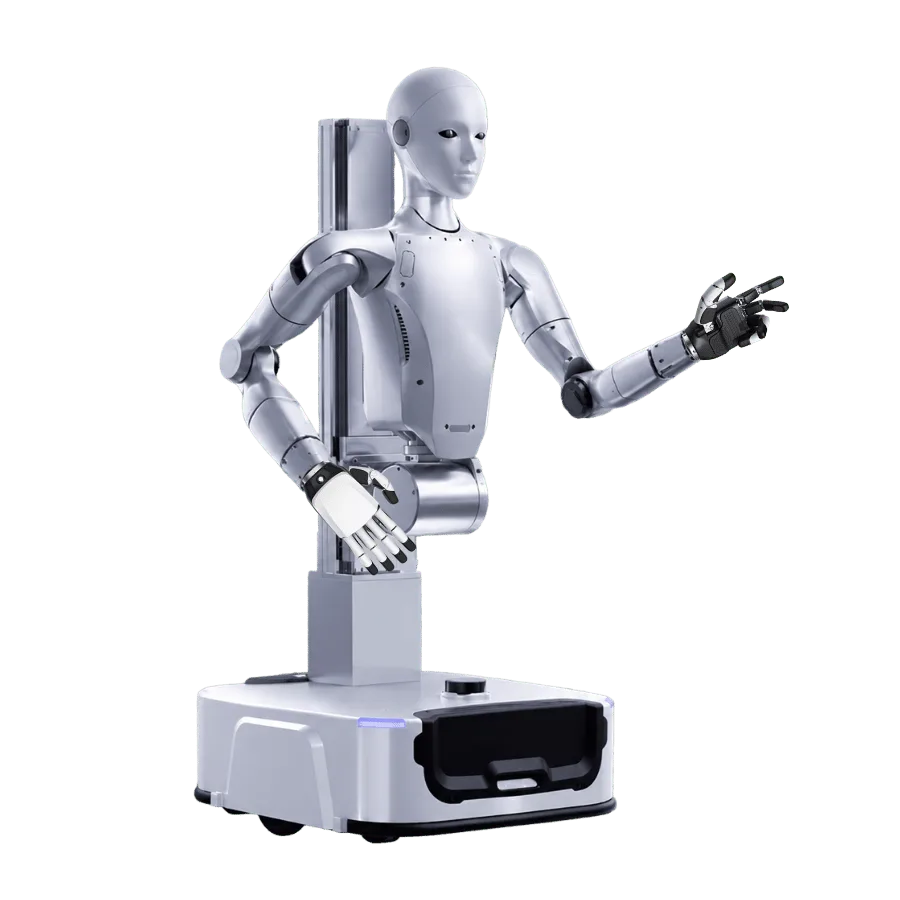
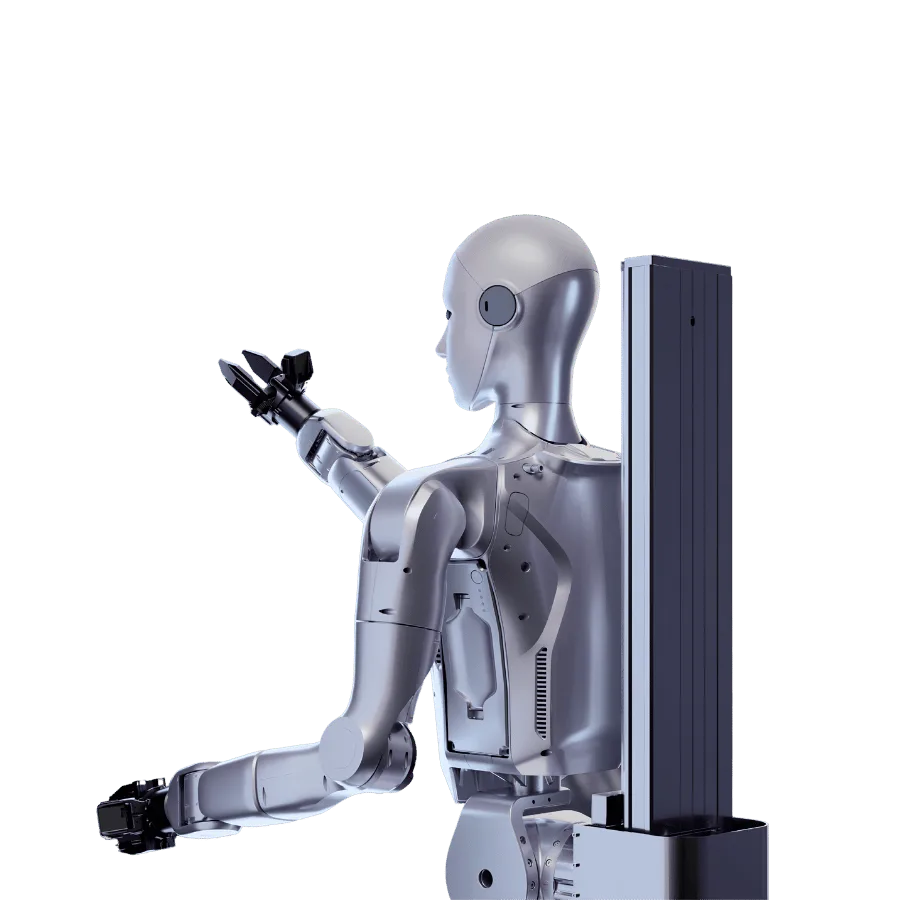
- Mobile dual-arm semi humanoid robot with a vertical lift column and wheeled chassis for industrial, commercial, research and embodied AI use
- Variant: H2-D Flagship I with Inspire E2 five-finger hand with 17 tactile sensors – 32 DOF in total
- Other variants: A Dex1-1 gripper; B Dex3-1 3-finger; C Dex3-1 tactile; D Dex5-1 5-finger; E Dex5-1P tactile; F Revo 2 Basic; G Revo 2 Touch; H Inspire DFQ; J Revo 3 U21; K Revo 3 U21T; L Revo 3 U21VT; M WUJI Hand 2
- Inspire E2: 6 DOF, 12 joints, 17 tactile sensors (0–30N), thumb 30N and four-finger 28N fingertip grip force, 0.8s palm closing time
- 20 DOF body: arms 7×2, waist 1 (pitch 0°–115°), head 2, column 1 (lift), chassis 2; 1200–1700mm height range, 576×620mm footprint, 135kg with battery
- Chassis: up to 1.5m/s, 360° in-place rotation, about 0.75m turning diameter, LiDAR, depth camera, 2 collision and 2 ultrasonic sensors
- Rated 7kg arm payload (peak about 15kg), about 0.62m reach with a two-finger gripper, 0.5m lift stroke; Intel Core i5 plus i7 compute, optional Jetson Thor or Orin NX, binocular head camera, wrist cameras, WiFi 6
- 48V/30Ah (1.44kWh) removable battery, about 5h runtime with swap and auto recharge, handheld remote, visual PC, OTA updates, secondary development
- Trusted dealerDirect manufacturer partnership
- Pan-India deliveryInsured shipping, all states
- Post-sale supportTraining + service included
What makes it work
Unitree H2-D Flagship I Dual-Arm Semi Humanoid Robot
Redefining Industrial Mobile Manipulation
From Research Labs to Production Lines — Accelerating the Large-Scale Deployment of Semi Humanoid Robotics
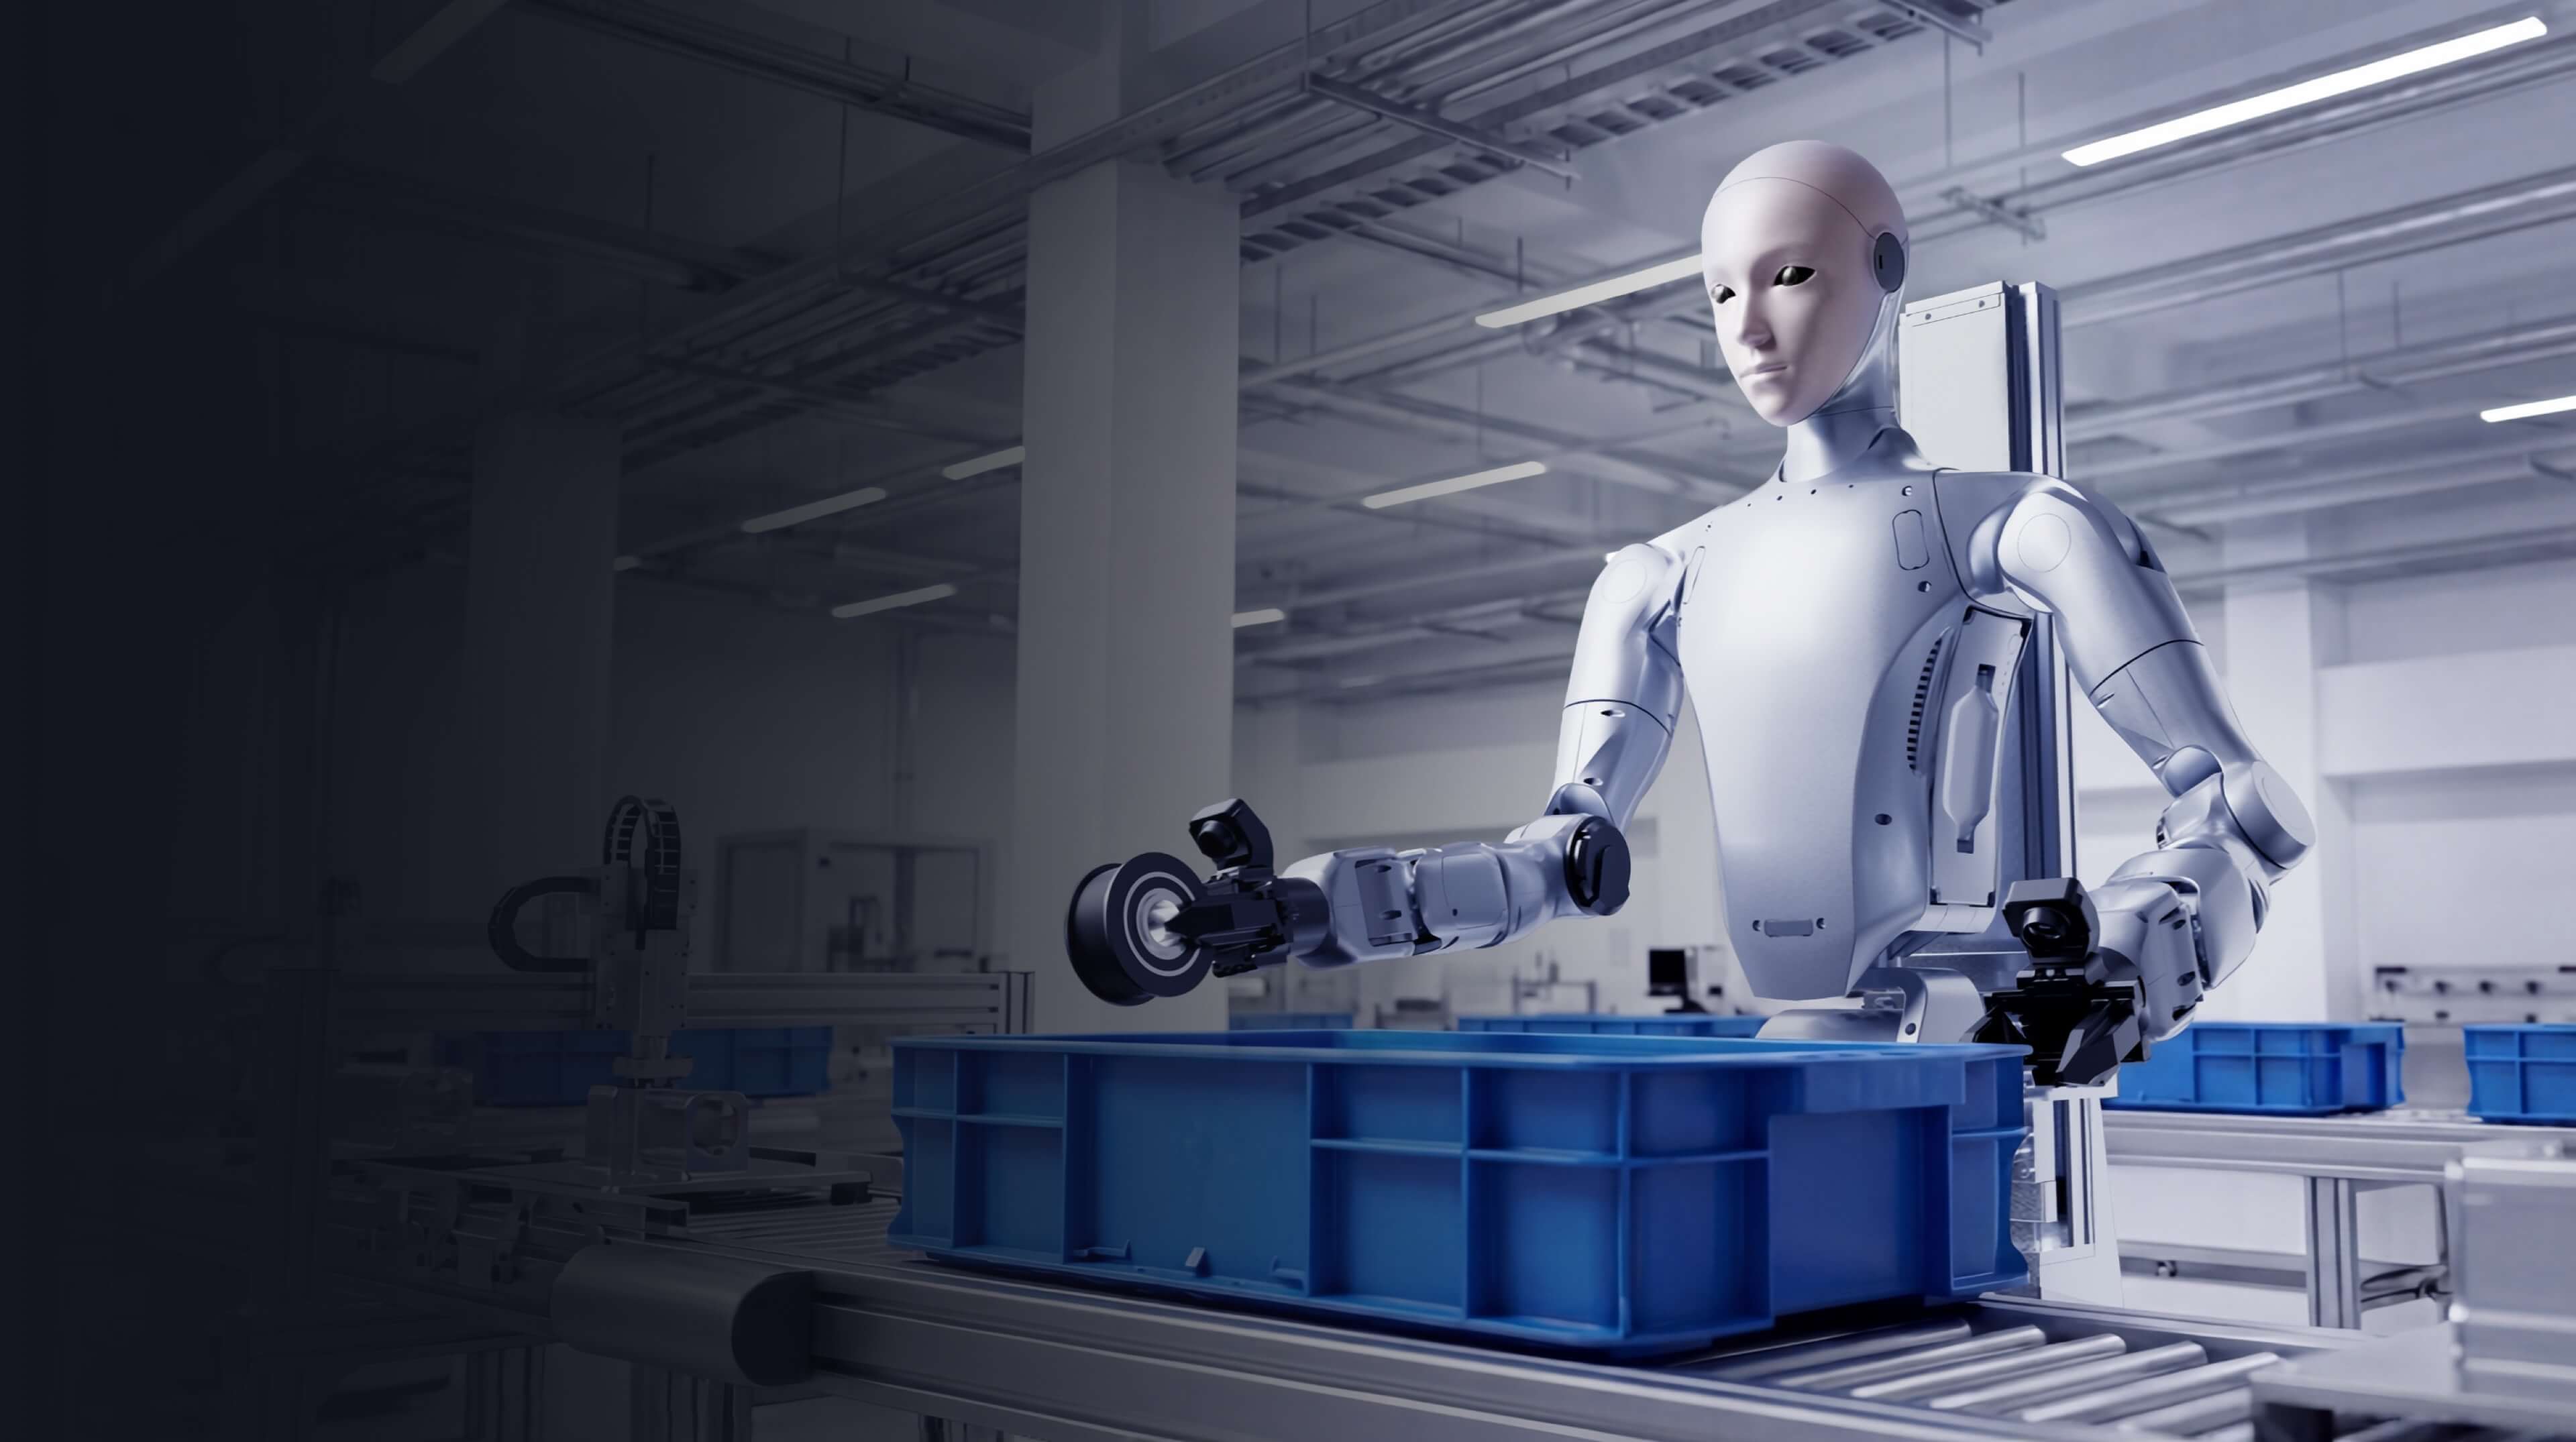
Mobile ChassisLiDAR Navigation SensorsInspire E232 DOF Total
H2-D Flagship — Mobile Chassis
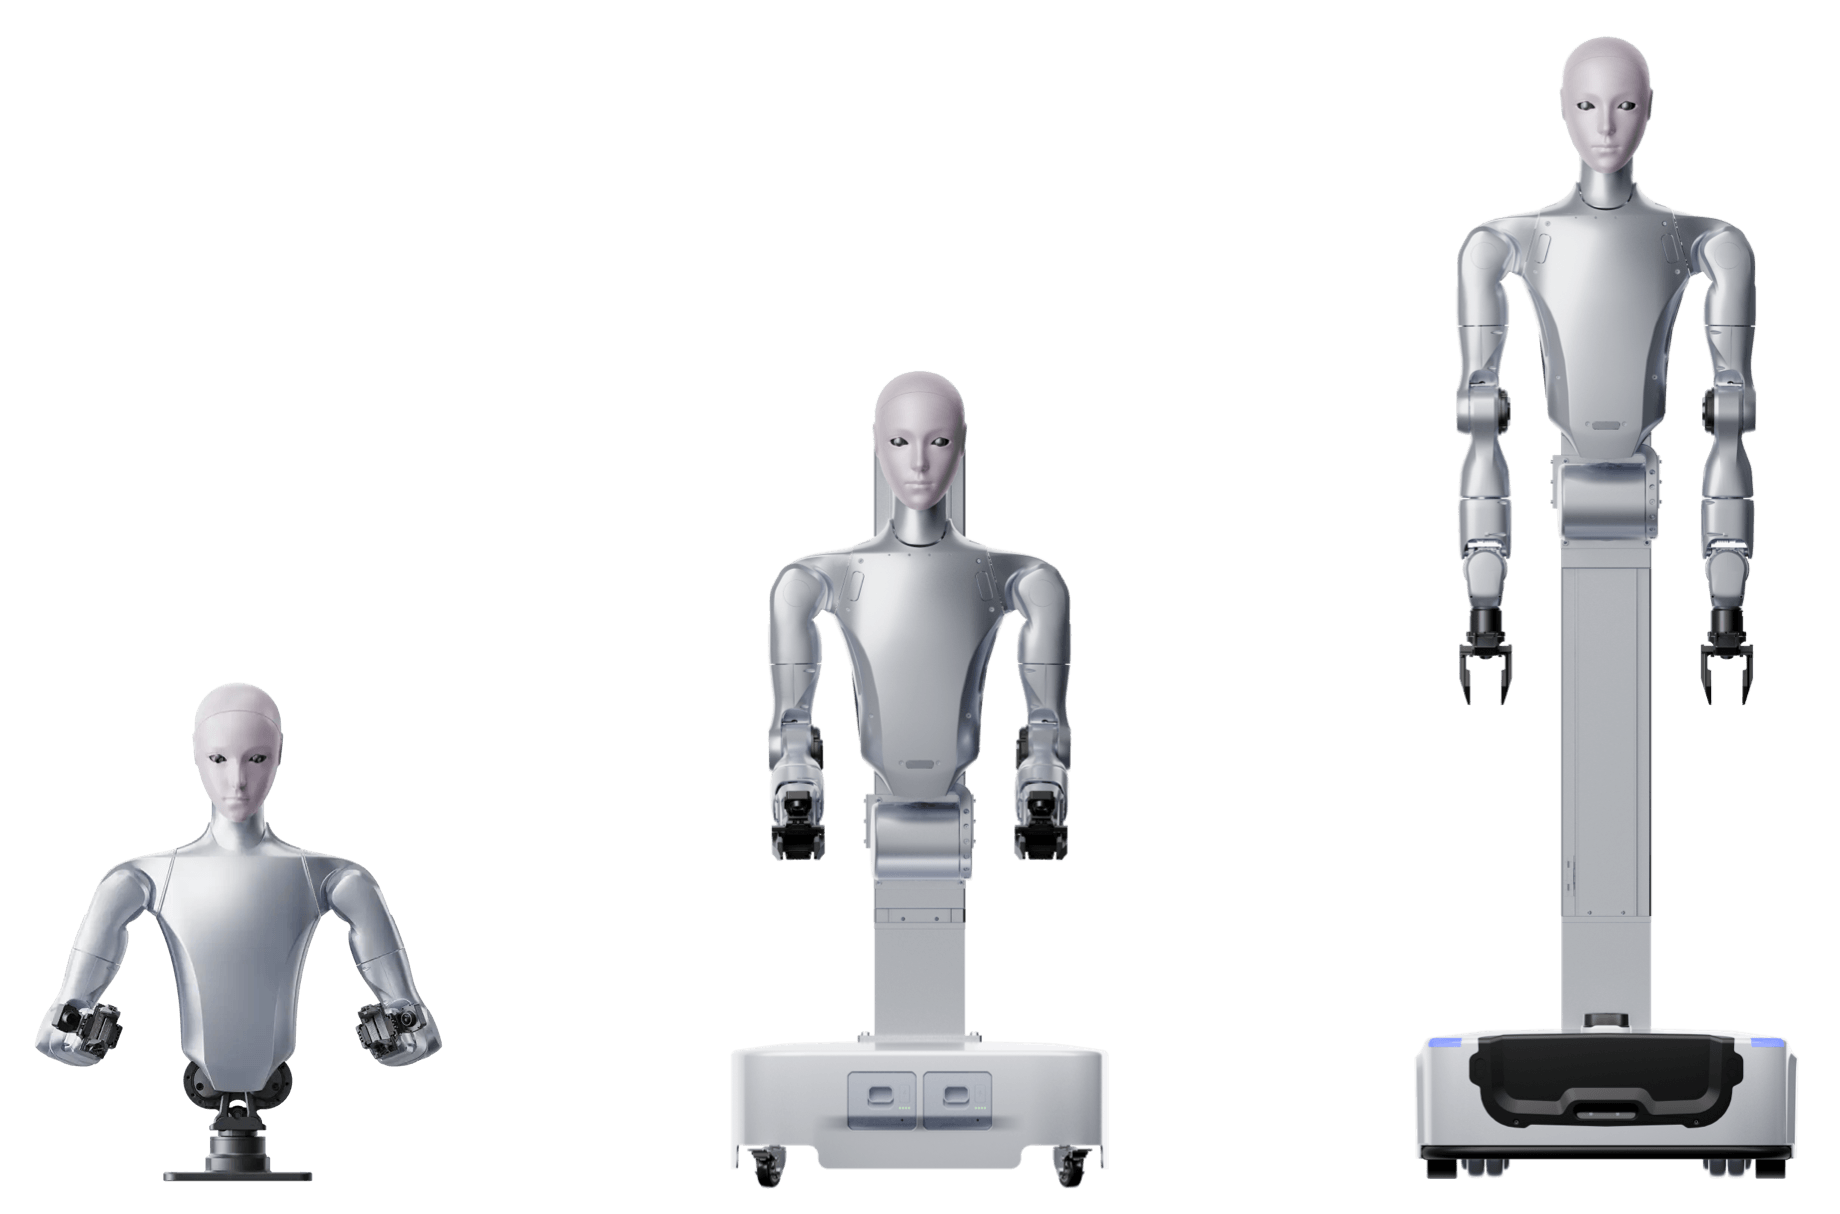
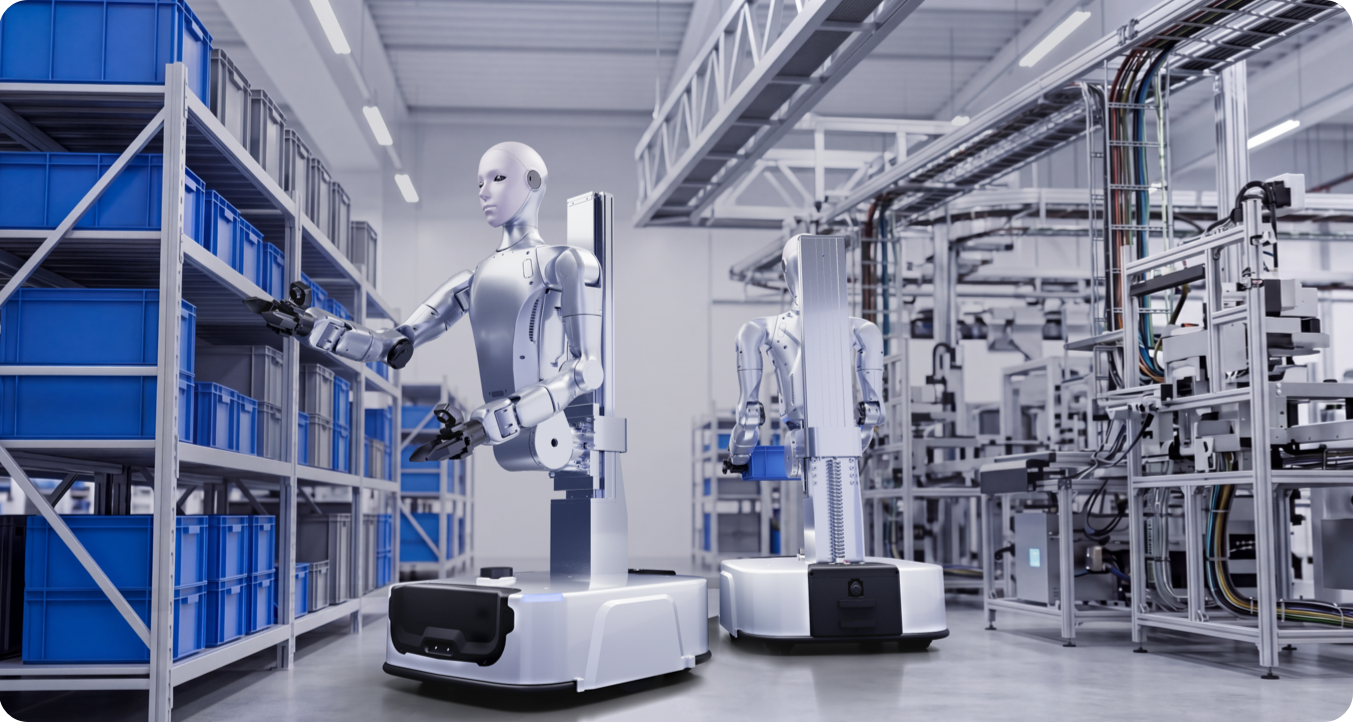
The H2-D Flagship combines the dual-arm semi humanoid upper body, a vertical lift column and a wheeled mobile chassis with LiDAR, depth camera, collision and ultrasonic sensors, designed for industrial operations, commercial services, research and development, and embodied intelligence training.
Configurable as a mobile manipulation platform for diverse production environments.
High-Performance Embodied AI Platform
Fully In-House Technology Stack
From self-developed actuators and force-controlled joints to motion control algorithms, the robot features an in-house technology stack with tightly integrated hardware and software. Supports secondary development and system customization for rapid deployment across industrial, commercial and research applications.
Multi-DOF Agile Motion
Featuring multiple highly integrated force-controlled joints, the robot supports omnidirectional mobility, vertical lift and body pitch while maintaining outstanding stability and mobility in confined and complex environments.
Multimodal Perception
Integrates vision, LiDAR, ultrasonic sensing, force feedback and voice interaction to build a multimodal perception system, enabling intelligent environmental awareness and natural human–robot interaction.
Biomimetic Design & Full-Body Mobility
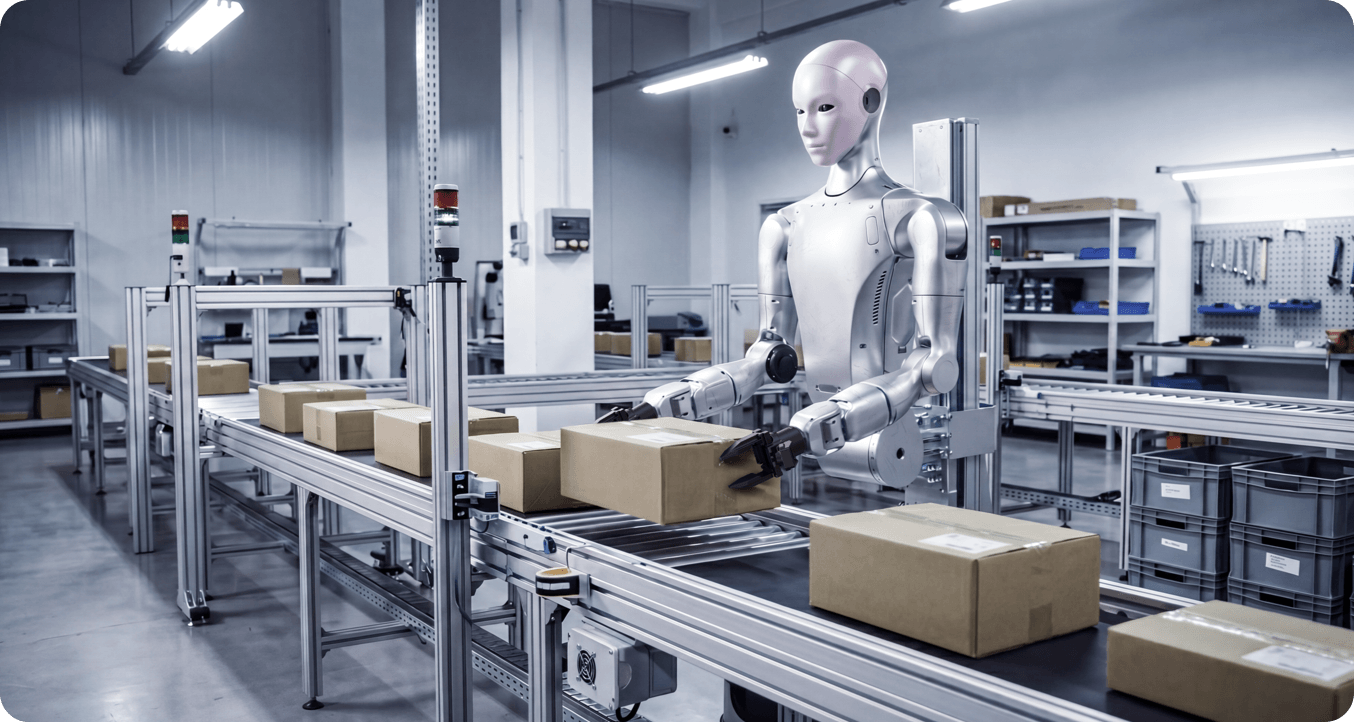
Mechanical Performance & Flexible Deployment
Supports a rated payload of up to 7 kg per arm, enabling efficient handling and assembly of heavy industrial components.
Mobile Chassis. Configurable as a mobile manipulation platform for diverse production environments.
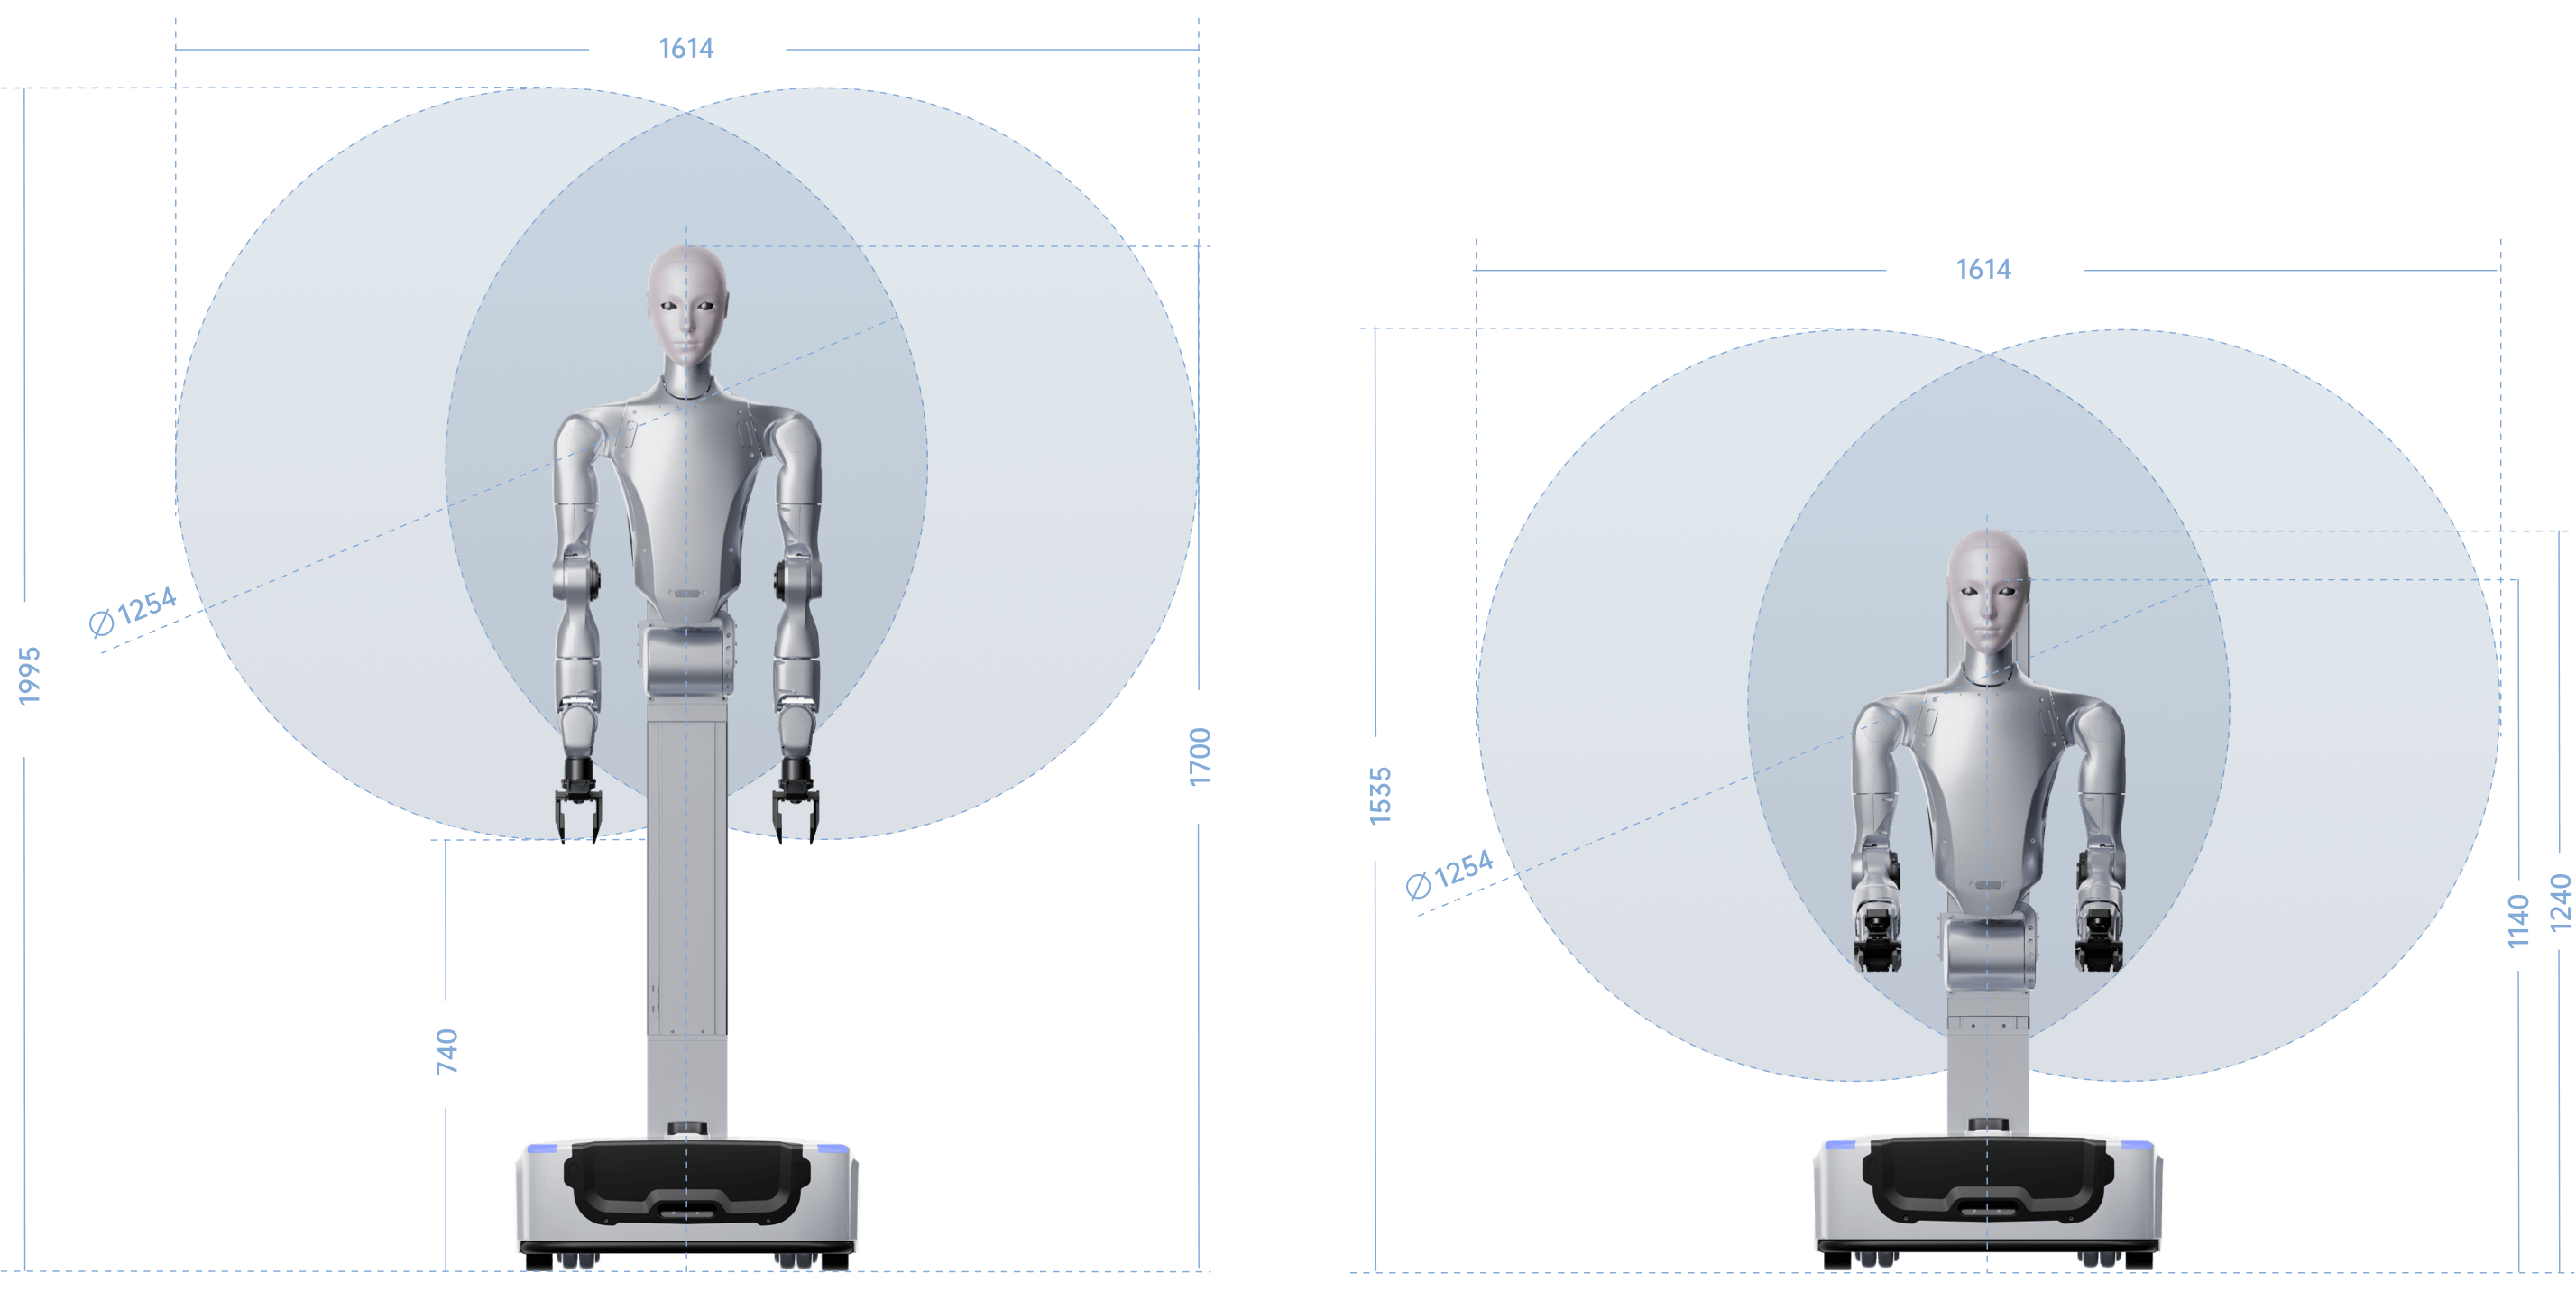
Expanded Workspace & Flexible Reach
By utilizing waist pitch adjustment, column vertical lift and whole-body coordination algorithms, the robot's operational workspace is extended, enabling flexible manipulation within a height range from ground level up to 2 meters.
Flexible Posture with Agile Pitch Motion
Supporting 0–115° body pitch, the robot adapts to floor-level picking and overhead handling while providing a natural and ergonomic operating experience.
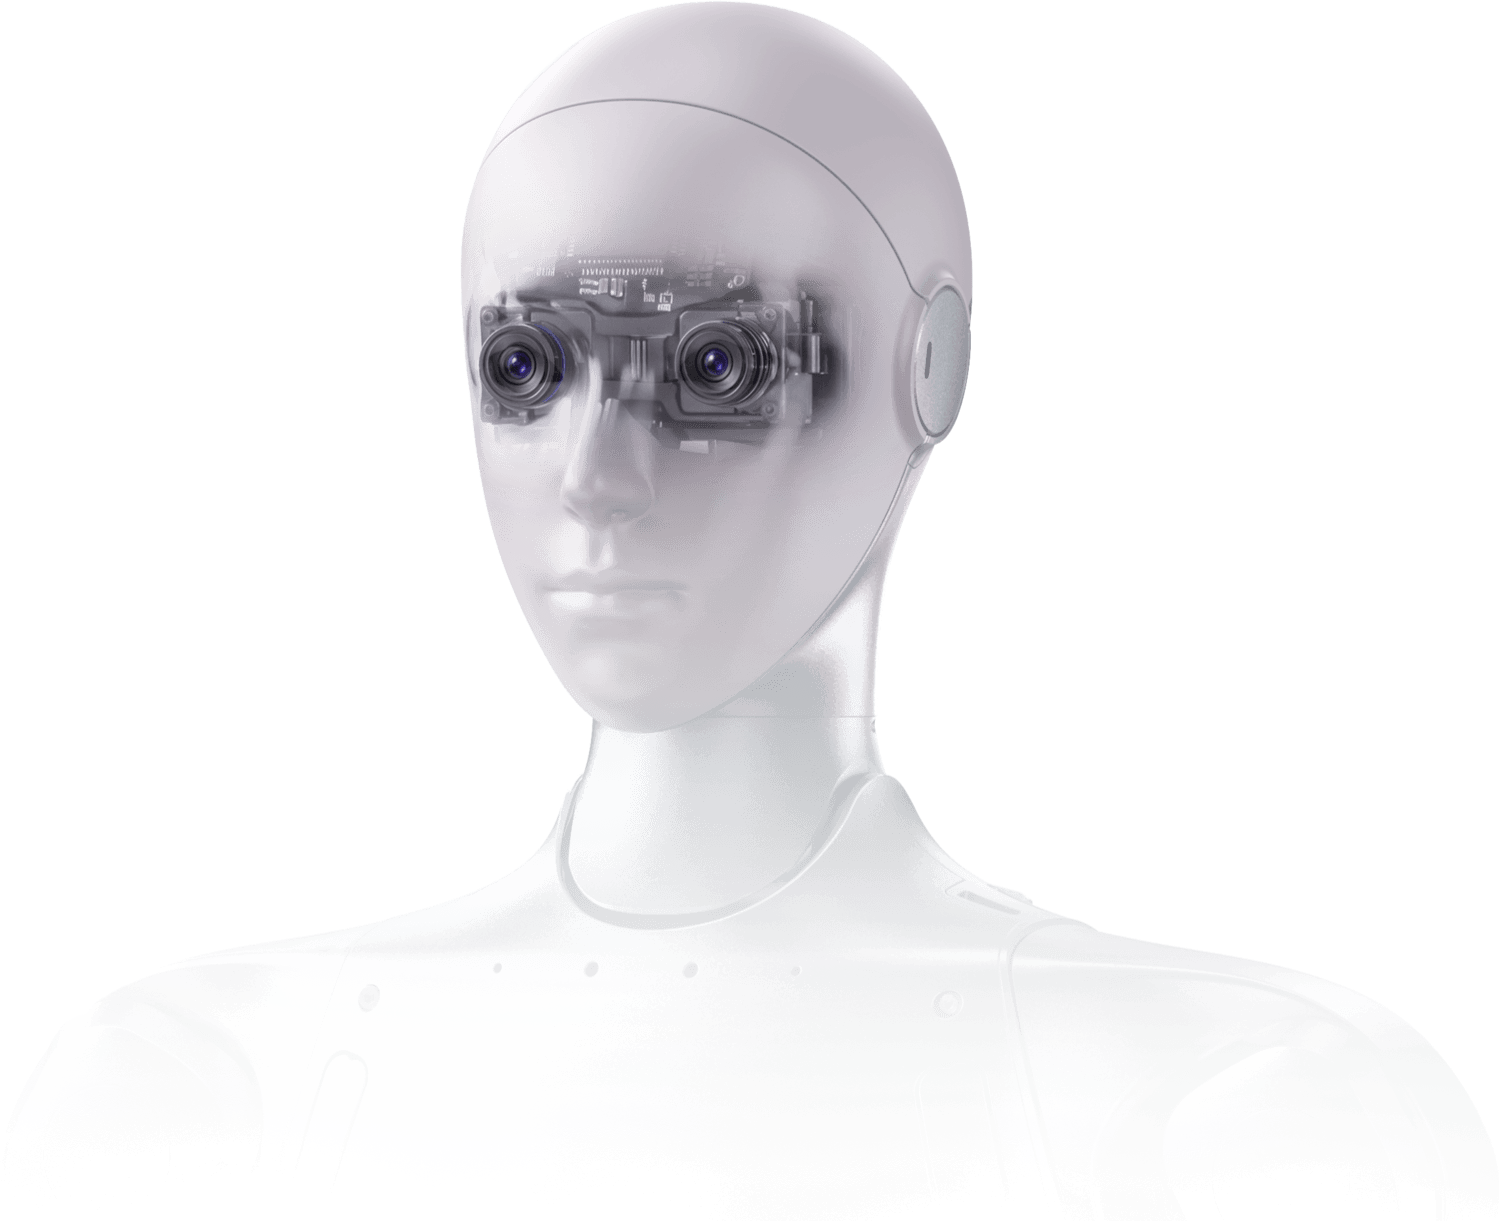
Multimodal Perception & Natural Interaction
Integrating binocular vision with natural language interaction, the robot enables intuitive and natural human–robot collaboration.
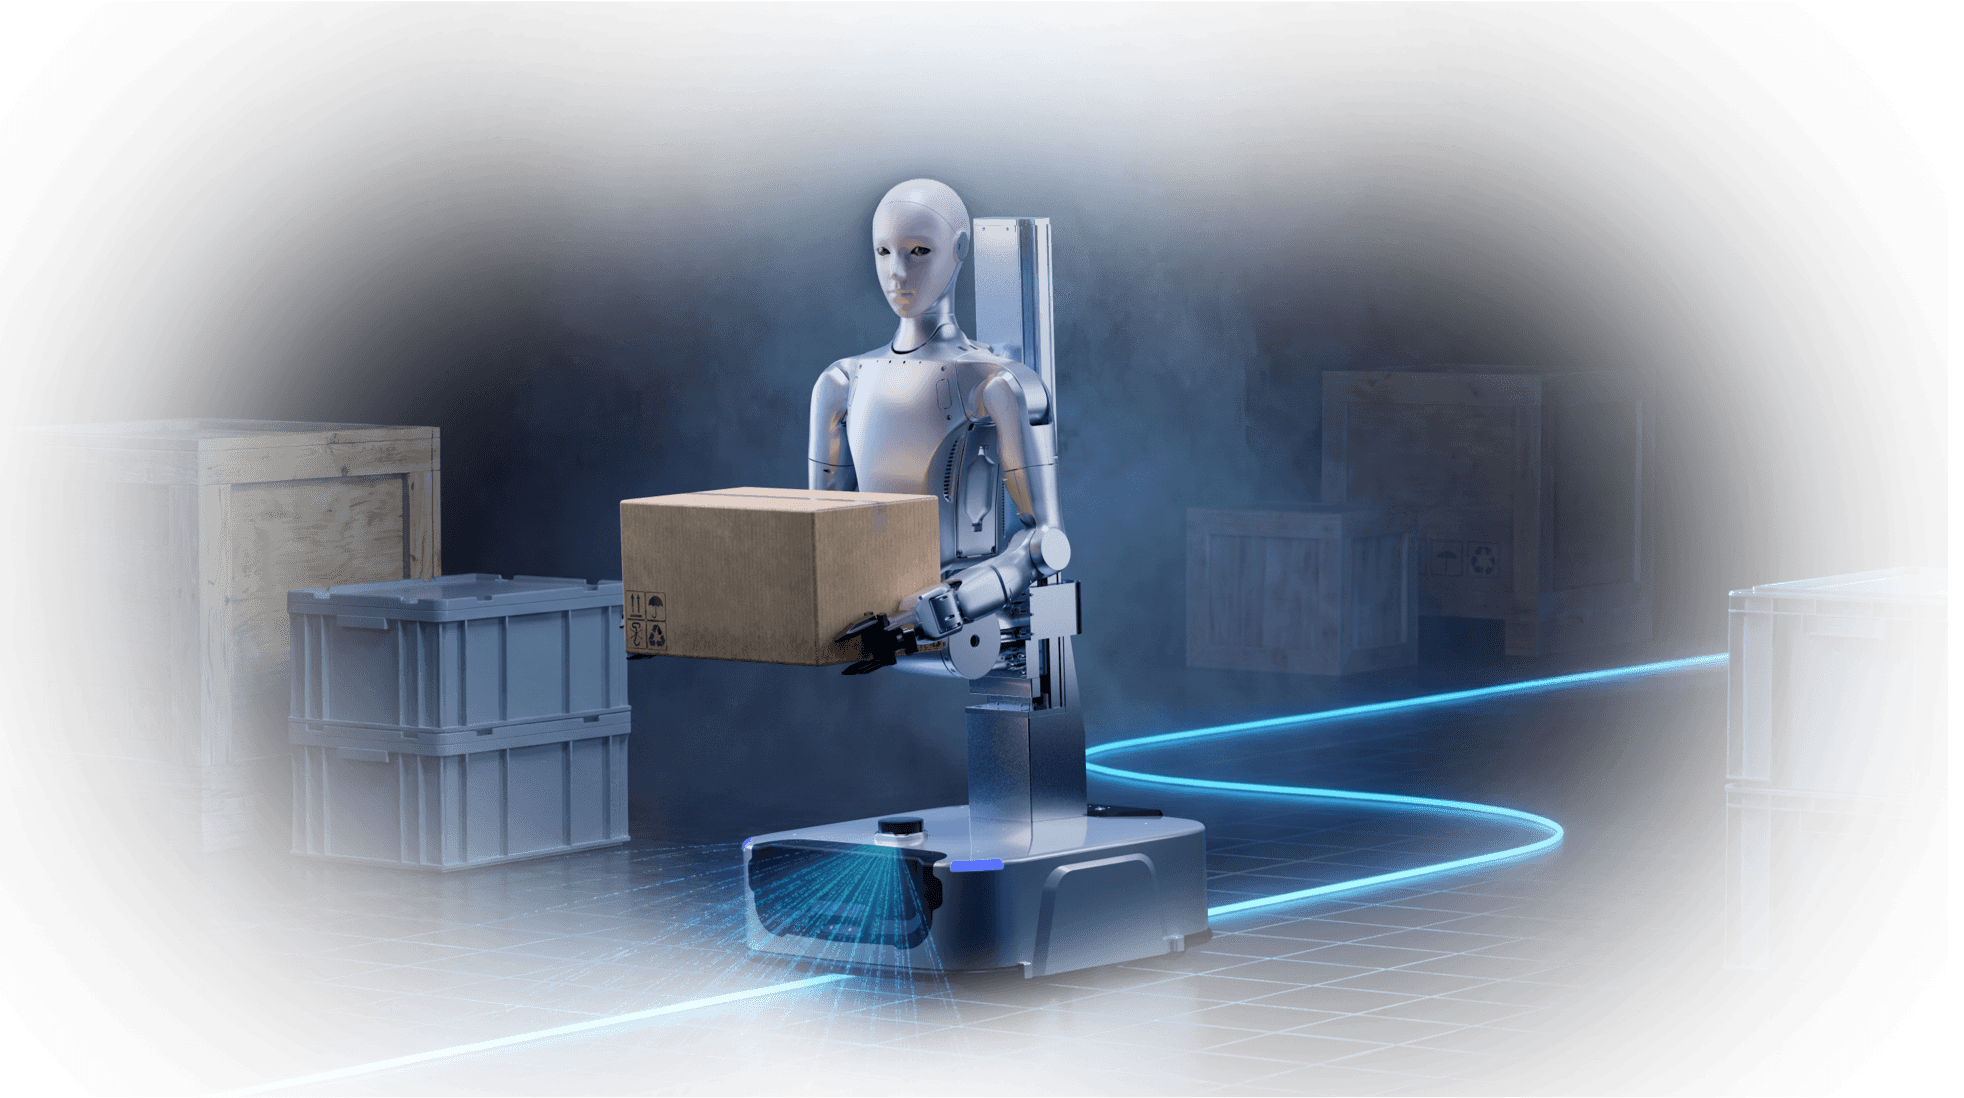
Dynamic Operation with Proven Stability and Reliability
The mobile platform integrates LiDAR, depth cameras and multiple sensors to enable autonomous navigation and intelligent obstacle avoidance. Combined with high-performance joints and whole-body dynamics algorithms, the robot coordinates mobility, manipulation and posture control to achieve precise operations in dynamic environments.
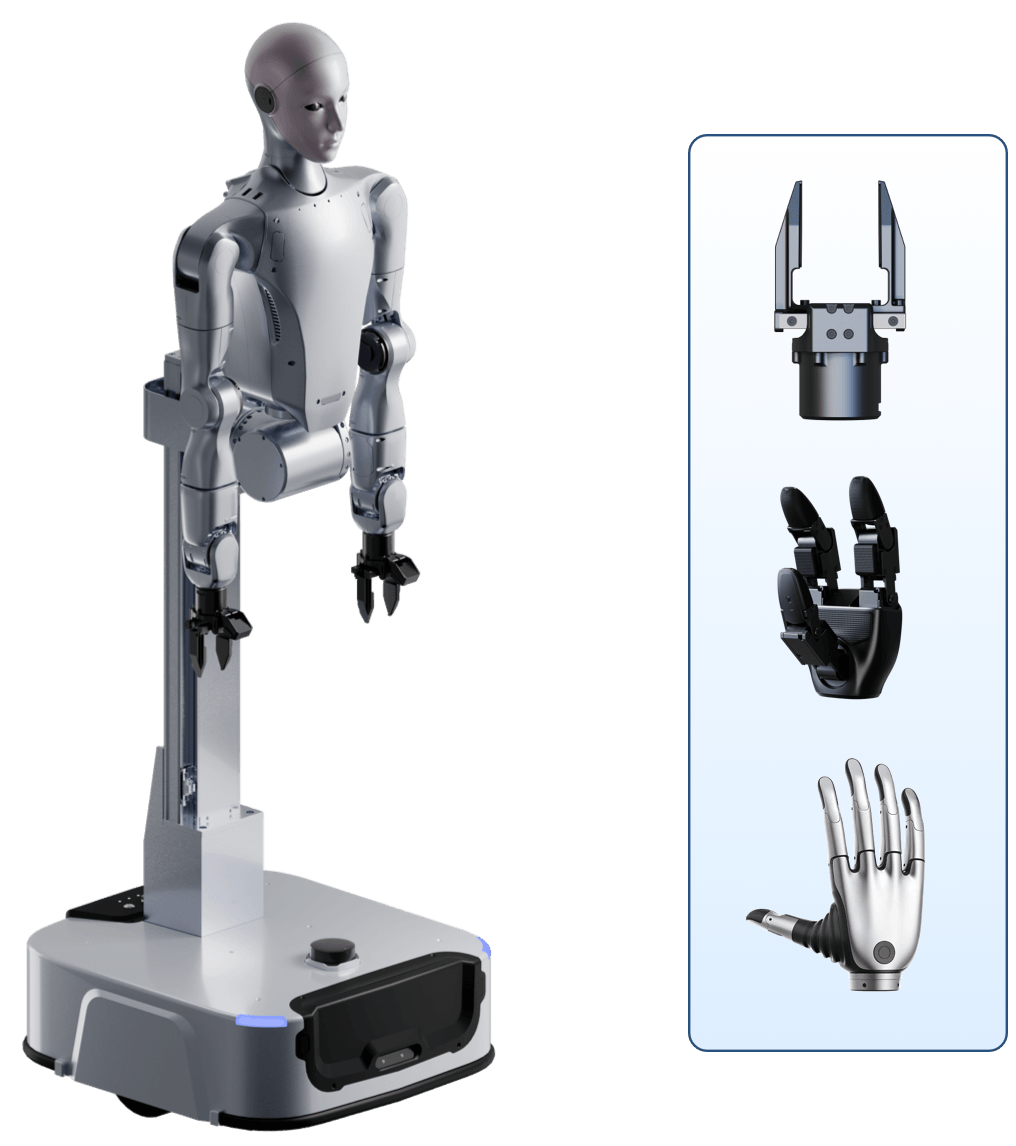
Multi-Type End Effectors & Flexible Adaptation
Supports multiple end-effectors including grippers, three-finger hands and five-finger dexterous hands. Quick-change design enables rapid adaptation to different precision requirements and workload conditions.
This version: Inspire E2 five-finger dexterous hand (with tactile sensing).
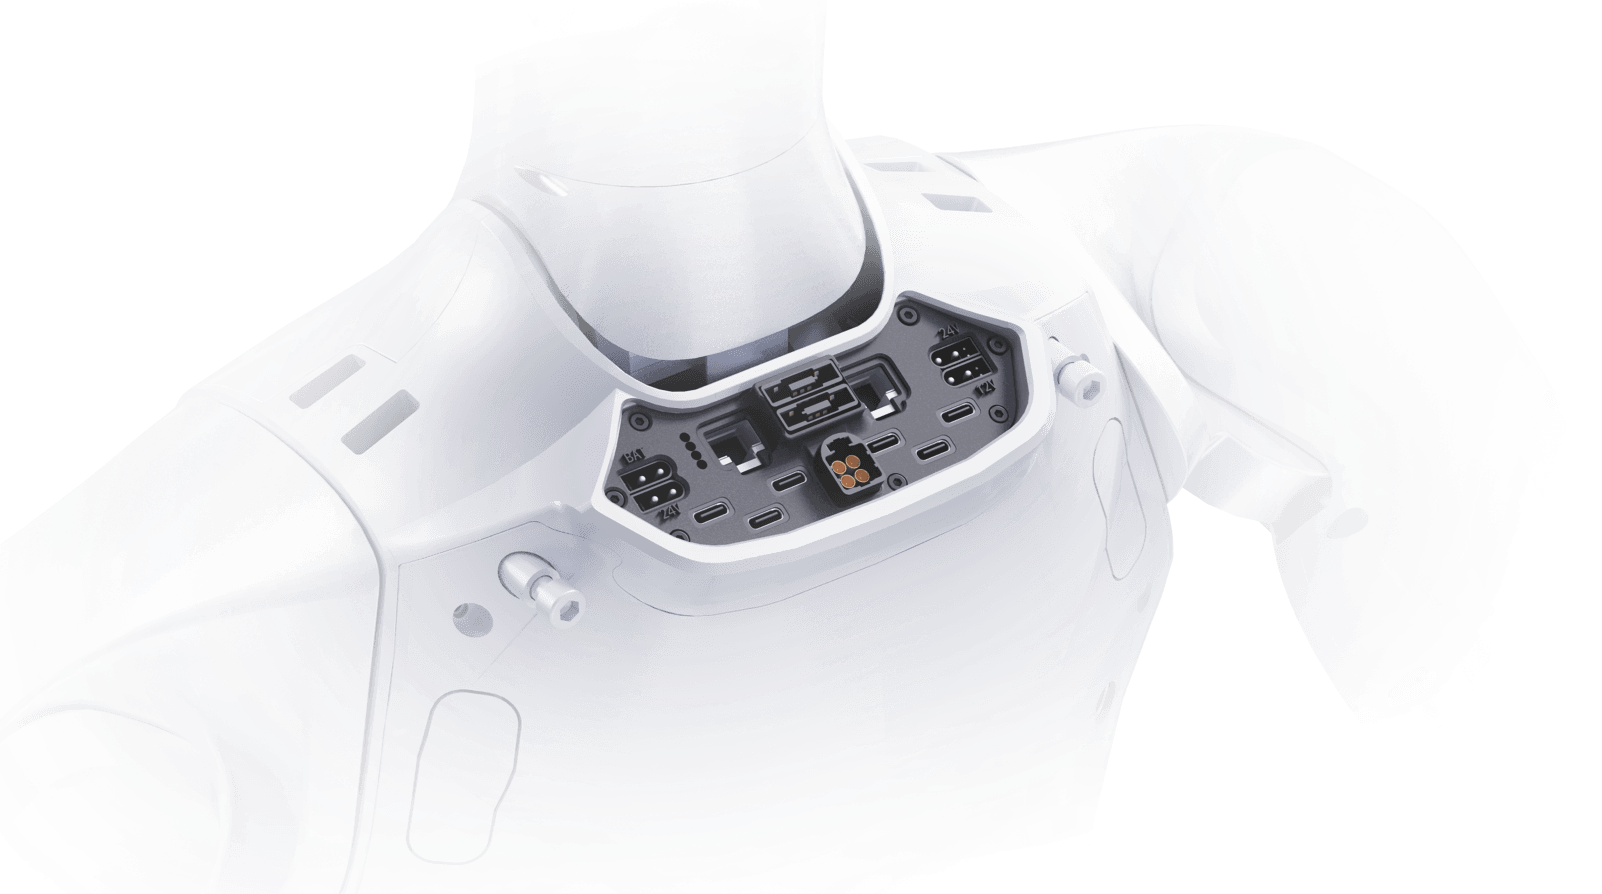
Open Development & Rapid Deployment
Comprehensive SDKs and APIs, together with a mature navigation software stack, enable developers to focus on application innovation while reducing development cycles from months to weeks.
H2-D Flagship I — Version Highlights
Inspire E2 five-finger dexterous hand (with tactile sensing) — includes all functions of H2-D Flagship A.
| End Effector | Inspire E2 five-finger dexterous hand, with tactile sensing (with wrist camera) |
|---|---|
| DOF per Hand | 6 |
| Number of Joints | 12 |
| Weight | 790g ±10g |
| Operating Voltage | 24V ±10% |
| Static Current | 0.25A |
| Max Current | 4A |
| Fingertip Repeat Positioning Accuracy | ±0.20mm |
| Fingertip Gripping Force | Thumb 30N, four fingers 28N |
| Thumb Side-Swing Speed | >130°/s |
| Thumb Flexion Speed | >130°/s |
| Four-Finger Flexion Speed | >200°/s |
| Tactile Sensor Range | 0–30N |
| Tactile Sensor Accuracy | ≤5%FS |
| Number of Tactile Sensors | 17 |
| Palm Closing Time | 0.8s |
| Wrist RGB Camera | FOV D 130° / H 120° / V 81°, resolution 1920×1080 |
| Total DOF | 32 (7×2 (arms) + 1 (waist) + 2 (head) + 1 (column) + 2 (chassis) + 6×2 end-effector) |
Technical Specifications — H2-D Flagship I
| Overall Dimensions | 1200×576×620mm (min. column height) / 1700×576×620mm (max. column height) |
|---|---|
| Weight (incl. battery) | 135kg |
| DOF (excl. end-effector) | 20 (arms 7×2 + waist 1 + head 2 + column 1 + chassis 2) |
| DOF (incl. end-effector) | 32 (7×2 (arms) + 1 (waist) + 2 (head) + 1 (column) + 2 (chassis) + 6×2 end-effector) |
| Arm DOF (excl. end-effector) | 7 per arm |
| Waist DOF | 1 (bending / pitch) |
| Head DOF | 2 |
| Column DOF | 1 (vertical lift) |
| Chassis DOF | 2 (forward/backward movement and 360° rotation) |
| Waist Range of Motion | Pitch 0°–115° |
| Single-Arm Max Load | ~7kg (rated); peak ~15kg |
| Single-Arm Reach (with two-finger gripper) | ~0.62m |
| Lift Speed | Up to ~200mm/s |
| Lift Stroke | 0.5m |
| Joint Output Bearing | Industrial-grade cross-roller bearing (high precision, high load-carrying capacity) |
| Joint Motor | Low-inertia high-speed inner-rotor permanent magnet synchronous motor (enhanced dynamic response and thermal performance) |
| Max Arm Joint Torque | 120N·m |
| Overall Material | Aerospace-grade aluminum, titanium alloy and high-strength engineering plastics |
| Max Speed | 1.5m/s |
|---|---|
| Drive | Servo motors, dual-wheel differential drive, supports 360° in-place rotation |
| Turning Diameter | ~0.75m |
| Chassis Sensors | LiDAR ×1, depth camera ×1, physical collision sensor ×2, ultrasonic sensor ×2 |
| PC1 | Intel Core i5 (platform functions) |
|---|---|
| PC2 | Intel Core i7 (user development) |
| PC3 | Empty slot, similar to B2 card-slot form (optional NVIDIA Jetson Thor ×1, available for a fee) |
| PC4 | Empty slot, similar to B2 card-slot form (optional Intel Core i7 ×1 or NVIDIA Jetson Orin NX ×1, available for a fee) |
| High-Performance Computing Module | Multiple brands and models available, such as Thor |
| Head Camera | Wide-angle semi humanoid binocular camera ×1 |
| Wrist Cameras | Wrist HD camera ×2 |
| Voice Interaction | Microphone array and high-power speaker for natural voice interaction |
| Wireless | WiFi 6, Bluetooth 5.2 |
| Cooling | Air cooling |
| Power Supply | Removable internal battery in the mobile base; standard charging pile kit and external power options included. The battery cannot be placed in the upper body. |
|---|---|
| Battery | Quick-release base battery 48V/30Ah (1.44kWh) |
| Endurance | Approx. 5 hours (battery swap / auto recharge supported) |
| Direct Power Supply | 7×24 hours |
| Visual PC | Standard |
| End Effector | Inspire E2 five-finger dexterous hand, with tactile sensing (with wrist camera) |
|---|---|
| DOF per Hand | 6 |
| Number of Joints | 12 |
| Weight | 790g ±10g |
| Operating Voltage | 24V ±10% |
| Static Current | 0.25A |
| Max Current | 4A |
| Fingertip Repeat Positioning Accuracy | ±0.20mm |
| Fingertip Gripping Force | Thumb 30N, four fingers 28N |
| Thumb Side-Swing Speed | >130°/s |
| Thumb Flexion Speed | >130°/s |
| Four-Finger Flexion Speed | >200°/s |
| Tactile Sensor Range | 0–30N |
| Tactile Sensor Accuracy | ≤5%FS |
| Number of Tactile Sensors | 17 |
| Palm Closing Time | 0.8s |
| Wrist RGB Camera | FOV D 130° / H 120° / V 81°, resolution 1920×1080 |
| Handheld Remote Controller | Yes |
|---|---|
| Smart OTA Update | Yes |
| Secondary Development | Yes |
| Warranty | 12 Months |
Frequently Asked Questions
What is the H2-D Flagship I?
The H2-D Flagship I is a mobile dual-arm semi humanoid robot with a vertical lift column and a wheeled chassis, fitted with Inspire E2 five-finger dexterous hand (with tactile sensing), with wrist cameras. It includes all functions of H2-D Flagship A. Tactile sensing: Yes (17 sensors).
What are the dimensions and weight of the H2-D Flagship I?
It measures 1200×576×620mm at minimum height and 1700×576×620mm at maximum height, and weighs 135kg including the battery.
How many degrees of freedom does the H2-D Flagship I have?
Excluding the end-effector it has 20 DOF (arms 7×2, waist 1, head 2, column 1, chassis 2). The column provides lifting and the chassis provides forward/backward movement and 360° rotation. With the 6-DOF end-effector on each side, the total is 32 DOF.
How fast is the H2-D Flagship I chassis, and what sensors does it carry?
The servo-driven dual-wheel differential chassis reaches 1.5m/s and supports 360° in-place rotation with a turning diameter of about 0.75m. It carries a LiDAR, a depth camera, 2 physical collision sensors and 2 ultrasonic sensors.
How is the H2-D Flagship I powered, and is it open for development?
It uses a removable base battery, 48V/30Ah (1.44kWh), with a standard charging pile kit and external power options; the battery cannot be placed in the upper body. Endurance is about 5 hours with battery swap and auto recharge supported. It supports secondary development and smart OTA updates, includes a handheld remote controller and visual PC, and carries a 12-month warranty.
The full sheet
Related products
-
·LND·00
-
·LND·01
-
·LND·02
 Unitree Go2 Air- Robot Dog (Without Controller)Original price was: ₹292,373.₹249,153Current price is: ₹249,153. (Excl. GST)Add to cart
-
·LND·03
 Unitree B2- Basic Version with 3D LIDAR Robot Dog (Industry grade)₹8,516,949 (Excl. GST)Add to cart

There are no reviews yet.